Week-4 Challenge WOT Condition Part-2
1.
Mapped Engine: Mapped Engine is the default settings in powertrain blockset. It is used to measure to measure performance parameters of the vehicle by using standard lookup tables which are prefed to the system. This type of modelling is less accurate. The lookup tables value are based on the values of brake torque, commanded torque and engine speed. If any other parameter like Input engine temperature is selected then lookup table values are also a function of the temperature parameter.
Dynamic Engine: This type of model uses real time data fed by the user at run time for modelling. This model is more accurate than mapped engine model. This type of model is used when the data of subsystems of a vehicle is required. We can calculate : Brake torque, fuel flow, port gas mass flow, exhaust temperature, exhaust mass flow rate and exhaust emissions.
Mapped Motor: The mapped motor works in torque control mode. This type of motor is used when the user requires a faster simulation and doesn't have the knowledge of motor parameters. The output torque and reference torque is compared and changes are made. Input torque or speed can be specified, electrical losses and maximum motor power and torque can be defined.
Dynamic Motor: In the dynamic motor a three phase interior permanent magnet synchronous motor (PMSM) is used. The block uses three phase input voltages to regulate the individual phase currents, allowing control of the motor torque or speed. This block is used when the user knows what parameters are to be used in that particular simulation. This motor is more accurate.
Mapped Generator: The mapped generator block is also similar like other blocks. Most of the data required is taken from the lookup tables corresponding to the given input parameters. Its simulation time is less.
Dynamic Generator: The dynamic generator involves user entering the parameters manually during the run time for their particular applications. The results take time and are more accurate.
We can change the model from mapped to dynamic by following procedures:
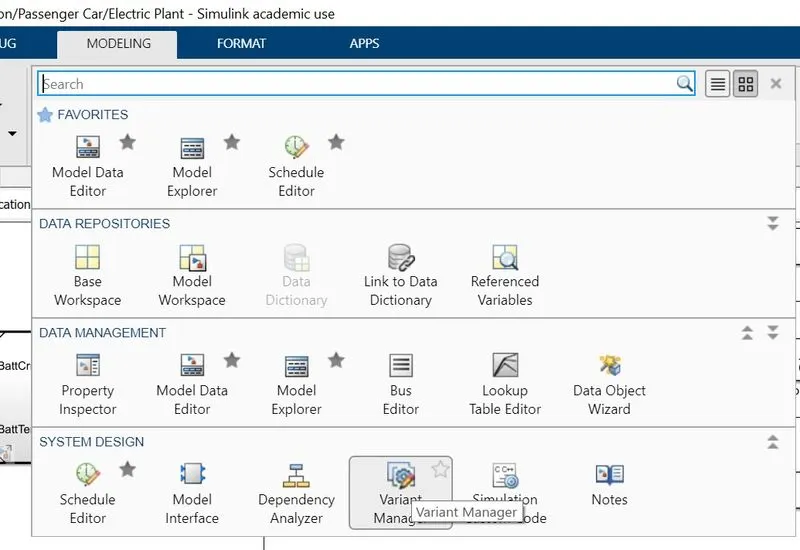
First go to 'MODELING' and selelct the 'Variant Manager' option.
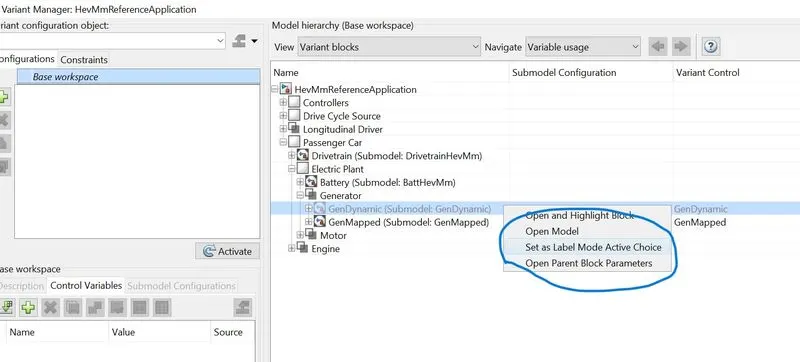
Next select the model which we want to change from that 'Variant Modeling' window.
And after that click on 'set as label mode active choice',Now the model will be changed.
2.
Miles per gallon (MPG) is the unit of measurement for cars to find out the fuel efficiency. In electric vehicle it is replaced with a unit named miles per gallon equivalent (MPGe).
1Gallon of gas=33.7 kwh of electricity
In HEV reference model, we can see performance calculation subsystem if we observe in visualization subsystem.
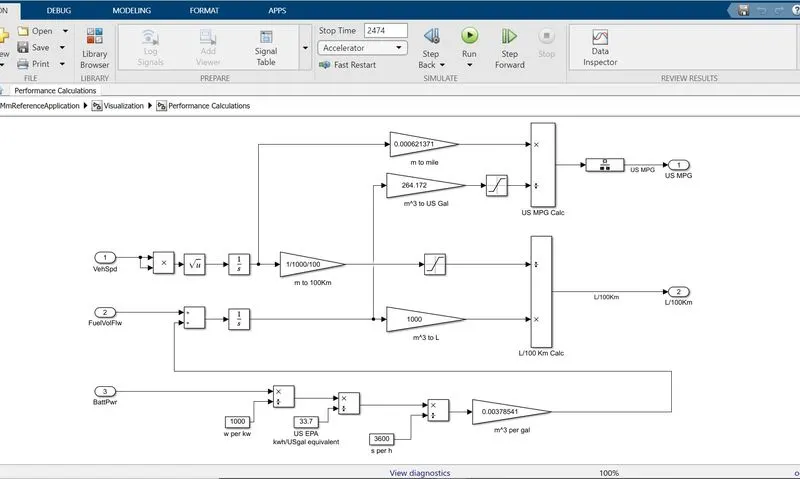
Here,three different inputs are taken into considerations:
1.vehicle speed.
2.fuel flow.
3.battery power.
The battery power is first converted into KW (W/1000) then its divides by 33.7 kwh, vehicle speed inputs is in m/s which is converted into miles by multiplying with 0.000621371.And the fuel equivalent of battery is added to the fuel flow. Using the vehicle speed and time the distance of travel is calculated. Then distance is converted into miles by conversions. Then as we have the fuel flow in m^3 and distance in miles. We can calculate the fuel efficiency.
3.
The hybrid electric vehicle (HEV) reference application represents multi model HEV with an internal combustion engine, transmission, battery, motor, generator and associated power train control algorithms. The HEV is configured with a mapped motor and battery. This diagram shows the power train configuration.
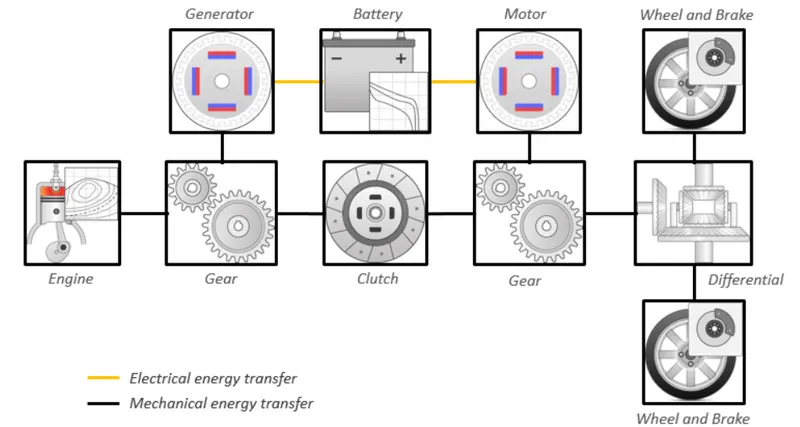
First open Hev reference application in matlab.
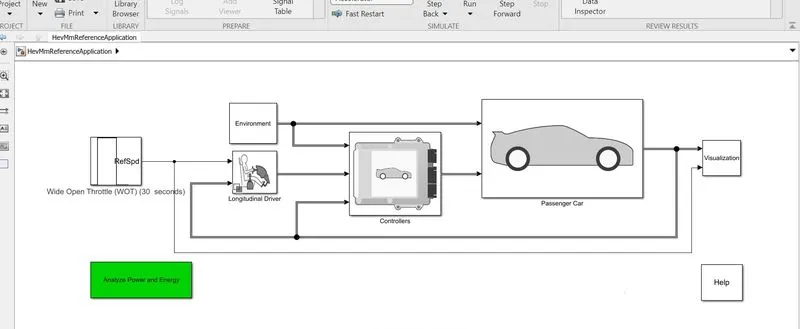
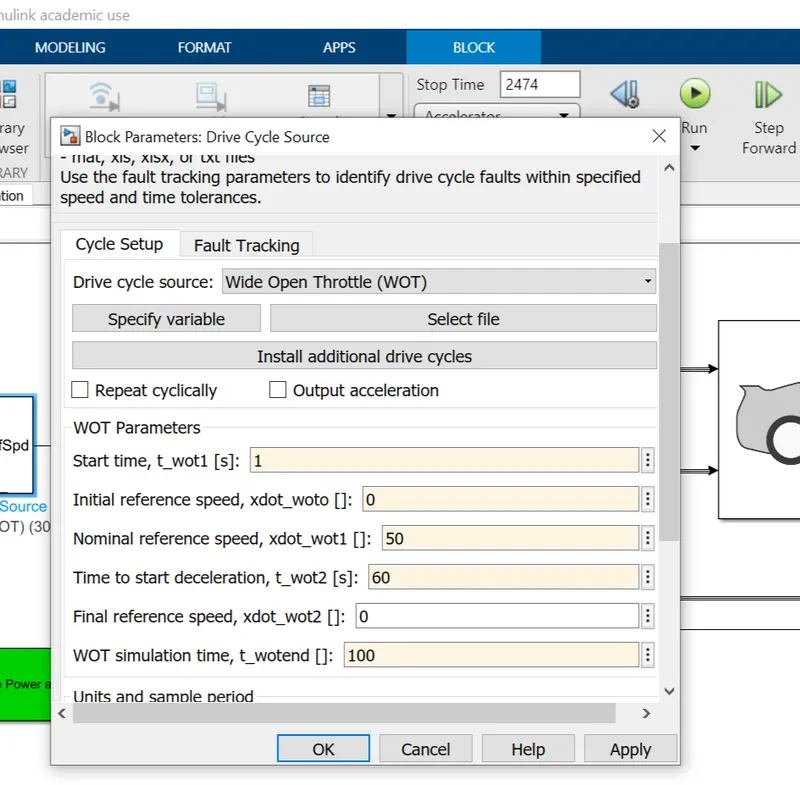
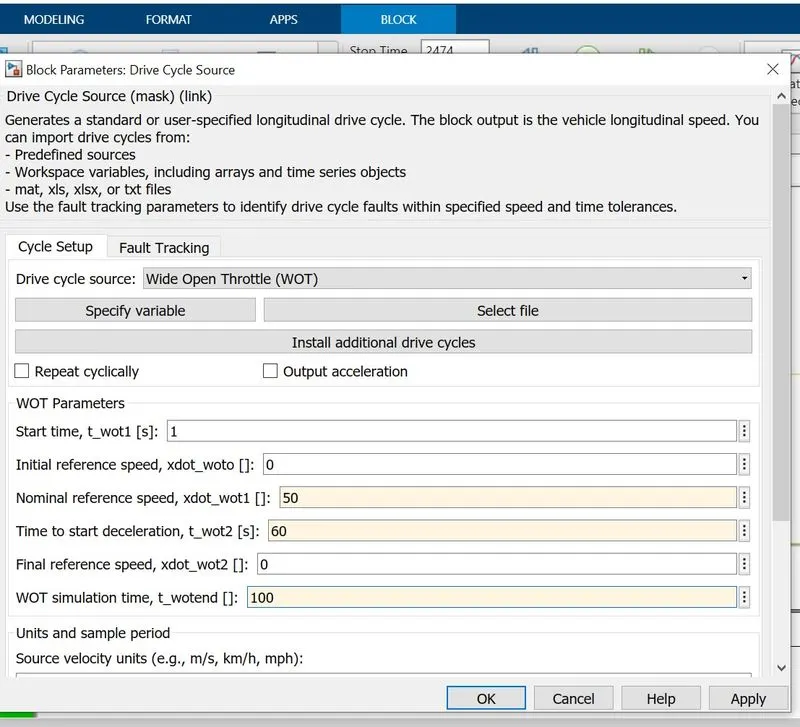
Then click on 'Drive cycle source' block and change the drive cycle to 'Wide Open Throttle(WOT)'.Also configure the parameters like below .
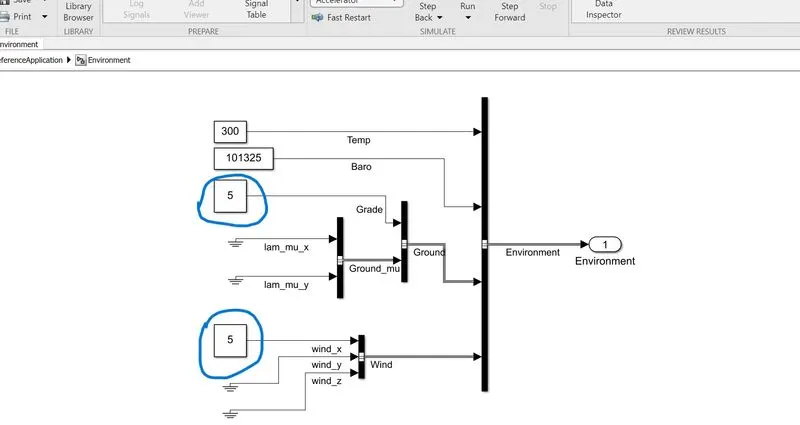
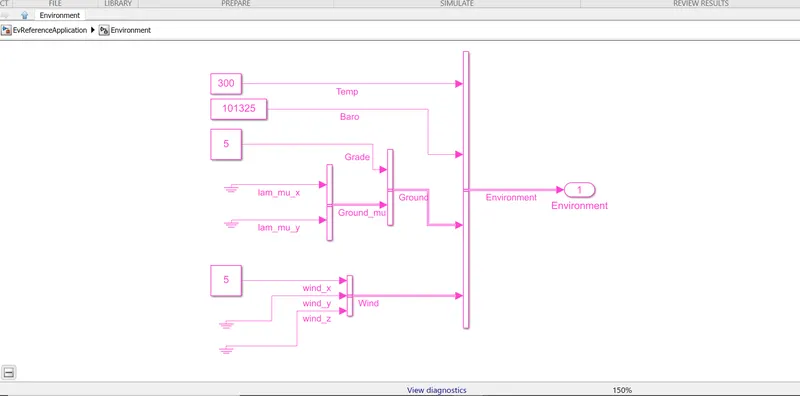
And next click on 'Environment' block to change th e grade and wind velocity.
After that the simulation is carried out and the results are obtained.
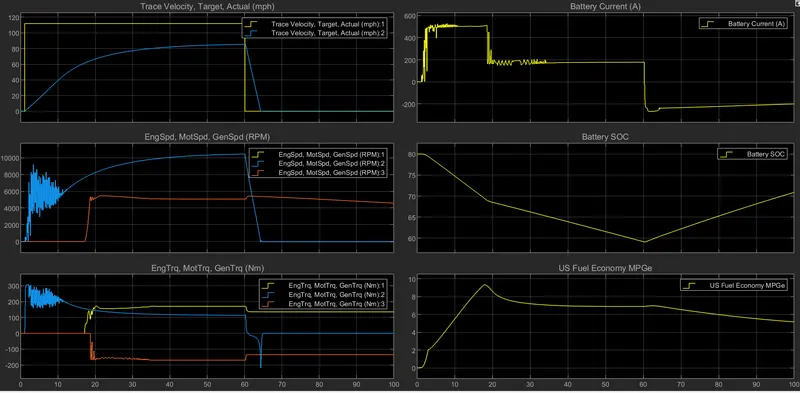
From the above graphs we can see that,
Trace Velocity target and actual graph: The yellow line indicates the desired path and blue line is the actual path. So it can be seen that battery power is not enough to meet the requirements of the grade and wind velocity.
Battery Current Graph: When the vehicle is accelerating the battery current is also increasing. When the velocity is constant the current requirement also becomes constant. When the deceleration starts the battery current becomes negative indicating regenerative braking.
Battery SOC: The battery SOC keeps on depleting until regenerative braking starts. This increases the SOC.
Engine, Motor and Generator Speed: Initially only motor is used to start the vehicle as motor has high initial torque. Later generator (red graph) kicks in charging the battery when SOC drops below 70%. Engine graph can't be seen as it may have overlaped with generator.
Engine, Motor and Generator Torque: Motor torque is high initially (blue line) and then engine kicks in at a later stage (yellow line). Generator torque (red line) is negative as its charging the battery.
4.Comparison with EV Reference Application
The electric vehicle (EV) reference application represents a fully electric vehicle model with a motor, generator, battery, direct drive transmission and associated power train control algorithms. The EV is configured with a mapped motor and battery.
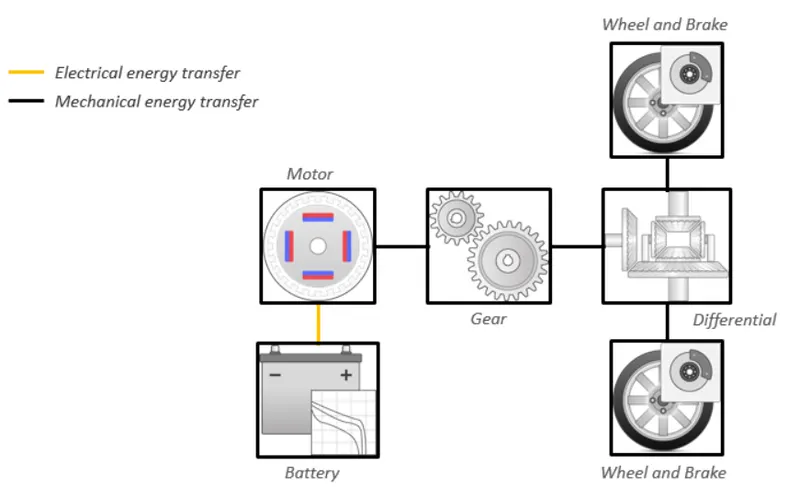
Now simulating the EV with WOT drivecylce, wind velocity as 5m/s, grade as 5 degree and keeping the rest of the parameters same as above HEV case.
Rsults:
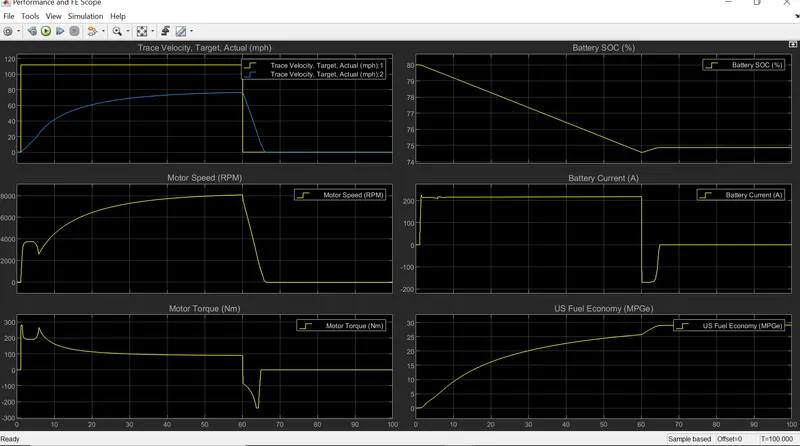
Conclusion:
1. The first graph (target and actual velocity graph) performance is almost same. the reason could be that in that region only motor was operating so the performance in both EV and HEV is similar.
2. The battery current drawn by HEV initially is upto 500 A and later decreases to 200 A. This can be attributed to the fact that initially only motor takes all the load and later engine kicks in so motor load drops thus current drawn by motor reduces. And during the deceleration it is seen that negative current (regenerative braking) flows for a longer time in HEV as compared to EV. So we can say that, regenerative braking is more aggressive in HEV.
3. SOC improvement of almost 15% is seen in HEV during deceleration and only 2% improvement can be seen in EV during deceleration. This can be understood by the same reason explained in point 2.
4. Motor torque and motor speed are stable in EV and they keep fluctuating a lot in HEV during the starting. Also the peak RPM of the motor in EV is less than HEV. These differences can attributed to the fact that battery power of EV is more than HEV.
5. Fuel economy of EV is significantly greater than HEV. This is because electric motor is more efficient than engine.
REFERENCES: