Week-4 Challenge WOT Condition Part-2
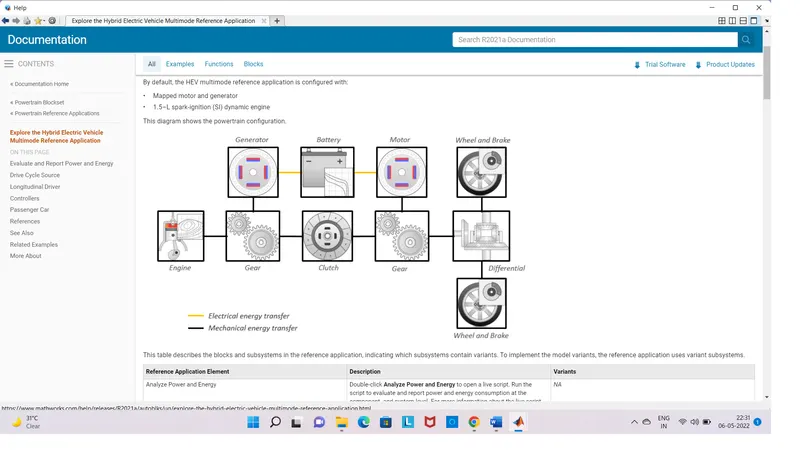
1.What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
Mapped motor or Static Model:-
Its Work faster and driven based on lookup table
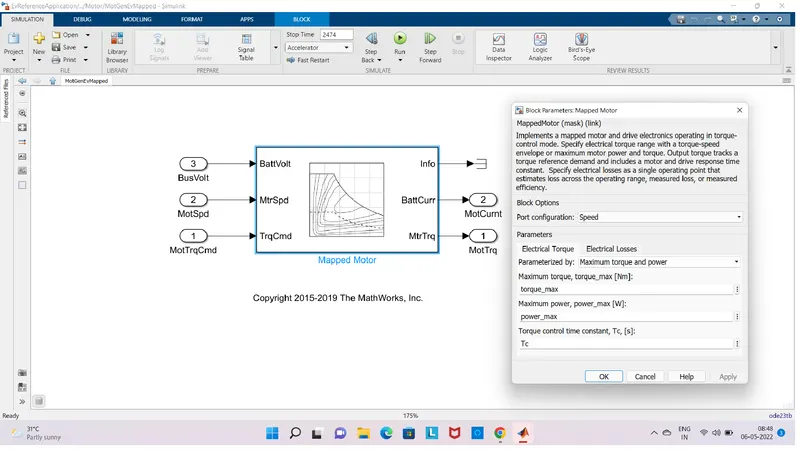
Mapped motor and drive electronics operating in torque control mode.Specify Electrical torque range with torque speed envelope or maximum motor power and torque.Output torque tracks atorque reference demand and include a motor and drive response time constant.
Dynamic model:-
It’s operating as a actual component and this internal response model.
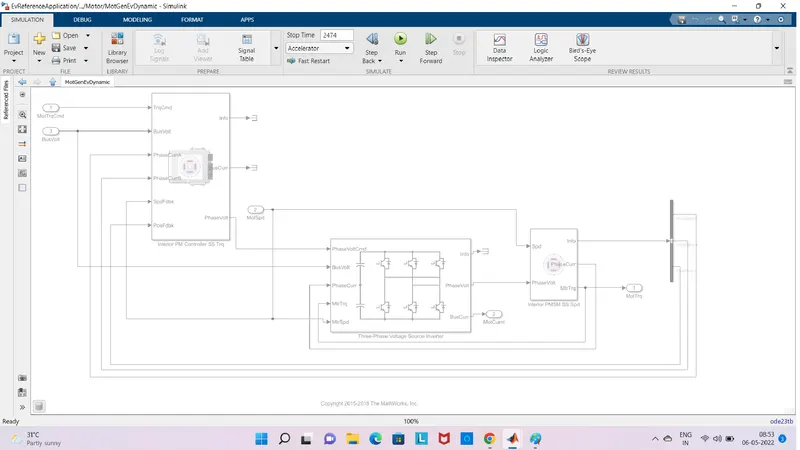
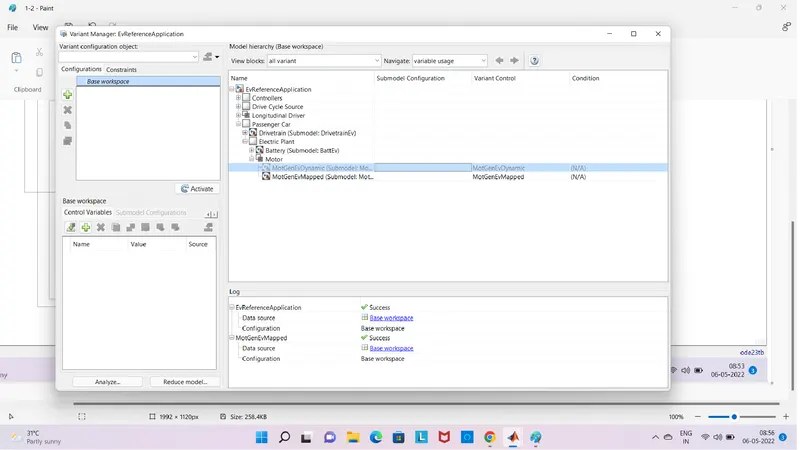
Changing the model type in EV power train Blocks:-
Use the Variant manager in the modelling tab to search on the set as Label mode active choice.
2) How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
model calculate miles per gallon
MPG, or miles per gallon, is the distance, measured in miles, that a car can travel per gallon of fuel. MPG is also the primary measurement of a car's fuel efficiency: The higher a car's MPG, the more fuel efficient it is.
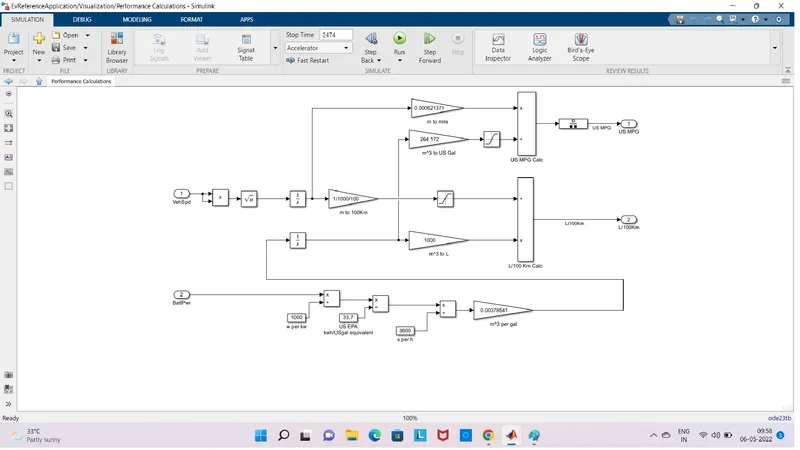
Vehicle speed data is used to calculate the distance travelled in meters then converted to miles, battery power data is used to find power in kwh is converted to gasoline-equivalent using US EPA value by dividing with 33.7
US environmental protection agency(EPA) 1 gallon of gasoline is equal to 33.7kwh.
Dividing distance travelled in miles by the no.of .gallons we can get miles per gallon
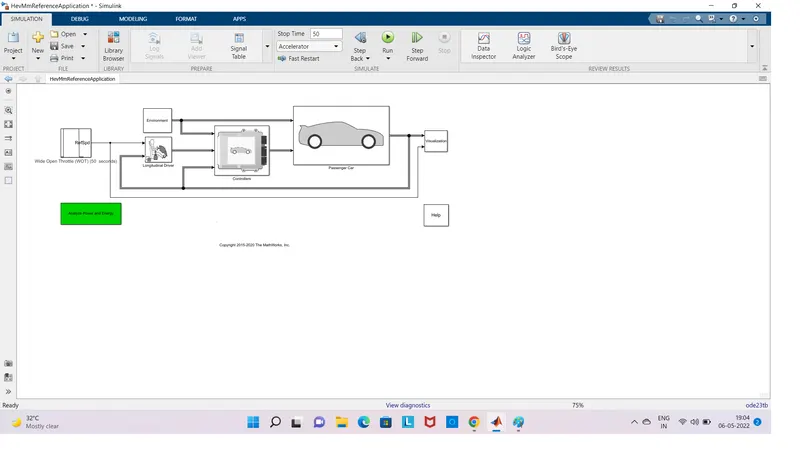
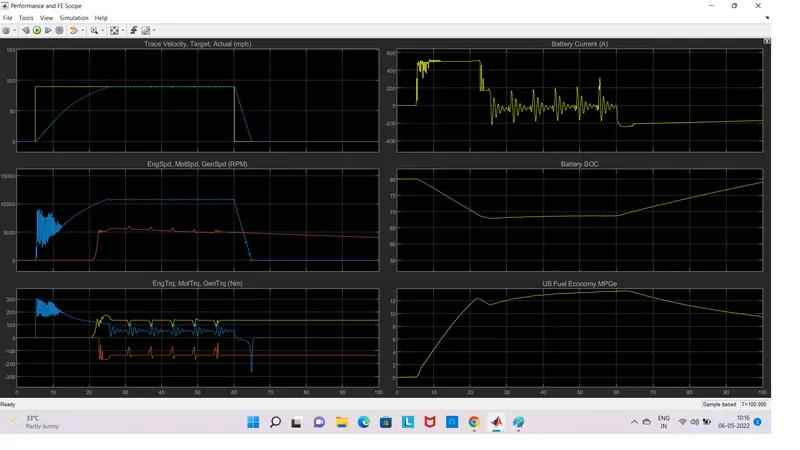
3) Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
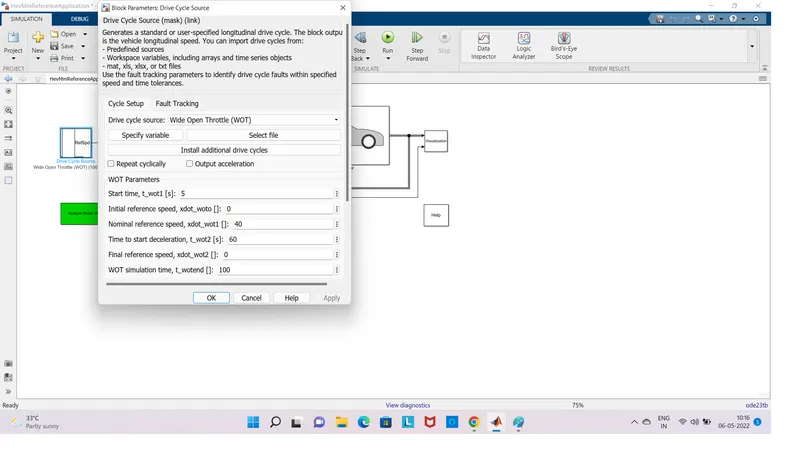
Grade-0,Wind Velocity-0m/s
Grade-5,Velocity10m/s
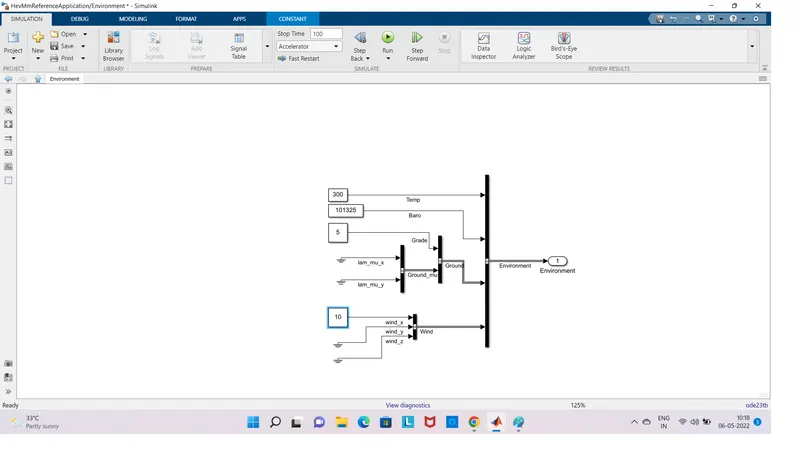
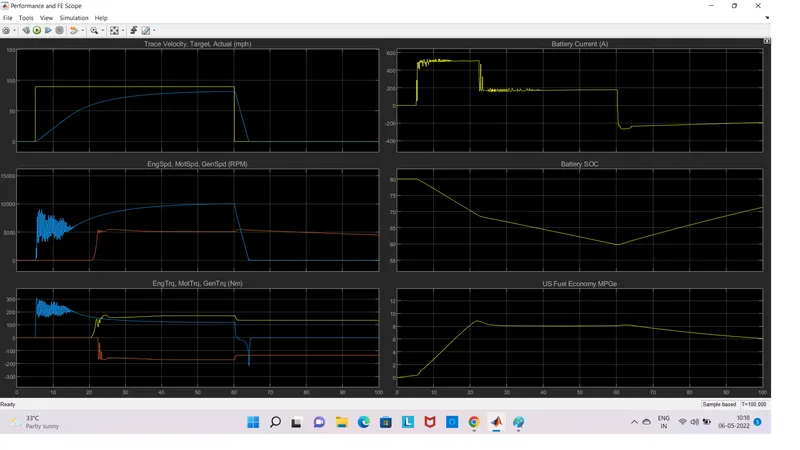
Grade-20,Velocity-35m/s
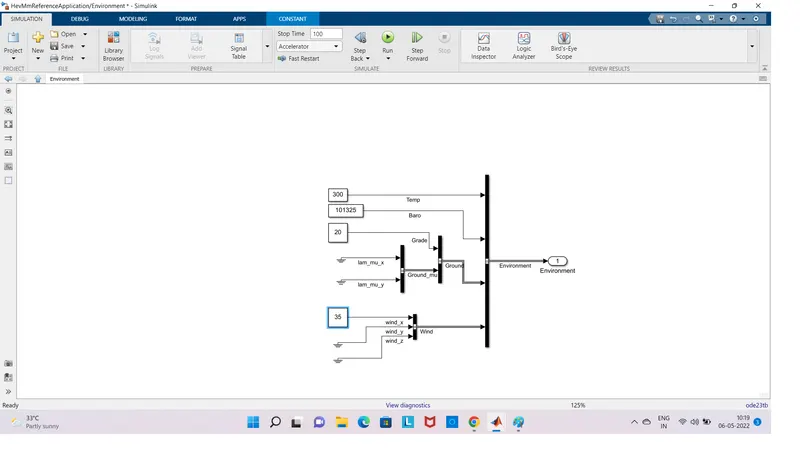
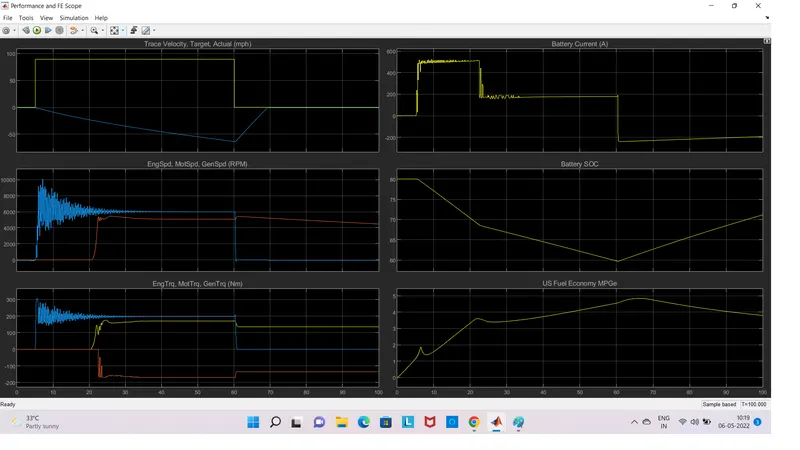
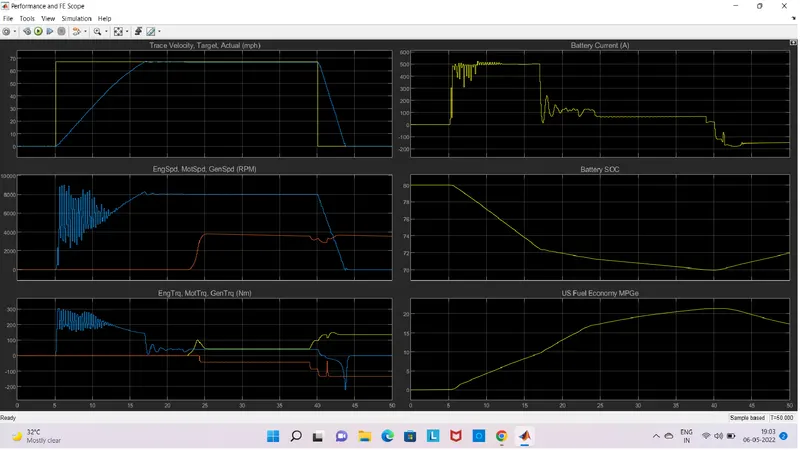
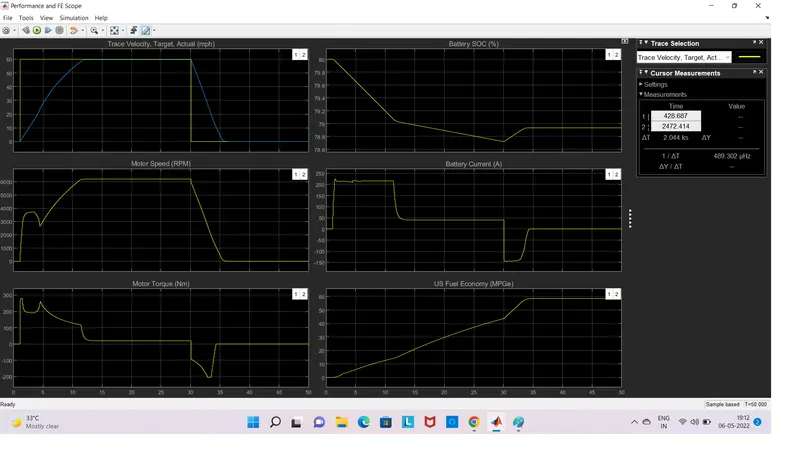
The above figure shows the results for the simulation and there are totally six plots,each plots shows a particular result and the plots are made in such a way that, there is a cursor measurement and if we change the cursor on one plot the cursor moves on the other plots too which paves way to study the result in a better way.the cursor enables us to study the behaviour of other result parameters corresponding to the acceleration of the vehicle.
4) Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
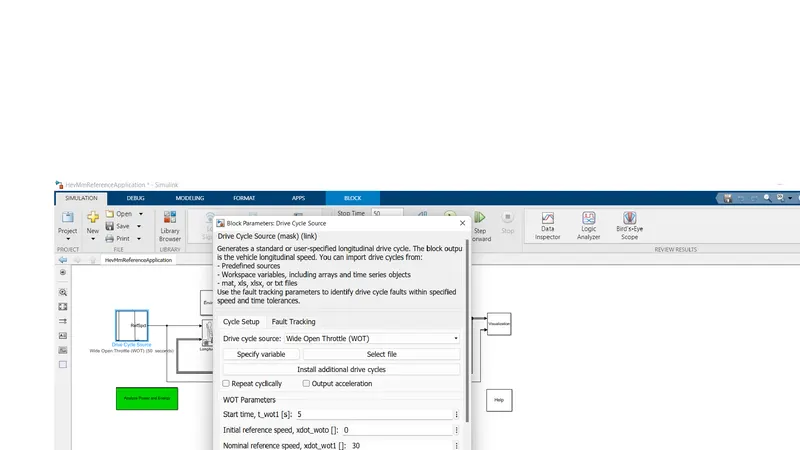
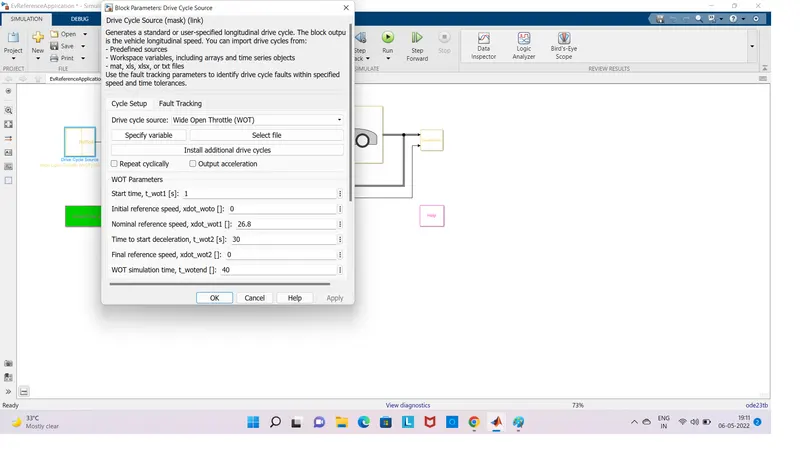
Simulation done for 50 seconds and the 40 seconds WOT drive cycle is used with wot acceleration for 0-30 seconds achieving a max speed of 26.8m/s and Decelerate for 10 seconds (30-40 Seconds)
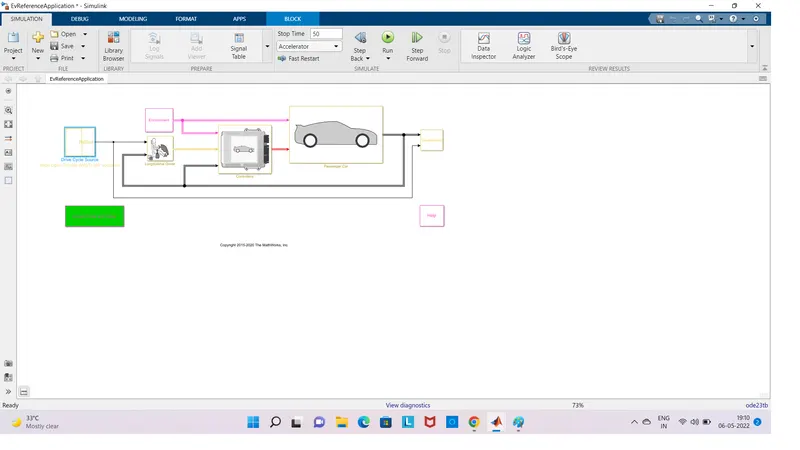
Hybrid Electric Vehicle Model