Week 3 - Solving second order ODEs
Aim: To write a program to solve a 2nd order ODE that represents the motion of a simple pendulum & to animate its motion.
Inputs from the question:
g = 9.81 m/s2, gravity
L = 1 metre, length of the pendulum
m = 1 kg, mass of the ball
B = 0.05, damping coefficient
Objective:
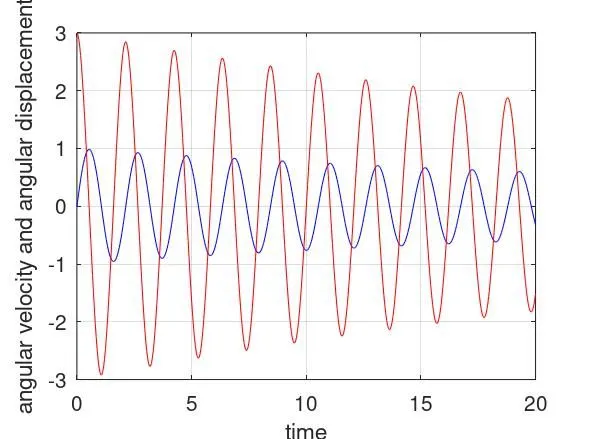
To Simulate the motion between 0-20 sec, for angular displacement=0,angular velocity=3 rad/sec at time t=0.
Function Program:
function[dtheta_dt] = ode_func(t,theta,b,g,l,m)

theta1 = theta(1)
theta2 = theta(2)
dtheta1_dt = theta2
dtheta2_dt = -(b/m)*theta2 - (g/1)*sin(theta1)
dtheta_dt = [dtheta1_dt ; dtheta2_dt]
end
Main Program:
% Program to simulate motion of a simple pendulum

clear all
close all
clc

% Inputs
b = 0.05;  % damping coefficient
g = 9.81;  % gravity in m/(s^2)
l = 1;     % length of the pendulum in metre
m = 1;     % mass of ball in kg

% Initial conditions  [Initial position & Initial velocity]
theta_0 = [0;3];

% Time
t_span = linspace(0,20,500);

% Solving ODE
[t,results] = ode45(@(t,theta) ode_func(t,theta,b,g,l,m),t_span,theta_0);

% Plots
figure(1)
plot(t,results(:,1),'color', 'b');
hold on;
plot(t,results(:,2),'color','r');
xlabel('time')
ylabel('angular velocity and angular displacement')
grid on

ct = 1;
% Pendulum Motion Animation
figure(2)
for i=1:length(t_span)
x0 = 0;
y0 = 0;
x1 = 1*sind(results(i,1));
y1 = -1*cosd(results(i,1));
plot([x0 x1], [y0 y1], [-0.5 0.5], [0 0], 'linewidth', 3);
hold on
plot(x1,y1,'marker','o','markersize',25,'markerfacecolor','r','markeredgecolor','k')
axis(gca,'equal');
grid on
pause(0.001)
hold off

% Gif
   k = 0.5;
   l_span = [1:5];
     printf('creating GIF- Progress... %d/%dn', k, length(l_span));
     img = print ('-RGBImage');
     imwrite(img,'animation.gif','Delaytime',0.005,'Compression','bzip','WriteMode','Append');

ct = ct +1;
end
Results:
Plot
Pendulum position as per question
Harmonic Oscillation of Pendulum: GIF
- Dunsten DsouzaDear @Karthikeyan. I am not able to run the last part of the code on MATLAB to generate a GIF. Please update your code if you have made any changes in ur project program and not in the report. It gives me this error. creating GIF- Progress... 5.000000e-01/5nError using writegif (line 82) ------------------------------------------------------------------------------ Unrecognized parameter name 'compression'. Error in imwrite (line 566) feval(fmt_s.write, data, map, filename, paramPairs{:}); Error in pendulum_simulation (line 55) imwrite(img,'animation.gif','Delaytime',0.005,'Compression','bzip','WriteMode','Append');;
- Karthikeyan RavishankarDear @Dunsten. I am sure I used this code only but still I'll check and get back to you. Also please note that i do not have Matlab. I use Octave which does not have an option to create video file. So I used this code given in the information tab. This has worked for since then. Probably that might be the case, Try this code in Octave, it probably might work. Nonetheless I'll check from my side also and if there is any change I'll request access and update it.