Week 3 - Solving second order ODEs
Objective:
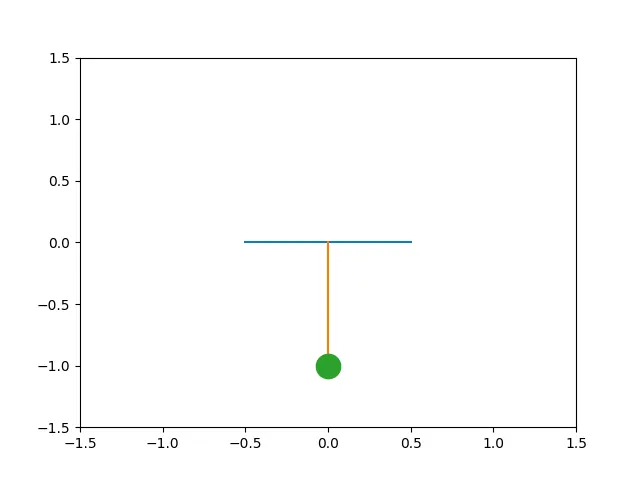
The main objective of this challenge is to write a python code for the 2nd order differential equation and plot the graph between time and ang velocity and also create a animation of pendulum.
Problem Statement:
Given 2nd order differential equation:
`[d^2theta]/dt^2 +b/m [d theta]/dt +g/l*sin theta = 0`
Converting it to multiple first order equations,
`theta = theta1`------eq1
`[d theta]/dt =[d theta1]/dt = theta2`------eq2
`[d^2theta]/dt^2 = [d^2theta1]/dt^2 =d/dt([d theta1]/dt) = d/dt(theta 2)` -------eq3
from all the above equations we simplified the equation as below;
`[d theta2]/dt +b/m theta 2 +g/l*sin theta 1 = 0`
In the above equation,
g = gravity in m/s2,
L = length of the pendulum in m,
m = mass of the ball in kg,
b=damping coefficient
L=1 metre,
m=1 kg,
b=0.05.
g=9.81 m/s2.
t=0 -20sec
using the above equation the problem need to be solved.
Solution Procedure:
- import required libraries including scipy module
- create a function using the input parameters so that it simplify the code
- give the input parameters
- use linspace command to divide the values from 0 to 20 in 300 types
- now solve the ode
- plot the results on graph and name them on x and y axis
- now use the basic math equation to find out the theta values of the pendulum
- create loop so that it calculates the values of theta in all the cases
- plot the results on graph
- use save command to save all the 300 files of different equations
- use imagemagic to attach them into one to create a smooth gif.
Results and Discussion:
using the above equations and values we get the required graph between time and angular velocity and also pendulum animation.
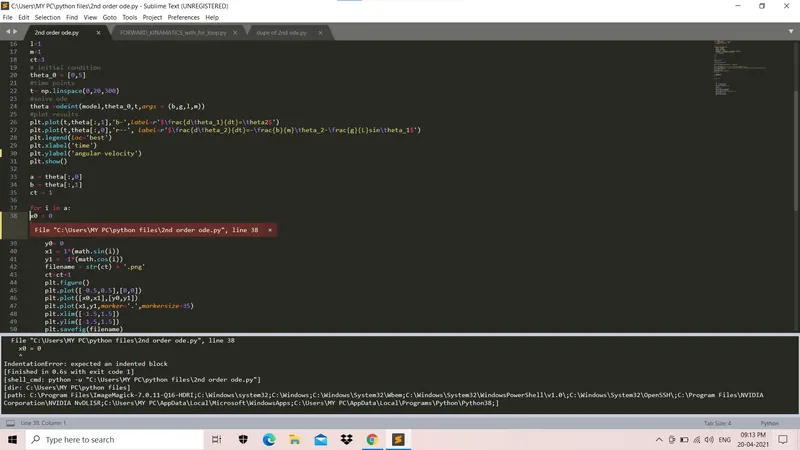
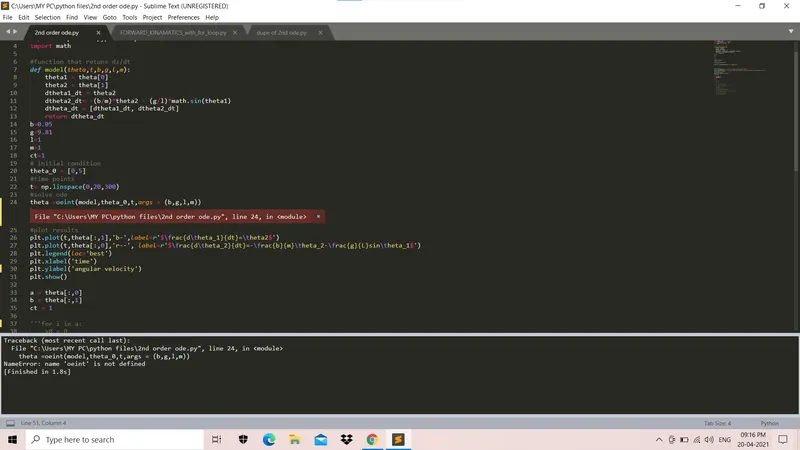
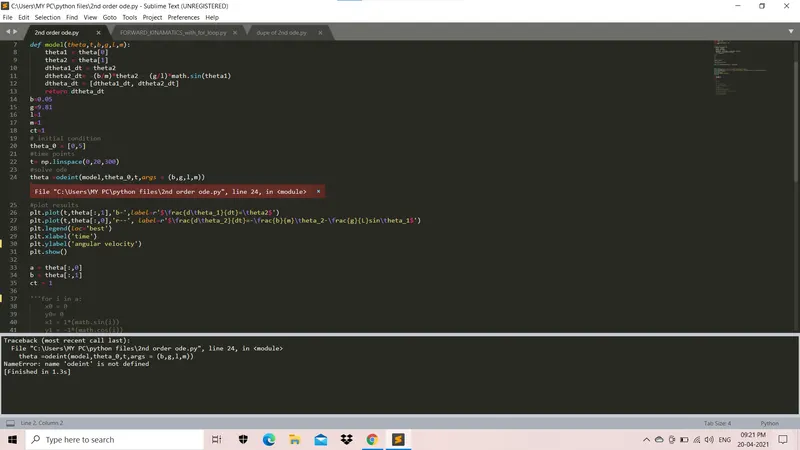
Errors faced:
- indentation error
- type error
- run time error
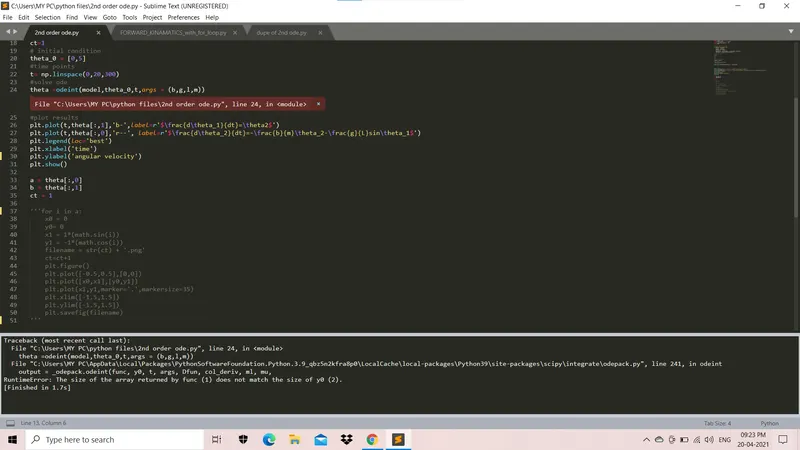
Python code:
import numpy as np
from scipy.integrate import odeint
import matplotlib.pyplot as plt
import math

#function that retuns dz/dt
def model(theta,t,b,g,l,m):
	theta1 = theta[0]
	theta2 = theta[1]
	dtheta1_dt = theta2
	dtheta2_dt= -(b/m)*theta2 - (g/l)*math.sin(theta1)
	dtheta_dt = [dtheta1_dt, dtheta2_dt]
	return dtheta_dt
b=0.05
g=9.81
l=1
m=1
ct=1
# initial condition
theta_0 = [0,5]
#time points
t= np.linspace(0,20,300)
#solve ode
theta =odeint(model,theta_0,t,args = (b,g,l,m))
#plot results
plt.plot(t,theta[:,1],'b-',label=r'$\frac{d\theta_1}{dt}=\theta2$')
plt.plot(t,theta[:,0],'r--', label=r'$\frac{d\theta_2}{dt}=-\frac{b}{m}\theta_2-\frac{g}{L}sin\theta_1$')
plt.legend(loc='best')
plt.xlabel('time')
plt.ylabel('angular velocity')
plt.show()

a = theta[:,0]
b = theta[:,1]
ct = 1

for i in a:
	x0 = 0
	y0= 0
	x1 = 1*(math.sin(i))
	y1 = -1*(math.cos(i))
	filename = str(ct) + '.png'
	ct=ct+1
	plt.figure()
	plt.plot([-0.5,0.5],[0,0])
	plt.plot([x0,x1],[y0,y1])
	plt.plot(x1,y1,marker='.',markersize=35)
	plt.xlim([-1.5,1.5])
	plt.ylim([-1.5,1.5])
	plt.savefig(filename)
Animation of the pendulum:
https://drive.google.com/file/d/1KJfigXx_W0mlM47ts0SM3ev8fdrNK-y3/view?usp=sharing