Week 3 - Solving second order ODEs
AIM:
To solve the given second order ODE function using the MATLAB/OCTAVE.
`d^2theta/(dt^2)+b/m(d theta /dt)+g/lsin theta=0`
ODE45:
ode45 is a function in matlab that solves ordinary or partial differential equations using a numerical methods.
EQUATIONS:
`theta= thetaunderset1`
`d theta/dt=underset(1)(d theta)/(dt)=thetaunderset2`
`d^2 theta/(dt^2)=underset(1)(d^2theta)=d/dt(underset(1)(d theta)/dt)=d/dtthetaunderset2`
`d^2theta/(dt^2)+b/m(d theta /dt)+g/lsin theta=0`
`d^2underset(1)theta/(dt^2)+b/m(d underset(1)theta /dt)+g/lsin underset(1)theta=0`
`dunderset2theta/(dt^2)+b/m underset2theta+g/lsin underset1theta=0`
`dunderset1theta/(dt)=underset2theta`
`dunderset2theta/(dt^2)=-b/m underset2theta-g/lsin underset1theta`
`d/dt``((underset1theta),(underset2theta))=((underset2theta),(-b/m underset2theta-g/l sin theta))`
CODIND AND EXPLANATION:
MAIN PROGRAM:
clear all
close all
clc

%input parameters
%b=damping co-efficient
%g=gravity
%l=length
%m=mass
b=0.05;
g=9.81;
l=1;
m=1;

%initial conditions we have two 1st order ODE
%the velocity(5) and displacement(0)
theta_0=[0;5];

%time span
t_span=linspace(0,20,300);

%ODE is an inbuilt solution in MATLAB
[t,results]=ode45(@(t,theta) ode_func(t,theta,b,g,l,m),t_span,theta_0);

ct=1;

figure(1)
plot(t,results(:,1))
hold on
plot(t,results(:,2))
title('simple damper pendulum')
xlabel('time')
ylabel('plot')
legend('displacement','velocity')

for i=1:length(results(:,1))
    ref=results(i);
    %co-ordinates
    x0=0;
    y0=0;
    x1=l*sin(ref)
    y1=l*(-cos(ref))

    figure(2)

    plot([x0 x1],[y0 y1],'linewidth',3);
    axis([-1.5 1.5 -1.5 0.5]);
    pause(0.01)

    %get individual frame to create a animated one
    %M is the frame
    M(ct)=getframe(gcf);
    ct=ct+1;
end
%conversion of plot into video
movie(M)
videofile=VideoWriter('ODE_MAIN.avi,uncompressed AVI')
open(videofile)
writeVideo(videofile,M)
close(videofile)
FUNCTION:
function[dtheta_dt]=ode_func(t,theta,b,g,l,m)

%solution array
theta1=theta(1);
theta2=theta(2);
%1st ODE
dtheta1_dt=theta2;
%2nd ODE
dtheta2_dt=(-b/m)*theta2-(g/l)*sin(theta1);
dtheta_dt=[dtheta1_dt;dtheta2_dt];
end
ERRORS:
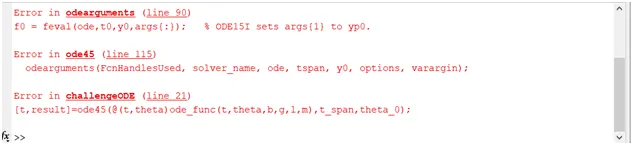
- The symbols in the equations are written wrong, the space between the ode_func and the (t,theta) is been done.
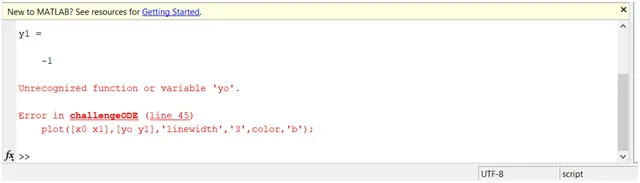
- The y0 is been written as yo in the plotting.
OUTPUT:
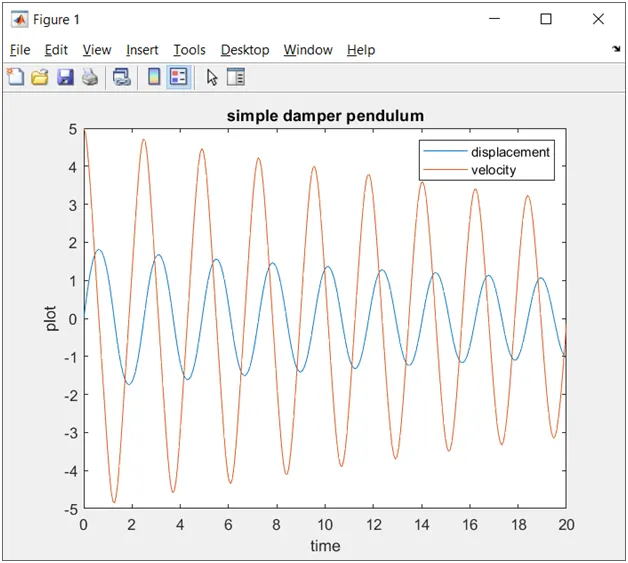
- The velocity and displacement values are been ranging to zero from their initial point of 0 and 5 respectively.
VIDEO LINK of pendulum motion:https://youtu.be/nm5HQwlcN80
RESULT:
Thus the given second order ODE is been solved, coded and explained.