Week 3 - Solving second order ODEs
Objective: Program to solve 2nd Order ODE which represents the equation of motion of a simple Pendulum with damping
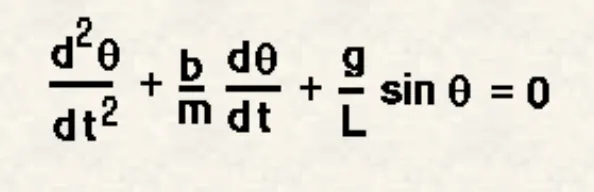
In Above Equation,
- g=Gravity in m/s2
- L=Lenght of Pendulum in m
- m=Mass of the ball in Kg
- b=Damping Coefficient
As per question,
L=1m; m=1Kg; g=9.81m/s2; b=0.05
Now, We have to Simulate the motion between 0-20 sec, for angular displacement=0,angular velocity=3 rad/sec at time t=0.
% Program to stimulate the Pendulum motion
clear all
close all
clc
b=0.05;
g=9.81;
l=1;
m=1;

%Initial Condition
theta_0 = [0;3];

%Time Points
t_span = linspace(0,10,500);

function[dtheta_dt] = ode_func(~, theta, b,g,l,m)
             theta1=theta(1);
             theta2=theta(2);
             dtheta1_dt=theta2;
             dtheta2_dt=-(b/m)*theta2-(g/l)*sin(theta1);
             dtheta_dt=[dtheta1_dt;dtheta2_dt];
         end

%SolveODE
[t, results] = ode45(@(t,theta) t_span , theta_0, ode_func(t, theta, b,g,l,m));
plot(t,results(:,1))
Hold On
plot(t,results(:,2))
ylabel('Plot')
xlabel('Time')

% for Animation
figure(1)
for i=1:length(t)
i;
clf
plot([-1.5,1.5],[0,0],'b-','LineWidth',10)
hold on
plot([0,0],[0,-1.5],'b--')
hold on
plot(x,y,'r--')
hold on
plot([0,x(i)],[0,y(i)],'k-','LineWidth',3)
plot(x(i),y(i),'r-o','markersize',30,'markerfacecolor','r')
plot(x(i),y(i),'r--')
axis([-1.5 1.5 -1.5 0])

%pause(0.1)
%if i~=length(t)
%clf
%end
movieVector(i)=getframe;
end

myWriter=VideoWriter('Pendulum');
%myWriter.FrameRate=10; % Frame per second
open(myWriter);
writeVideo(myWriter,movieVector);
close(myWriter);
% Program to stimulate the Pendulum motionclear allclose allclcb=0.05;g=9.81;l=1;m=1;%Initial Conditiontheta_0 = [0;3];%Time Pointst_span = linspace(0,10,500);function[dtheta_dt] = ode_func(~, theta, b,g,l,m) theta1=theta(1); theta2=theta(2); dtheta1_dt=theta2; dtheta2_dt=-(b/m)*theta2-(g/l)*sin(theta1); dtheta_dt=[dtheta1_dt;dtheta2_dt]; end%SolveODE[t, results] = ode45(@(t,theta) t_span , theta_0, ode_func(t, theta, b,g,l,m));plot(t,results(:,1))Hold Onplot(t,results(:,2))ylabel('Plot')xlabel('Time')% for animationfigure(3)for i=1:length(t)i;clfplot([-1.5,1.5],[0,0],'b-','LineWidth',10)hold onplot([0,0],[0,-1.5],'b--')hold onplot(x,y,'r--')hold onplot([0,x(i)],[0,y(i)],'k-','LineWidth',3)plot(x(i),y(i),'r-o','markersize',30,'markerfacecolor','r')plot(x(i),y(i),'r--')axis([-1.5 1.5 -1.5 0]) %pause(0.1)%if i~=length(t)%clf%endmovieVector(i)=getframe;endmyWriter=VideoWriter('Pendulum');%myWriter.FrameRate=10; % Frame per secondopen(myWriter);writeVideo(myWriter,movieVector);close(myWriter);ERRORS:
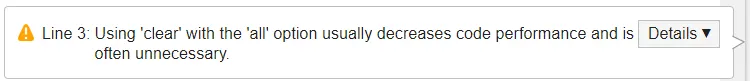
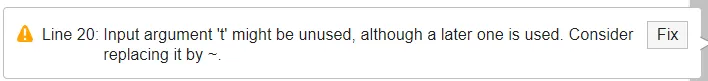
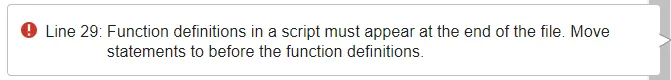
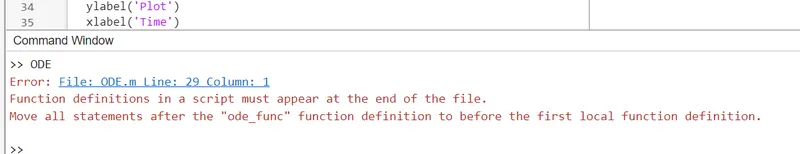
Here, Line no. 20 error has been resolved by replacing 't' with~ and line no. 29 error has be overcome by moving the statements to before the function definations.
Below is the screenshot of showing error in command window