Week 3 - Solving second order ODEs
Aim:
To solve the second order ODEs function by using Matlab
objective:
- To write matlab program by using ode45 sover for second order differential equation
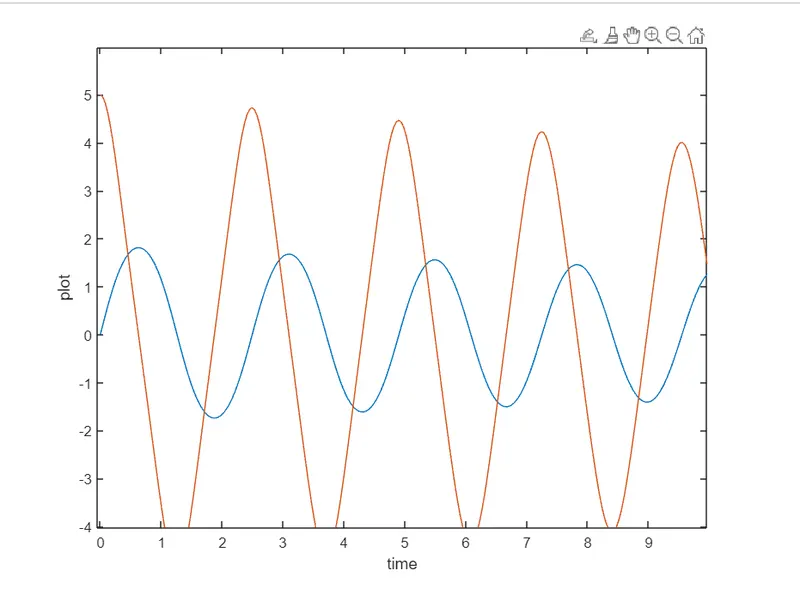
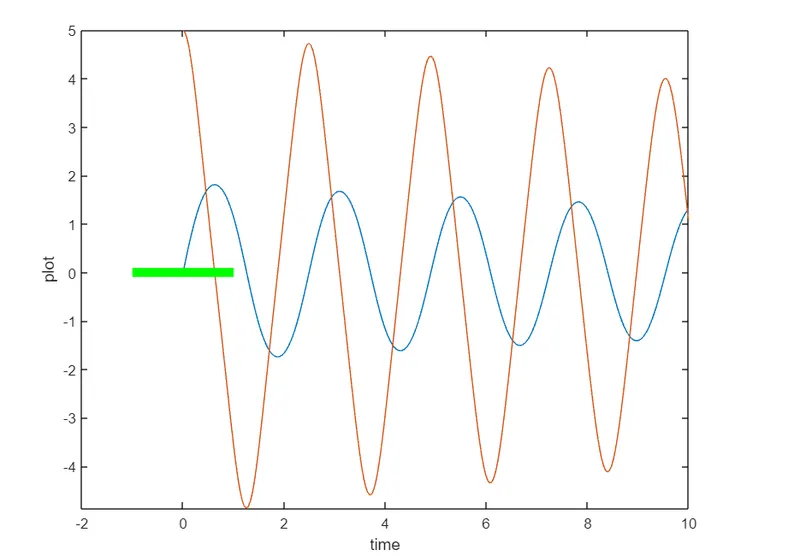
- Plot the graph
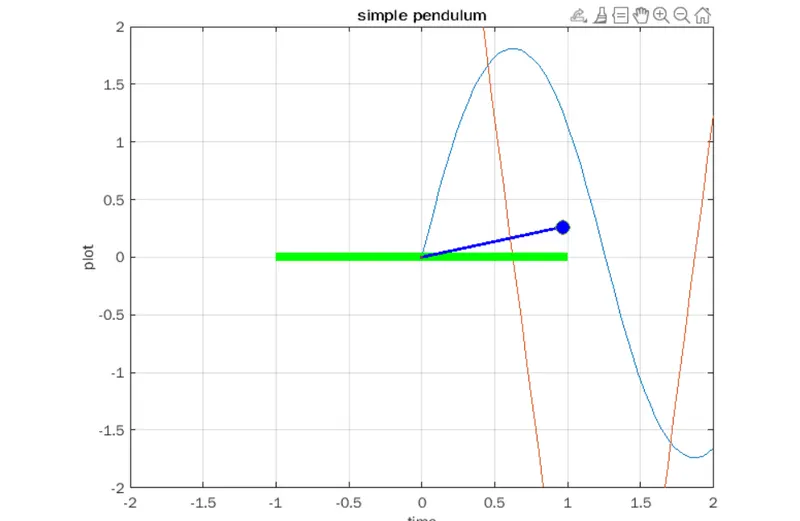
- To create animation for simple pendulum
Introduction
Second-Order Differential Equation A differential equation is an equation of a function and one or more derivatives which may be of first degree or more. Differential Equations are of the form:
d2y/dx2 + p dy/dx + qy = 0.
for example
dy/dx + y2 = 5x First Order Differential Equation.
d2y/dx2 + xy = sin(x) Second Order Differential Equation.
d3y/dx3 + x dy/dx + y = ex Third Order Differential Equation.
Differential Equations might be of different orders i.e. th
Second-Order Differential Equation Examples
In several real-world situations, First Order Differential Equation does not suffice properly and there is a need to implement Second Order Differential Equation. For a degree greater than one, there’s always a specific trick that is particular to the type of situation you are handling. For you to know how to handle the 2nd order Differential Equation, make sure you go through the concept completely as it will show you some examples and the technique involved in solving 2nd Order Differential Equation.
Difference Between 1st and 2nd Order Differential Equations
In the unknown y(x) Equation (1) is 1st order seeing that the highest derivative that seems in it is a 1st order derivative. Similarly, equation (2) is a 2nd order because also y appears. They are both linear, since y, y and y are not squared or cubed etc and their product is not appearing.
e highest degree of the derivative.
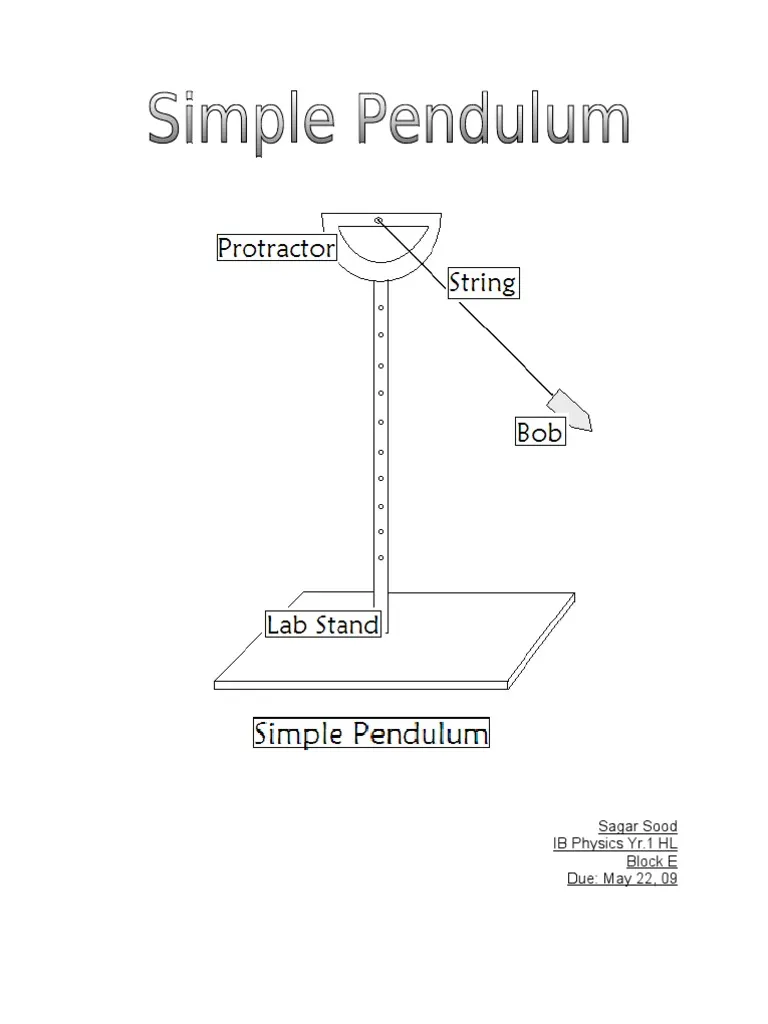
Simple Pendulum:
- SHM. SHM or simple harmonic motion is the type of periodic motion in which the magnitude of restoring force on the body...
- Effect of Gravity. The time period of simple pendulum is inversely proportional do the square root of acceleration due...
- Physical Pendulum. For simple pendulum we consider the mass of the string to be negligible as compared to the Bob
- Summary. A simple pendulum is a mechanical system which consist of a light inextensible string and small bob
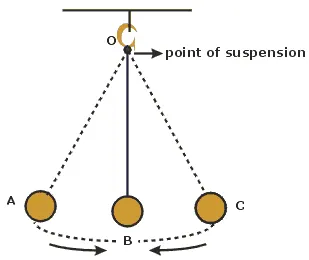
Equation of simple pendulum;
g = gravity in m/s2,
L = length of the pendulum in m,
m = mass of the ball in kg,
b=damping coefficient
Programe for pendulum motion