Week 2- 2R Robotic Arm Challenge
#Forward kinematics of a 2R Robatic Arm:
Aim
To simulate the forward kinematics of a 2R Robotic Arm by using Matlab.
Introduction.
This following Matlab program is used to solve the forward kinematics of the 2R robotic arm manipulator.
THEORY
Kinematics is the analysis of motion without considering the forces. Here we need only geometric properties such as length and degree of freedom of the manipulator bodies. Forward kinematics refers to use of kinematics equation of a robot to compute the position of end effector from specified values for the joint parameters.
It is a type of mechanical arm usually it’s perform a similar function like a human arm.in the 2r robotics arm the two links and manipulator were connected by the joints and the joints allow to perform either rotational motion or linear displacement.the links of the manipulator can be consider to form a kinematic chain
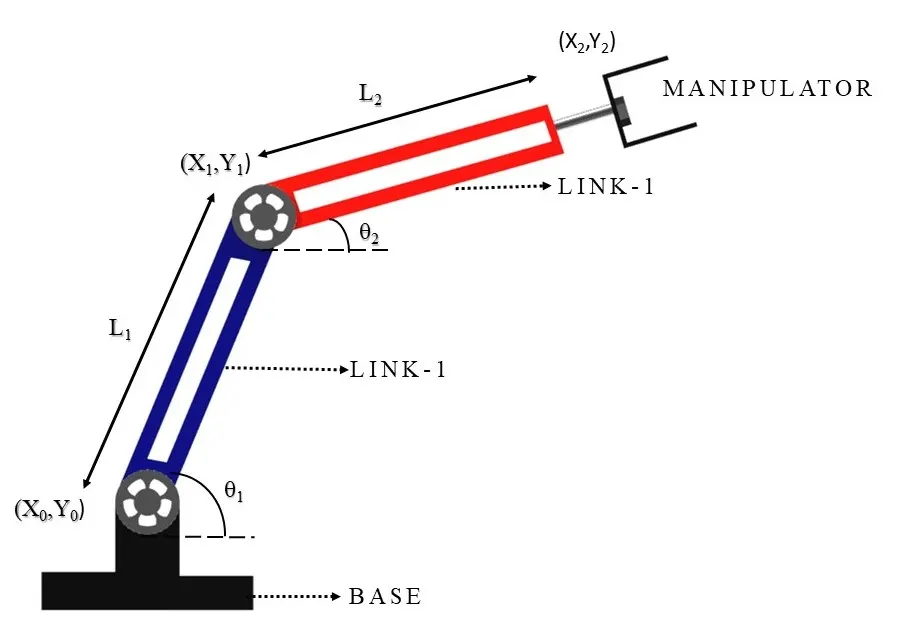
Forward Kinematic equation,
x1=l1*cosd(theta1)
y1=l1*sind(theta1)
x2=x1+l1*cosd(theta1)
y2=y1+l1*cosd(theta1)
commands used
- linspace
- for loop
- linewidth
- pause
- videofile
- plot
Program.
%forward kinematics 0f 2R robatics
clear all
close all
clc
%inputs
l1=1;
l2=0.5;
theta1 =(45);
theta2 =(30);
%coordinates
x0=0;
y0=0;
x1=l1*cosd(theta1);
y1=l1*sind(theta1);
x2=x1+l2*cosd(theta2);
y2=y1+l2*sind(theta2);
% ploting
line([x0 x1],[y0 y1],'linewidth',3,'color','g')
line([x1 x2],[y1 y2],'linewidth',3,'color','b')
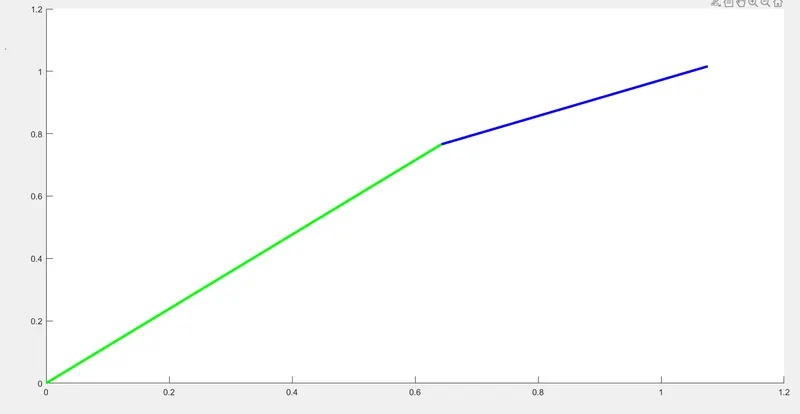
%forward kinematics 0f 2R robatics
clear all
close all
clc
%inputs
l1=1;
l2=0.5;
theta1 =linspace(0,90,10);
theta2 =linspace(0,90,10);
%coordinates
x0=0;
y0=0;
ct=1
for i = 1:length(theta1)
THETA1 = theta1(i);
for j= 1:length(theta2)
THETA2 = theta1(j);
x1=l1*cosd(THETA1);
y1=l1*sind(THETA1);
x2=x1+l2*cosd(THETA2);
y2=y1+l2*sind(THETA2);
% ploting
plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)
axis([-0.5 1.5 0 1.5])
pause (0.05)
M(ct) = getframe(gcf)
ct=ct+1
end
end
movie(M)
videofile= VideoWriter('forward_kinematics.avi','Uncompressed AVI');
open(videofile)
writeVideo(videofile,M)
close(videofile)
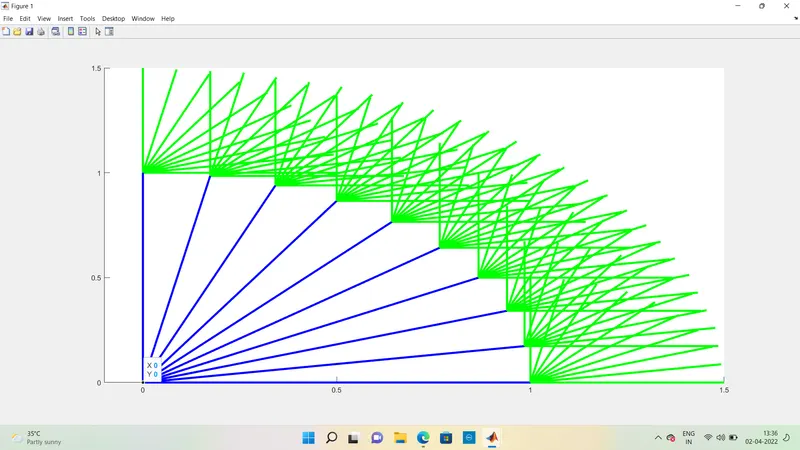
"C:\Users\dhamd\Documents\MATLAB\forward_kinematics.avi"