Week 2- 2R Robotic Arm Challenge
% Simulating video of Forward Kinematics of a Robotic Arm
close all
clear all
clc
% Inputs
l1 = 1; % length of first arm
l2 = 0.5; % lenght of second arm
theta1 = linspace(0,90,10); % angle of initial arm
theta2 = linspace(0,90,10); % angle of final arm
ct = 1;
for i = 1:length(theta1)
THETA1 = theta1(i);
for j = 1:length(theta2)
THETA2 = theta2(j);
x0 = 0;
y0 = 0;
x1 = l1*cosd(THETA1);
y1 = l1*sind(THETA1);
x2 = x1 + l2*cosd(THETA2);
y2 = y1 + l2*sind(THETA2);
% Plotting
plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'LineWidth',3)
axis([-0.1 1.5 0 1.5])
pause(0.03)
grid on
M(ct) = getframe(gcf);
ct = ct+1;
end
end
movie(M)
videofile = VideoWriter('forward_kinematics.avi',"Uncompressed AVI");
open(videofile)
writeVideo(videofile,M)
close(videofile)
# ERRORS FACED WHILE SIMULATING THE CHALLENGE
1) Error faced through spelling mistakes
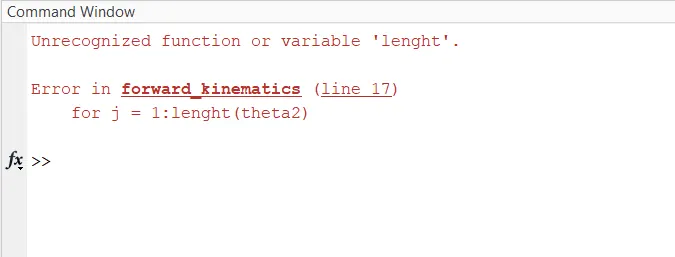
Solved by correction os spelling
2) Errors faced while not putting end command
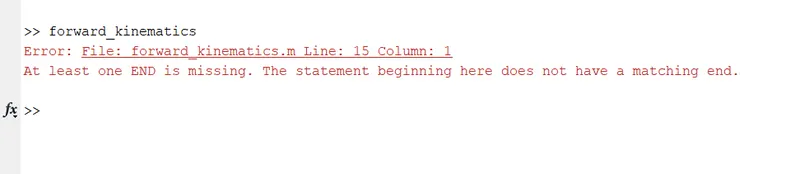
Solved by putting the end command for the for loop function.
3) Errors faced while converting the code to video
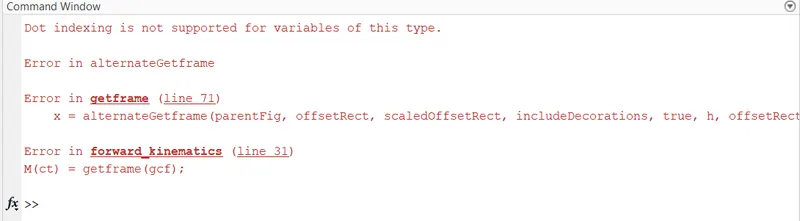
Solved by correcting the spelling and bracket mistake
#YOUTUBE VIDEO LINK :