Week 2- 2R Robotic Arm Challenge
AIM :
To write a program in matlab to simulate the forward kinematic of a 2R robotic arm
OBJECTIVE :
Animating and creating a movie from the plots obtained from the program .
THEORY:
A manipulator end effector movement determines the workspace where the roboic arm can be applicable our motive is t animate the movement of robotic arm with the subseqent relative motion between the two comprising links
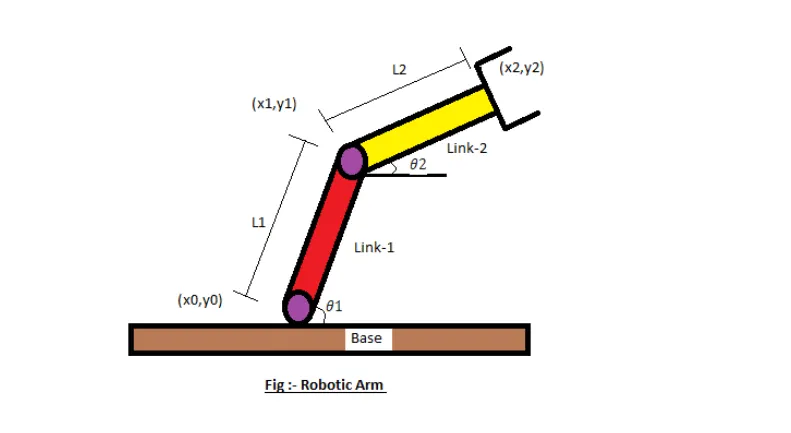
INTRODUCTION:
* Kinematics is the relationships between the positions,velocities and accelerations of the link of a manipulator
* The forward kinematics is when the kinematical data are known for the joint coordinator the variables of the end-effector in a given cartesin space are to be computed
* Robotic arms are machines that are programmed to exeute a specific task or job quickly ,efficiently and extremely accuratly
* A robotic joint provides relative motion between two links of the robot each point or axis provides a certain degee-ofpfreedom(DOF)
INPUTS:
(x0,y0) = starting point of link 1
(x1,y1) = end point of link1 and starting point of link 2
(x2,y2) = end point of link 2
l1 = length of link attached to the base
l2 = length of link between the first and the end effection
theta 1 = angle made by link 1 with x -axis
theta 2 = amgle made by link 2 with x-axis
CODE EXPLANATION:
* Programming language used in MATLAB
* starting program by using commands
* clear all-remove data from the workspace frecing up system memory
* close all -deletes the current figure or specific figure
* clc - clears all input and output from the command windows display giving you clean screen
* providing the inputs variables like
* predefining the length /values of robotic arms
* providing the values for theta 1 and theta 2 using linspace command for theta 0 to 90 degree for l1 values
* providing the Cr(compression ratio) value specfic digit
OUTPUT :
The simulation of the forward kinematics of a 2R -robotic arm amnipulator is done and we observed that each 10 degree of movement of the link 1 there is 90 degree of the link 2
FOR LOOP : for loop is used here for the iteration of the values from 0 to 90 degree I is used as outer loop and J is inner loop
COSD and SIND are used to coverd the radians into degrees beacuse MATLAB by defult takes in radians
PAUSE : we have paused the code so that process can be visulised more clearly
Ct : ct is used for saving the frames in order to create a movies frames
GETFRAME: similarly getframe is used to caputre the frame and then by fast movement of those frames it can be convert into a movie
Movie: movie command is used to create the movie frames caputre
video writter: It is create a video file of the movie created and save in pc hard disc
plot: the plot command is used to plot the graphs of the coordinates provided
Axis: the axis command is used to create the axis upon which we are going to the plot the coordinates
Linspace: the linspace command is useful creating an arrays of values specified by the user
PROGRAMMING:
CONCLUSION:
* A practical scenario regarding the functioning of the robotic arm and its workspace has been expernced by simulating the forward kinematics with a program in MATLAB