Week 2- 2R Robotic Arm Challenge
%Program to simulate the forward kinematics of 2R robotic arm.

clear all
close all
clc

%Input

l1=1;
l2=0.5;

theta1=linspace(0,90,10);
theta2=linspace(0,90,10);
ct=1;
for i=1:length(theta1)
    THETA1=theta1(i);
    for j=1:length(theta2)
        THETA2=theta2(j);
        x0=0;
y0=0;

x1=l1*cosd(THETA1);
y1=l1*sind(THETA1);

x2=x1+l2*cosd(THETA2);
y2=y1+l2*sind(THETA2);

%Plotting

plot([x0,x1],[y0,y1],[x1,x2],[y1,y2]);
axis([-0.1 1.2 0 1]);
pause(0.3)
M(ct) = getframe(gcf);
ct=ct+1;

end


end
movie(M)
videofile=VideoWriter('forward_kinematics.avi','Uncompressed AVI');
open(videofile)
writeVideo(videofile,M)
close(videofile)
Explanation of Progam.
- First we define the length of both the links.
- After that we defined coordinate.
- defined the values of theta1 and theta2
- Used linspace commad to generate lineraly spaced vectors.
- using for loop for values of variables.
- Plotting all coordinates.
- movie command is used to combine the figures saved in M file to make movie and saving in .avi format.
Animation Video of forward kinematics link
Errors faced while programming:
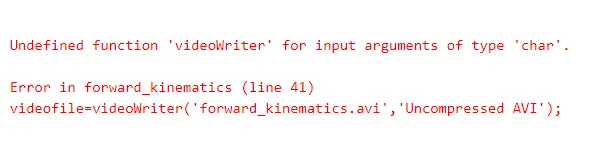
Step taken to overcome this error:
I have just puten the V insted of v in Videowriter.
Puten the V insted of v in writeVideo.