Week 2- 2R Robotic Arm Challenge
% forward kinematics of 2r robot
clear all
close all
clc

% inputs
l1=1;
l2=0.5;
theta1= linspace(0,90,10);
theta2 = linspace(0,90,10);
ct=1
for i= 1:length(theta1)
    THETA1 = theta1(i)
    for j= 1:length(theta2)
        THETA2 = theta2(j)
        %coordinates
x0= 0;
y0 = 0;

x1 = l1*cosd(THETA1);
y1 = l1*sind(THETA1);

x2= x1+l2*cosd(THETA2);
y2= y1+l2*sind(THETA2);

%plotting

plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)
axis([-0.1 1.5 0 1.5])
pause(0.03)
M(ct) = getframe(gcf);
ct=ct+1;

    end
end

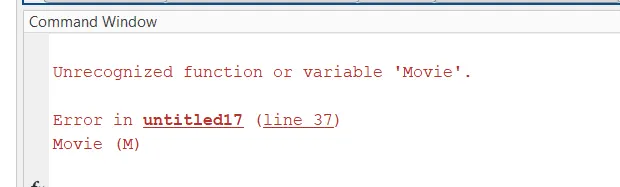
Movie (M)

videofile = VideoWriter("2R robotic arm challenge.avi",'Uncompressed AVI');
open(videofile)
writevideo(videofile,M)
close(videofile)
CODE EXPLANATION:
1.forward kinematics of 2r robot
2.started with inputs for robot and given linspace for angles.
3.using for loop giving the THETA1 and THETA2 values.
4.x1,y1 is given in COSD AND SIND because it should be in degrees.
5.plotting with first line [x0,x1]nad[y0,y1] and second line [x1 x2],[y1 y2].
6. i tried to get outputbut here is some error1.
7. now i run the program and i got clumsy shape.
8.so i choose to start with counter ct.
9. now using pause command i can see the required animation.
10. for better animation given axis coordinates and frames and contour by increasing step by step.
11. now end the for loop.
12.i want to give movie.so created videofile and opened and write and then closed.
13. now the animation came.
Errors:
1.in line 13 i forgot to give theta1 and line 37 solved.