Week 2- 2R Robotic Arm Challenge
%Matlab program for Forward Kinematics of a 2R Robotic arm
clear all
close all
clc
%Inputs
l1 = 1; %Length of link1
l2 = 0.5; %Length of link2
theta1 = linspace(0,90,40); % Angle made by link1 with respect to x-axis
theta2 = linspace(0,90,40); % Angle made by link2 with respect to x-axis
ct = 1; % counter variable counts the every event in for loop
%For each angle of THETA1 we need to obtain different angles of THETA2
for i = 1:length(theta1)
THETA1 = theta1(i);
for j = 1:length(theta2)
THETA2 = theta2(j);
%co-ordinates
x= 0;
y = 0;
x1 = l1*cosd(THETA1);
y1 = l1*sind(THETA1);
x2 = x1 + l2*cosd(THETA2);
y2 = y1 + l2*sind(THETA2);
%plotting- plot command creates 2D line plot.
plot([x x1],[y y1],[x1 x2],[y1 y2],'linewidth', 3)
axis([-0.1 1.5 0 1.5]);
M(ct) = getframe(gcf); % Assigning current figure window in M.
ct = ct+1;
end
end
movie(M) %movie command to generate movie.
videofile = VideoWriter('Froward_kinematics.avi','Uncompressed AVI');
open(videofile)
writeVideo(videofile,M)
close(Videofile)
ERRORS faced while programming
1. Used 'space' instead of ','(coma) in linspace command. 
2. Used 'Movie' command instead of 'movie' command, as matlab is case sensitive it shown an error.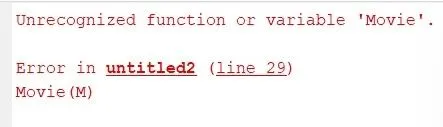
Animation video link of 2R robotic arm