Week 2- 2R Robotic Arm Challenge
CHALLENGE REPORT:
AIM:
To Write a program in Matlab to simulate the forward kinematics of a 2R Robotic Arm
OBJECTIVE:
*To calculate the position of link1,
*To calculate the position of link2,
*To calculate the position of link1 & link2 for multiple degree of theta.
* To simulate the forward kinematics of a 2R Robotic Arm.
PROGRAMES IN MATLAB:
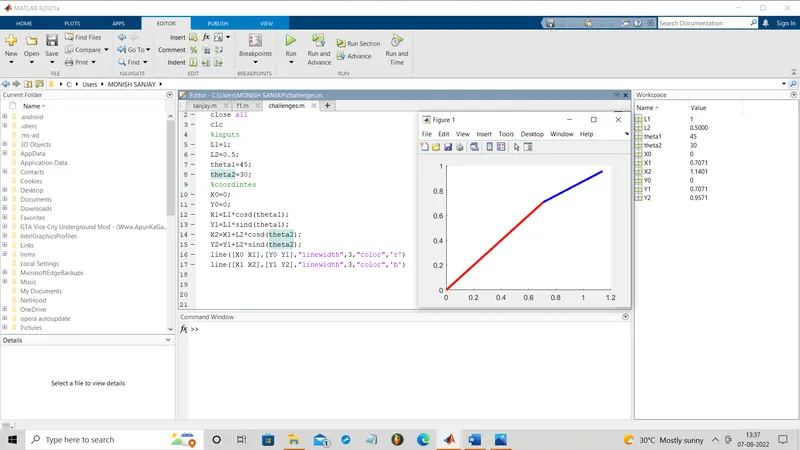
i)To calculate the position of link1 and link2 for theta1=45 & theta2=30:
clear all
close all
clc
%inputs
L1=1;
L2=0.5;
theta1=45;
theta2=30;
%coordintes
X0=0;
Y0=0;
X1=L1*cosd(theta1);
Y1=L1*sind(theta1);
X2=X1+L2*cosd(theta2);
Y2=Y1+L2*sind(theta2);
line([X0 X1],[Y0 Y1],"linewidth",3,"color",'r')
line([X1 X2],[Y1 Y2],"linewidth",3,"color",'b')
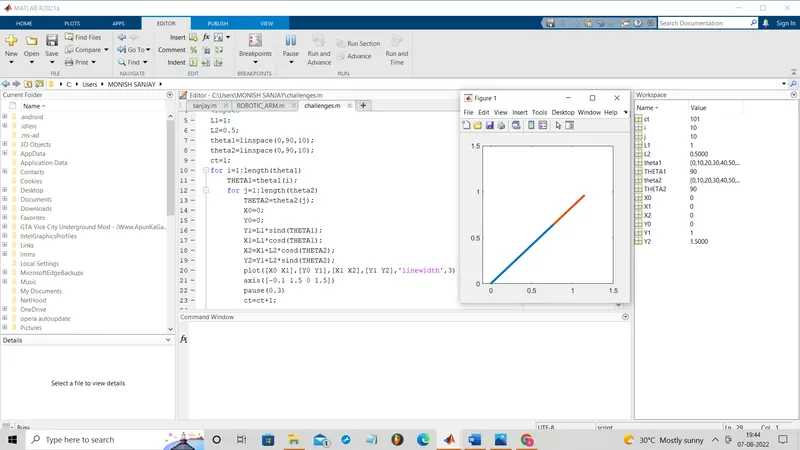
ii) To calculate the position of link1 & link2 for multiple degree of theta.
clear all
close all
clc
%inputs
L1=1;
L2=0.5;
theta1=linspace(0,90,10);
theta2=linspace(0,90,10);
ct=1;
for i=1:length(theta1)
THETA1=theta1(i);
for j=1:length(theta2)
THETA2=theta2(j);
X0=0;
Y0=0;
Y1=L1*sind(THETA1);
X1=L1*cosd(THETA1);
X2=X1+L2*cosd(THETA2);
Y2=Y1+L2*sind(THETA2);
plot([X0 X1],[Y0 Y1],[X1 X2],[Y1 Y2],'linewidth',3)
axis([-0.1 1.5 0 1.5])
pause(0.3)
ct=ct+1;
end
end
iii)To simulate the forward kinematics of a 2R Robotic Arm
clear all
close all
clc
%inputs
L1=1;
L2=0.5;
theta1=linspace(0,90,10);
theta2=linspace(0,90,10);
ct=1;
for i=1:length(theta1)
THETA1=theta1(i);
for j=1:length(theta2)
THETA2=theta2(j);
X0=0;
Y0=0;
Y1=L1*sind(THETA1);
X1=L1*cosd(THETA1);
X2=X1+L2*cosd(THETA2);
Y2=Y1+L2*sind(THETA2);
plot([X0 X1],[Y0 Y1],[X1 X2],[Y1 Y2],'linewidth',3)
axis([-0.1 1.5 0 1.5])
pause(0.3)
M(ct)=getframe(gcf);
ct=ct+1;
end
end
movie(M)
videofile=VideoWriter('forwardkinamatics.avi','uncompressed AVI')
open(videofile)
writeVideo(videofile,M)
close(videofile)
CODE EXPLANATION:
i)
*First provide the inputs values and coordinates
*Using the line command make two lines for 3 coordinates((X0,Y0),(X1,Y1),(X2,Y2)).
ii)
* first provide the inputs values (using linspace command for theta1 & theta2),
*putting the length of theta1 & theta2 in for loop, as follows the coordinates((X0,Y0),(X1,Y1),(X2,Y2)) and using the plot command plot the coordinates wth the given axis and end up with end.
iii)
* first provide the inputs values (using linspace command for theta1 & theta2),
*putting the length of theta1 & theta2 in for loop, as follows the coordinates((X0,Y0),(X1,Y1),(X2,Y2)) and using the plot command plot the coordinates wth the given axis and end up with end.
* using getframe we are capturing each frame,videofile helps to name the file and formate of video.
CONCULSION:
i)
ii)
iii)
YOUTUBE LINKS:https://youtu.be/r2B3-zfFAHY
drive link:https://drive.google.com/file/d/1futzZ6XDFwP8MCrQZP7xm7255r_cyUp2/view?usp=sharing