week-11 Joint creation and Demonstration
JOINT CREATION AND DEMONSTRATION
OBJECTIVE :
To create Cylindrical,Translational,Revolute & Spherical joints between two Rigid and two deformable bodies using Ls-Dyna solver.
THEORY :
A distinguishing feature of multibody systems is the presence of joints that impose constraints on the relative motion of thevarious bodies of the system. Most joints used in practical applications can be modelled in terms of the so-called lower pairs likespherical, revolute, cylindrical, and translational joints
Spherical Joint:
A spherical joint is used for allowing free rotation in two planes at the same time while preventing translation inany direction, including rotating in those planes.
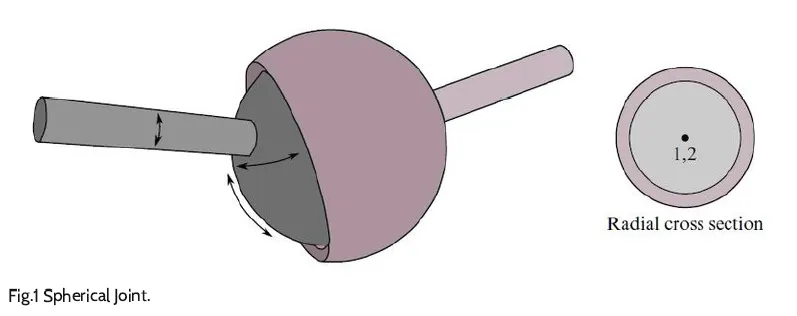
The relative motion of the rigid bodies is constrained so that nodes which are initially coincident remain coincident. In the abovefigure the socket’s node is not interior to the socket—LS-DYNA does not require that a rigid body’s nodes be interior to the body.
Revolute Joint:
A revolute joint is a one degree of freedom kinematic pair used frequently in mechanisms and machines. Thejoint constrains the motion of two bodies to pure rotation along a common axis.
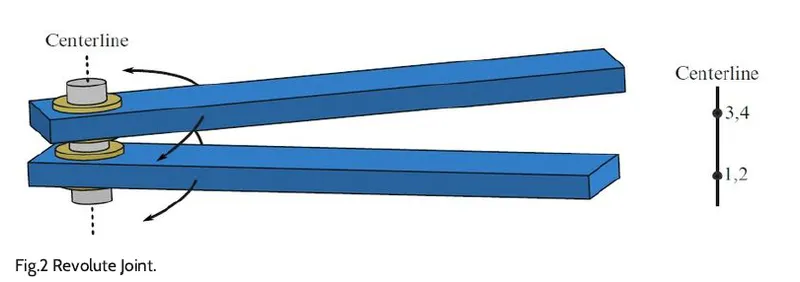
As shown in fig.2, Nodes 1 and 2 are coincident; nodes 3 and 4 are coincident. Nodes 1 and 3 belong to rigid body A; nodes 2 and4 belong to rigid body B. The relative motion of the two rigid bodies is restricted to rotations about the axis formed by the twopairs of coincident nodes. This axis is labelled the “centerline”.
Cylindrical Joint:
A cylindrical joint is a two degrees of freedom kinematic pair used in mechanisms. It provides single axis slidingfunction as well as a single axis rotation, providing a way for two rigid bodies to translate and rotate freely.
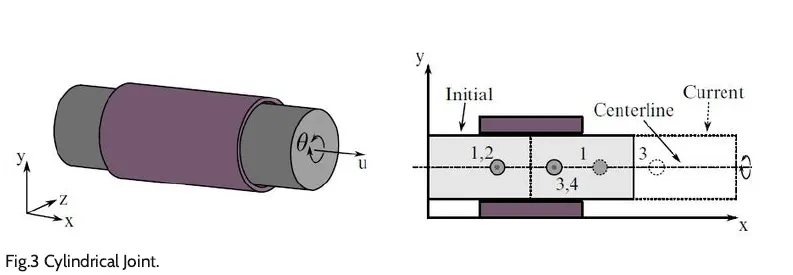
This joint is derived from the rotational joint by relaxing the constraints along the centerline. This joint admits relative rotationand translation along the centerline as shown in fig.3.
Translational Joint:
A Translational joint provides a linear sliding movement between two bodies.
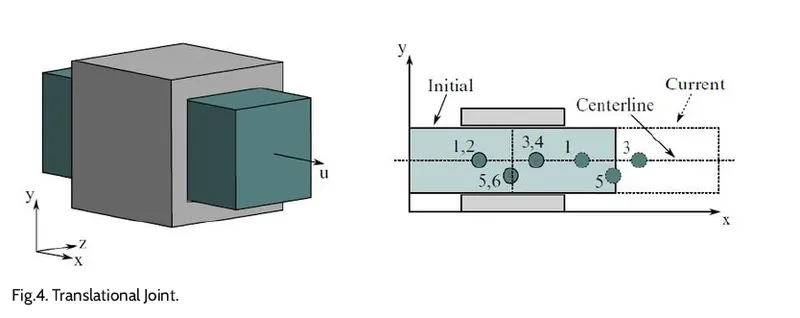
This is a cylindrical joint with a third pair of off-centerline nodes which restrict rotation. Aside from translation along thecenterline, the two rigid bodies are stuck together.
PROCEDURE :
- Here we need to create four joints, i.e., Cylindrical,Translational,Revolute & Spherical joints
- The joints which are to be created is between two rigid bodies and two deformable bodies separately which are considered as two cases here
:
Since we are studying only about the characteristics of the joints, there are some cards which is common in all the cases which are as Follows
1. SECTION :
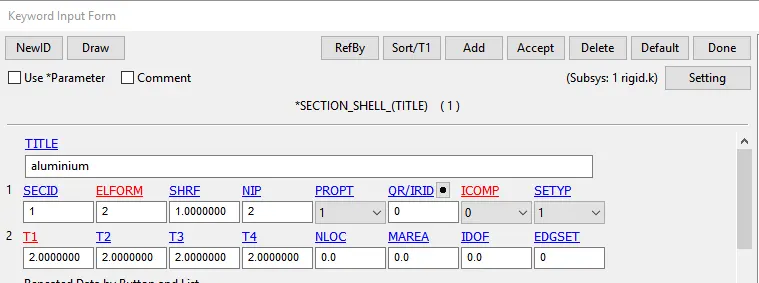
the section shell card with Element formulation of 2 and thickness of 2mm is Followed through out to all the cases for both rigids and deformables.
2. MATERIAL CARD :
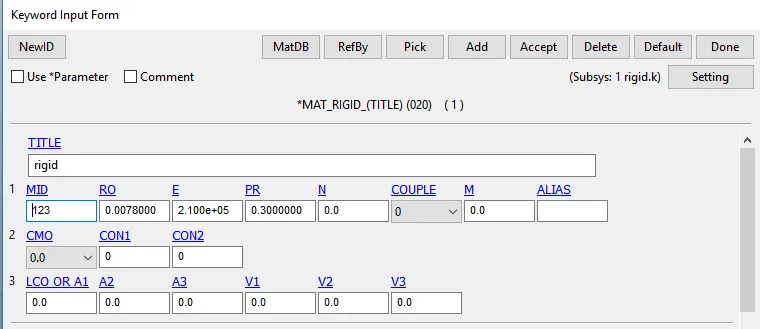
the material card *MAT_RIGID is used for all the rigid cases in all four joints with the properties of steel given.
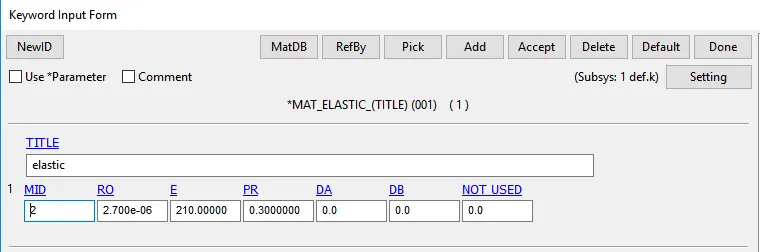
the material card *MAT_ELASTIC is used for all the deformable cases in all four joints with the properties of aluminium is given
3. CONTROL CARD :
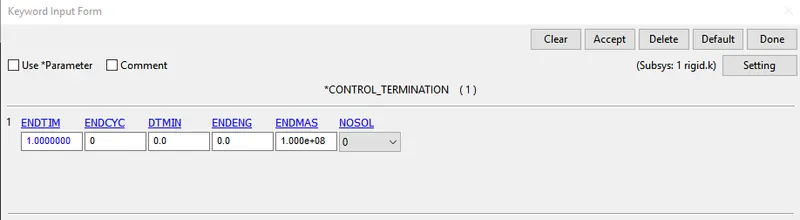
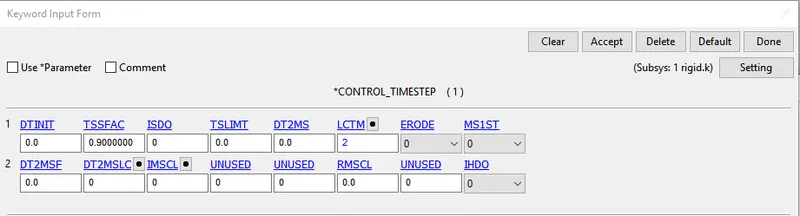
The control cards such as *Control_Termination and *Control_Timestep is common through out all the cases in all the four joints.
REVOLUTE JOINT
Case(i): Rigids
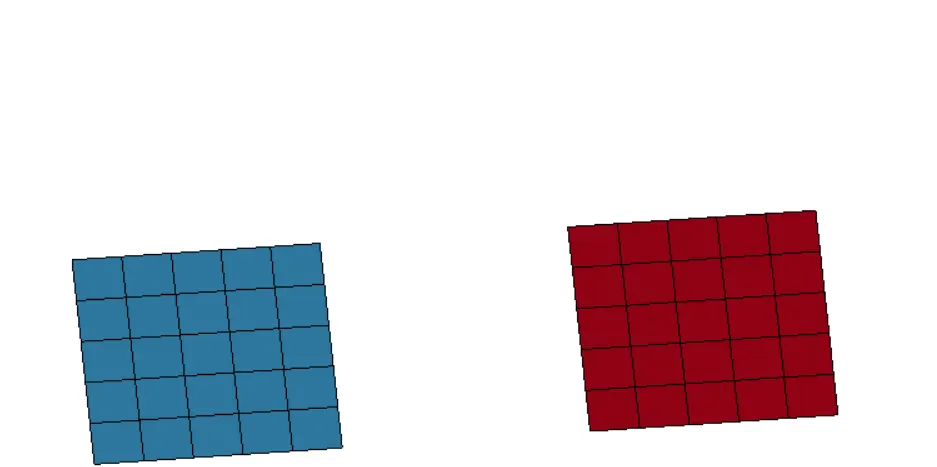
1. Two 4-noded Shell is created using the mesh option with two part Id's
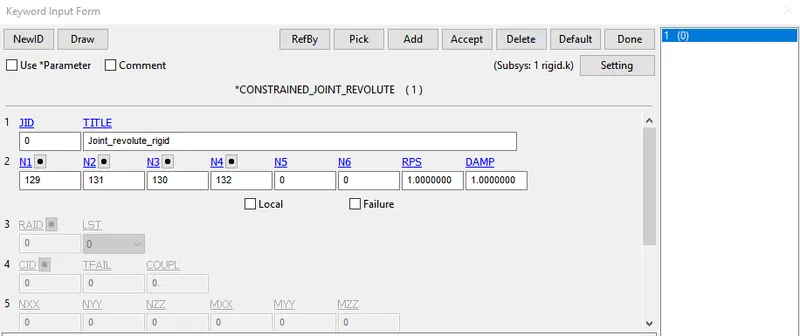
2. Four nodes should be created with two pair of coincident nodes at the centre between the two shell elemets parts which is created. i.e., here nodes 129 and 131 are coinciding and nodes 130 and 132 are coinciding.
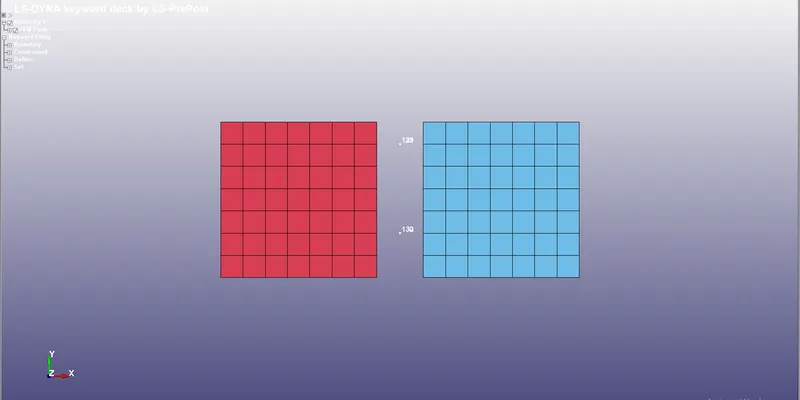
3. To assign the nodes to their parts we first need to create Node set containing the pairs which are needed to be assigned, then using the key word *CONSTRAINED_EXTRA_NODES_SET
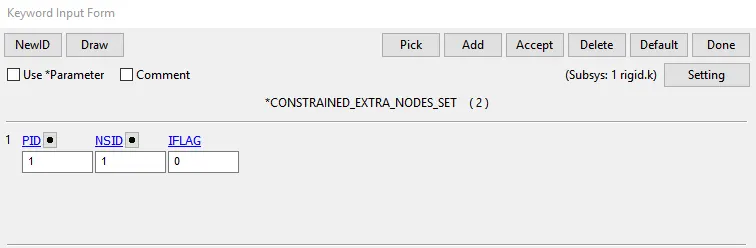
The Node set containing nodes 129 and 130 is assigned to Part 1
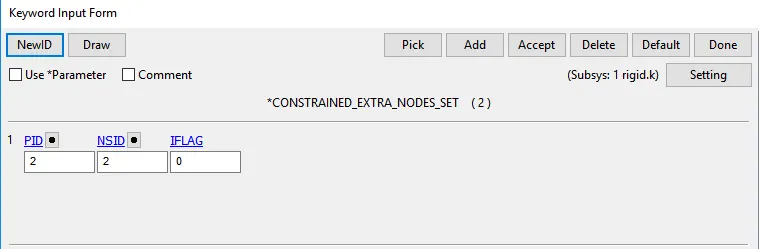
The Node Set containing node 131 and 132 is assigned to Part 2
4. The coincident nodes are enetered in the Card *CONSTRAINED_JOINT_REVOLUTE
After this Velocity Rigid is given to Part 2 while part 1 is fixed using Spc
RESULT
Case(ii): Deformable
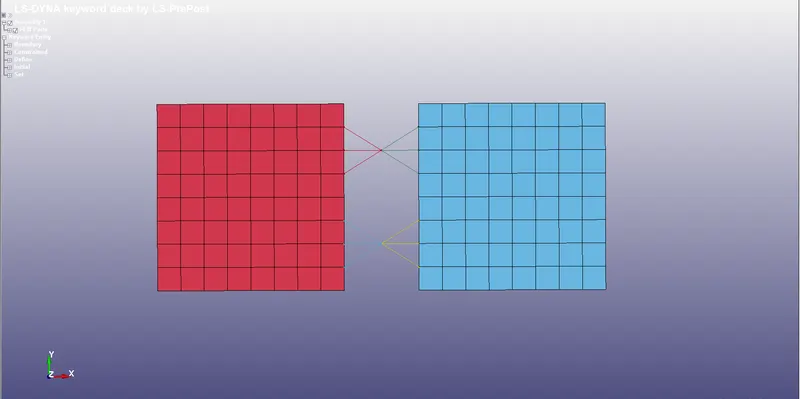
1. For Deformable we need to create CNRB in place of *CONSTRAINED_EXTRA_NODES_SET
2. As mentioned above the material card is changed from Mat_rigid to Mat_Elas
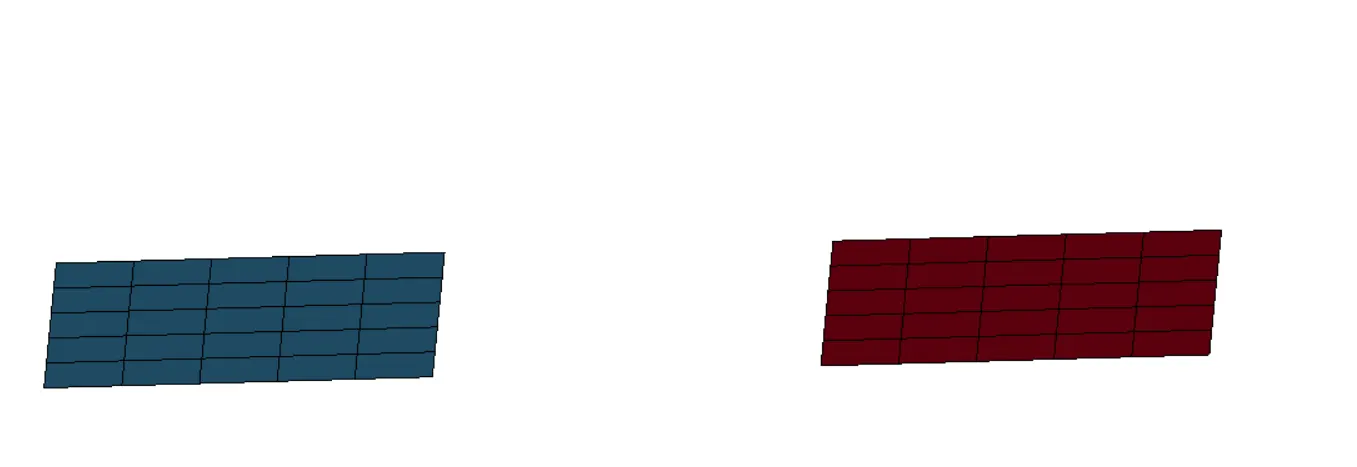
3. Also the velocity_rigid card is changed to Initial velocity since we are not using any Rigids here
4. All other cards are similar to the above
RESULT
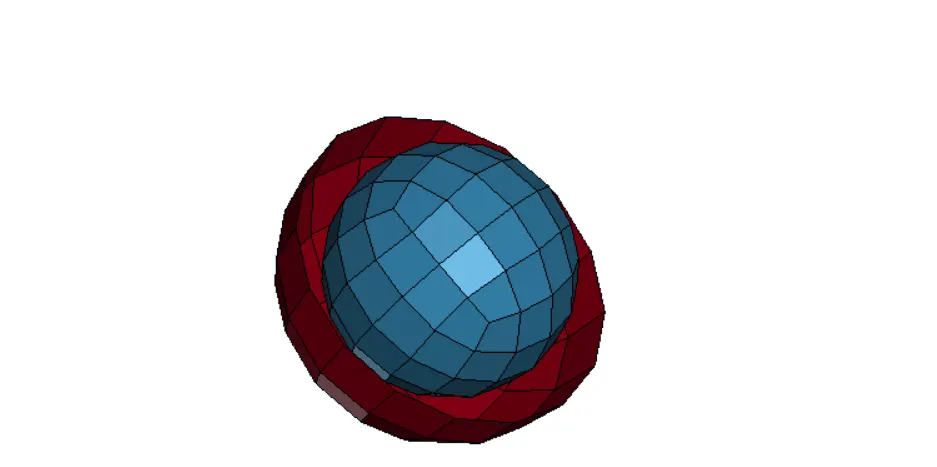
SPHERICAL JOINT
Case(i): Rigids:
1. Two Spherical shell is created using the mesh option with two part Id's
2. Two nodes is created at the centre of the spheres coincident to each other.
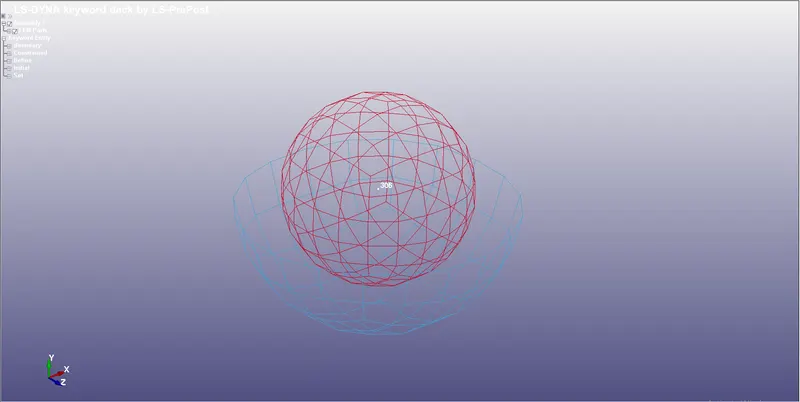
3. To assign the nodes to their parts we first need to create Node set containing the nodes which are needed to be assigned, then using the key word *CONSTRAINED_EXTRA_NODES_SET
The Node set containing nodes 305 is assigned to Part 1
The Node Set containing node 306 is assigned to Part 2
4. The coincident nodes are enetered in the Card *CONSTRAINED_JOINT_SPHERICAL
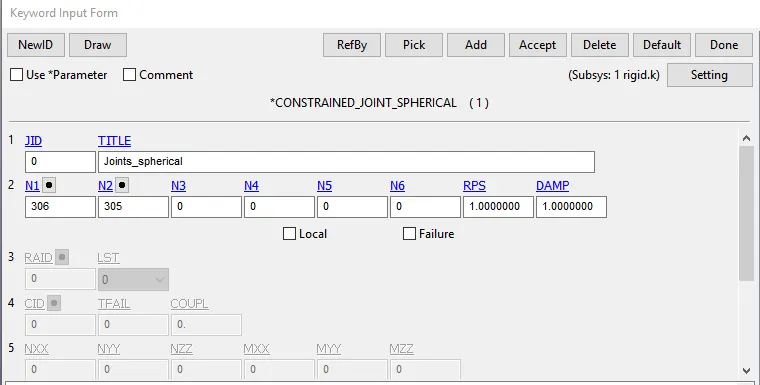
After this A rotational Velocity Rigid is given to Part 1 while part 2 is fixed using Spc
RESULT
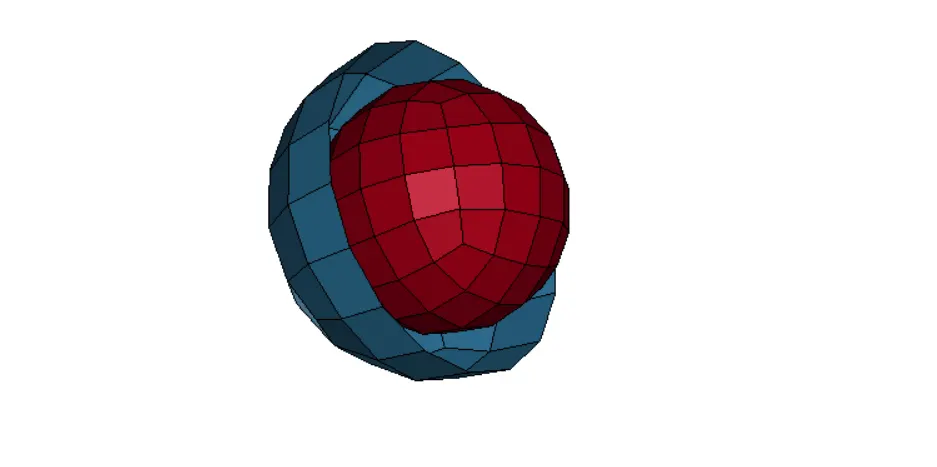
Case(ii): Deformable
1. For Deformable we need to create CNRB in place of *CONSTRAINED_EXTRA_NODES_SET
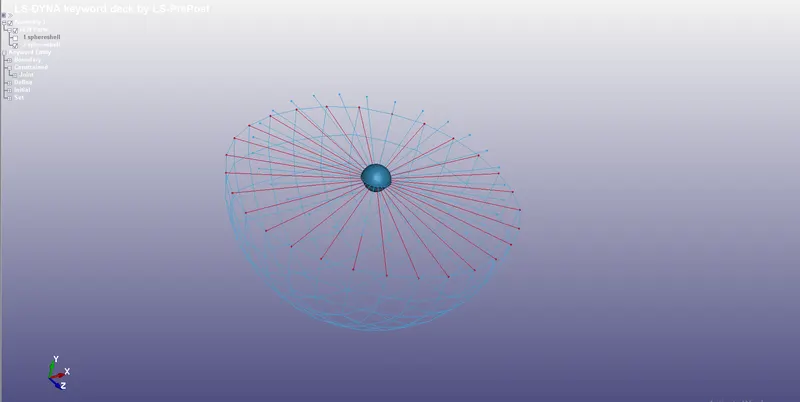
2. As mentioned above the material card is changed from Mat_rigid to Mat_Elas
3. Also the velocity_rigid card is changed to Initial velocity since we are not using any Rigids here
4. All other cards are similar to the above
RESULT
CYLINDRICAL JOINT
Case(i): Rigids:
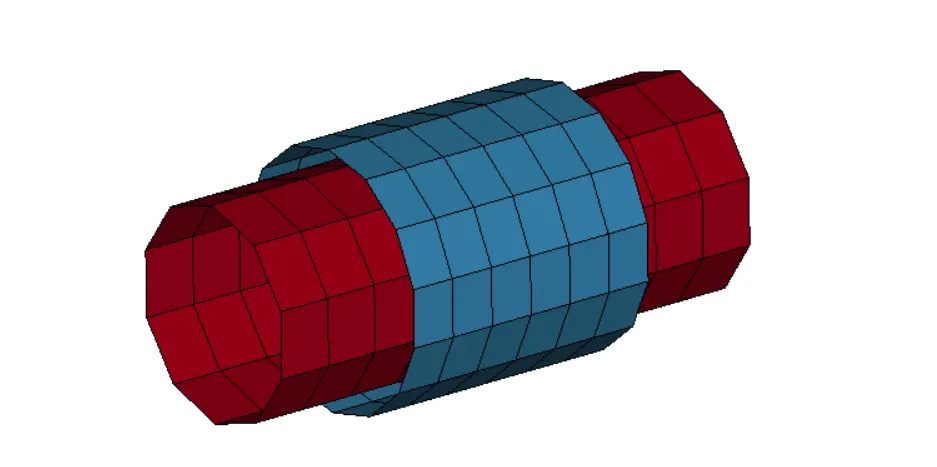
1. Two Cylindrical shell is created using the mesh option with two part Id's
2. Four nodes should be created with two pair of coincident nodes at the centre axis of the two shell elemets parts which is created. i.e., here nodes 363 and 368 are coinciding and nodes 366 and 367 are coinciding.
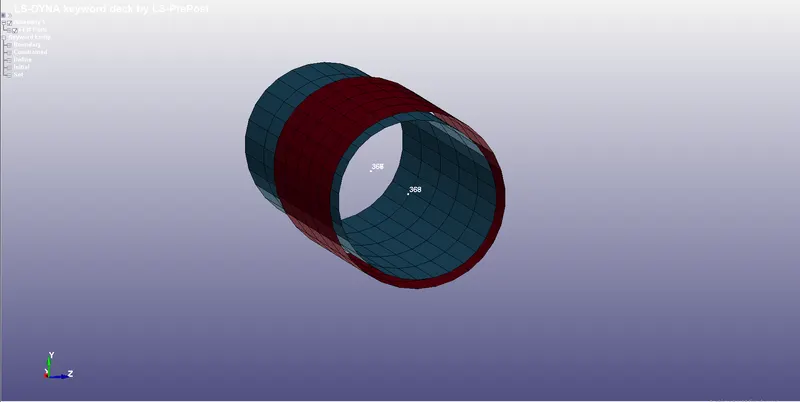
3. To assign the nodes to their parts we first need to create Node set containing the pairs which are needed to be assigned, then using the key word *CONSTRAINED_EXTRA_NODES_SET
The Node set containing nodes 363 and 366 is assigned to Part 1
The Node Set containing node 368 and 367 is assigned to Part 2
4. The coincident nodes are enetered in the Card *CONSTRAINED_JOINT_CYLINDRICAL
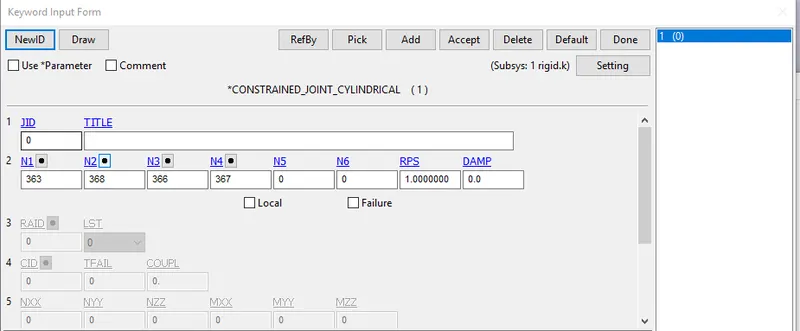
After this Velocity Rigid is given to Part 2 while part 1 is fixed using Spc
RESULT
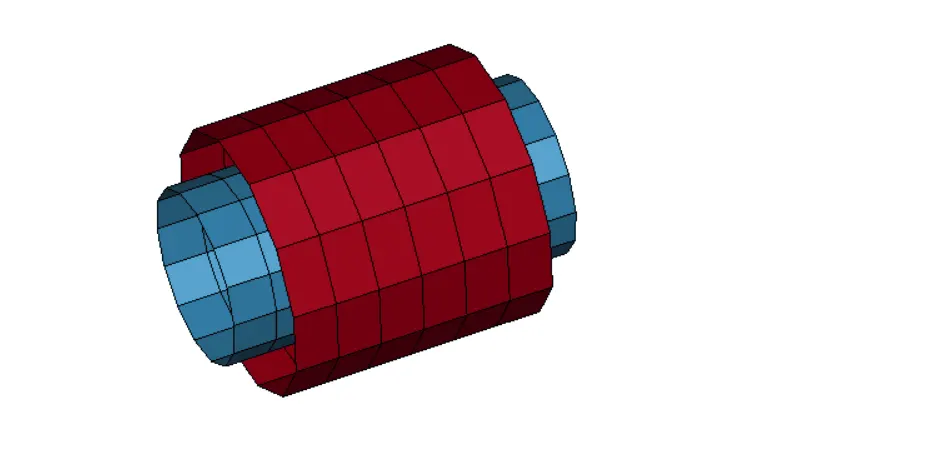
Case(ii): Deformable
1. For Deformable we need to create CNRB in place of *CONSTRAINED_EXTRA_NODES_SET
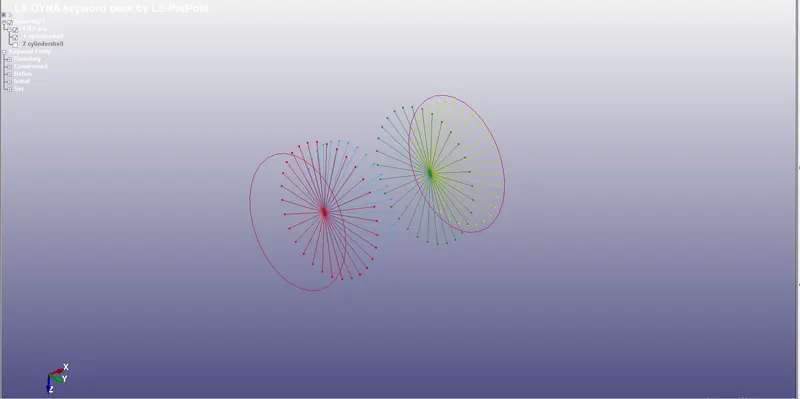
2. As mentioned above the material card is changed from Mat_rigid to Mat_Elas
3. Also the velocity_rigid card is changed to Initial velocity since we are not using any Rigids here
4. All other cards are similar to the above
RESULT
TRANSLATION JOINT
Case(i): Rigids:
1. Two Cylindrical shell is created using the mesh option with two part Id's
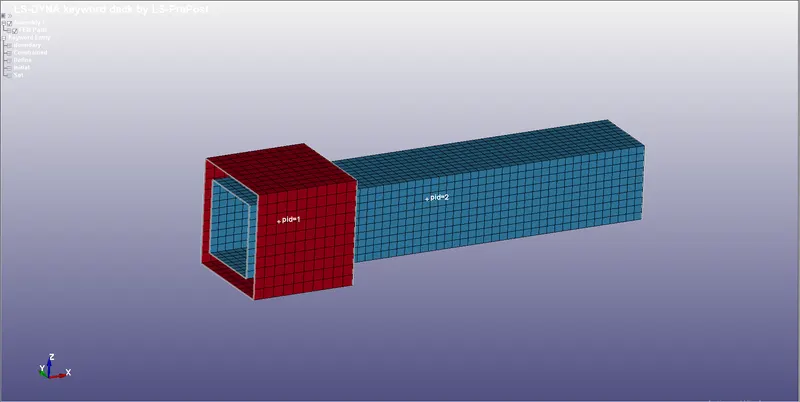
2. Six nodes should be created with three pair of coincident nodes at the centre axis of the two shell elemets parts which is created. i.e., here nodes 2500 and 2503 are coinciding , nodes 2501 and 2504 are coinciding and nodes 2502 and 2505 are coinciding.
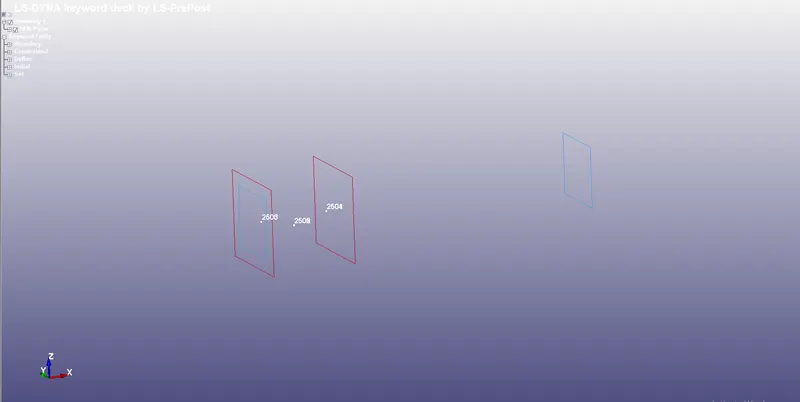
3. To assign the nodes to their parts we first need to create Node set containing the pairs which are needed to be assigned, then using the key word *CONSTRAINED_EXTRA_NODES_SET
The Node set containing nodes 2500, 2501 and 2502 is assigned to Part 1
The Node Set containing node 2503, 2504 and 2505 is assigned to Part 2
4. The coincident nodes are enetered in the Card *CONSTRAINED_JOINT_TRANSLATIONAL
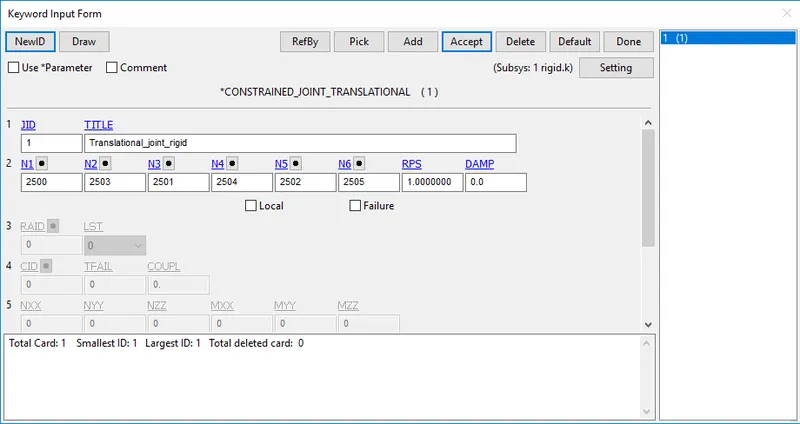
After this Velocity Rigid is given to Part 2 while part 1 is fixed using Spc
RESULT
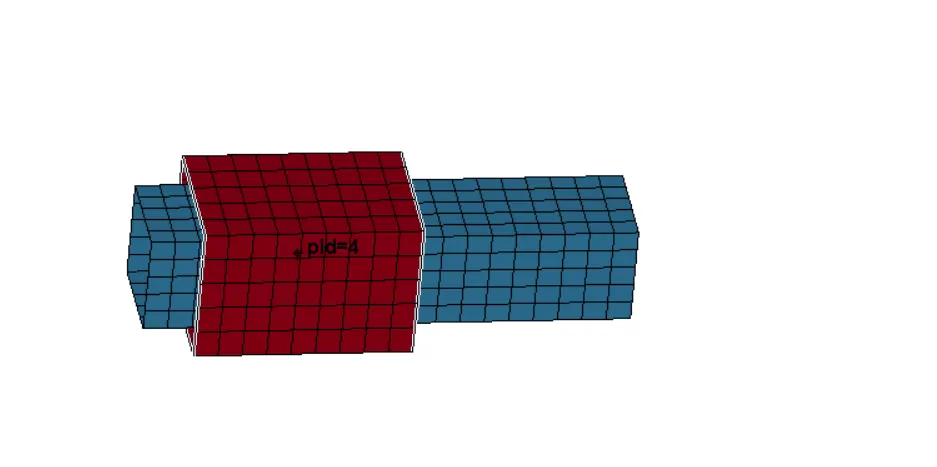
Case(ii): Deformable
1. For Deformable we need to create CNRB in place of *CONSTRAINED_EXTRA_NODES_SET
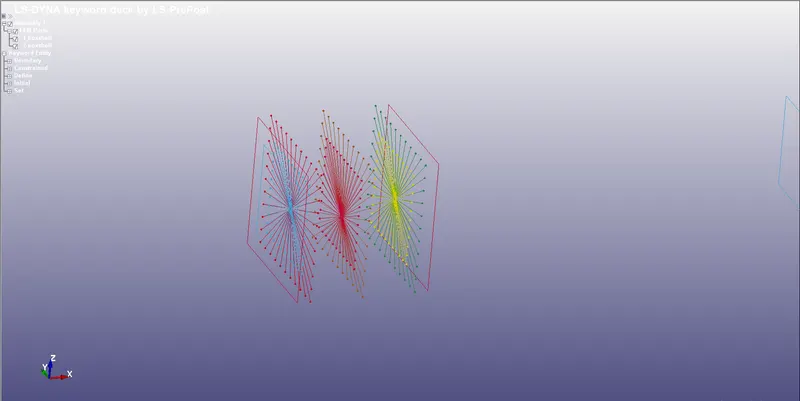
2. As mentioned above the material card is changed from Mat_rigid to Mat_Elas
3. Also the velocity_rigid card is changed to Initial velocity since we are not using any Rigids here
4. All other cards are similar to the above
RESULT
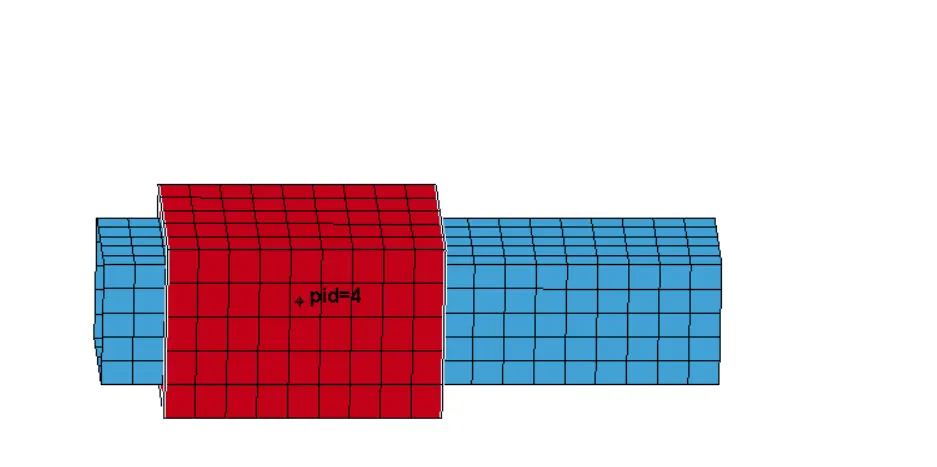
CONCLUSION :
The Cylindrical,Translational,Revolute & Spherical joints between two Rigid and two deformable bodies are created using Ls-Dyna solver with the help of "ls-dyna_manual_volume_i_r12" .