week-11 Joint creation and Demonstration
Joint Creation and Demonstration in LS DYNA:
A joint is a section or sub-assembly used to connect two parts (linkages) with a relative motion between the connected parts. The joint can either be a fully constrained and partial constrained i.e free movement. The demonstration presented here comprises of creation and working of joints between simple parts (both rigid and Deformable in nature) and these can be extended to complex parts although the principle remains same.
Defining joints using Constrained nodal rigid body(CNRB) (For Deformable bodies):
Another way to define joints is by using Constrained nodal rigid body(CNRB). This is used to define joints among the deformable bodies. Just like the constrained extra node set, cnrb are defined to associate the nodeset with the parts. Then joints are then defined using Contrained_joint_.
Constrained nodal rigid body are created from Entity creation tab, selecting all the nodes of the part and the additional node created for defining the joint.
Defining joints using extra node/node set (For rigid bodies):
Joints in LS DYNA can be defined using extra nodeset methods, provided the bodies are rigid in nature.
In this method, nodes which are co-incident are created. These nodes are associated with the rigid bodies using Constrained_Extra_node_set keyword.
Then joint is defined using the extra nodes associated with the parts using Contrained_joint_
1. Cylindrical joint: The relative motion between bodies has two degrees of freedom, i.e one axial and 1 rotational dof. Only two sets of nodes are required to define the cylindrical joint for rotational degree of freedom and axial movement can be provided using the Velocity_rigid_motion.
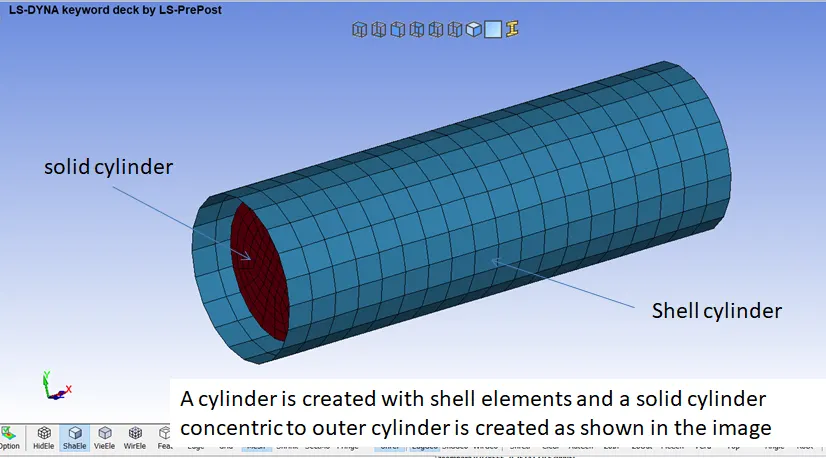
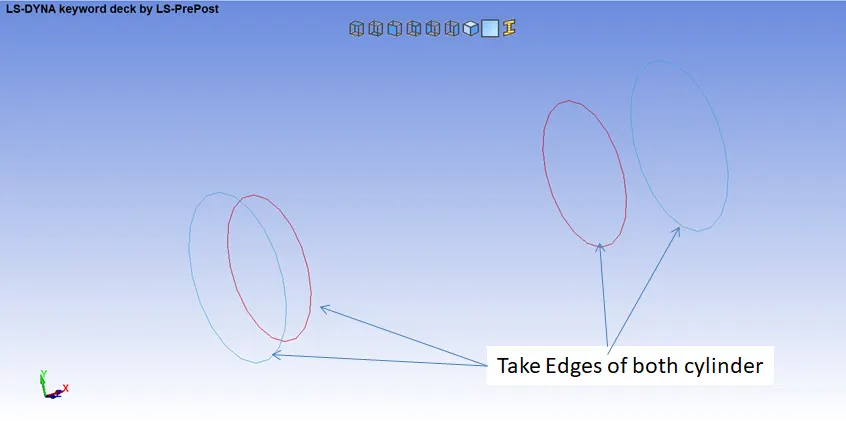
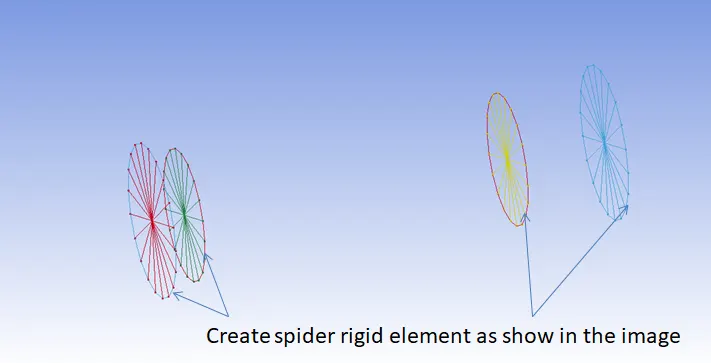
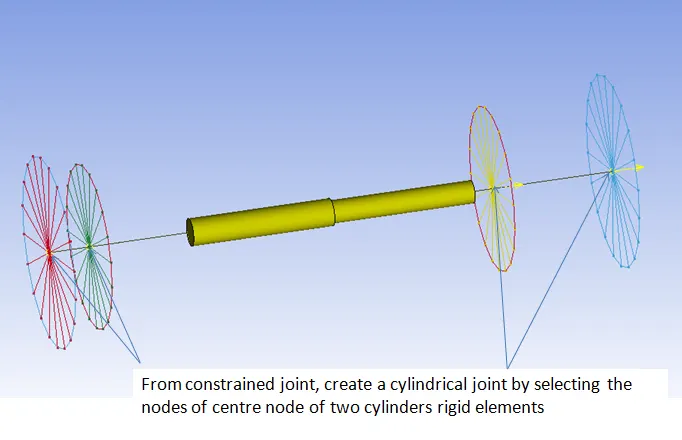
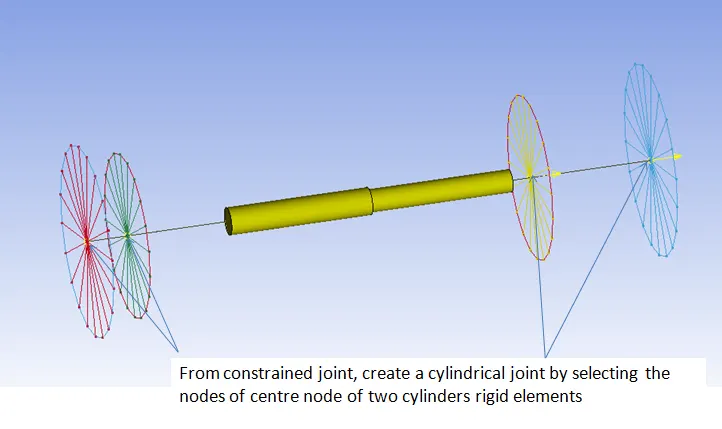
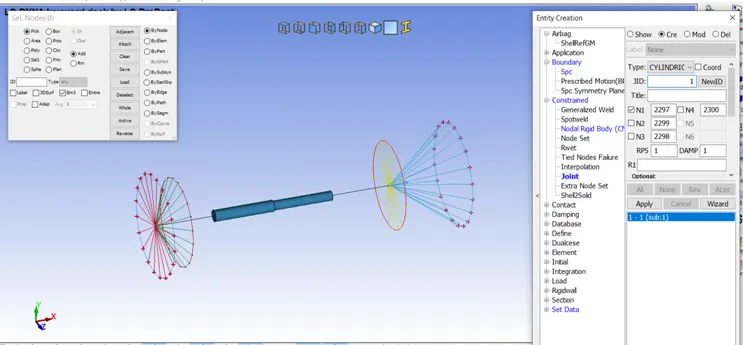
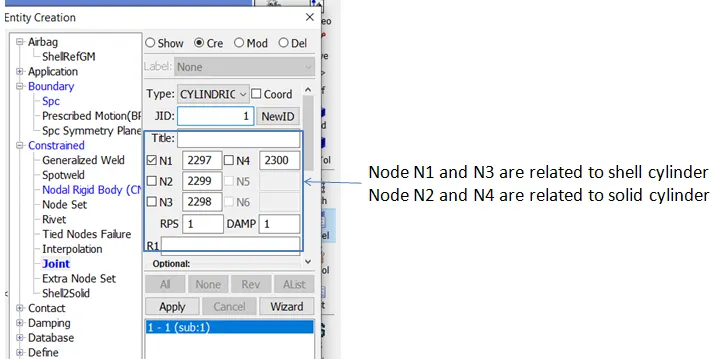
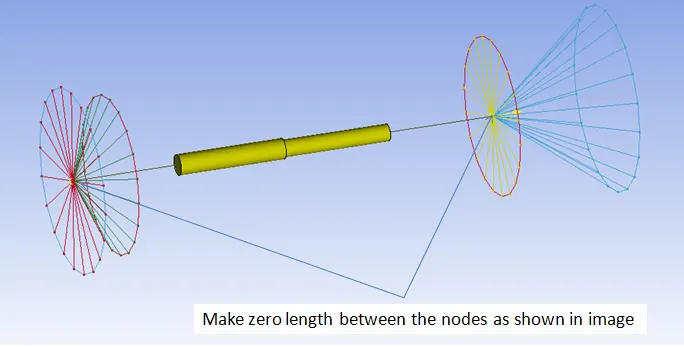
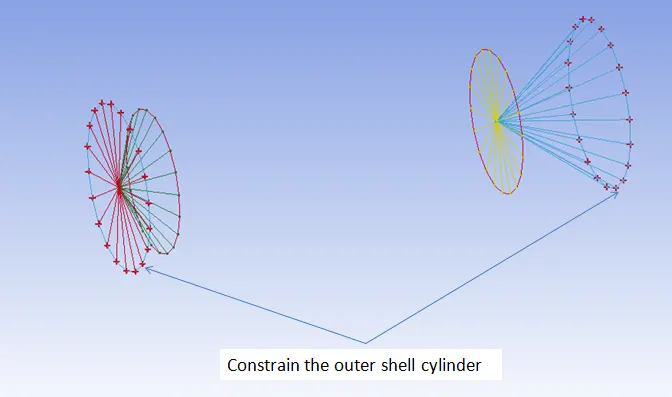
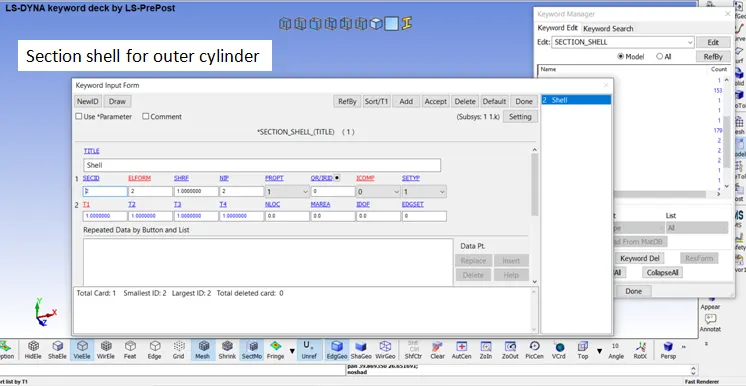
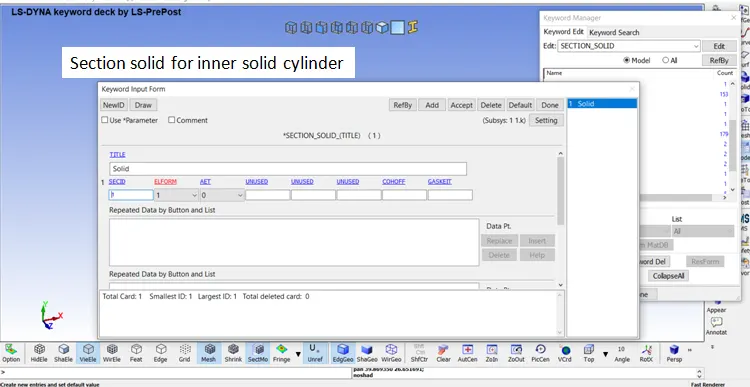
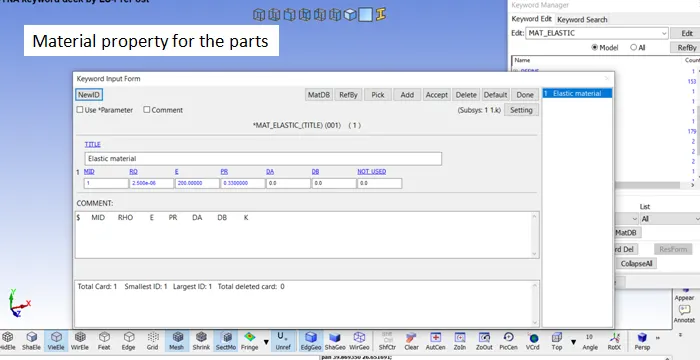
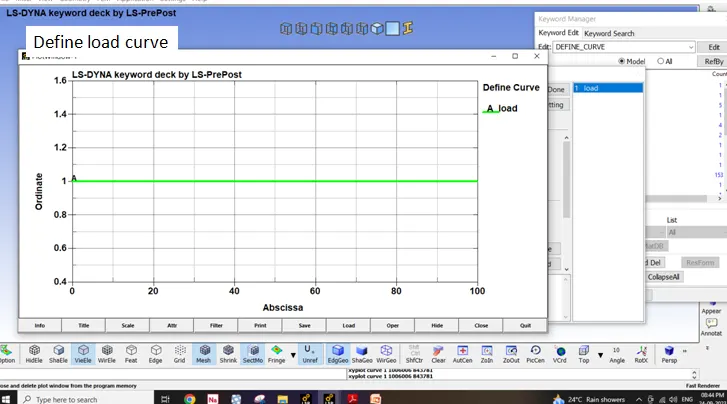
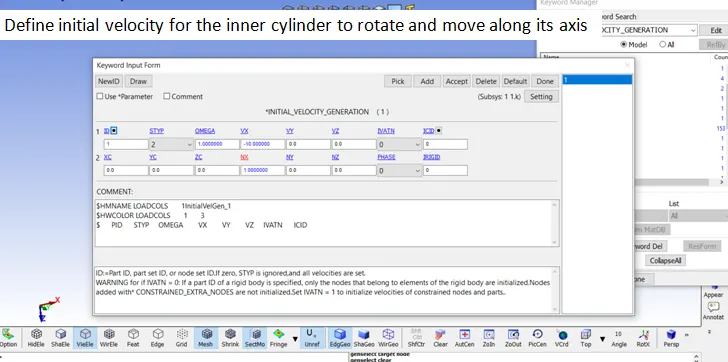
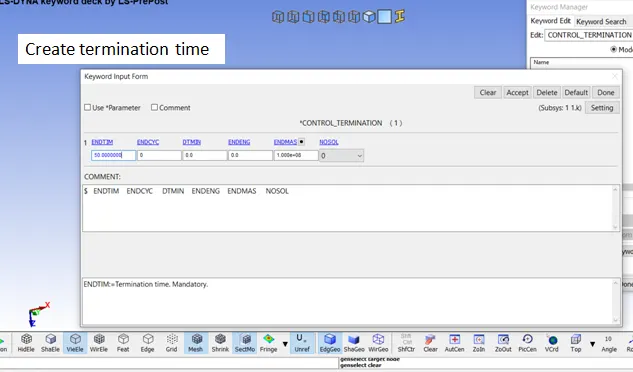
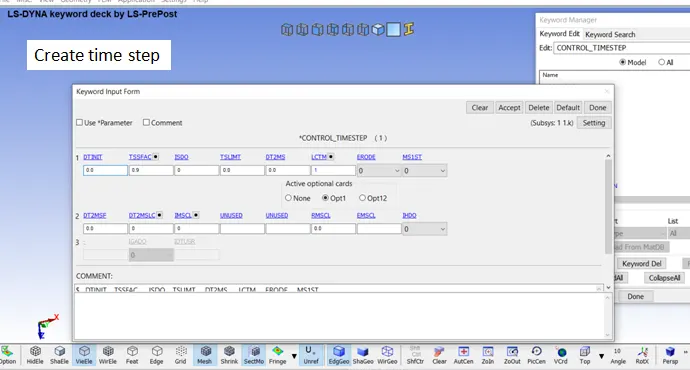
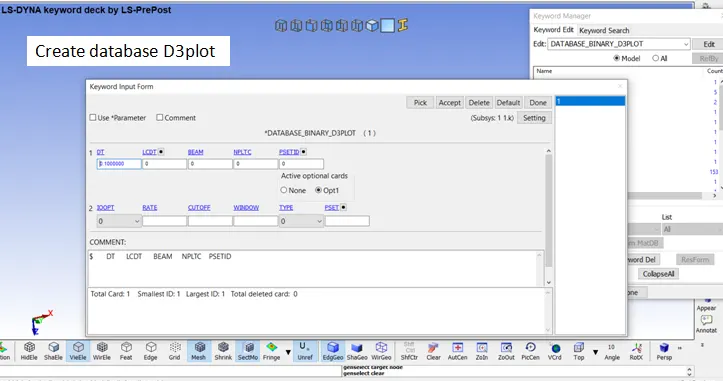
Save the model and run the key file
result
Deformable bodies result
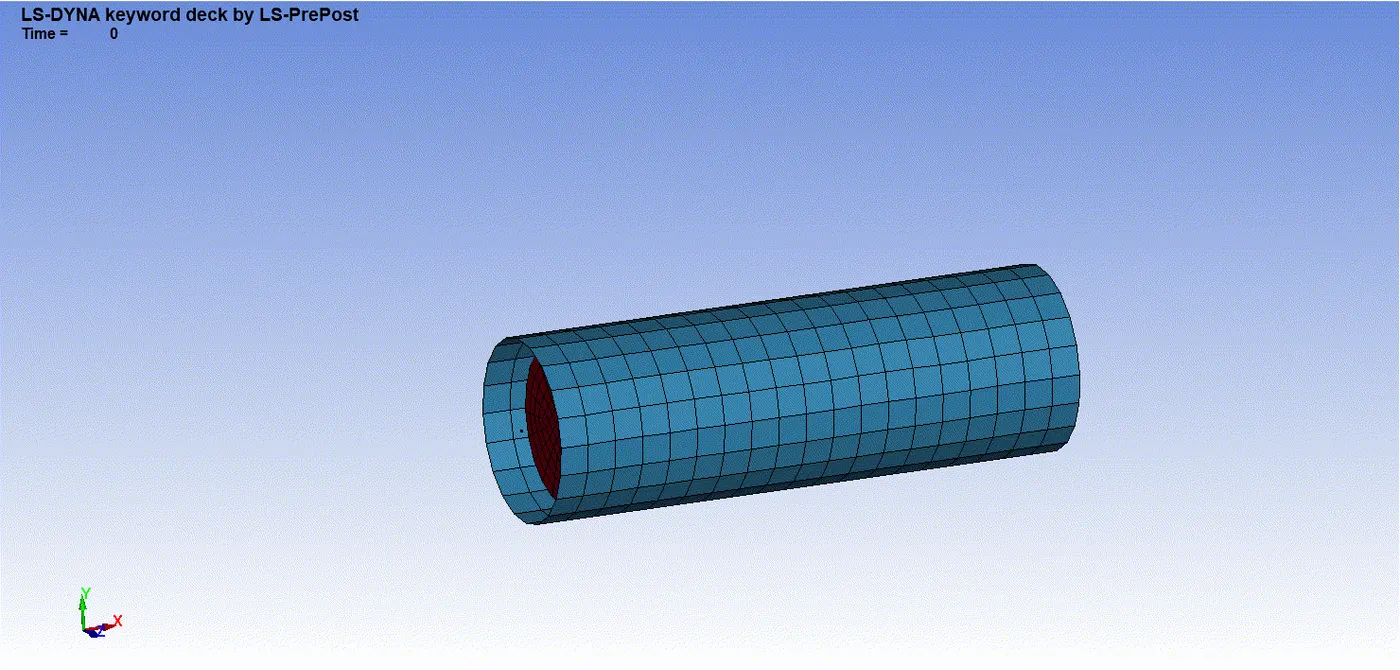
for using rigid bodies
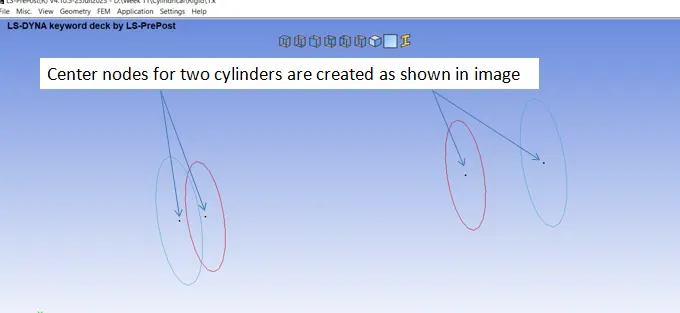
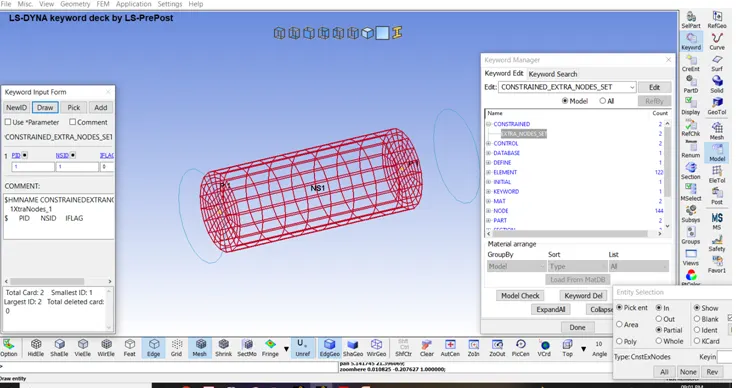
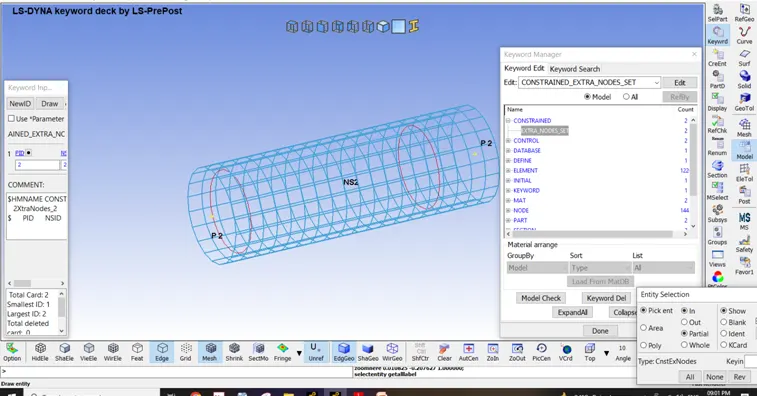
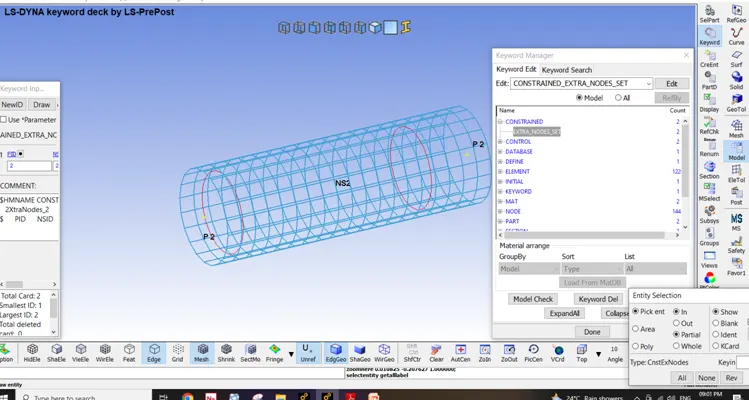
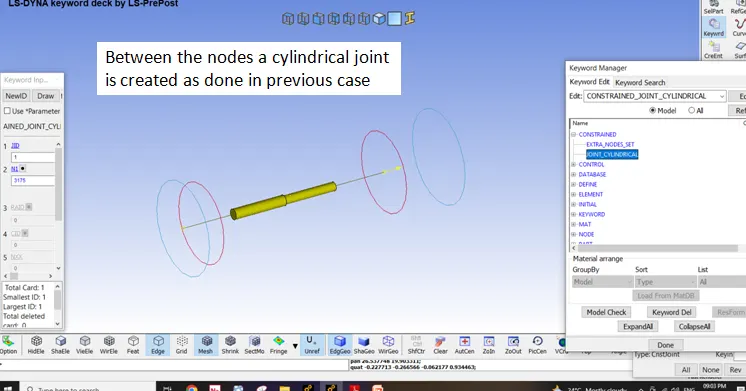
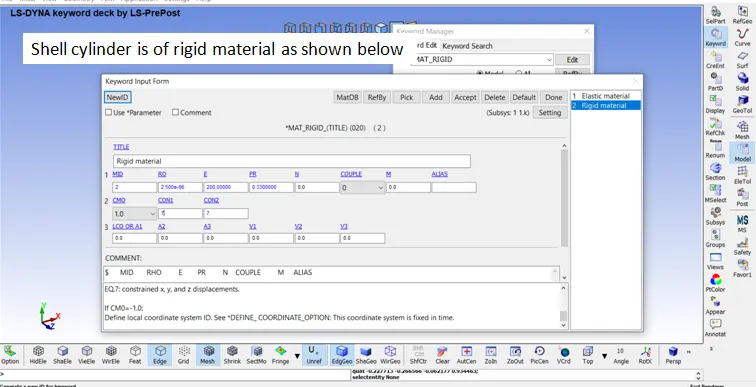
Rest of the procedure is same as in deformable bodies case, then save the model and submit for run
rigid bodies result
2. Revolute joint: This joint is also known as hinge joint or pin joint. In this case the relative motion between bodies is restricted to rotations about the axis formed by pair of co-incident nodes.
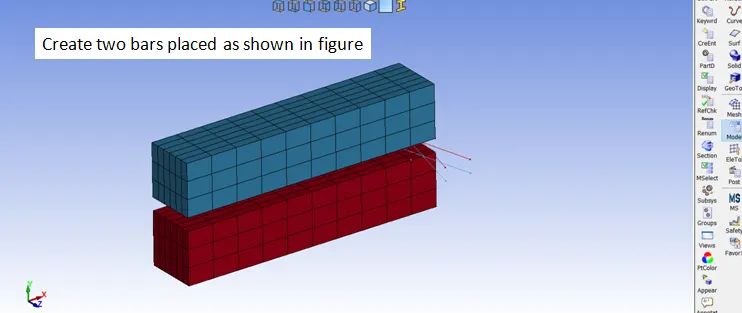
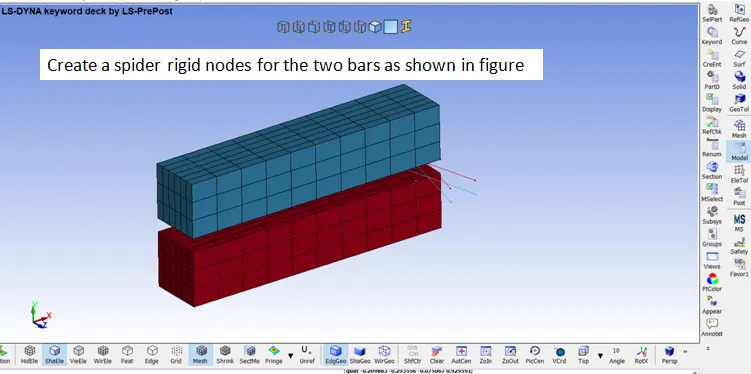
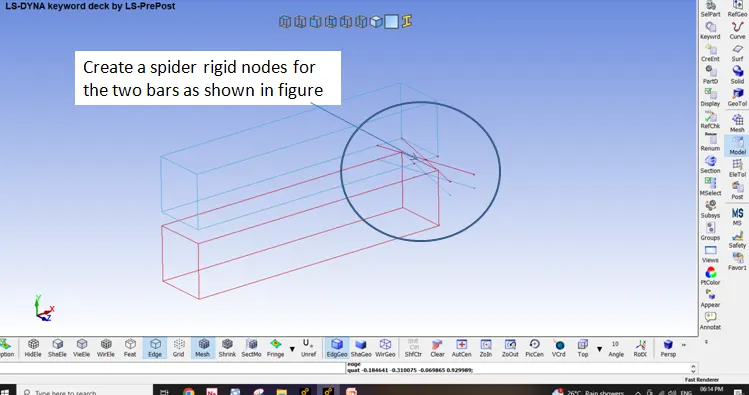
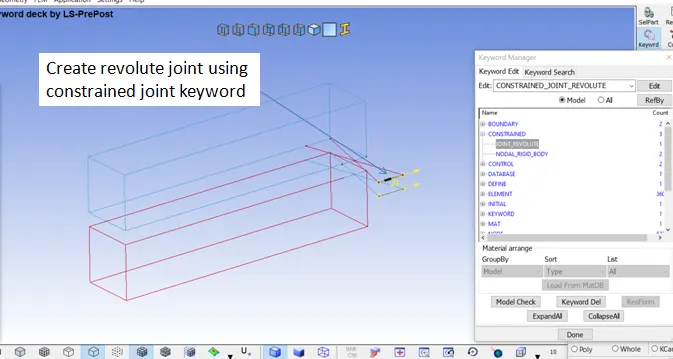
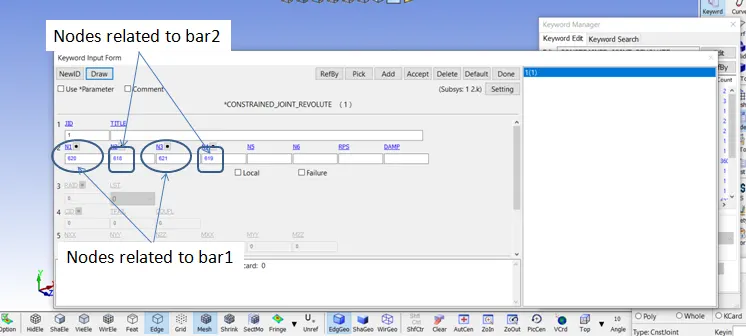
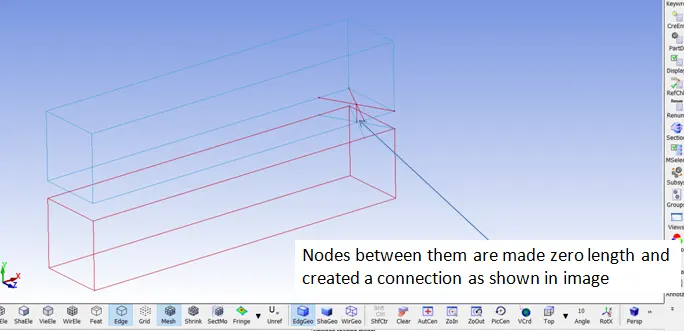
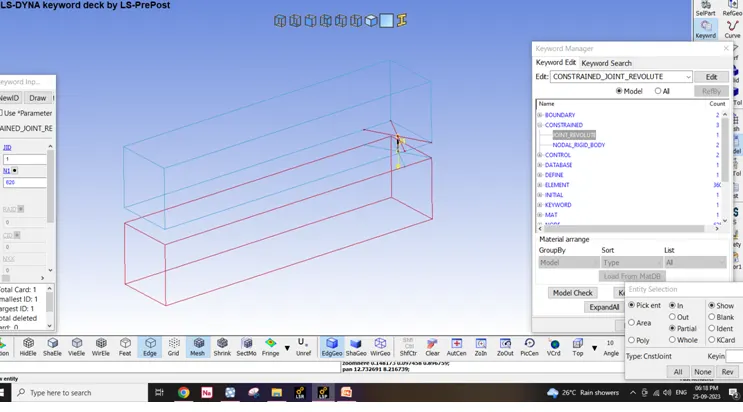
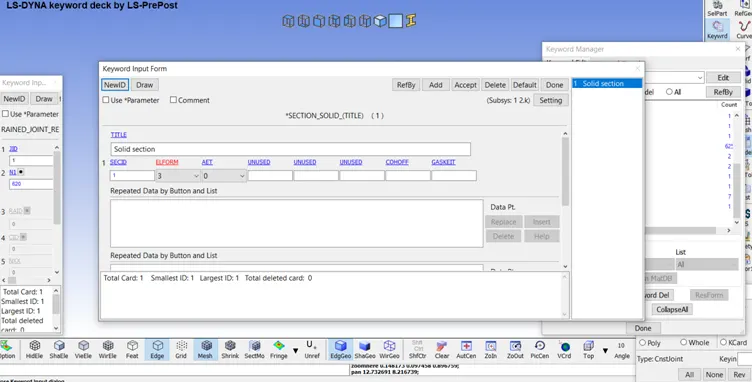
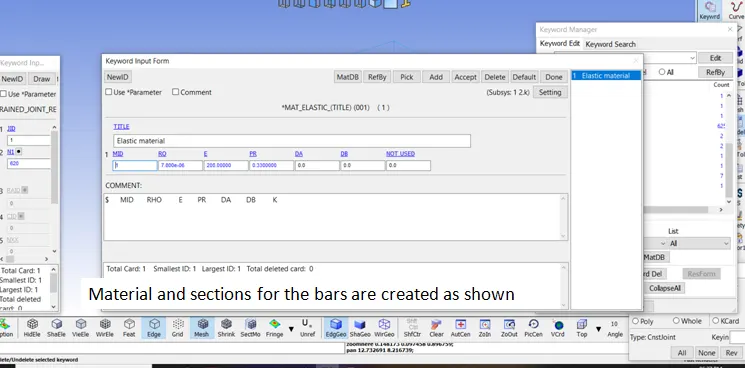
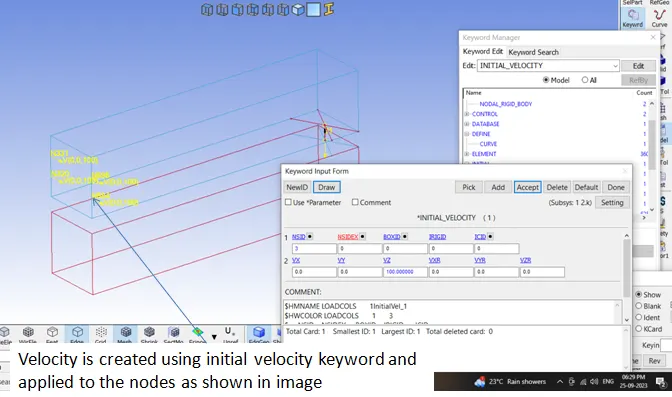
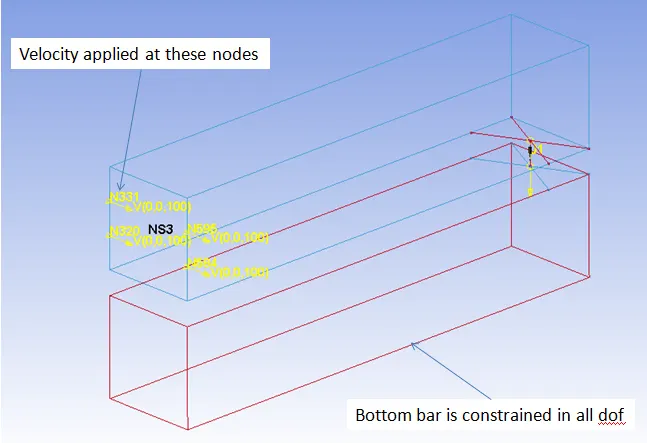
Control cards, database cards are same as in previous joint case. Save the model and run.
Deforamable bodies results
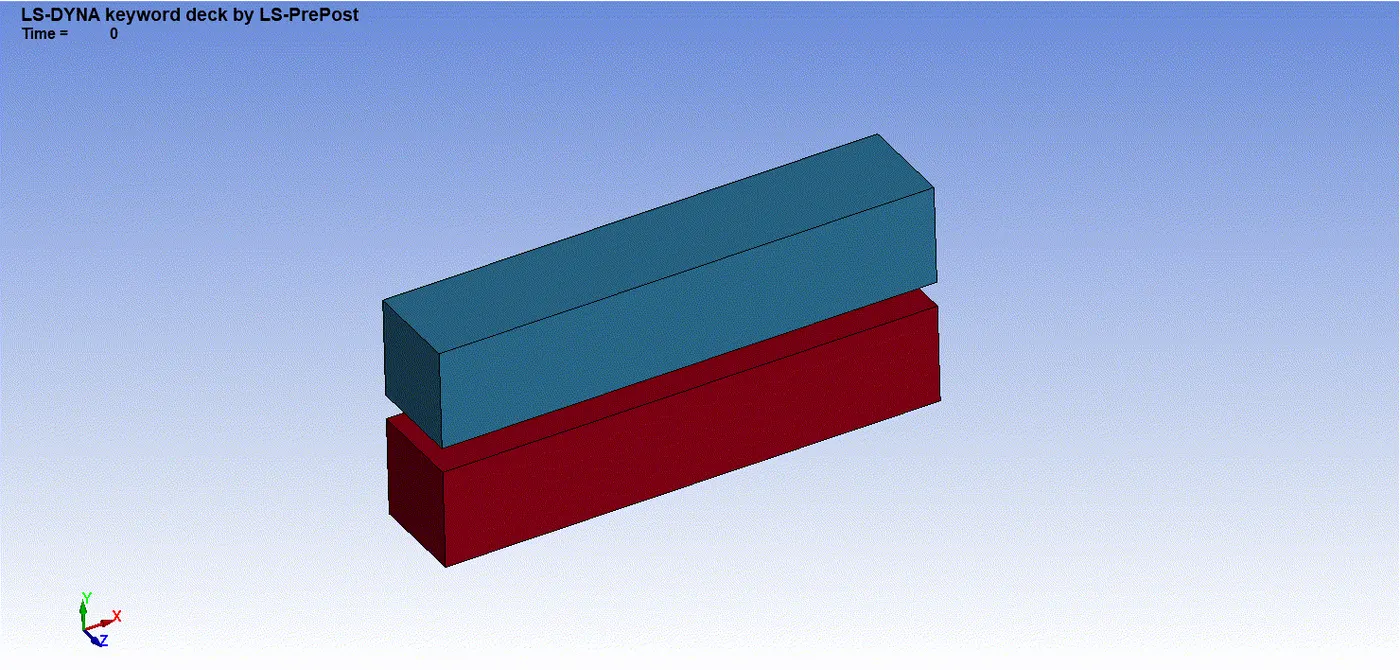
for rigid bodies
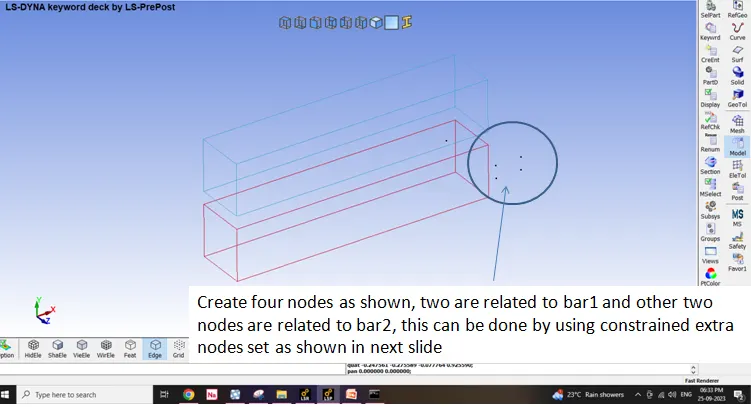
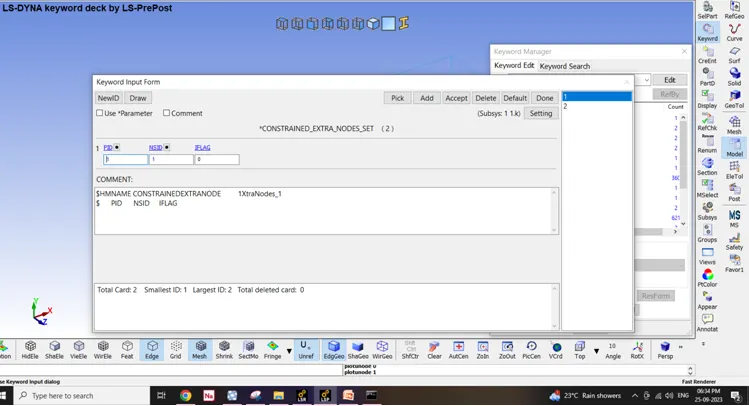
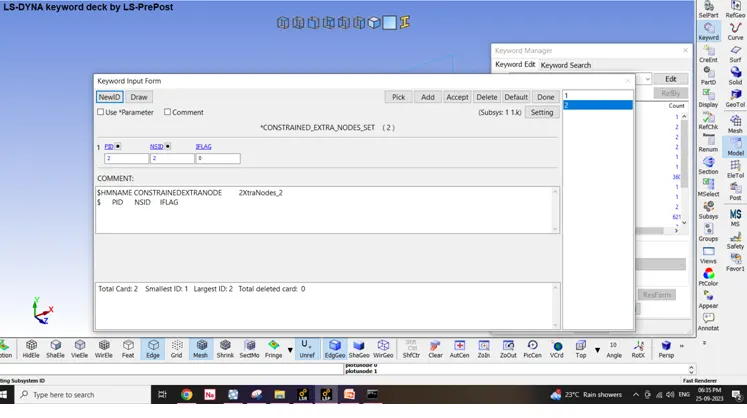
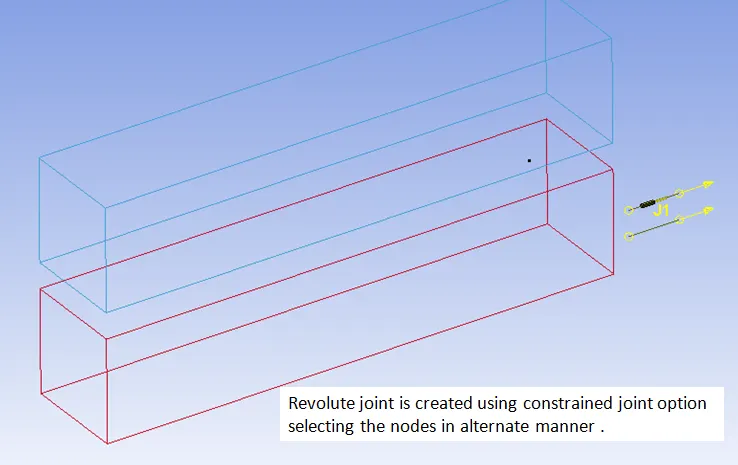
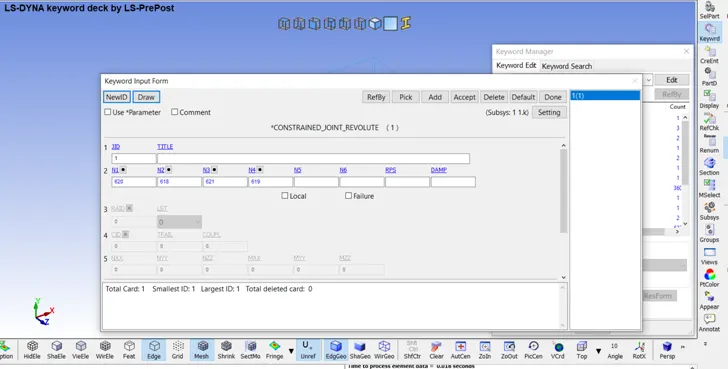
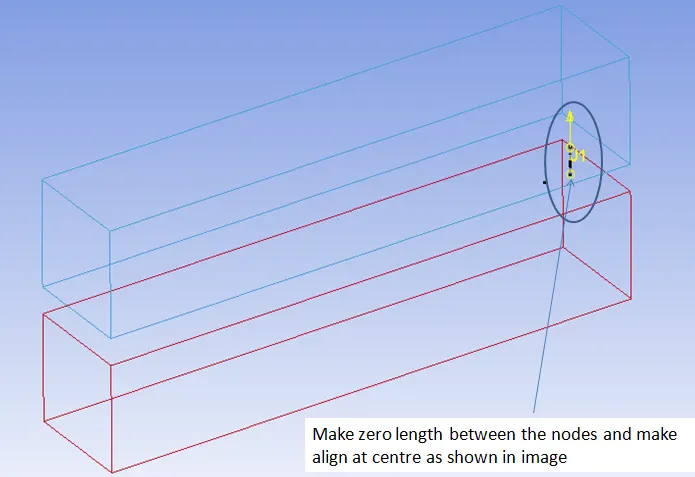
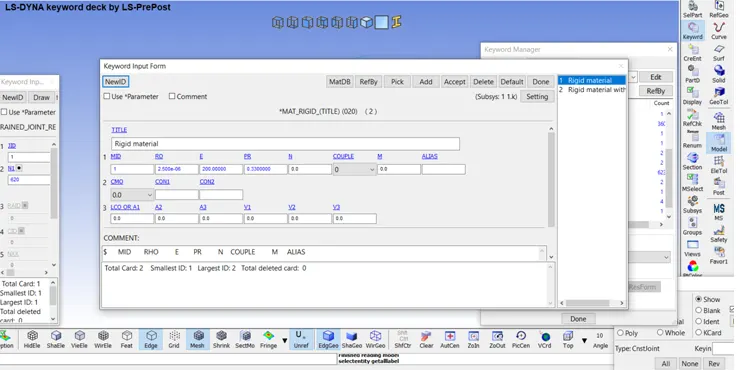
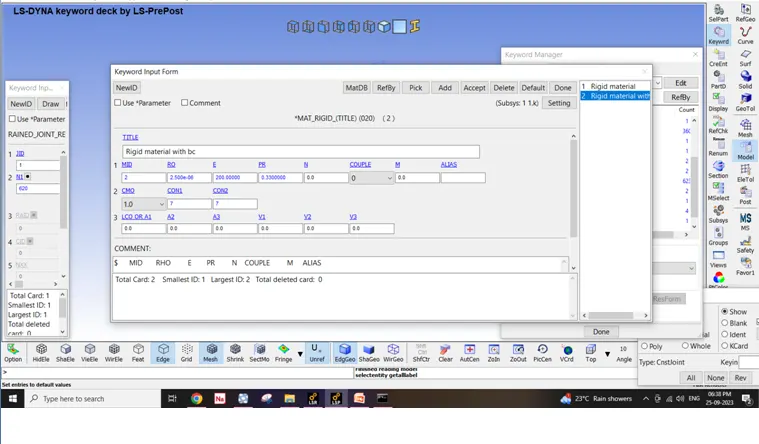
Material and section are created as usual, boundary condition, control cards and database cards are same as in previous case. Save the model and submit for run
Rigid bodies results
3. Spherical joint: In this joint, the relative motion between two bodies is free in all rotational degree of freedom but constrained in translational degree of freedom. Defining this joint in LS DYNA requires one set of nodes.
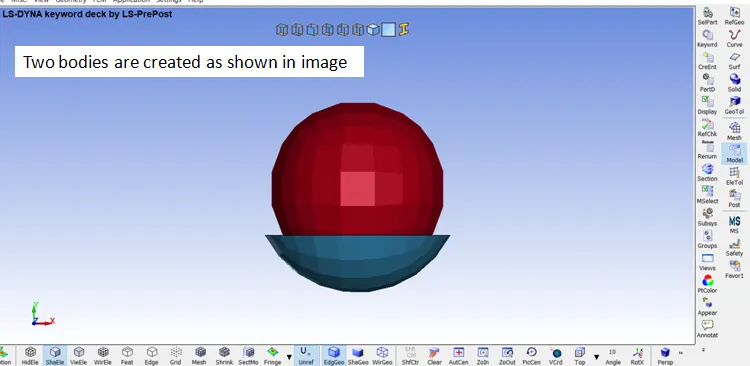
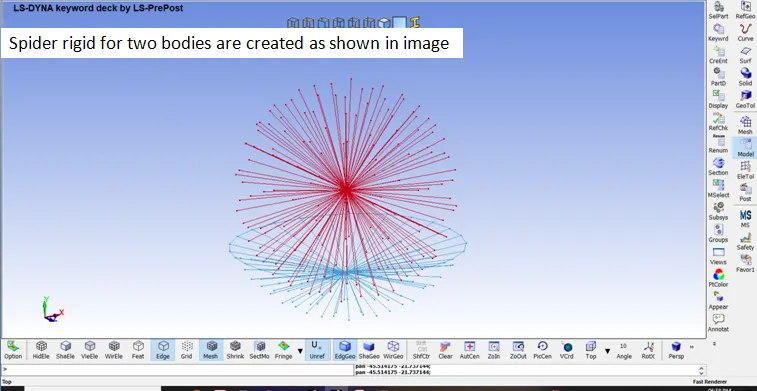
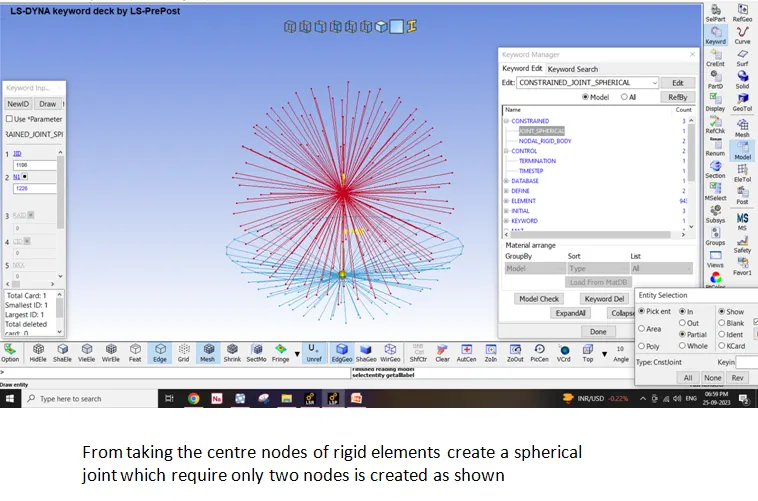
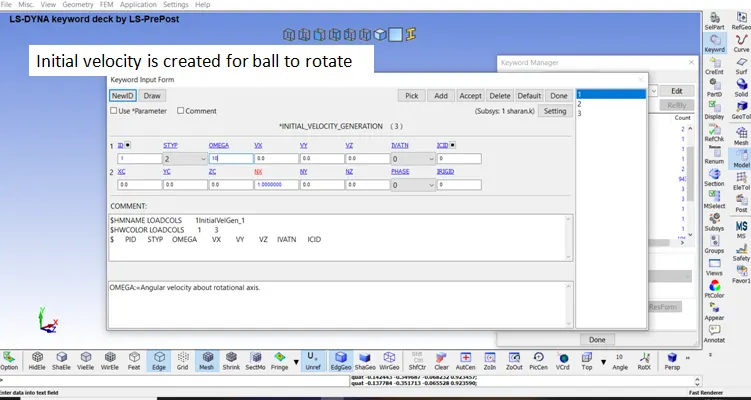
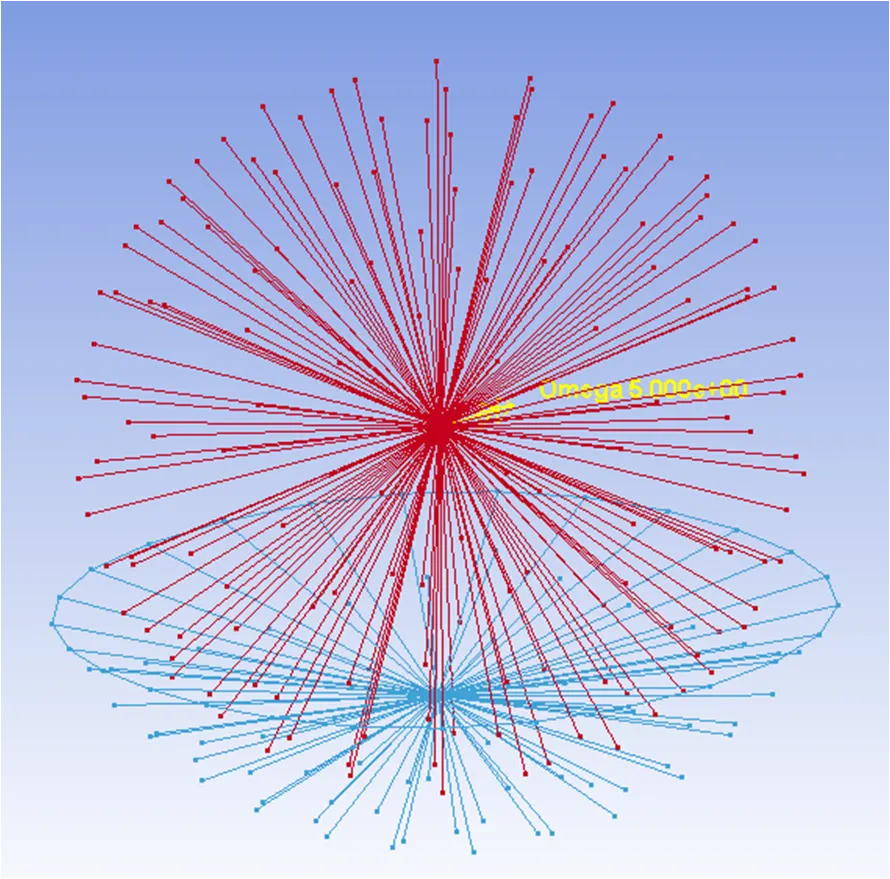
Material cards, Section cards, parts , control cards and database cards are created same as in previous joint case. Save the model and run it
Deformable bodies results
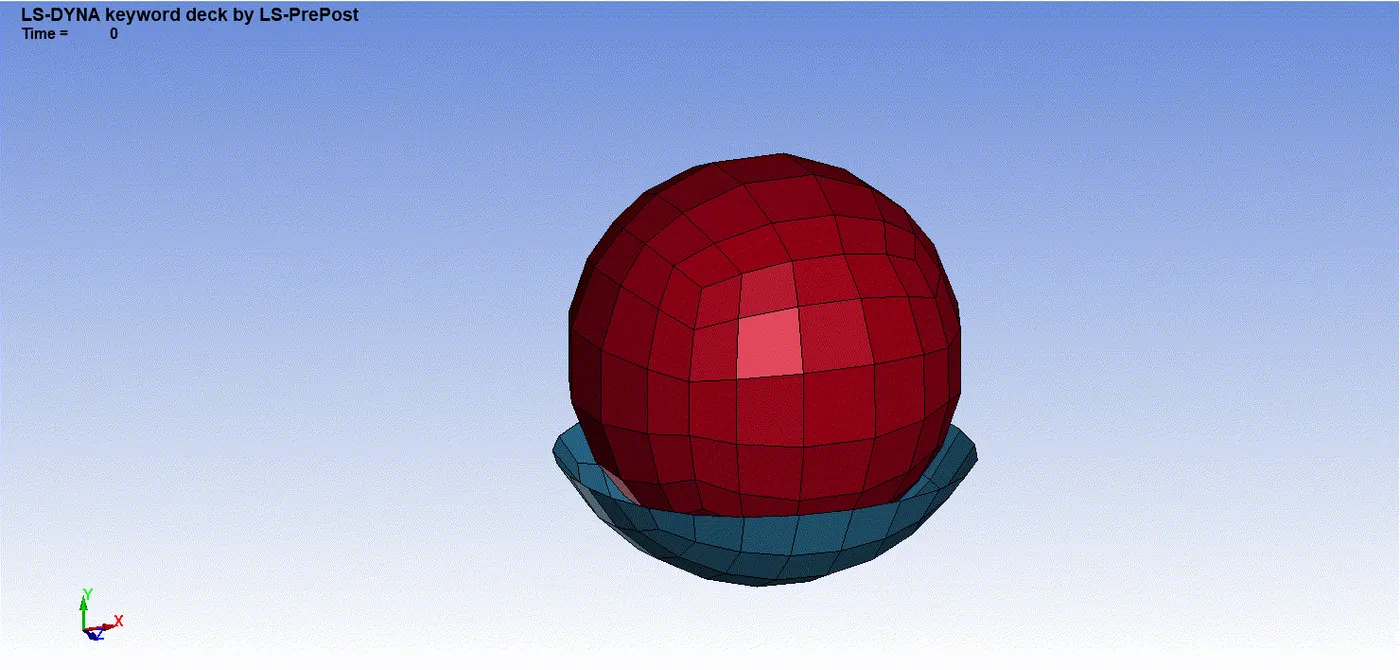
Rigid bodies case
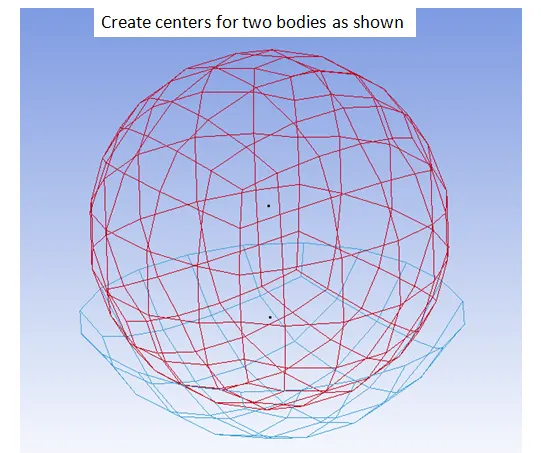
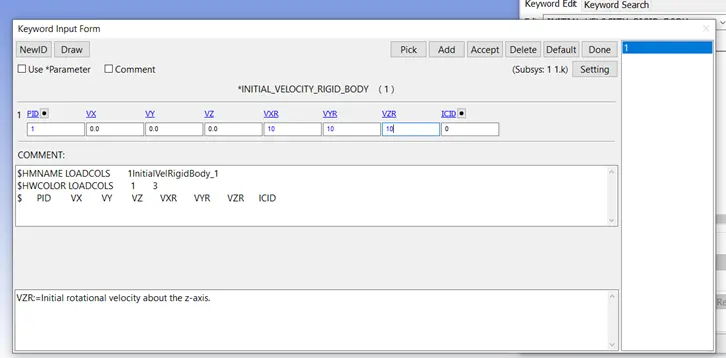
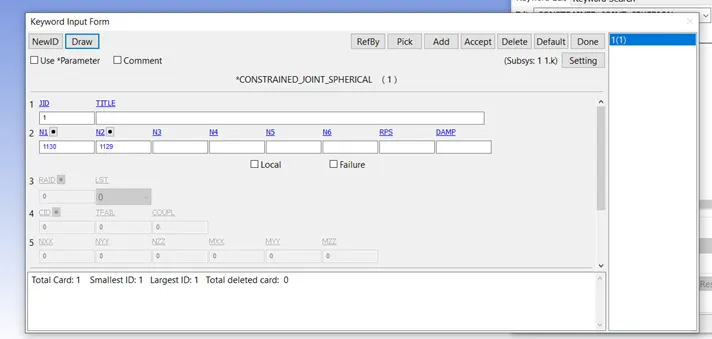
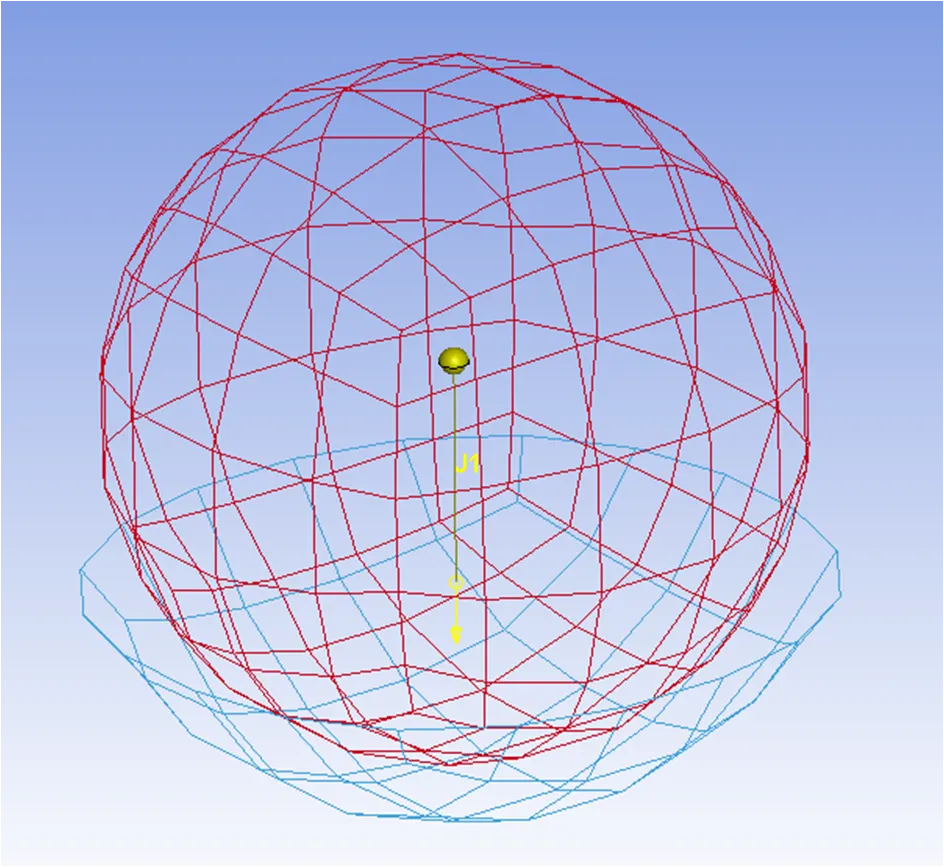
Material cards, Section cards, parts , control cards and database cards are created same as in previous joint case. Save the model and run it
results for rigid bodies
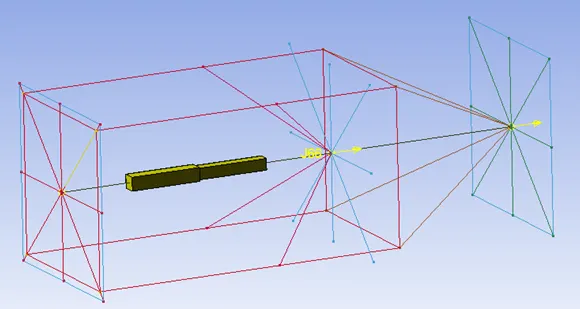
4. Translational joint: The relative motion between bodies has only degree of freedom i.e along the axial direction. Three sets of nodes are required to define this joint. Two sets for allowing the motion, one set for constraining the rotational degree of freedom.
Accordingly, three sets of co-incident nodes are created at three points and respective sets are associated with parts.
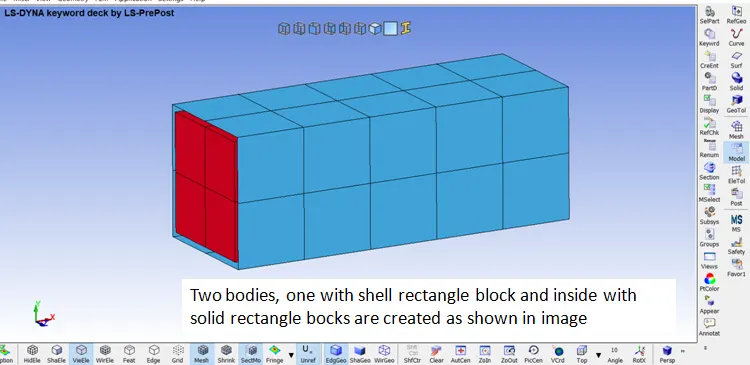
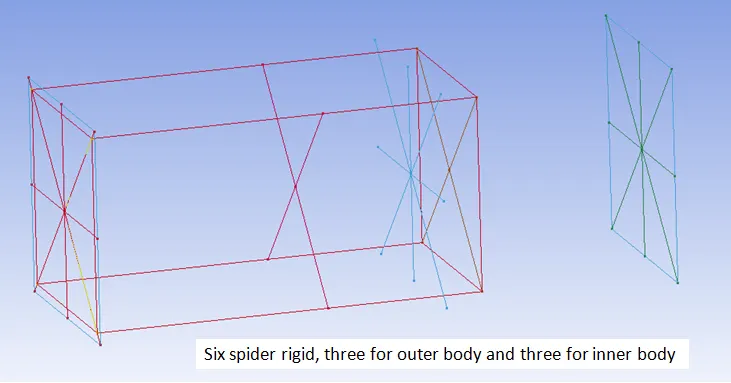
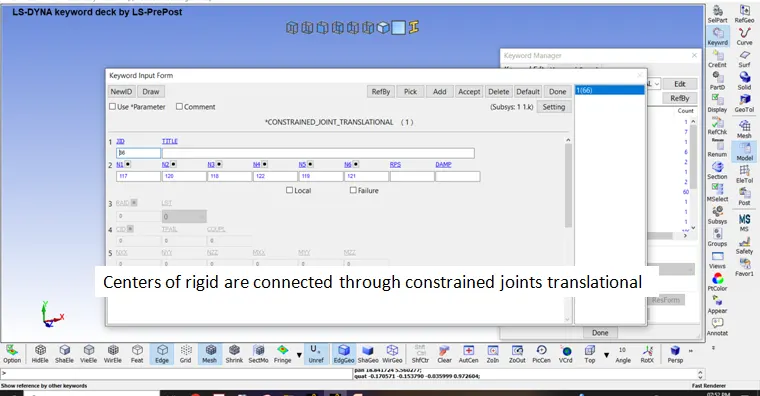
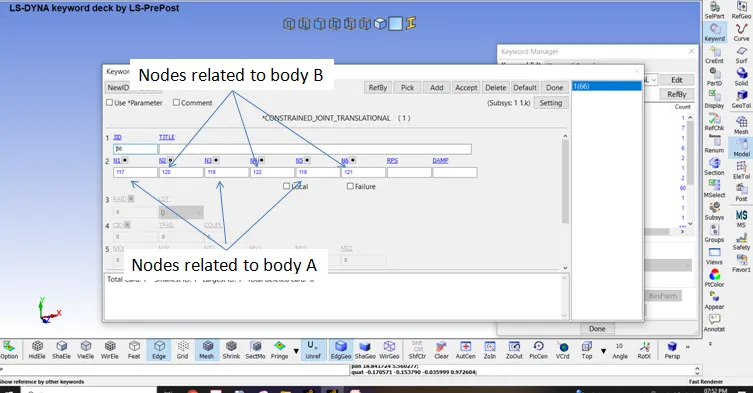
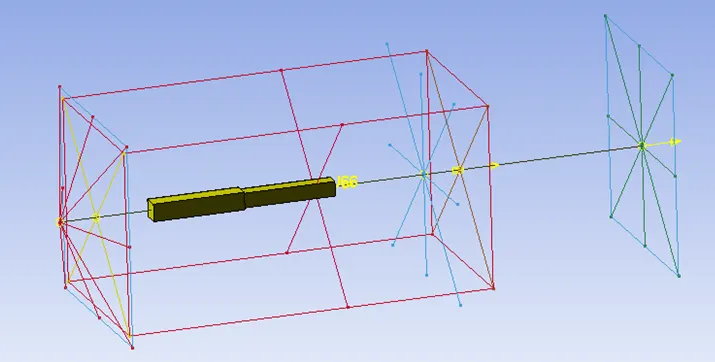
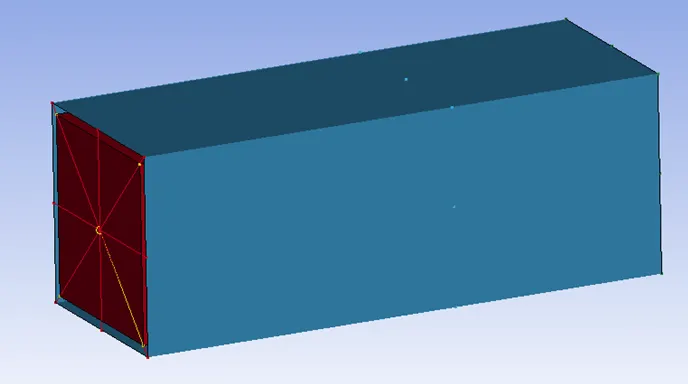
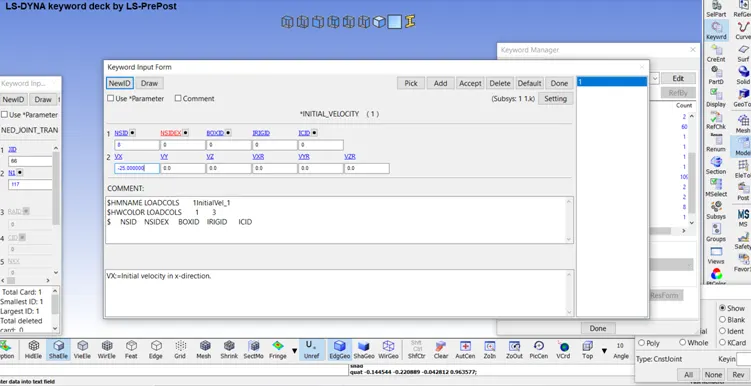
Material cards, Section cards, parts , control cards and database cards are created same as in previous joint case. Save the model and run it
for rigid bodies case, only the spider rigid are removed and joint is created using contrained joint and contrained extra node set
Deformable bodies results
Rigid bodies results
Conclusion:
Defining and creation of joints were demonstrated for both rigid and Deformable bodies. The major difference between them is the association of extra nodes to the respective parts in case of of rigid bodies and creation of CNRB with the extra nodes in case of Deformable bodeis. The boundary conditions have to be changed accordingly in both cases as per the case.