week-11 Joint creation and Demonstration
AIM:
To defining and creation of joints were demonstrated for both rigid and deformable bodies.
THEORY:
A joint is a section or a sub-assembly used to connect two parts with a relative motion between the connected parts. The joint can either be a fully constrained and partial constrained which means free movement.
The demonstration presented here comprises of creation and working of joints between simple parts and these can be extended to complex parts although the principle is same.
PROCEDURE:
For Case-1(RIGID BODIES):
Defining the joints using Nodes:
1.The joint is defined using the extra nodes associated with the parts using contrained joint.
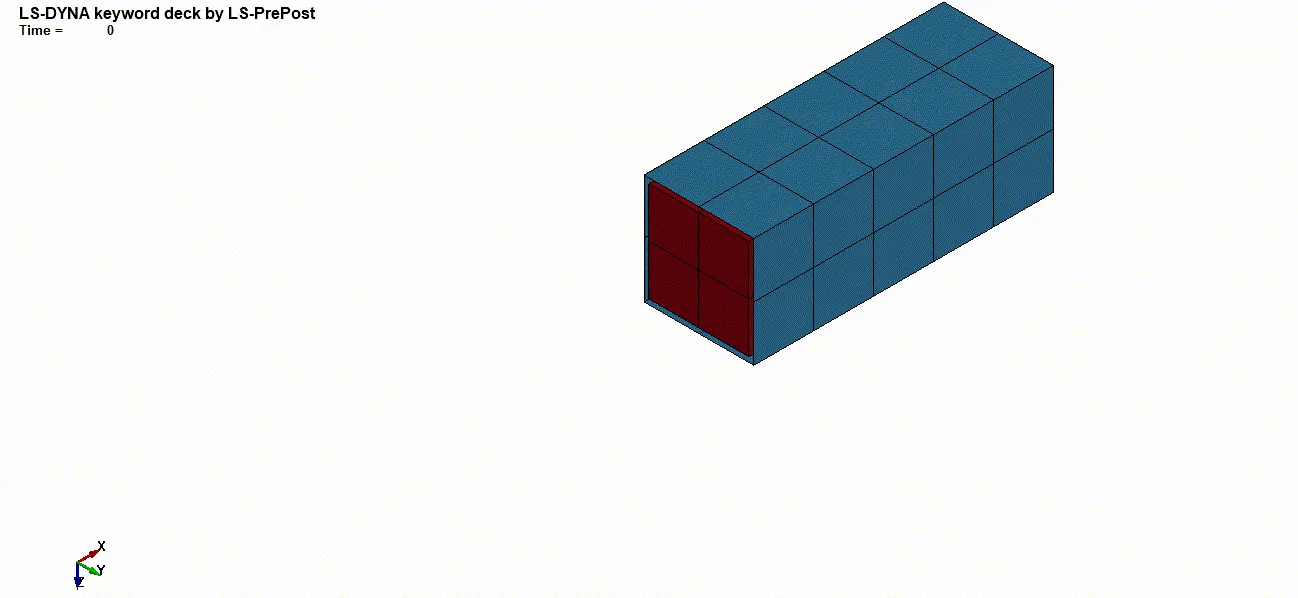
1.Translational Joint:
The relative motion between bodies has only degree of freedon along the axial direction. Three set of node is required to define this joint. Where two of them allows motion and one set of rotaional degree of freedom.
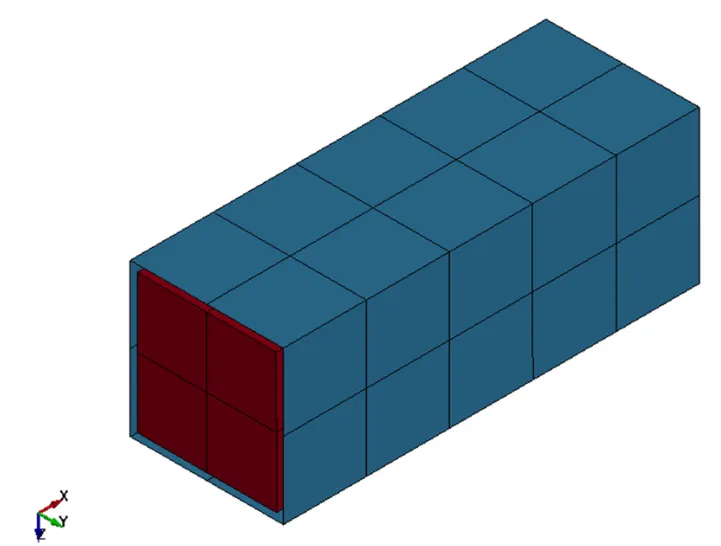
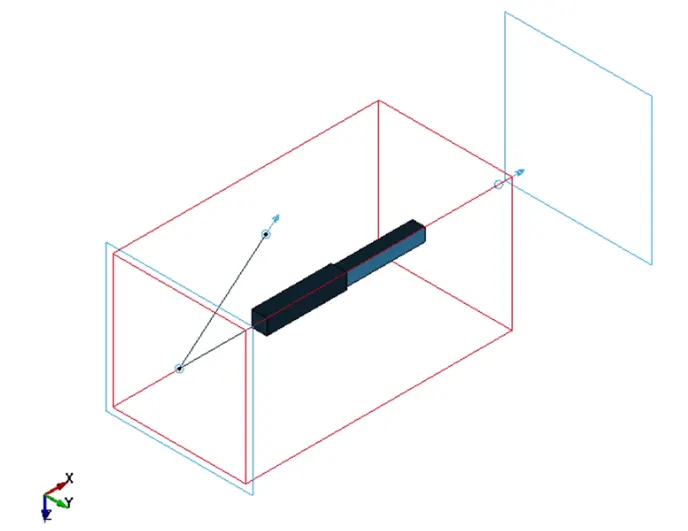
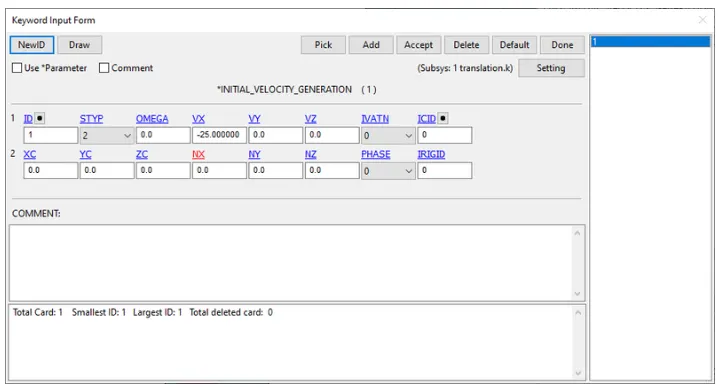
The boundary conditoion is used where a rigid card was used the shell was fixed using the MAT20 rigid material keyword. The solid tube was given using Initial velocity generation keyword for the part in -veX direction.
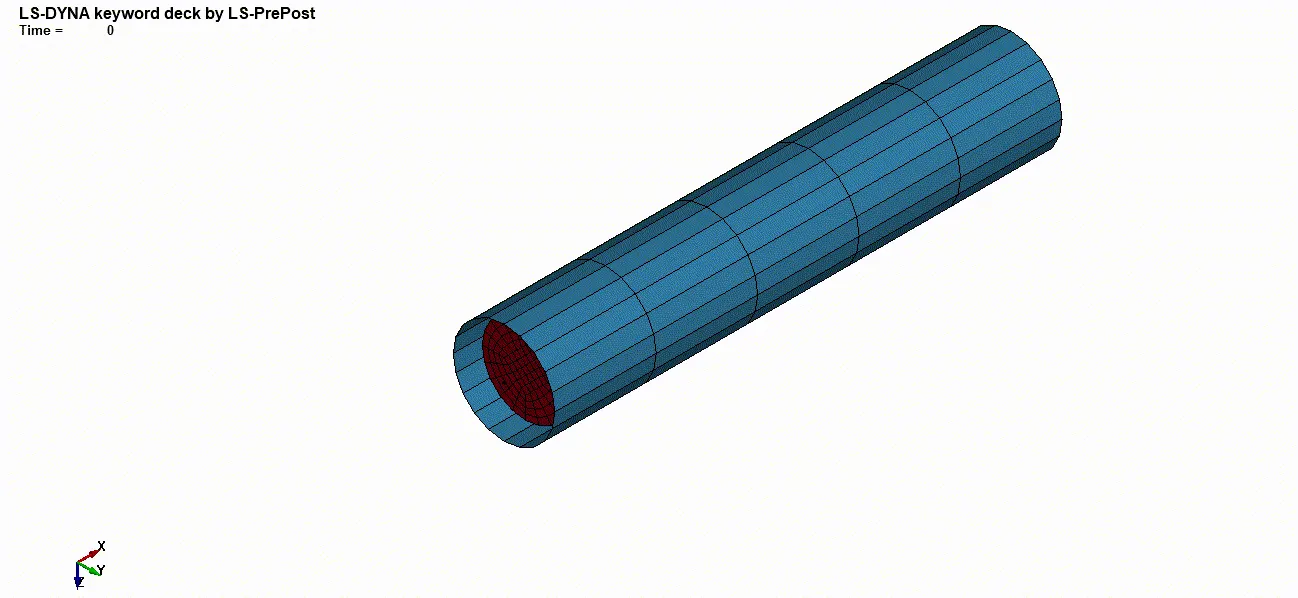
2.Cylindrical Joint:
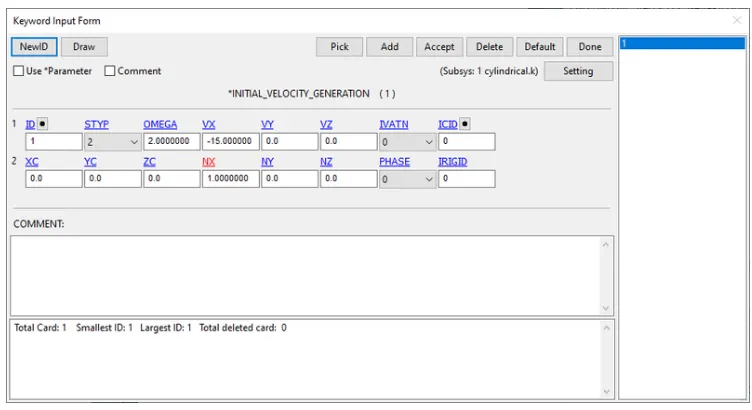
The relative motion between bodies has two degrees of freedom one axial and one rotaiional degree of freedom. Only two nodes are required to define the cylindrical joint for rotational degree of freedom and axial movement can be provided using the velocity rigid motion keyword.
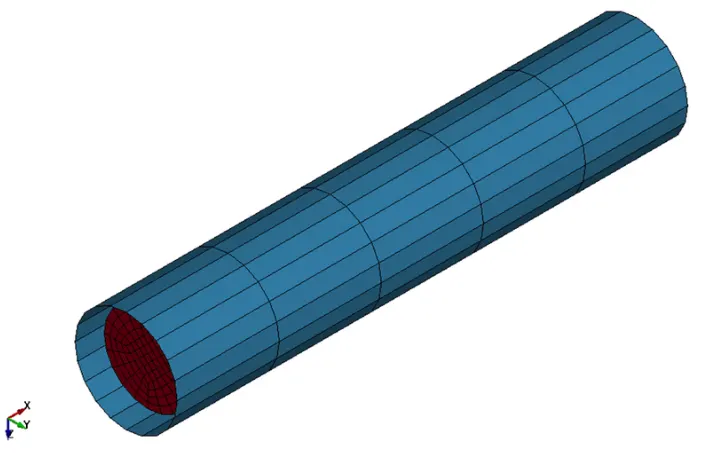
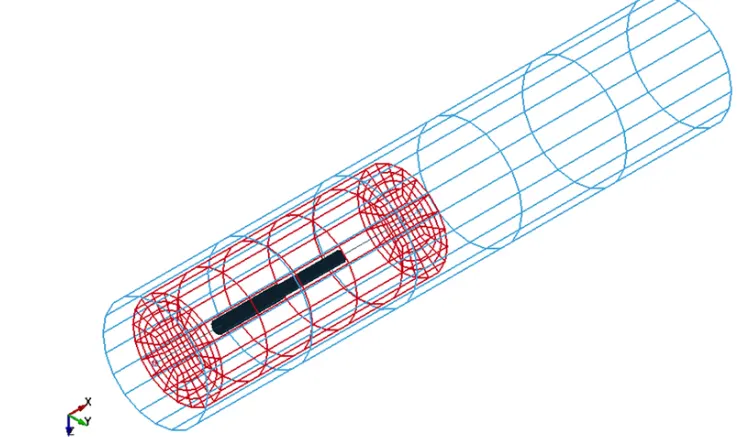
The boundary condition used where a rigid card was used the shell is fixed using the MAT20 material keyword. The solid tube was given using initial velocity generation keyword for the part in -ve X direction and rotational velocity about the X-direction.
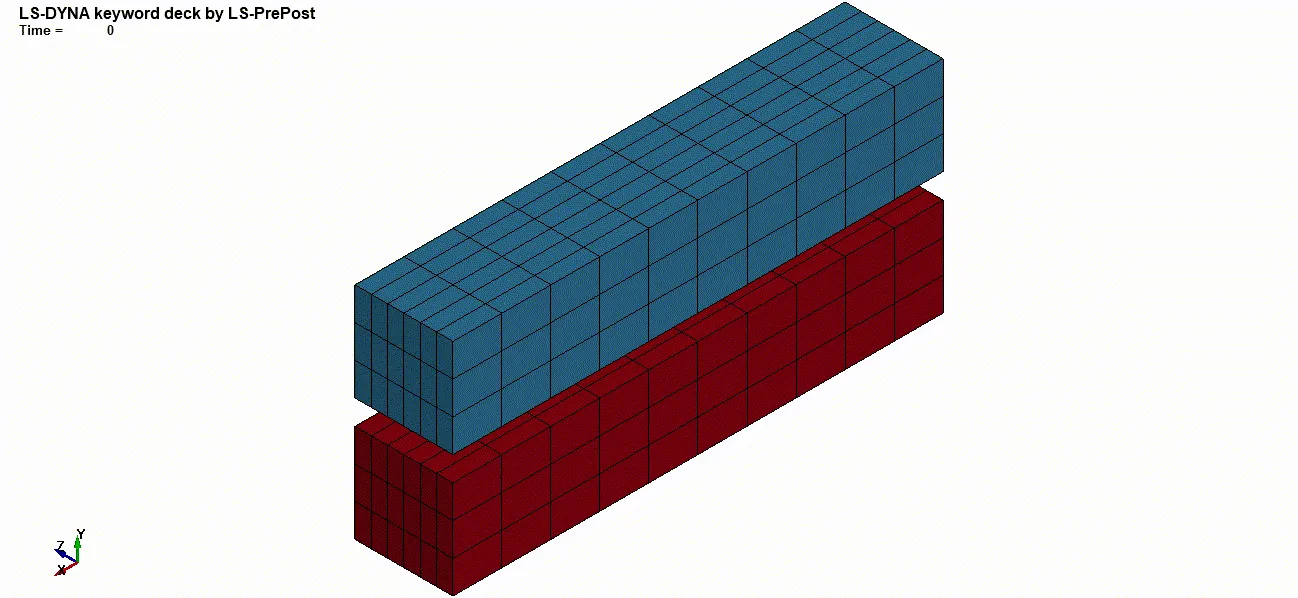
3.Revolute Joint:
This joint is also known as pin joint. The relative motion between bodies is restricted to rotaions abou the axis formed by pair of co-incident nodes.
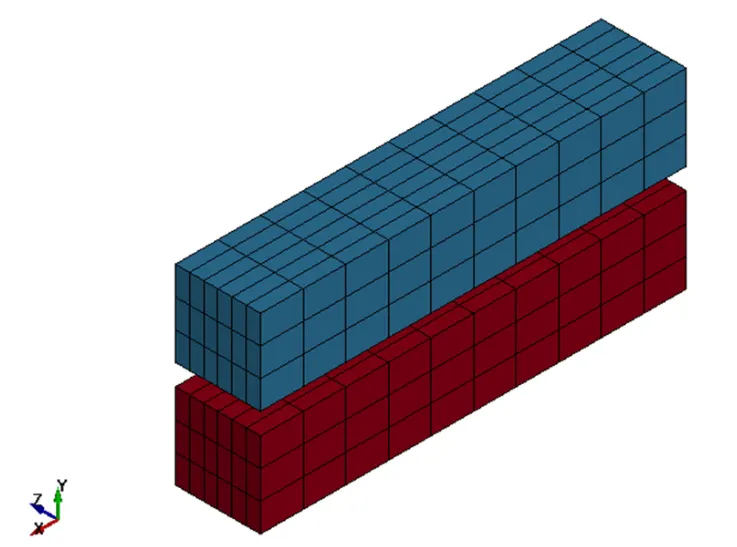
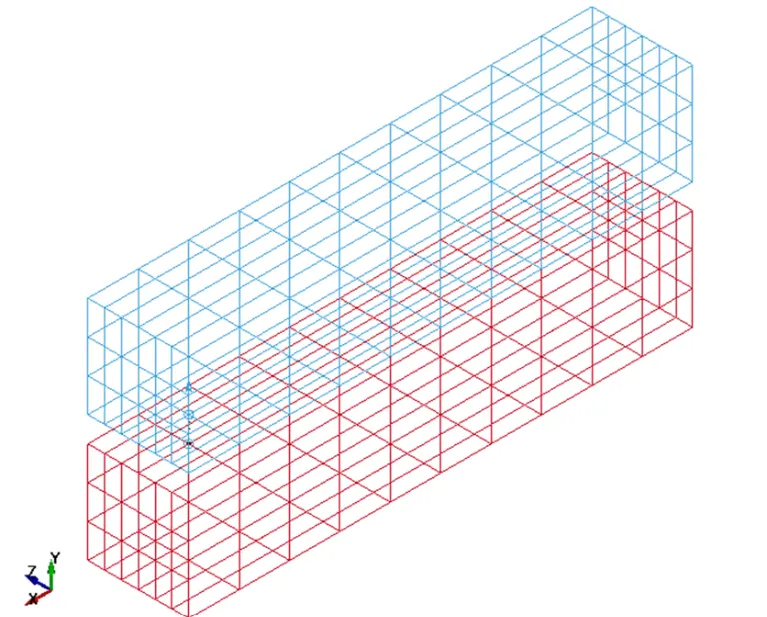
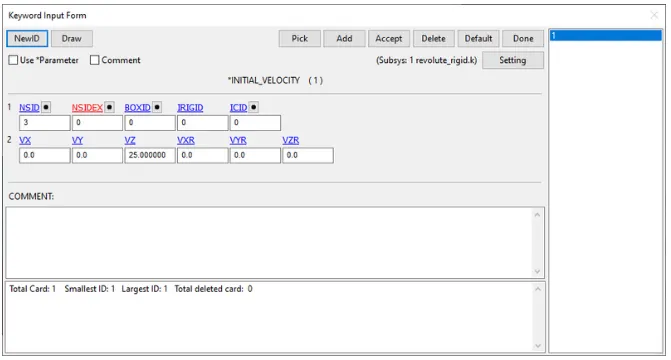
The boundary condition is used where a rigid card was used the bar was fixed using the MAT20 rigid material keyword. A intial velocity card was defined after creating a nodeset consisting of edge nodes to impart the velocity to the moving bar.
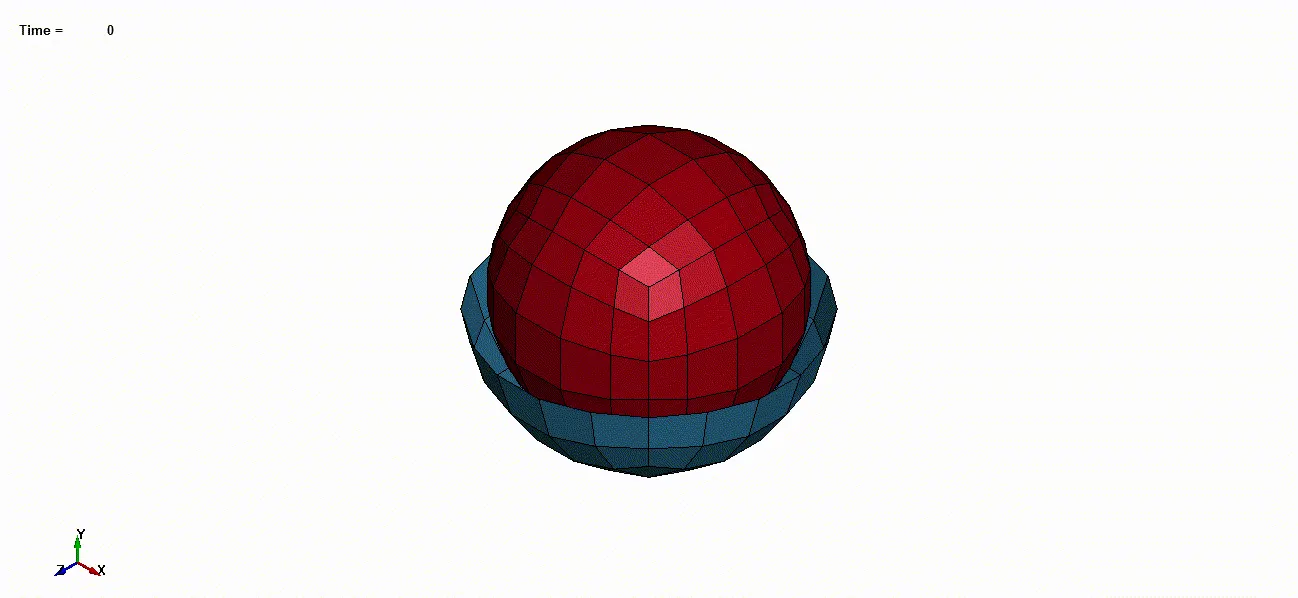
4.Spherical Joint:
The relative motion between two bodies is free in all rotational degree of freedom but constrained in translational degree of freedom.
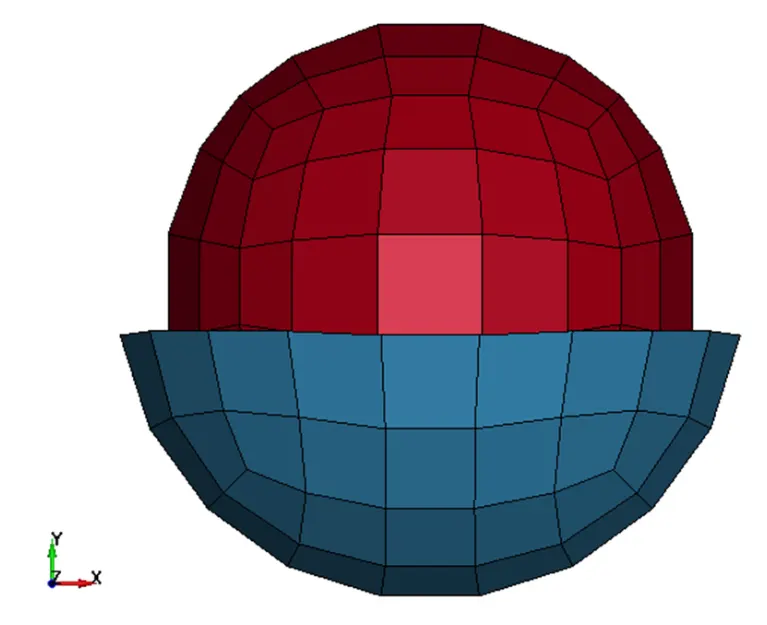
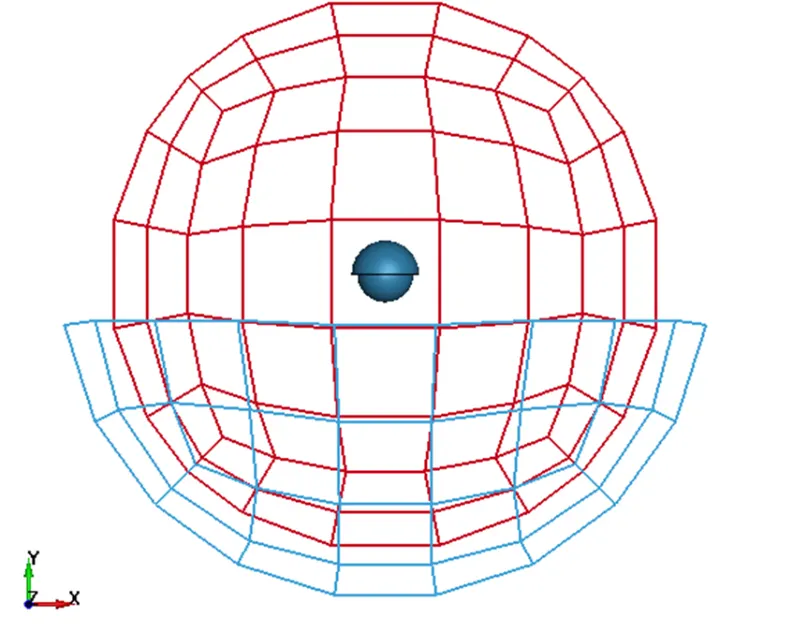
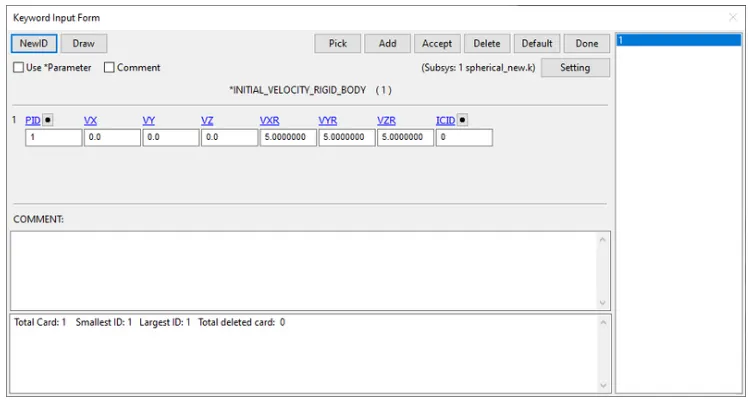
The boundary condition is used where a rigid card, the shell was fixed using the MAT20 rigid material keyword. The solidsphere was given rotational velocity about x,y,z direction.
For Case-2(DEFROMABLE BODIES):
Defining the joints using Constrained Nodal Rigid Body:
Constrained nodal rigid body are created from Entity Creation tab, Selectin all the nodes of the part and the additional node created for defining the joint.
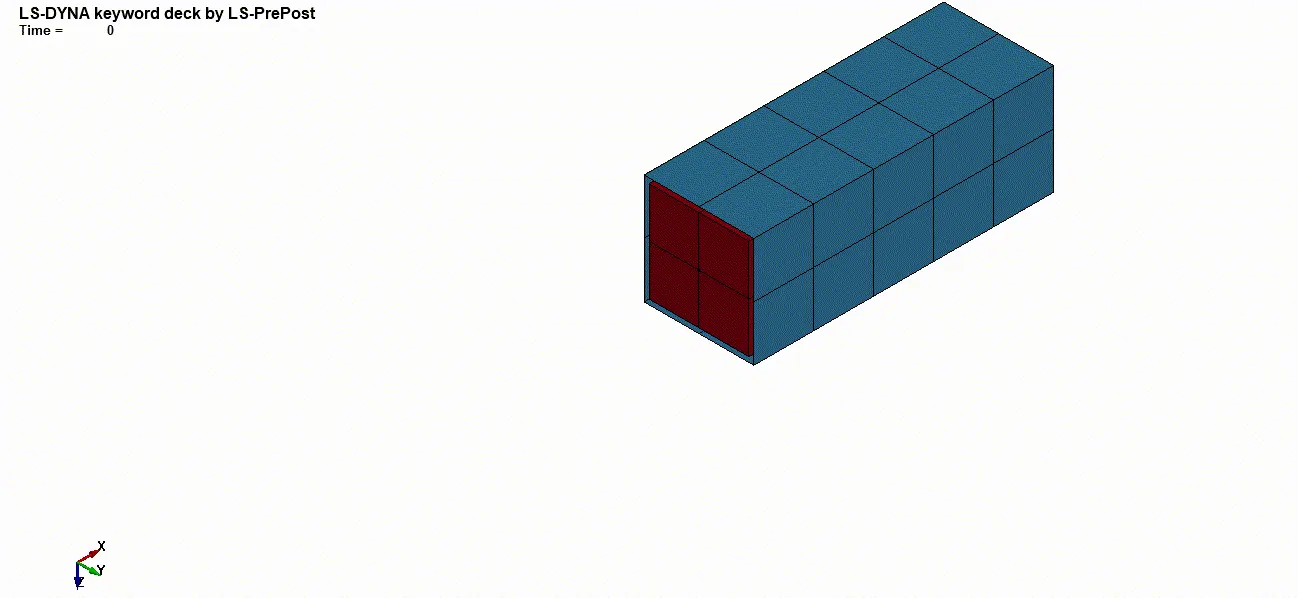
1.Translational Joint:
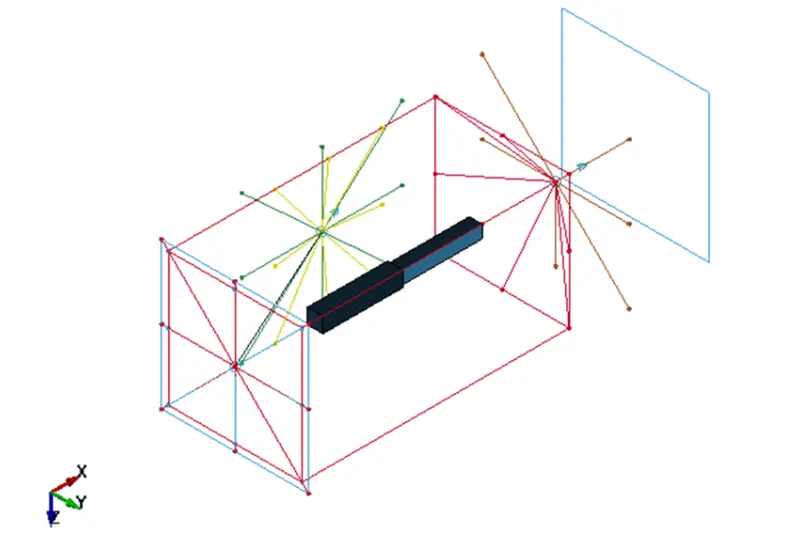
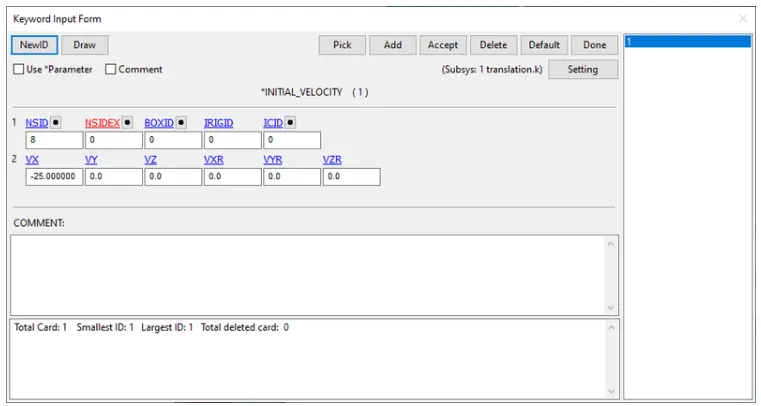
The boundary conditions Spc_set card is used to fix the hollow shell nodes and initial velocity card was used to impart the velocity to solid tube using node set.
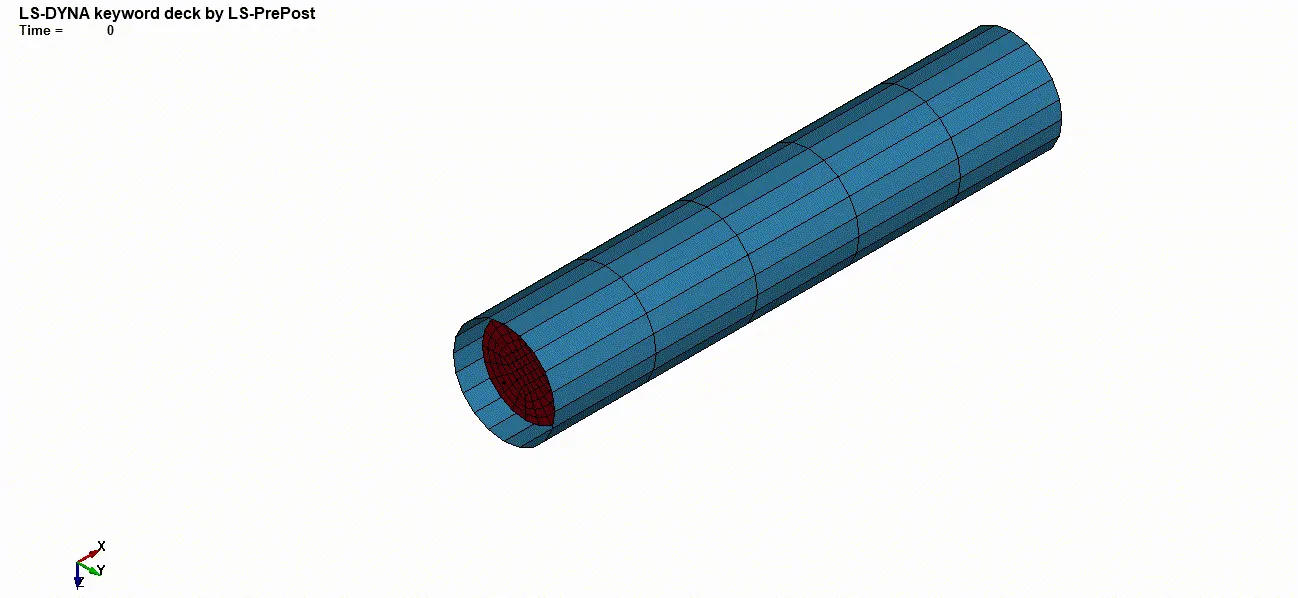
2.Cylindrical Joint: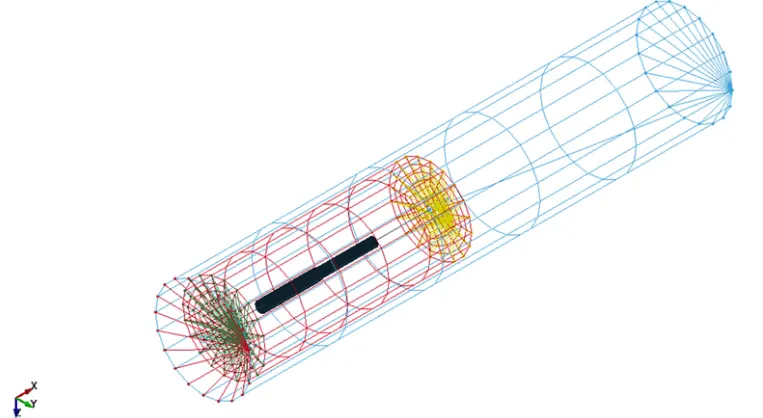
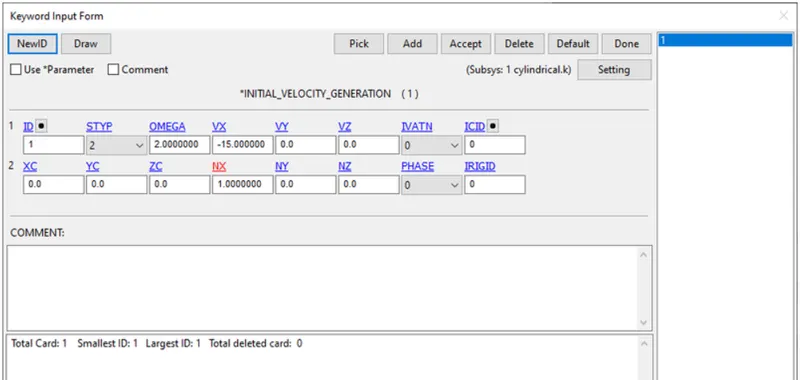
The boundary condition A Spc_set card was used to fix the hollow shell nodes and velocity generation card was used to impart the velocity to solid tube using nodeset.
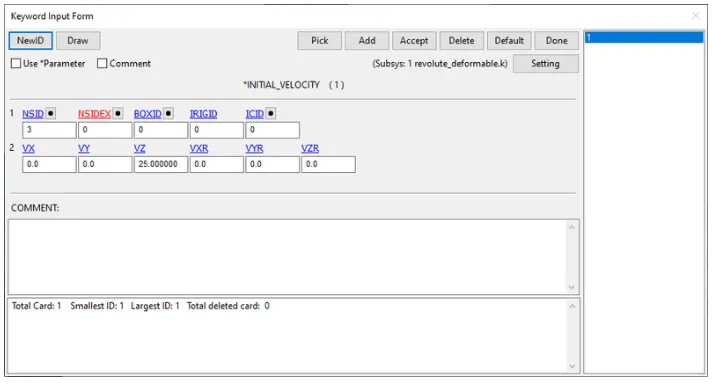
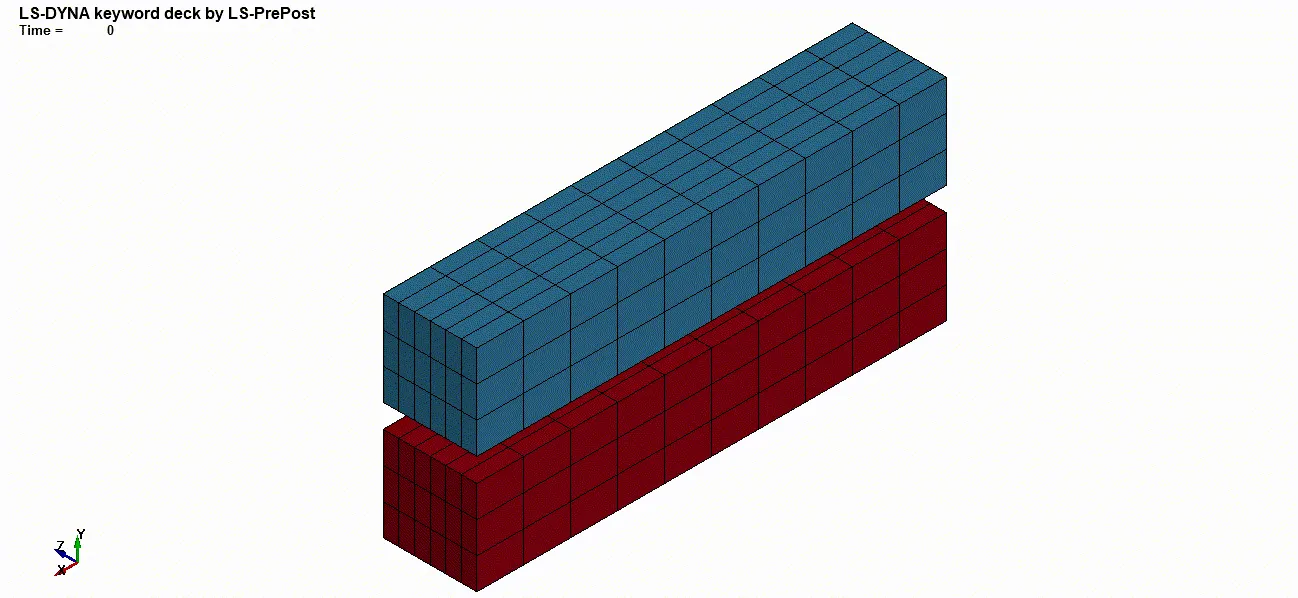
3.Revolute Joint:
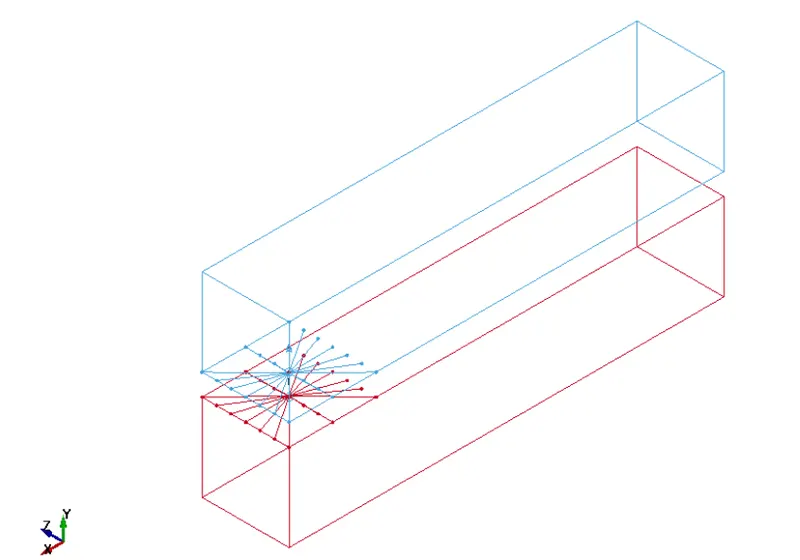
The boundary condition a Spc_set card was used to fix the solid nodes and intial velocity card is used to impart the velocity to the edge nodes using nodeset.
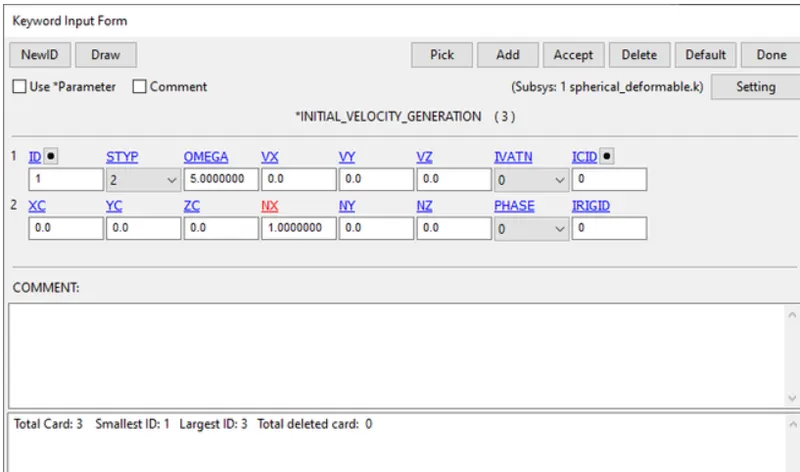
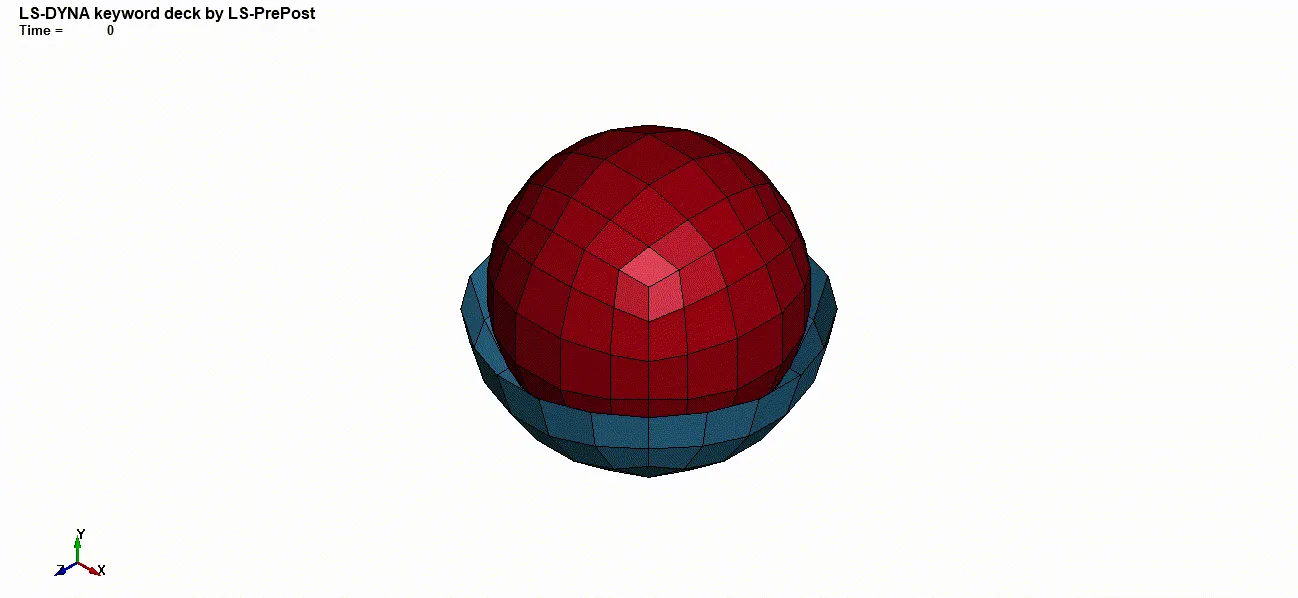
4.Spherical Joint:
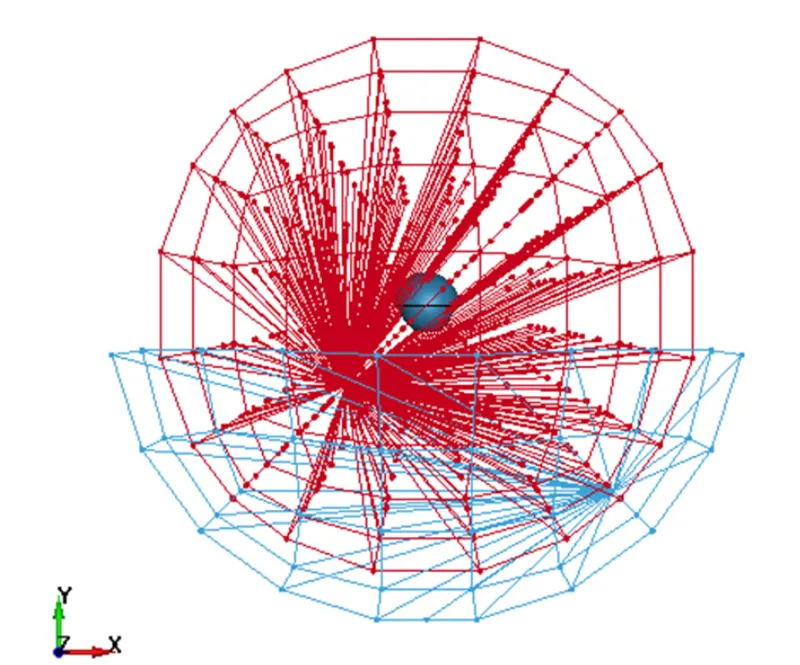
The boundary conditions a Spc_set card was used to fix the shell nodes, three initial velocity generation cards are used to impart the rotational velocity in each of the directions for the solid sphere as part.
Boundary conditions:
1.For the joints in case of rigid bodies, partial boundary conditions are imported using Mat_Rigid material card.
2.Velocity conditions are used to define relative motion of the moving parts.
3.Control termination keyword is used to denote the endtime of the simulation.
OUTPUT:
For Case-1(RIGID BODIES):
1.Translational Joint:
2.Cylindrical Joint:
3.Revolute Joint:
4.Spherical Joint:
For Case-2(Deformable Bodies):
1.Translational Joint:
2.Cylindrical Joint:
3.Revolute Joint:
4.Sphercial Joint:
RESULT:
Thus thedefining and creation of joints were demonstrated for both rigid and deformable bodies are performed sucessfully.