Week-11 Challenge: Braking
SOLUTION[1]: For a defined driving cycle, calculating the energy required for braking.
Drive cycle :-
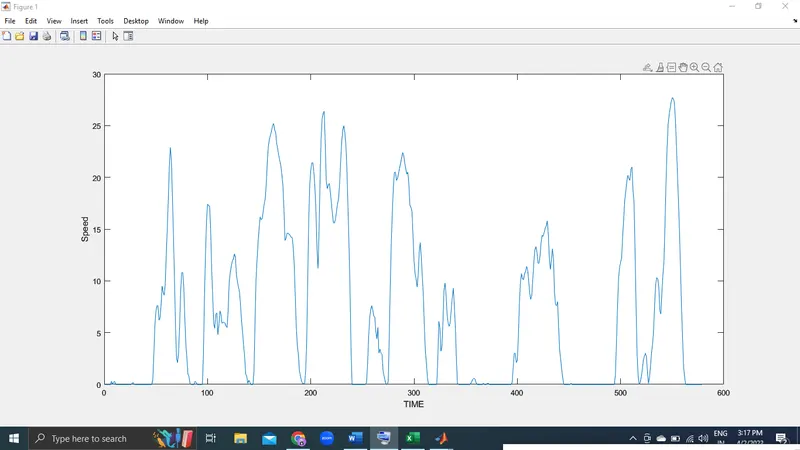
A driving cycle is a series of data points representing the speed of a vehicle versus time. Driving cycles are produced by different countries and organizations to assess the performance of vehicles in various ways, as for instance fuel consumption, electric vehicle autonomy and polluting emissions.
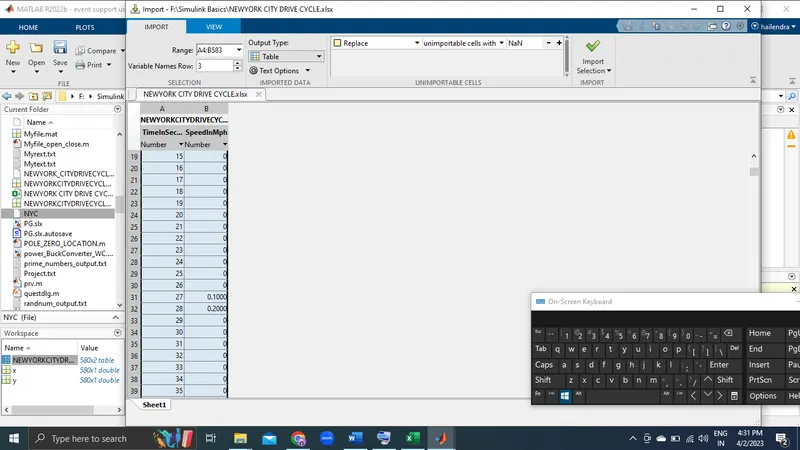
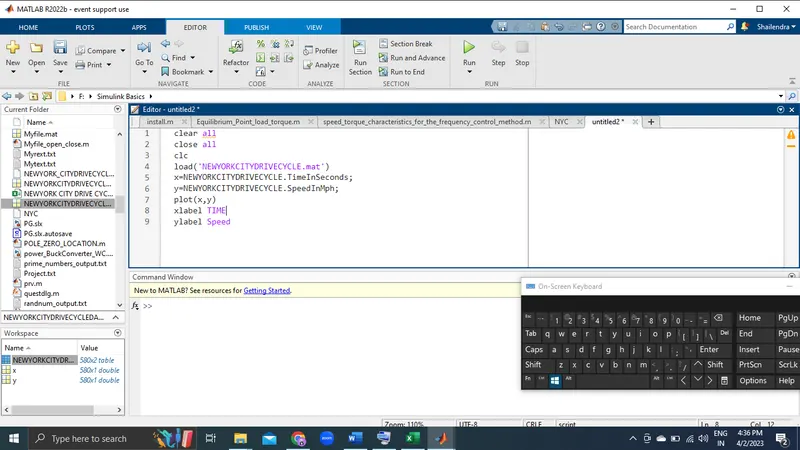
Here have taken the drive cycle data from a website the link is attached below. We have used NEW YORK CITY DRIVE CYCLE for our calculation.https://www.epa.gov/sites/default/files/2015-10/nycccol.txt
Parameters
M : Mass : 800kg
Vf : Final velocity : Here the minimum velocity obtained after braking is considered as final velocity.
Vi : Initial velocity : Here the maximum velocity obtained before braking is considered as initial velocity.
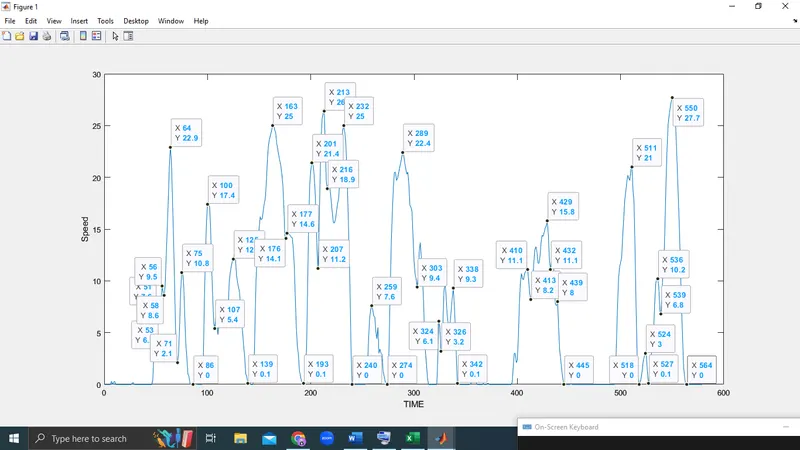
22 decelerations were made during this driving cycle, So 22 braking energy is to be calculated and sum it up to get the Total braking energy.
Braking energy Formula
Braking energy =(1/2)*M*(Vf-Vi)^2
Miles per hour To meter per sec conversion
7.6 mph to 6.2 mph=3.3mps to 2.77 mps
Braking energy =(1/2)*M*(Vf-Vi)^2=0.112KJ
9.5 mph to 8.6 mph = 4.24 mps to 3.84 mps
Braking energy =(1/2)*M*(Vf-Vi)^2=0.064 KJ
22.9 mph to 2.1 mph =10.3 mps to 0.93 mps
Braking energy =(1/2)*M*(Vf-Vi)^2=35.11 KJ
10.8 mph to 0 mph =4.28 mps to 0 mps
Braking energy =(1/2)*M*(Vf-Vi)^2=73.24 KJ
17.4 mph to 5.4 mph =7.77 mps to 2.41 mps
Braking energy =(1/2)*M*(Vf-Vi)^2=11.49 KJ
12.1 mph to 0.1 mph =5.4 mps to 0.04 mps
Braking energy =(1/2)*M*(Vf-Vi)^2=11.49 KJ
25 mph to 14.1 mph =11.17 mps to 6.3 mps
Braking energy =(1/2)*M*(Vf-Vi)^2=9.4KJ
14.6 mph to 0 mph =6.52 mps to 0 mps
Braking energy =(1/2)*M*(Vf-Vi)^2=17.00KJ
21.4 mph to 11.2 mph =9.5 mps to 5 mps
Braking energy =(1/2)*M*(Vf-Vi)^2=8.1 KJ
26.4 mph to 18.9 mph = 11.8 mps to 8.4 mps
Braking energy =(1/2)*M*(Vf-Vi)^2=4.624 KJ
25 mph to 0 mph =11.17 mps to 0 mps
Braking energy =(1/2)*M*(Vf-Vi)^2=49.9 KJ
7.6 mph to o mph =3.3 mps to 0 mps
Braking energy =(1/2)*M*(Vf-Vi)^2=4.35 KJ
22 mph to 9.4 mph =9.8 mps to 4.2 mps
Braking energy =(1/2)*M*(Vf-Vi)^2=12.5 KJ
6.1 mph to 3.2 mph =2.7 mps to 1.4 mps
Braking energy =(1/2)*M*(Vf-Vi)^2=0.676 KJ
9.3 mph to 0 mph =4.1 mps to 0 mps
Braking energy =(1/2)*M*(Vf-Vi)^2=6.7 KJ
11.1 mph to 8.2 mph =4.9 mps to 3.66 mps
Braking energy =(1/2)*M*(Vf-Vi)^2=0.615 KJ
15.8 mph to 11.1 mph =7.1 mps to 4.9 mps
Braking energy =(1/2)*M*(Vf-Vi)^2=1.93 KJ
8.0 mph to 0 mph =3.5 mps to 0 mps
Braking energy =(1/2)*M*(Vf-Vi)^2=4.9 KJ
21 mph to 0 mph =9.3 mps to 0 mps
Braking energy =(1/2)*M*(Vf-Vi)^2=34.5 KJ
3 mph to 0.1 mph =1.3 mps to 0.04 mps
Braking energy =(1/2)*M*(Vf-Vi)^2=0.635 KJ
10.2 mph to 6.8 mph =4.5 mps to 3 mps
Braking energy =(1/2)*M*(Vf-Vi)^2=0.9 KJ
22.7 mph to 0 mph =10.1 mps to 0 mps
Braking energy =(1/2)*M*(Vf-Vi)^2=40.8 KJ
Total energy is equal to summation of all above individual energy =329.03 KJ
SOLUTION[2]:
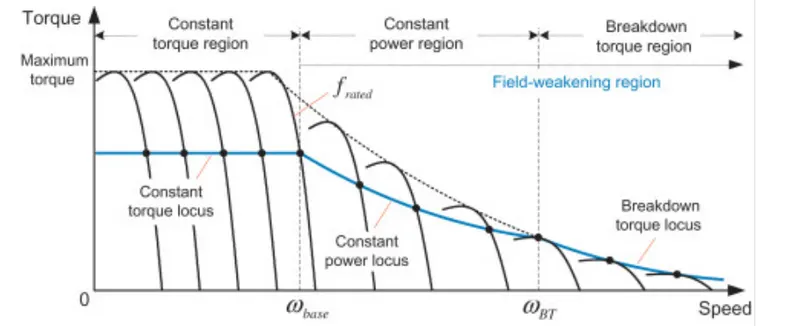
From above curve , we see the three region first one is constant torque region , constant second is power region , third is breakdown torque region. So at the start of motor, the motor ahieved the peak torque till the moment at it reaches the certain speed and after that it start rapidly drop. The reason of dropping the torque of motor because the motor shaft reaching the critical speed.The area motor achieve the peak torque and constant is called constant torque region.
The region where the torque reduce is known as constant power regionas the power generated by motor will be its peak.so the torque produced at constant power region is low this is reason where the motor does not produced braking torque in this region.
Co-ordianation in electric brake and mechanical brake :There are two types of braking is used electric and mechanical braking system written below,
[1]Electric braking(Regenerative) : In electric braking, the winding of the motor is used to produce the braking torque these braking torque developed during braking operation.These operation opposes the rotation of shaft and it doing by changing the connection of motor.The regenerative brake are nothing but the application of electric brakes which convert the kinetic or frictional energy during braking into electric energy which is feed back to the battery
[2]Mechanical braking : In mechanical braking ,the frictional force produce between rotating part of wheel and brake drum produce require braking to achieve these braking various mechanical part are use such as brake lining and brake drum.
The brakes are again divided on the basis of Brake control strategies :Series & Parallel
In series brakes the brakes are applied one after the other it may be regenerative first and the mechanical or vice versa , they are applied only one at a time we use such type of brake control strategies where we are required for comfortable and efficient braking. In parallel braking strategy both the brakes are applied at a time.
As per the system developed by Nissan leaf Electric Driven Intelligent Brake (EDIB) the below graphs are been shown where the coordination of brake system is been plotted
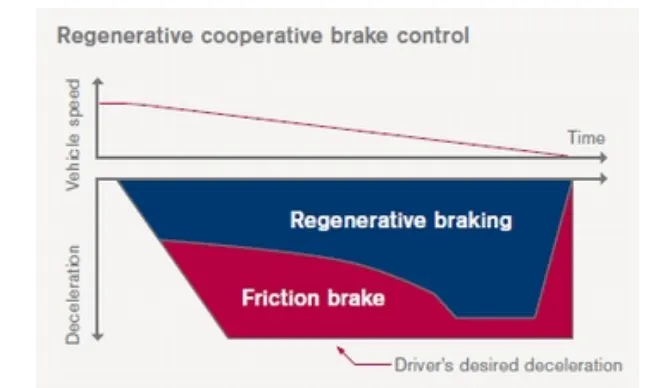
In an Electric vehicle, at start of the vehicle the friction brake gives the 60 % contribution and regenrative brake give 40 % contribution and speed of vehicle start reduce. But as the speed of vehicle is decreasing the percentage of brake ratio is changes and the regenerative brake are applied in greater ratio as compared to mechanical brakes. As we know the braking torque is very low at high speed at start so friction braking apply brake and slow down the speed of vehicle and after that the regenrative braking in which motor act as generator and supply toward the source by producing negative torque.
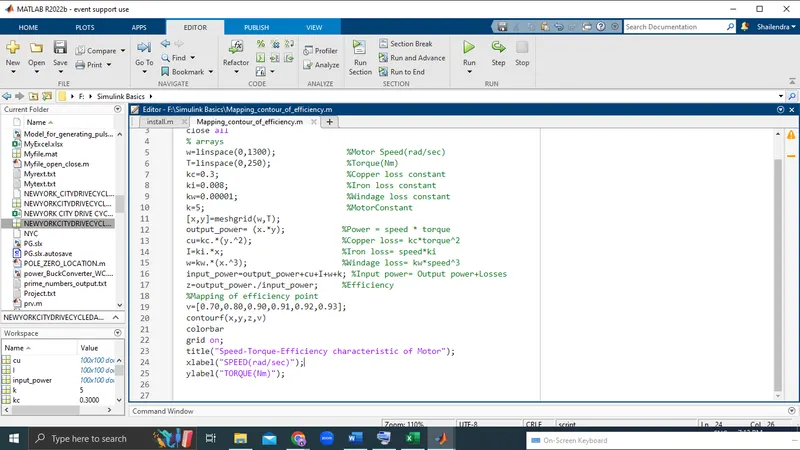
SOLUTION[3]:MATLAB program which plots contour of given motor speed, torque and efficiency values
RESULT
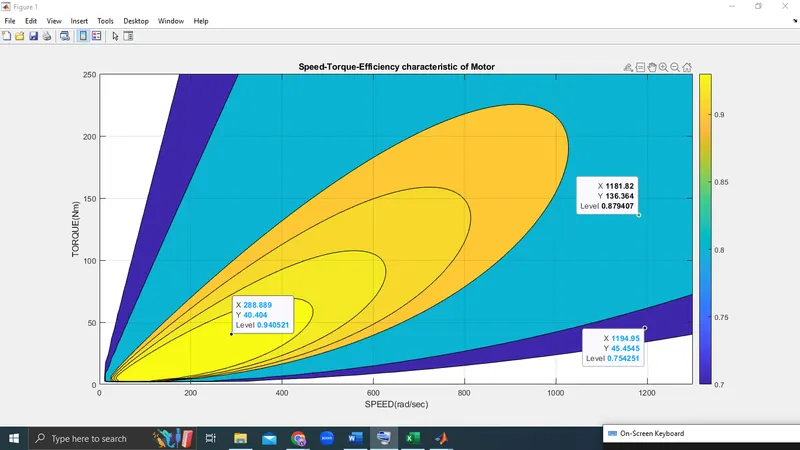
From the plot it can be observed that the speed and torque varies as efficiency increase. This is occur due to motor losses. As we see the drak blue region represent the 75% efficiency and the yellow region represnt 94% efficiency. Ex.- when it is at 75 % efficiency the torque reaches its peak value 250 Nm. it means the when the vehicle is at very low spweed the torque decrease as the speed increase for same efficviency and at 94% efficiency the speed and torque required much less compared to an efficiency 75%. Greater the motor efficiency lower speed torque combination is required to overcome the motor losses.