Week-11 Challenge: Braking
1.ANS:
BRAKING:
Braking is the process of controlling the velocity of an object by inhibiting its motion. An object in motion
possesses kinetic energy and to bring the object to a stop this kinetic energy must be removed. Removing the kinetic
energy can be accomplished by dissipating the energy to the atmosphere through friction or by converting it into
another form of energy. The most common type of braking is a mechanical brake which inhibits motion through friction
brake pads. A mechanical brake applies a friction force to convert the kinetic energy of the vehicle into thermal
energy which then dissipates into the atmosphere. Braking systems which don't use friction are referred to
as regenerative braking systems (RBSs). In RBSs, the kinetic energy is converted into other forms of useful energy, which
can be stored for later use, increasing fuel efficiency.
Braking energy :- K= 1/2mv^2
where m = mass of the veichle
v = speed of the starting of braking
if the speed of the is changes from intial energy(vi) to final velocity(vf) then the requried braking energy is given by
Braking energy requried = 1/2m(vi^2-vf^2)
Indian Drive Cycle:
In India, 85% of veichles are having engine capacity less than 125cc, Whereas in Europe (35%), Japan (31%), and US (7%).
1.Initial cost and fuel economy are highest priority.
2.More a uitility and family oriented vehicle.
3.Small entreprenuers and formers conduct their business carrying loads.
4. very limited usage of sport
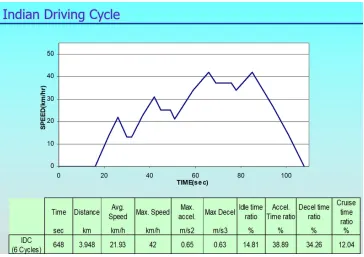
indian drive cycle is formulated after collecting real world data from major cites representing actual driving pattern.
The energy requried for bracking:-
Here taken the IDC in excel formate and obtanied the braking energy at different speed and time intervels.
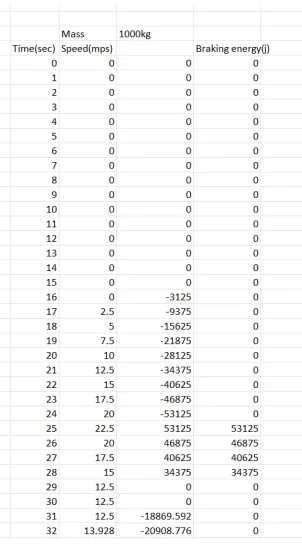
plotted the above data excel
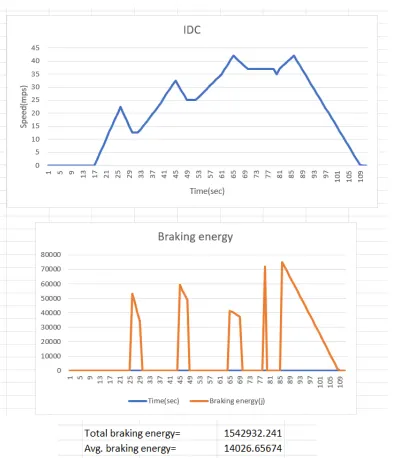
Energy units in joules
Hence defined driving cycle calculated the energy required for braking using excel and ratio attched the excel file
2.ANS:
Why electric motor can’t develop braking torque at high speed similar to starting?
As you can see, an Induction motor does not generate max torque at zero speed but at certain speed much like a
internal combustion engine.
But the thing is, these characteristics are obtained when we run the motor directly from a rated supply. Fortunately, we
do not run motors directly from supply. We use Motor Controllers in-between the motor and the supply.
Motor Controllers provide lots of advantages over running from from direct supply, Speed Control, regenerative
breaking, smooth starting to name a few.
Motor controllers emloys one of several control techniques like PWM, space vector modulation, variable frequency etc
etc to control motor torque, speed, power output. They can also make a motor produce max torque at any speed below
rated speed.
As evident from the graph, maximum torque output can be maintained upto the rated speed. When rated speed is
reached, motor hits it's power limit, so further increase in speed requires torque to be decreased.
How electric and mechanical brakes are coordinated?
Electrical brakes:
Regenerative braking takes place whenever the speed of the motor exceeds the synchronous speed. This baking
method is called regenerative baking because here the motor works as generator and supply itself is given power from
the load, i.e. motors.
Mechanical brakes:
The mechanical braking system powers the hand brake or emergency brake. It is the type of braking system in which
the brake force applied on the brake pedal is carried to the final brake drum or disc rotor by the various mechanical
linkages like cylindrical rods, fulcrums, springs etc. In order to stop the vehicle. It is also known as friction braking.
There are two types of Brake Control Statergies
1. Series brake control:
Applying the barkes one after another between regenerating and mechanical braking at required ratios.
2. Parallel brake control:
Both the brakes regnerative and mechanical brake applied at the same time.
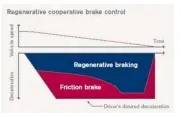
Electric Driven Intelligent Brake(EDIB):
EDIB (Electric Driven Intelligent Brake) controls the regenerative brake and friction brake to support both of these
requirements. Further, it also controls the reactive force from the pedal in order to unify the feeling when stepping down
on the pedal and the sense of deceleration.
3.ANS:
Taken data
Max. Motor Speed(W) = 1000 rad/s
Max. Torque (T) = 250m/s
Copper loss contant (Kc) = 0.2
Iron loss constant (Ki) = 0.008
Windage loss constant(Kw) = 0.00001
Contant loss = 20
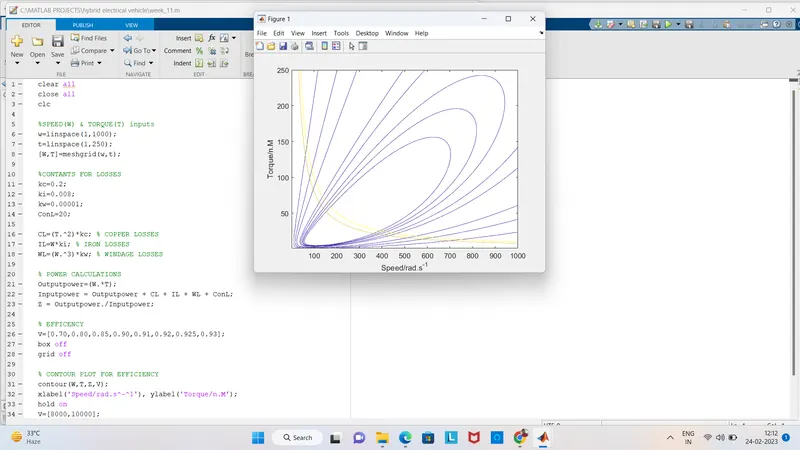
A MATLAB program which plots contour of given motor speed, torque and efficiency values
clear all
close all
clc
%SPEED(W) & TORQUE(T) inputs
w=linspace(1,1000);
t=linspace(1,250);
[W,T]=meshgrid(w,t);
%CONTANTS FOR LOSSES
kc=0.2;
ki=0.008;
kw=0.00001;
ConL=20;
CL=(T.^2)*kc; % COPPER LOSSES
IL=W*ki; % IRON LOSSES
WL=(W.^3)*kw; % WINDAGE LOSSES
% POWER CALCULATIONS
Outputpower=(W.*T);
Inputpower = Outputpower + CL + IL + WL + ConL;
Z = Outputpower./Inputpower;
% EFFICENCY
V=[0.70,0.80,0.85,0.90,0.91,0.92,0.925,0.93];
box off
grid off
% CONTOUR PLOT FOR EFFICIENCY
contour(W,T,Z,V);
xlabel('Speed/rad.s^-^1'), ylabel('Torque/n.M');
hold on
V=[8000,10000];
% CONTOUR PLOT FOR OUTPUT POWER
contour(W,T,Outputpower,v);
Results:-