Week-11 Challenge: Braking
1. For a defined driving cycle, calculate the energy required for braking.
STUDY 1:
Driving Cycle: A driving cycle are a set of vehicle speed points versus time, it is used to calculate the fuel consumption of a vehicle, which is later on is compared with different vehicles. Main use of driving cycle are as follows:
- To assess the performance of a vehicle (fuel economy, emission tests)
- To analyze battery state and energy consumption in Electric Vehicles
- To simulate vehicle model prior to the actual development
Braking: Road vehicles involves the conversion of kinetic energy into thermal energy (heat). When stepping on the brakes, the driver commands a stopping force several times as powerful as the force that puts the car in motion and dissipates the associated kinetic energy as heat.
The process of braking follows the law of conservation of energy i.e. Energy cannot be created or destroyed it can only be converted into another form.
`E(kinetic) = 1/2 * m * v^2`
where,
m = mass of the vehicle in Kg
v = velocity of the vehicle in m/s
E(kinetic) = Kinetic energy in KJ
In our case, velocity will be (V-Vi) where, V is the speed of the vehicle, Vi the speed of the vehicle which is slow down or brought down to rest.
%Matlab Code for calculating Energy required for Braking

clear all
close all
clc
%Read the Drive Cycle data from given .xls file
DC=xlsread('VelocityandTime.xlsx');
T=DC(:,1); %Time in seconds
S=DC(:,2); %Speed in Kmph
%other data
m = 1000; %mass in Kg
V=S./3.6; %Speed in m/s
%To create an Array to store values for Deceleration & Braking Energy
Z=length(T);
deceleration=zeros(1,Z);
acceleration=zeros(1,Z);
BE=zeros(1,Z);
AE=zeros(1,Z);
for i=1:(length(T)-1)
if V(i)>V(i+1)
BE(i)=0.5*(V(i)-V(i+1))^2; %Braking Energy in Joules

speed_decrease(i)=V(i+1)-V(i);
deceleration(i)=speed_decrease(i);
%since Time Delta is 1s Acc/dec=V/T.m/s^2, where T=1
end

if V(i)<V(i+1)
AE(i)=0.5*m*(V(i)-V(i+1))^2; %Accelerating Energy in Joules

speed_increase(i)=V(i+1)-V(i);
acceleration(i)=speed_increase(i);
end

end
%Total Braking Energy in KJ
B_E=(sum(BE)/1000);
%Total Acceleration Energy in KJ
A_E=(sum(AE)/1000);
%Plotting Curves
figure(1)
subplot(2,1,1)
plot(T,S,'color','b')
xlabel('Time(s)')
ylabel('Speed(Kmph)')
title('Drive Cycle')
subplot(2,1,2)
plot(T,deceleration,'color','r')
hold on
plot(T,acceleration,'color','g')
xlabel('Time(s)')
ylabel('Acc/Dec(m/s^2)')
title('Acceleration-Deceleration')
figure(2)
plot(T,BE)
hold on
plot(T,AE)
xlabel('Time(s)')
ylabel('Energy(J)')
title('Energy consumed during Braking & required for acelerating throughout Drive Cycle')
legend('Braking Energy','Accelerating Energy')
fprintf('Total Energy consumed during Braking is %f KJ',B_E)
disp(' ')
fprintf('Total Energy consumed during Acceleration is %f KJ',A_E)
For Driving cycle an Excel sheet is imported:
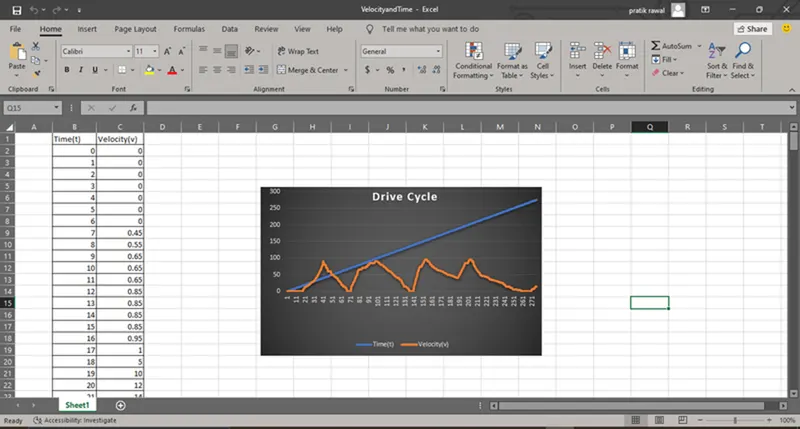
Code Explanation:
-- An excel sheet name 'VelocityandTime.xls' is been imported into Matlab workspace and the Time and Velocity values are inserted into Array.
-- All the values like mass, velocity are been defined first in the code, Velocity value is converted into m/s.
-- A for loop for the length of time value is been created. The variable name length has been defined.
-- Acceleration and Deceleration values are been calculated inside a for loop.
-- Total energy is calculated.
-- All the required input has been mentioned for plotting graphs.
Results:
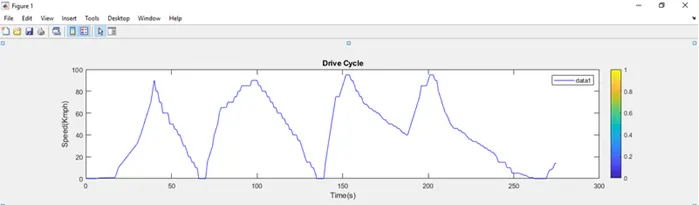
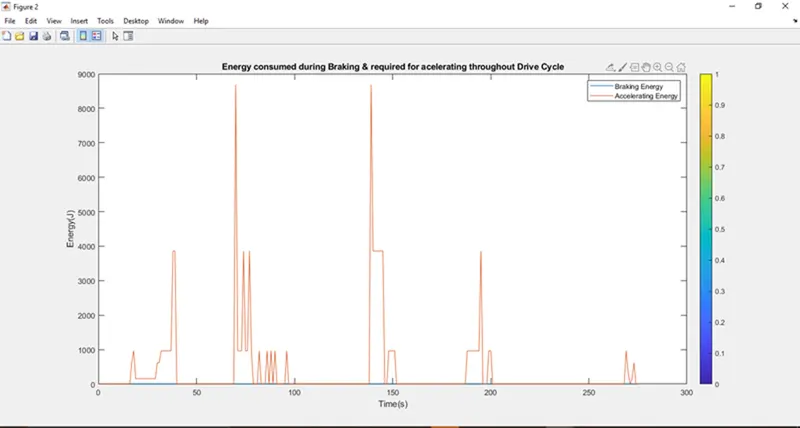
- We can observe after the simulation is completed the two values Total energy required in braking 0.066975 KJ whereas, Total Energy consumed during Acceleration is 95.342400 KJ.
- We can also observe the driving cycle is same as the excel file which was imported.
- We can also observe the Energy consumed during braking as well as while accelerating red color is for Acceleration whereas, the blue color is for braking.
2.Why electric motor can’t develop braking torque at high speed similar to starting? How electric and mechanical brakes are coordinated?
STUDY 2:
This are the type kinetic energy recovery system that transfer the kinetic energy of an object into potential or stored energy to slow down the vehicle and as a result to increase the fuel efficiency. There are multiple methods of energy conversion in Regenerative Braking System including spring, flywheel, electromagnetic and hydraulic. More recently, an electromagnetic-flywheel hybrid.
They are installed along the drive train or fitted to the drive wheels of a vehicle where they inhibit the motion of the wheels using magnetic fields or mechanical torque. These methods of motion inhibition allow energy to be generated under braking, as opposed to friction brakes which simply waste away energy to slow the vehicle by turning the kinetic energy into thermal energy.
Regenerative Braking system can improve fuel consumption and reduce the overall braking load taken on by the vehicles friction brakes, reducing the wear on the brake pads. In HEV and EV the transmission of the car is set up such that when the driver applies the brakes, the electric motor reverses itself and applies a resistance to the wheels rather than power, this resistance applied to the wheels is then put through the electric motor where it is used to recharge the batteries.
Limitations :
There is a limitation due to the maximum recharging rate of the circuit and the capacity of battery, the braking force from an electromagnetic is always limited.
Why electric motor can’t develop braking torque at high speed similar to starting?
In EV application there is a motor-generator, and a battery pack to supply power, as the electric current travels through the motor within a magnetic field, it generates a force. The more current applied, the more the motor will spin.
For Regenerative Braking a motor will act as a generator i.e. the direction of the electric flow is reversed, the electric motor will rather than taking in current to spin the armature, the armature is spun through the field by the deceleration of the vehicle. The electricity produces is used to recharge the battery, and the motor can switch between powering the car and regenerating electricity as fast as the driver can accelerate and lift off.
As the motor revered increase, it also creates "back electromotive force" or "back EMF." The faster the motor spins, the more back EMF is created, reducing the effective voltage it can deliver. But at zero RPM, all of the electricity the motor creates from the time electric power is applied becomes instant torque—without any back EMF to reduce its output. The higher the revs, the more back EMF, meaning that instantaneous torque effect diminishes.
The reason behind this no matter how much the current loop wants to increase current (proportional to torque) by increasing the PWM duty cycle of the power stage, the Vmotor is too close to Vbemf and therefore current can't increase more.
- Whenever Friction torque + Additional loads = Motor Torque, the load remain in equilibrium(moves under a constant speed).
- Whenever Friction torque + Additional loads < Motor Torque, the load accelerates (Motor torque - Friction torque - Additional loads = Acceleration torque > 0).
- But, at high speed the BEMF is so close to Vbus that the applicable Motor torque gets limited, the bigger the Friction torque + Additional load is, the smaller the Acceleration torque becomes.
- This situation does not occur at the beginning of an acceleration because most of the torque is used to increase the kinetical energy of the load (and motor). But when the speed is already high and no extra load is applied it is not possible to increase the torque.
We can prevent this by,
- Increase DC bus voltage.
- Unlimite system acceleration.
- Use a motor with less resistance and lower back EMF proportion.
How are electric brakes and mechanical brakes coordinated?
In electric vehicles, two types of braking systems are used electric brake system and mechanical brake system.
Electric Braking System: In electrical braking, the winding of the motor is used to produce a braking torque. A braking torque is developed during the braking operation. This braking torque opposes the motion of the rotating member or shaft. This is achieved by suitably changing the electrical connections of the motor. The motor operates on a speed–torque characteristic, depending upon the method of braking employed.
Mechanical Braking System: In mechanical braking, the frictional force between the rotating parts and the brake drums produces the required braking. To achieve this, mechanical equipment, such as brake linings and brake drums, are required. Whether electrical or mechanical, the braking of the drive should stop the motor at the specified point of time and position.
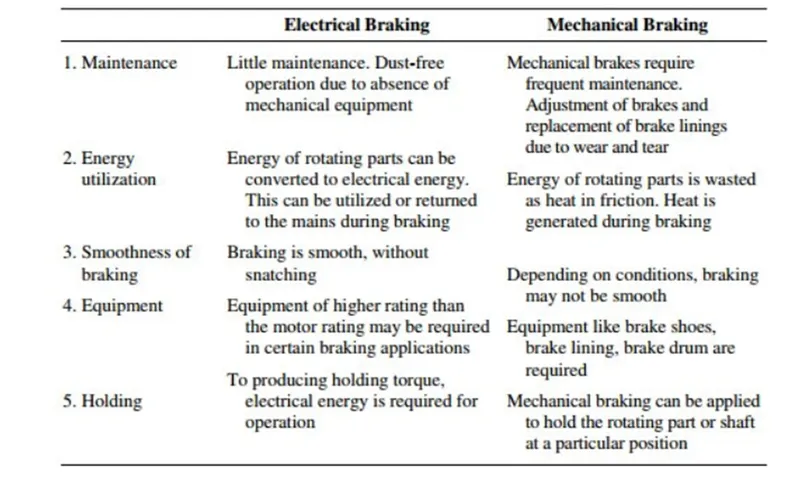
The electric braking system used in EVs and HEVs is regenerative braking. This method uses the motor as a generator during braking, developing a retarding torque, which acts on the running motor and halts it. The kinetic energy and potential energy, minus the losses of the motor are returned to the mains and the motor runs at a constant speed. Thus, regenerative braking eliminates the tendency of the load to accelerate the motor.
Mechanical braking systems used can be either disc or drum brake system. Where in case of a disc brake system friction pads rub against a disc when the brake pedal is applied and the kinetic energy is converted to heat and slows the vehicle down. In a drum brake system a set of brake shoes which are the friction materials press against a drum.
Since the braking torque is very less at high speeds, mechanical brakes are applied to slow down the vehicle. As the motor reaches the constant torque region the regenerative braking system takes effect where the motor acts as a generator and the negative torque produced charges the battery pack.
3.Make a MATLAB program which plots contour of given motor speed, torque and efficiency values. Attach the code as a .m file attach a screenshot of all the plots.
STUDY 3:
An efficiency map of an electric motor is a contour plot of torque and speed. It is used to describe the speed and torque combinations required at different efficiency ranges. In order to model the efficiency contour we must consider the losses that occur in electric motors and these losses are,
- Iron or Core Losses: Iron losses are made of two components which are hysteresis and eddy currents. Hysteresis losses occur as we switch the electromagnets in our motor on and off, and depends on the magnetic properties of the iron material used in the motor. Eddy current losses depend on many variables, including the thickness of the laminations in the stator, the frequency at which the motor operates, the flux density and the material's resistivity. The iron losses are proportional to the square of the lamination thickness.
- Copper or Variable Losses: Copper losses are due to the resistance of the copper conductors and the current that we ask them to carry, and they lead to heating of the conductors. Of course, because copper is heavy, we want to use as little of it as possible, minimizing cross-sectional area. This increases resistance and therefore increases losses and heating.
- Windage Losses: The loss caused by air friction between rotor and surrounding air is called windage losses. It occurs due to air resistance to the armature. Higher the speed of the motor more will be the windage losses.
Based on these 3 losses the MATLAB program to plot the efficiency contour is written below.
% Motor efficiency contour.
clear all
close all
clc

% Defining the speed and torque as arrays.
x = linspace(1,1000); % Motor speed in rad/s
y = linspace(1,250);  % Motor torque in N-m

% Motor loss constants
Kc = 0.2;     % Copper losses constant
Ki = 0.008;   % Iron losses constant
Kw = 0.00001; % Windage losses constant
ConL = 20;    % Constant motor losses
[X,Y] = meshgrid(x,y); % To create a 3D array

Output_power = (X.*Y); % Power equation

C_l = (Y.^2)*Kc;% Copper losses equation
I_l = X*Ki;     % Iron losses equation
W_l = (X.^3)*Kw;% Windage losses equation

Input_power = Output_power + C_l + I_l + W_l + ConL;
Z = Output_power./Input_power; % Efficiency
V = [0.7,0.8,0.85,0.9,0.91,0.92,0.925,0.93]; % Mapping the contours of the efficiency

% Plotting the contour
box off
grid off
contour(X,Y,Z,V);

xlabel('Speed in rad/s');
ylabel('Torque in N-m');
legend('0.7,0.8,0.85,0.9,0.91,0.92,0.925,0.93');
hold on
Explanation of the code,
- First the clear all, close all and clc commands are written to clear all variables in workspace, to clear all plots and to clear the workspace respectively.
- The speed and torque are defined as 2-Dimensional linearly spaced arrays using the linspace command.
- The constants of the motor losses are defined.
- The 2-D arrays of the speed and torque are then defined as 3-Dimensional arrays using the mesh grid command.
- The output power equation is defined as the product of speed and torque.
- The equations of the motor losses based on the speed and torque are defined.
- The input power is defined as the sum of output power plus motor losses.
- The efficiency is then defined as the ratio of output power to input power.
- In order to map the contour for different efficiency ranges an array is defined which consists of the efficiencies from 0.7 to 0.93.
- The graph is plotted using the contour command to plot the speed, torque, and efficiency.
The contour plot of the above MATLAB program is given below,
OUTPUT:
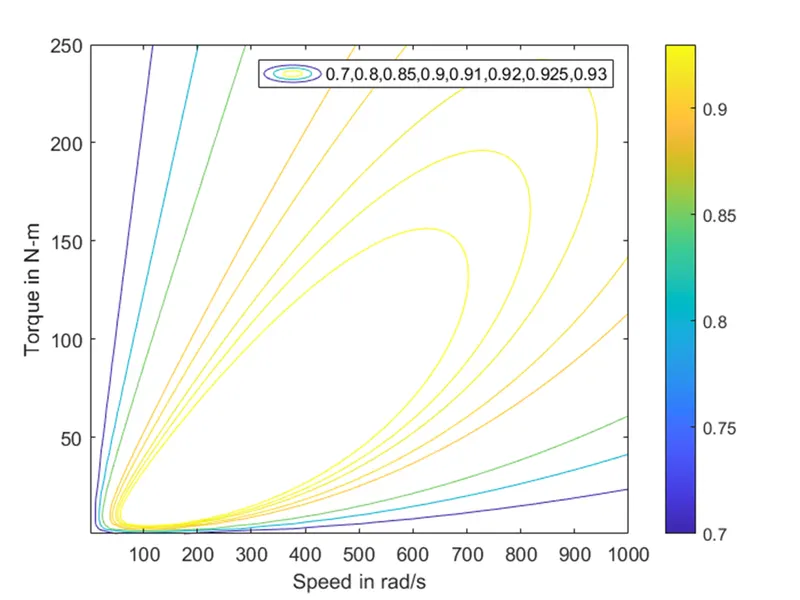
From the plot it can be observed that the speed and torque varies as the efficiency increases. This is due to the motor losses that occur. The dark blue line represent the contour 70% efficiency and the bright yellow line represents the contour 93% efficiency.
For example at 70% efficiency, the torque reaches it's peak value of 250 N-m when the vehicle is a very low speed but the torque decreases significantly as the speed increases for the same efficiency. And at a motor efficiency of 93% the speed and torque required is much less compared to an efficiency of 70%.
Greater the motor efficiency, lower speed-torque combination is required to overcome the motor losses.
RESULT:
As we see in output we going inside to circle our efficiency get increase and outside it will decrease.
CONCLUSION :-
- The energy required for braking of a vehicle based on a drive cycle is calculated.
- The co-ordination between electric brakes and mechanical brakes and why braking torque is less at high speed are explained.
- The MATLAB program to plot the speed, torque and efficiencies contour is written and the graph is plotted.