Week-11 Challenge: Braking
EV LIVE BATCH -16:
1)For a defined driving cycle, calculate the energy required for braking.?
SOLUTION:
- We required some amount of power which is used for accelerating the vehicle and also for braking of vehicle.
- hence we consider the drive cycle which is predefined as FTP75
work done=kinetic energy=0.5m*v^2
For calculating the energy the formula is E= 0.5 m*v^2
v= velcoity of vehicle =vf (here the vehicle is decelerating from 100 to 0 speed)
so,vf=final velocity=100kmph ,
vi=initial velocity=0kmph
t=time required from 100 to 0 speed is =10sec
power required is p=E\t
p=(o.5*1000*(100*0.277)^2)\100
p=38.36kw
Energy required for braking of vehicle from 100 to 0 in 10sec is E=0.0106kwhr
Energy required for braking of vehicle from 100 to 0 in 1sec is E=0.0106kwhr
2)Why electric motor can’t develop braking torque at high speed similar to starting? How electric and mechanical brakes are coordinated?
SOLUTION:
- Braking is an important as acceleration for acceleration and braking the vehicle certain amount of energy certain amount of energy required
- when considering the electric motor application in EV vehicles the braking of electric motor itself is braking the vehicle ,electric braking is where the motor apply brakes and propulsion source itself provides the braking power
- consider the case where electric vehicle operted by electric motor took 10sec to reach 0 to 100kmph speed and also take 10sec to reach 100 to 0 speed.
CASE 01:
ELECRIC MOTOR TOOK 10 SEC TO REACH 0 TO 100KMPH:
- When the vehicle is starting from zero speed at this stage the torque maintained by electric motor is almost constant
- so,at low speed characteristics of motor the torque produced is constant hence the motor opertion in constant torque region therefore the vehicle has higher acceleration power possible at low speed motor torque is high
CASE-02:
ELECTRIC MOTOR TOOK 10SEC TO REACH 100 TO 0KMPH:
- when it comes to braking part where the torque is negative and the speed is positive therefore the power the power is negative this is called second quadrant operation of motor or forward braking stage
How electric and mechanical brakes are coordinated?
SOLUTION:
- This is explained by the brake force distribution between electric (regenerative braking)and mechanical braking
- The brakes forces are distribution keeping the safety in consideration here there are two axels of the vehicle where the brake force is dstributed not equally but almost same.
- when the vehicle is running with low speed the electric brakes can applied but when the vehicle is at high speed we have to apply both electric and mechanical brakes to make the vehicle come to zero speed in less time otherwise if we can apply electric brakes
KEEPING THE 1)moment of inertia of vehicle
2) vehicle speed
3) kinetic energy stored in the vehicle
4) forces acting on the vehicle
5) time required for braking
6)mechanical losses like friction and windage losses
The above all factors decide the type of braking needed for the vehicle at the particular instant of time based on that the electric and mechanical brakes are coordinated.
THERE ARE TWO BRAKE CONTROL STRATEGIES DEVELOPED THET ARE:
1)SERIES BRAKING : we apply the mechanical brakes and electric brakes one after another
2)PARALLEL BRAKING: we apply both mechanical brakes and electric brakes simultaneously at a time
- motor of electric vehicle is able to be used to brake regeneratively,so braking energy can be recycled
- Braking stability of electric vehicles with electro-hydralic braking system can be influenced by braking force distribution between hydralic braking force and regenerative braking force
- in order to research on breaking stability and braking energy recovery ,simulink platform of elctro-hydralic braking brake system based on matlab \simulink is built and a control strategy of electro-hydralic hybrid system
- but also braking energy can be recycled one demand of hydralic pressure can be reduced......
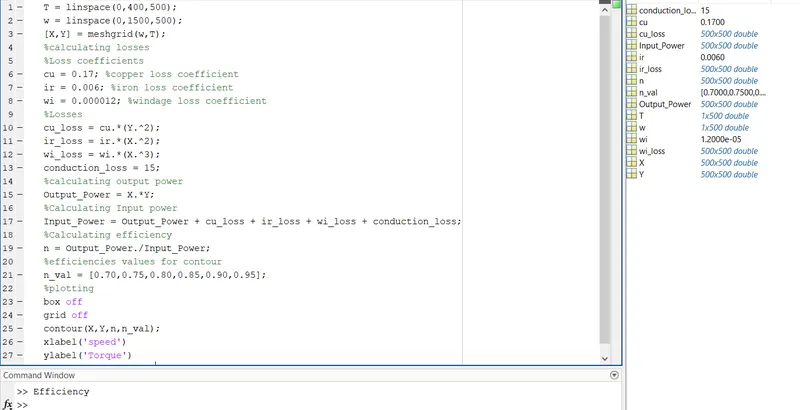
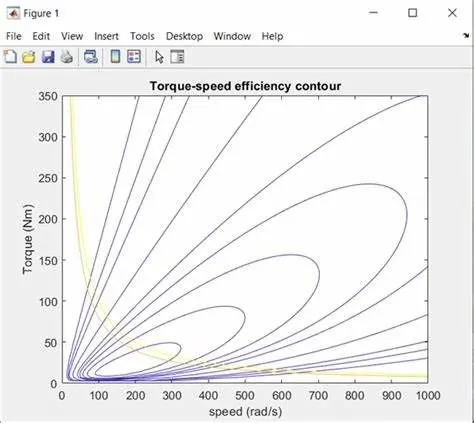
3)Make a MATLAB program which plots contour of given motor speed, torque and efficiency values. Attach the code as a .m file attach a screenshot of all the plots.
SOLUTION:
OUTPUT WAVEFORM:
Speed values taken up to 1000values
Torque values taken upto 250values
X AND Y ARE DEFINED AS ARRAAY OR FOR MULTIPLE VALUES OF SPEED AND TORQUE.
 ..........,