Week-11 Challenge: Braking
-
- For a defined driving cycle, calculate the energy required for braking.
Energy required for braking is the kinetic energy difference from the current spped and the speed from which braking was started
as we know K.E=0.5*m*v^2
for our case
K.E =0.5*m*(v1^2-v2^2)
where v1is initail velocity'
v2 is velocity after braking
Braking of a vehicle require vehicle to deaccelerate vehicle to lower speed within a given time
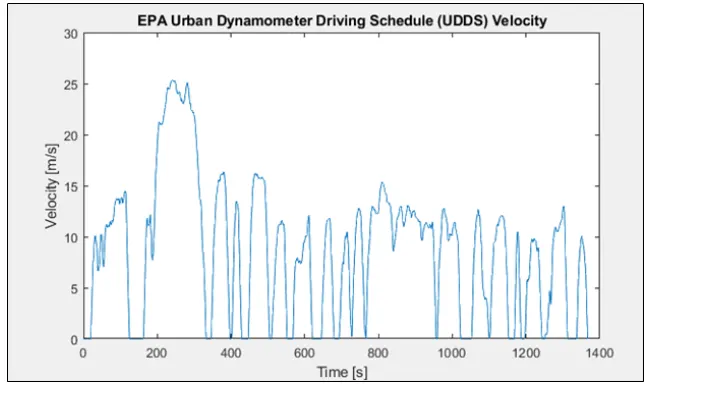
acceleration and decelaration for a vehicle is same only difference would be in the in values V1 AND V2
- Why electric motor can’t develop braking torque at high speed similar to starting? How electric and mechanical brakes are coordinated?
SPEED torque characteristics of motor are given in the following daigram
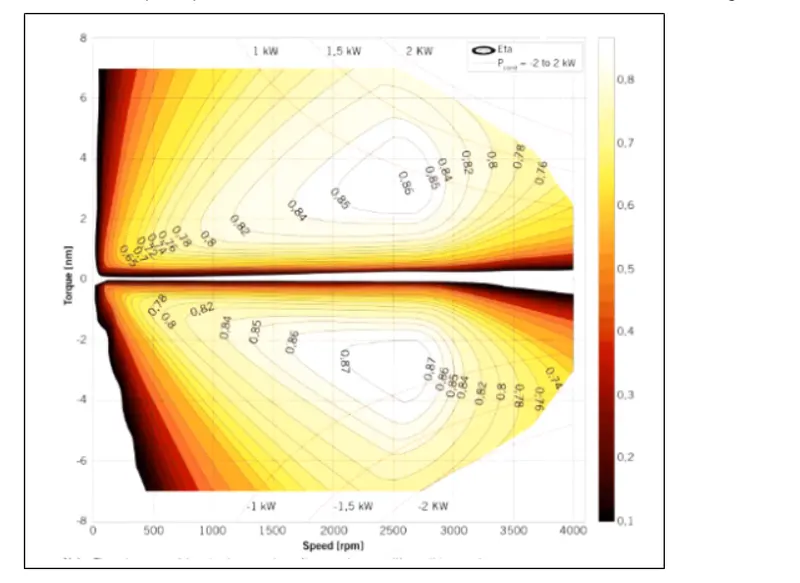
we can see that at start of the vehicle maximum torque is available ,in that motor will have maximum torque available ,but as motor starts deaccelerating motor charcterictics are shifted towards braking region,we dont have max torque available for braking as vehicle is already at higher spped
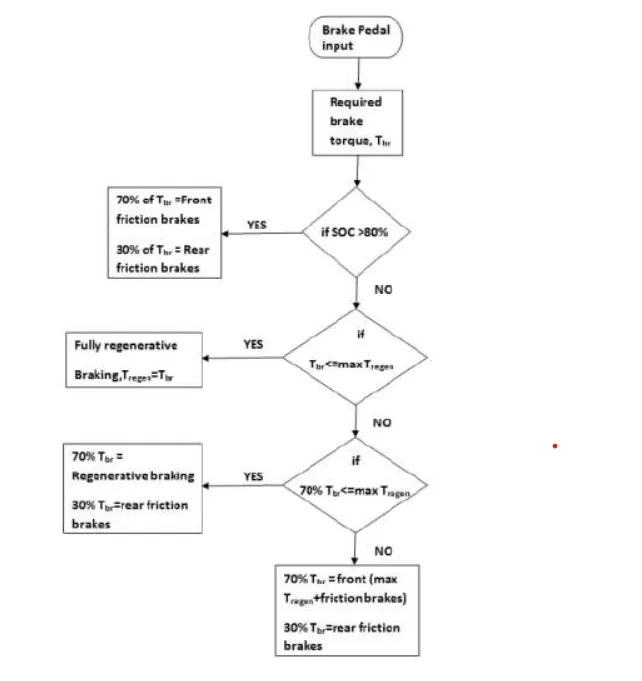
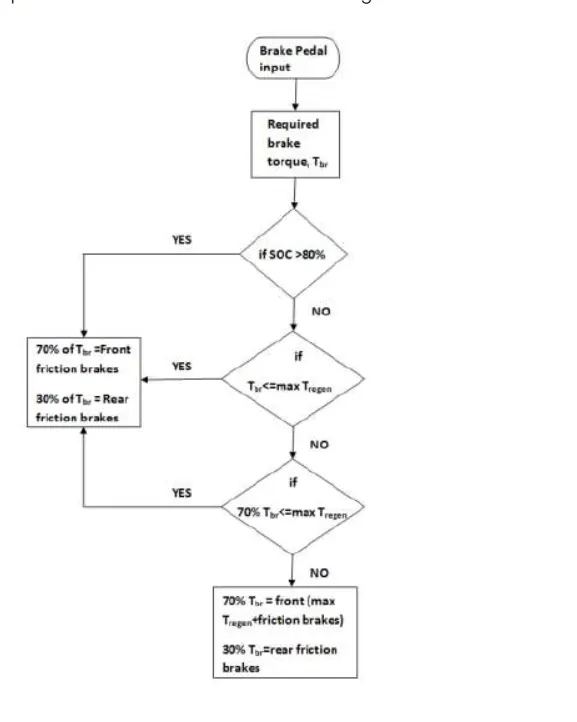
brake strategy system:
1)serial braking strategy
2)parallel braking strategy
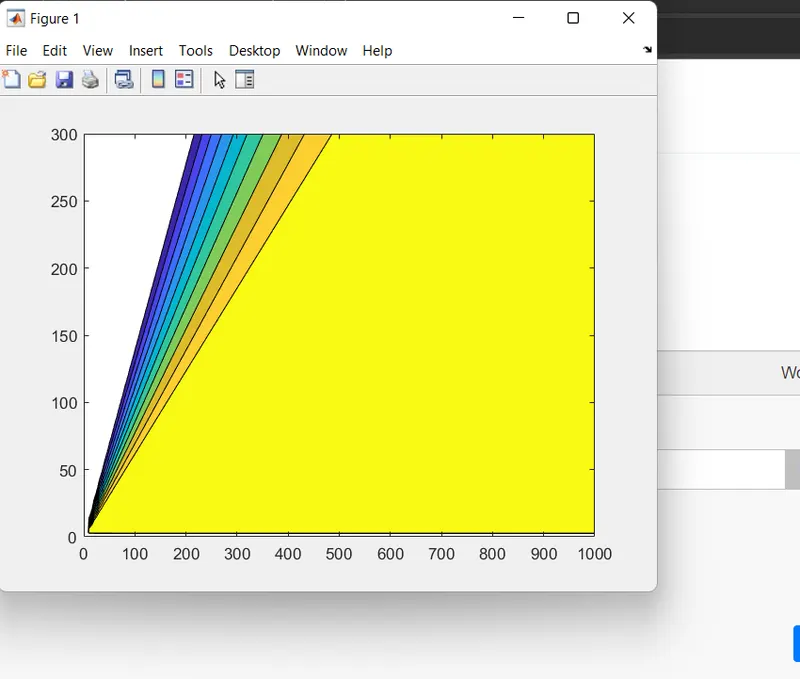
- a MATLAB program which plots contour of given motor speed, torque and efficiency values. Attach the code as a .m file attach a screenshot of all the plots.
w=linspace(0,1000);
t=linspace(0,300);
kc=0.18;
ki=0.006;
kw=0.00015;
[X,Y]=meshgrid(w,t);
copperloss=(Y.^2)*kc;
ironloss=X*ki;
windingloss=(X.^3)*kw;
K=20;
outputpower=X.*Y;
inputpower=(copperloss)+(ironloss)+(outputpower);
effi=(outputpower)./(inputpower);
n=linspace(0.8,0.9,10);
contourf(X,Y,effi,n);
xlavel('speed rad/s')
ylabel('torque n-m')