Week-11 Challenge: Braking
AIM:
- To make a drive cycle for calculating the energy required for braking.
- To answer the question 'why electric motor cant develop braking torque at high speed similar to starting? How electric and mechanical brakes are co ordinate?'
- To Make a MATLAB program which plots contour of given motor speed, torque and efficiency values. Attach the code as a .m file attach a screenshot of all plots.
Study 1 :
- A driving cycle is a series of data points representing the speed of a vehicle versus time. Driving cycles are produced by different countries and organizations to assess the performance of vehicles in various ways
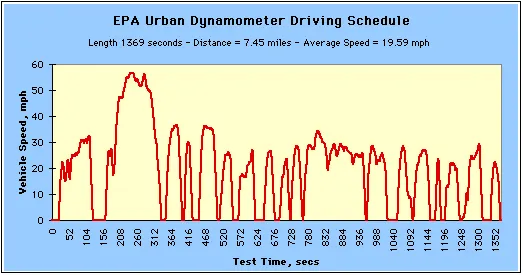
- In this calculation UDDS Drive cycle data is used. The total Braking energy required for the UDDS drive cycle is calculated.
UDDS Driving Cycle:
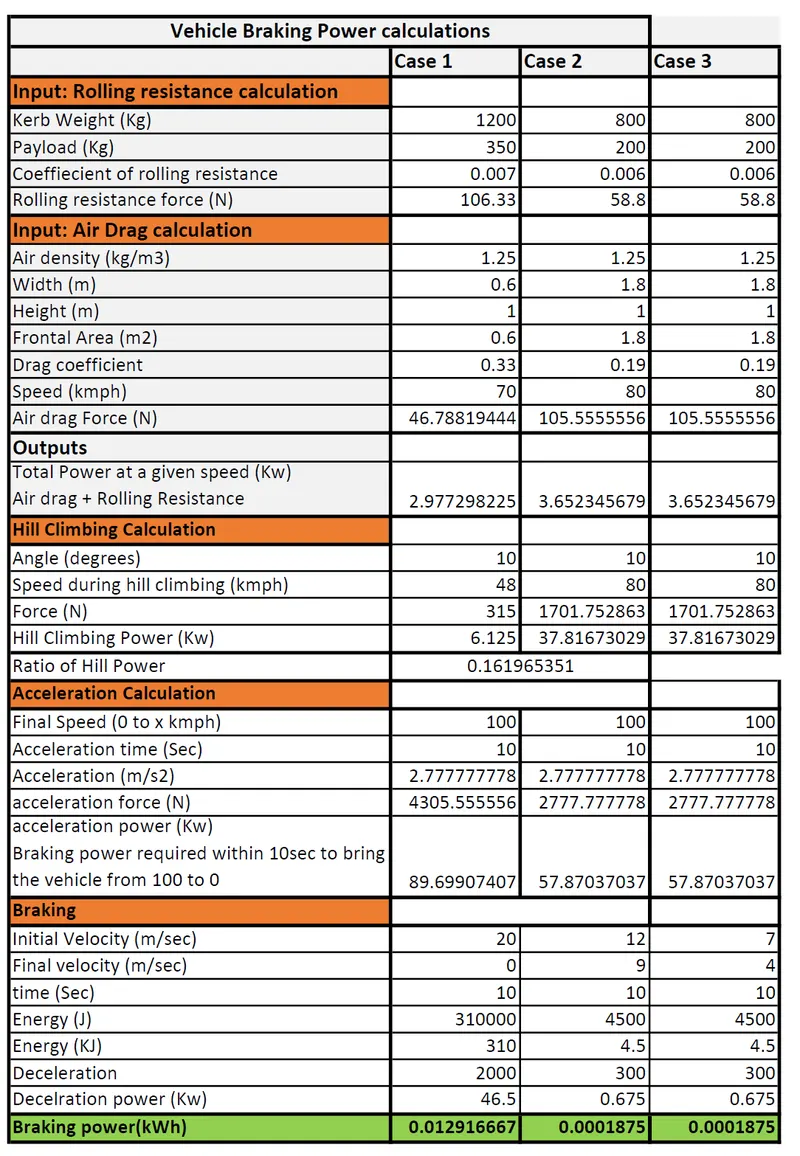
- Kinetic Energy is calcualted as =KE=`1/2*m.v^2`
- Braking enrgy required=`1/2*m*(v_i-v_f)^2`
Study 2 :
There are two major reasons for a motor developing higher starting torque compare to braking:
- Due To Transients:
At starting the motor draws a large current due Transient. As torque is proportional to square of current, therefore torque value is also high at this moment.
When we applies brakes to motor at that time current value is within the range therefore Torque values is also within the range.
- Torque speed characteristic: From Torque speed characteristic when speed increases torque should decrease to maintain power constant. At the time of starting speed is very low therefore Torque value is very high. At the time of braking, speed value is high therefore torque value will be low.
- Therefore at the time of braking torque value available will be lower.
In order to stop the vehicle it requires electrical as well as mechanical brakes.
There are two methods to apply this brakes:
- Series braking
- Parallel braking
- Series braking: In this mechanical and electrical (Regenerative) braking's are applied one after the other. Parallel Braking: In this both Braking methods are applied at a same time.
- Parallel braking: In this both the brakes are appliled simultaneously.Both at a time.
- At lower speeds Regenerative braking's are used and at higher speeds mechanical brakes are used.
Study 3 :
Matlab Script Program for Contour Plot:
clear all
close all
clc

speed= linspace(0,1000);
torque= linspace(0,500);

kc= 0.2;
ki=0.006;
kw=0.000010;
k=20;

[x,y] = meshgrid(speed,torque);
copper_loss= (y.^2)*kc;
iron_loss= x*ki;
windage_loss= (x.^3)*kw;

output_power= x.*y;
input_power= (copper_loss+iron_loss+windage_loss+output_power+k);
efficiency=(output_power./input_power);

n=linspace(0.7,0.95,10);
contourf(x,y,efficiency,n);
title('speed-torque efficiency')
xlabel('speed (rad/s)');
ylabel('torque (Nm)');
colorbar
Program Description:
- Here in this program first two inputs were given. They are Speed & Torque using linspace command.
- Then the motor constant values are assigned namely Copper loss, Iron loss, Windage loss and Constant motor.
- Then meshgrid is used to evaluate functions of two variables and three-dimensional mesh/surface plots.
- Output Power is calculated by multiplying speed and torque.
- Then all the loss were calculated and the input powers were also calculated.
- Then comes the efficiency were calculated. And Contour graph is plotted between Speed, Torque and Efficiency.
- Title were given and labels were given.
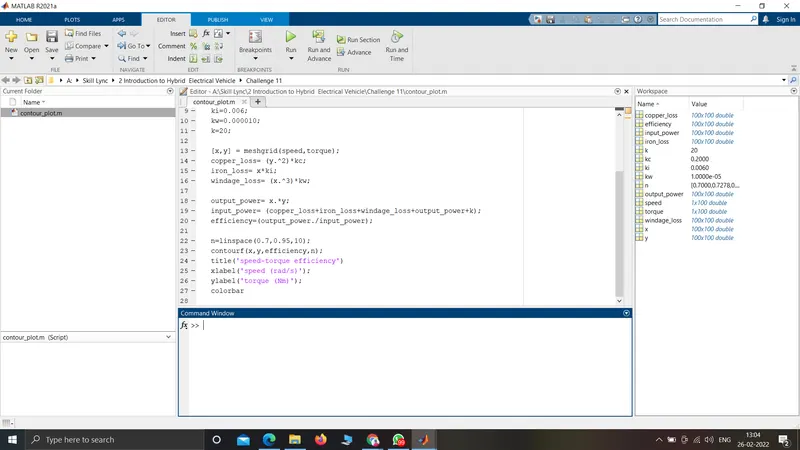
Workspace:
Contour Plot:
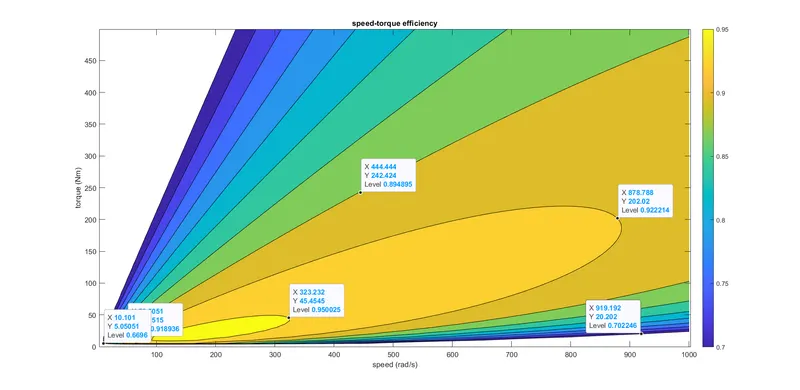
- This plot clearly shows that maximum efficiency of 95 % is achieved by 45.45rad/sec and at 50 Nm. The lowest Efficiency 70 % is achieved at 10.10 rad/sec and at torque of 10.1Nm.
- This Contour plot clearly gives the idea on Speed, Torque and Efficiency relationship of the motor.
- The color indicates the efficiency denoted in the right side with the colorbar.
CONCLUSIONS:
- For a defined driving cycle, the energy required for braking is calculated.
- Why electric motor can't develop braking torque at high speed similar to starting and how electric and mechanical brakes are coordinated were dicussed.
- A MATLAB program which plots contour of given motor speed, torque and efficiency values is coded.