vehicle dynamics week 11D
Question:
The goal here is to obtain the ratio between the rear and front steer angles to obtain zero side slip angle and plot the relationship between that ratio and forward speed. Following are the steps to solve this problem
- Start with state space representation of 4WS
- Assume steady state (some changes are necessary to accommodate for dynamic conditions)
- Set yaw acceleration to zero
- Set Lateral acceleration to zero
- Using the yaw rate and lateral speed equations, derive an expression for the ratio between front and rear steer angles (del_r/del_f)
- Plot this ratio against forward velocity and make conclusions
Your deliverables:
- del_r/del_f formula for zero side slip (15 points)
- Plot of the ratio against forward speed (5 points)
- Conclusions from the plot (5 points)
Matlab code:
clear all
close all
clc
l= 2.5 ; % Wheelbase (m)
a = 0.85; % cg to front axle (m)
b = l-a; % cg to rear axle (m)
m = 1200; % Mass (kg)
jz = 2000 ; % moment of inertia (kg-m^2)
cf = 160000; % front cornering stiffness (N/rad)
cr = 120000
u=[0.1:60]
for i=1:length(u)
A{i}=[-(cf+cr)/(m*u(i)),(((b*cr)-(a*cf))/(m*u(i)))-u(i);((b*cr)-(a*cf))/(jz*u(i)),-((((a^2)*cf)+((b^2)*cr))/(jz*u(i)))]
B=[cf/m,cr/m;(a*cf)/jz,-(b*cr)/jz]
x{i}=-inv(B)*A{i}
ratio(i)=x{i}(2,2)/x{i}(1,2)
i=i+1
end
for j=1:length(u)
S(j)=(cf*(((-cr*a*b+a*m*((u(j))^2)-((b)^2)*cr))))/(cr*(a*b*cf+b*m*((u(j))^2)+(a)^2*cf))
j=j+1
end
figure(1)
plot(u,ratio,'linewidth',3)
grid on
hold on
plot(u,S,'linewidth',3)
grid on
hold on
Steps:
-input is declared
-velocity range is declared
-then for loop is constructed with the counter having same number of elements in the velocity array
-then A matrix is declared using:
A=[-(cf+cr)/(m*u(i)),(((b*cr)-(a*cf))/(m*u(i)))-u(i);((b*cr)-(a*cf))/(jz*u(i)),-((((a^2)*cf)+((b^2)*cr))/(jz*u(i)))]
-then B matrix is declared using:
B=[cf/m,cr/m;(a*cf)/jz,-(b*cr)/jz]
-{i} brackets are used to save each A matrix in a different cell, while (i) is used to select specific velocity element from velocity array
-then x matrix is computed from multiplying the negative inverse of b matrix with A
[X]=-[invB]*[invA] and each matrix is stored in a cell
-then the rear to front steering ratio is computed by taking the second element in the x matrix in each cell and dividing it by the first element,so inorder to do that the brackets are used {} to select the matrix in the cell and () is used to select the element in the matrix.
-then another for loop is used for the derived formula
-then the two formulas are plotted against each other
-Derived formula:
`(δr)/(δf )=(cf*(-a*b*cr+a*m*(v)^2-(b)^2*cr))/(cr*(a*b*cf+b*m*(v)^2+(a)^2*cf))`
plot:
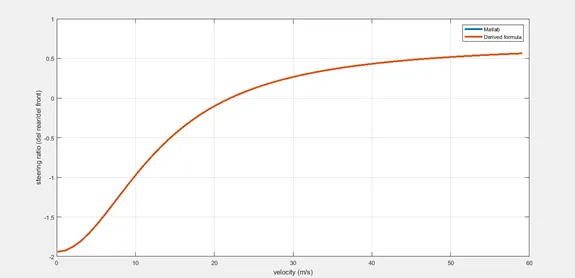
The plot shows exact match between the matlab and derived formula,also the plot shows that rear wheels should be turned opposite to the front wheels at low speed until 22 (m/s) or approx. 80 kmph as this will aid the agility of the vehicle required at low speeds, but above 80 kmph it should be turned in the same direction as the front wheels as this will aid the stability of the vehicle required at high speeds,performing this shift in direction between the rear and front wheels at low and high speeds will ensure zero side slip angle on any speed.
Files:
https://drive.google.com/file/d/1hxjplxSf38dSA5gvyWIX6vYwQCx3qNhu/view?usp=sharing