Study of EV Drivetrain using MATLAB.
Aim: To study the EV Drivetrain.
Objective:
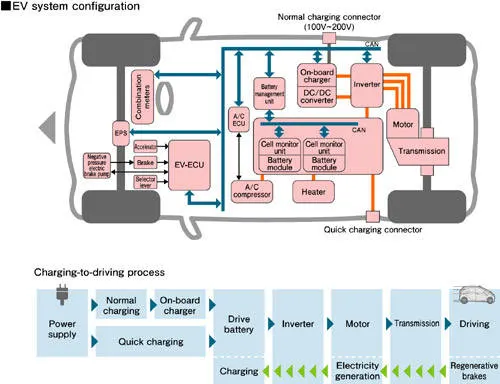
- To explain the types of power converter circuits that are employed in an electric and hybrid electric vehicle.
- To solve the problem by data's that are given in the question and determine what is EV steady-state speed if the duty cycle is 70%
- To explain Induction Versus DC brushless motors by Wally Rippel, Tesla.
1. Which types of power converter circuits are employed in electric and hybrid electric vehicles?
Power Electronic Converters:
- The main aim of the converter is to produce conditioning power with respect to a certain application.
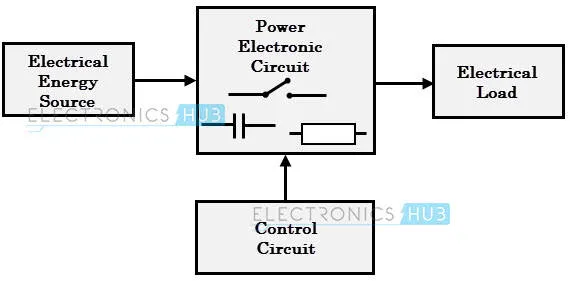
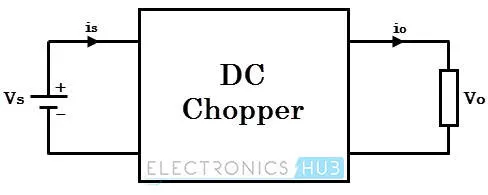
- The block diagram of a power electronic converter is shown in the figure above. It consists of an electrical energy source, a power electronic circuit, a control circuit, and an electric load. This converter changes one form of electrical energy to other forms of electrical energy.
- Power electronic converters perform various basic power conversion functions. This converter is a single power conversion stage that can perform any of the functions in AC and DC power conversion systems.
Depending on the type of function performed, power electronic converters are categorized into the following types.
- AC-to-DC= Rectifier: It converts AC to unipolar (DC) current.
- DC-to-AC= Inverter: It converts DC to AC of desired frequency and voltage.
- DC-to-DC= Chopper: It converts constant to variable DC or variable DC to constant DC.
- AC-to-AC= Cycloconverter, Matrix converter: It converts AC of the desired frequency and/or desired voltage magnitude from a line AC supply.
AC to DC Converters or Rectifiers:
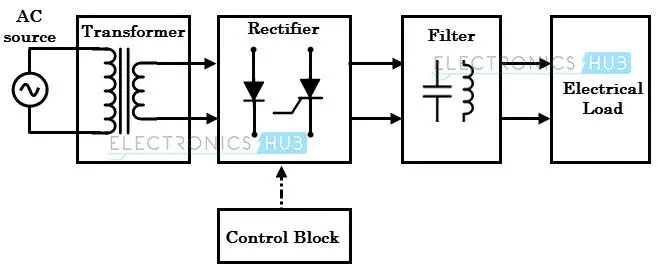
- An AC to DC converter is also called a rectifier, which converts AC supply from main lines to DC supply for the load. The block diagram of an AC to DC converter is shown in the figure below.
DC to AC Converters or Inverters:
- These converters are connected between DC source of fixed input and variable AC load. Most commonly, these DC to AC converters is called inverters. An inverter is a static device that converts the fixed DC supply voltage to variable AC voltage.
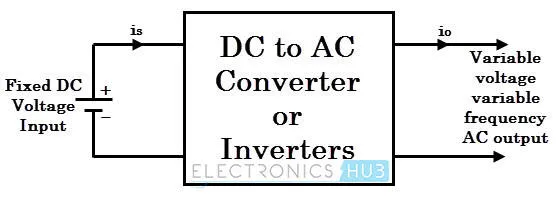
- Here the fixed DC voltage is obtained from batteries or by DC link in most power electronic converter. The output of the inverter can be variable/ fixed AC voltage with variable/fixed frequency.
- This conversion from DC to AC along with variable supply is produced by varying the triggering angle to the thyristors. Most of the thyristors used in inverters are employed with forced commutation techniques.
- These can be single-phase or three-phase inverter depending on the supply voltage. These converters are mainly divided into two groups. One is PWM based inverters and other multilevel inverters.
DC/DC converters for electric vehicles:
- The different configurations of EV power supply show that at least one DC/DC converter is necessary to interface the FC, the Battery, or the Super capacitors module to the DC-link.
- In electrical engineering, a DC-to-DC converter is a category of power converters and it is an electric circuit, which converts a source of direct current (DC) from one voltage level to another, by storing the input energy temporarily and then releasing that energy to the output at a different voltage. The storage may be in either magnetic field storage components (inductors, transformers) or electric field storage components (capacitors).
- DC/DC converters can be designed to transfer power in only one direction, from the input to the output. However, almost all DC/DC converter topologies can be made bi-directional. A bi-directional converter can move power in either direction, which is useful in applications requiring regenerative braking.
Non-isolated converters:
The non-isolated converters type is generally used where the voltage needs to be stepped up or down by a relatively small ratio (less than 4:1). Moreover, when there is no problem with the output and input having no dielectric isolation. There are five main types of the converter in this non-isolated group, usually called the buck, boost, buck-boost, and Cuk and charge-pump converters. The buck converter is used for voltage step-down, while the boost converter is used for voltage step-up. The buck-boost and Cuk converters can be used for either step-down or step-up. The charge-pump converter is used for either voltage step-up or voltage inversion, but only in relatively low power applications.
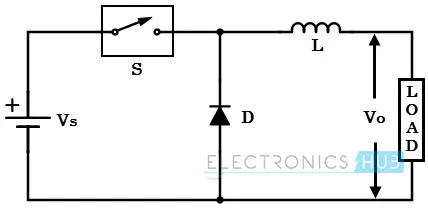
(a) Step-Down (Buck) Converter:
A step-down circuit is used to generate a lower voltage than the input. It is also called a buck. The polarities are the same as in the input.
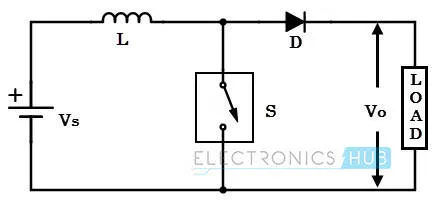
(b) Step-Up (Boost) Converter:
A step-up circuit is used to generate a higher voltage than the input voltage. It is called a boost. The polarities are the same as in the input.
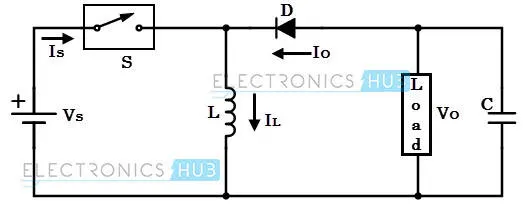
(c) Buck-Boost Converter:
In the Buck-Boost converter, the output voltage can be increased or decreased than the input voltage. It works to either boosting or bucking the voltage. The common usage of this converter is to reverse the polarity.
(d) Cuk:
This type of converter is similar to the Buck-Boost converter. The difference is its name, named after Slobodan Cuk, the man who created it.
(e) Charge Pump:
This converter is used to step the voltage up or down in applications that have low power.
Isolated converters:
Usually, in this type of converters, a high-frequency transformer is used. In the applications where the output needs to be completely isolated from the input, an isolated converter is necessary. There are many types of converters in this group such as Half-Bridge, Full-Bridge, Fly-back, Forward, and Push-Pull DC/DC converters (Garcia et al., 2005), (Cacciato et al., 2004). All of these converters can be used as bi-directional converters and the ratio of stepping down or stepping up the voltage is high. Some of the types are explained below,
AC-to-AC Converters:
- AC/AC converters connect an AC source to AC loads by controlling the amount of power supplied to the load. This converter converts the AC voltage at one level to the other by varying its magnitude as well as the frequency of the supply voltage.
- These are used in different types of applications including uninterrupted power supplies, high power AC-to-AC transmission, adjustable speed drives, renewable energy conversion systems, and aircraft converter systems.
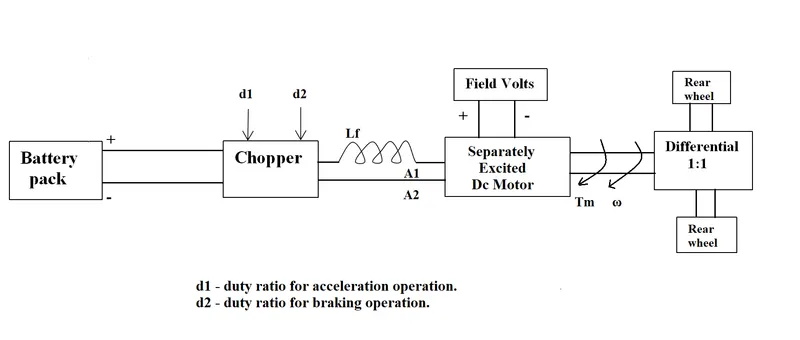
2. To solve the problem by data are given in the question and determine. What is EV steady-state speed if the duty cycle is 70%?
Given Data,
- Mass (m) = 1000kg.
- Drag Coefficient (Cd) = 0.2.
- Frontal Area (A) = 2 sq-m.
- Coefficient of Rolling Resistance (c_o) =0.009.
- Gear Ratio C1 = 1.
- Density (ρ) = 1.1614 kg/cub-mtr.
- Radius of the wheel (r) = 11 inches= 0.28 m.
- Rated Armature Voltage (V) = 72 V.
- Rated Armature current (I) = 400 A.
- Armature Resistance Ra = 0.5Ω.
- Armature Inductance La = 8 mH.
- Motor Constant Kφ = 0.7 V-s.
- Chopper Switching frequency = 400 Hz.
- Duty Cycle = 70%.
Formula Used:
- The Rolling Resistance Force.
Frr = `mu`rr.m.g`
- Drag Force.
Fad = 0.5.ρ.A.v^2.Cd.
- The Total Tractive Force.
Fte = Frr + Fad.
- Speed-Torque Equation for D.C Motor.
ω = (V/kφ)-(T.R/(kφ)^2).
Solution:
We find the Rolling Resistance Force.
- Frr = `mu`rr.m.g`
- Frr = 0.009*1000*9.81.
- Frr = 88.29 N.
Then we find the Drag Force.
- Fad = 0.5.ρ.A.v^2.Cd.
- Fad = 0.5*1.1614*2*v^2*0.2.
- Fad = 0.232*v^2.
- Fad = 0.232*ω^2*(0.28) ^2.
- Fad = 0.01821*ω^2.
The Total Tractive Force.
- Fte = Frr + Fad.
- Fte = 88.29+ (0.01821*ω^2)…………….(Equation-1).
We know that.
- Fte =G.T/r.
Substituting in (1).
- (1*T)/0.28 = 88.29+(0.01821*ω^2).
- T_TR = 24.72+0.0051*ω^2…………. (Equation-2).
The vehicle characteristics are given by equation (2) and it is derived.
- TR=24.7+0.0051w2.
Which is given in the question.
We know that.
Speed-Torque Equation for D.C Motor.
- ω = (V/kφ)-(T.R/(kφ)^2).
By rearranging it in the form torque equation.
- T = ((V.kφ)/R)-(ω.(kφ)^2/R).
Substituting the values of voltage, kphi, Armature Resistance, we get.
In the question, it is given that the duty cycle is 70%.
Therefore, we need the find out the voltage at 70% duty cycle.
- V = 72*0.7 = 50.4V.
- T = ((50.4*0.7)/0.5)-((ω.(0.7)^2)/0.5).
- T_m = 70.56-(ω*0.98)…………Equation (3).
At the steady-state condition of EV.
- T_TR = Tm.
Now substituting the values of T_TR and Tm i.e. equation (2) and (3).
- 24.72+0.0051*ω^2 = 70.56-(ω*0.98).
- (0.0051*ω^2) + (ω*0.98)-45.84 = 0.
Omega value will always be positive, therefore.
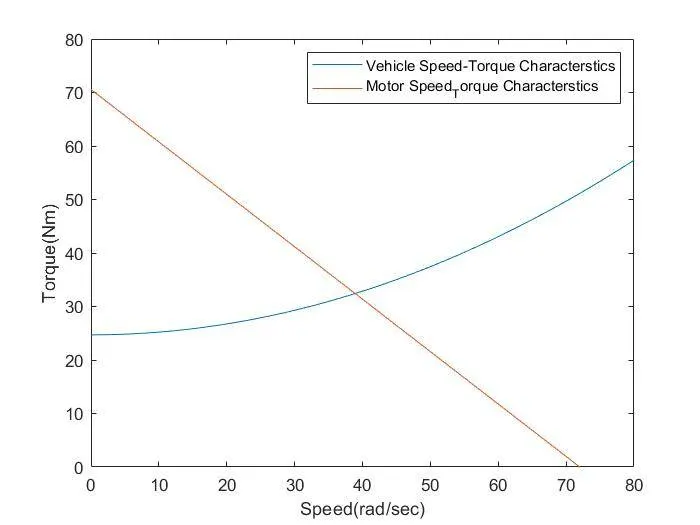
- ω = 38.90 rad/sec.
Therefore, EV steady state speed if duty cycle is 70% is, ω = 38.90 rad/sec.
MatLab Code:
clear all
close all
clc

%Given Data
%Rated Armature Voltage
V = 72;
%Rated Armature Current
I = 400;
%Armature Resistance
R_a = 0.5;
%Constant Factor
K_phi = 0.7;
%Chopper switching frequency
f = 400;
omega = linspace(0,100,50);
%Vehicle Speed-Torque Characterstics Equation
T_TR = 24.7+(0.0051*omega.^2);

%To Find
%EV Steady state speed for duty cycle 70%
% V = 72*0.7 = 50.4 v

%Motor Speed -Torque Characterstics Equation
%omega = (V/K_phi)-((R_a*T)/K_phi);
%Rearranging the above equation in terms of Torque
T = ((V*K_phi)/R_a)-((omega*K_phi^2/R_a));
T = ((50.4*0.7)/0.5)-((omega*0.7^2)/0.5);
T = 70.56-(0.98*omega);

%Substitute Vehicle & Motor Speed-Torque eqn in for loop to get EV Steady State Speed
for i=0:length(omega)
    T_TR = 24.7+(0.0051*(omega.^2));
    T = 70.56-(0.98*omega);
end
plot(omega,T_TR)
hold on
plot(omega,T)
axis([0 80 0 80]);
xlabel("Speed(rad/sec)");
ylabel("Torque(Nm)");
legend("Vehicle Speed-Torque Characterstics","Motor Speed_Torque Characterstics")
Output Graph:
3. Induction Versus DC brushless motors by Wally Rippel, Tesla.
DC brushless drives:
- In brushless machines, the rotor includes two or more permanent magnets that generate a DC magnetic field (as seen from the vantage point of the rotor). In turn, this magnetic field enters the stator core (a core made up of thin, stacked laminations) and interacts with currents flowing within the windings to produce a torque interaction between the rotor and stator. As the rotor rotates, it is necessary that the magnitude and polarity of the stator currents be continuously varied – and in just the right way - such that the torque remains constant and the conversion of electrical to mechanical energy is optimally efficient.
- The device that provides this current control is called an inverter. Without it, brushless motors are useless motors.
- A brushless DC motor produces no starting torque when directly connected to fixed frequency utility power. They really need the aid of an inverter whose “phase” is maintained in step with the angular position of the rotor.
- One of the main differences is that much less rotor heat is generated with the DC brushless drive.
- Rotor cooling is easier and peak point efficiency is generally higher for this drive.
- In an ideal brushless drive, the strength of the magnetic field produced by the permanent magnets would be adjustable.
- DC brushless drives require an absolute position sensor.
Induction motor drives:
- The induction rotor has no magnets – just stacked steel laminations with buried peripheral conductors that form a “shorted structure.” Currents flowing in the stator windings produce a rotating magnetic field that enters the rotor.
- In turn, the frequency of this magnetic field as “seen” by the rotor is equal to the difference between the applied electrical frequency and the rotational “frequency” of the rotor itself. Accordingly, an induced voltage exists across the shorted structure that is proportionate to this speed difference between the rotor and electrical frequency. In response to this voltage, currents are produced within the rotor conductors that are approximately proportionate to the voltage, hence the speed difference. Finally, these currents interact with the original magnetic field to produce forces – a component of which is the desired rotor torque.
- The fact that induction motors are directly compatible with conventional utility power is the main reason for their success.
- When a 3-phase induction motor is connected to utility type 3-phase power, torque is produced at the outset. The motor has the ability to start under load. No inverter is needed.
- In contrast, induction machines have no magnets, and B fields are adjustable.
- Induction drives require only a speed sensor.
Similarities of Induction And DC brushless drives:
- Both DC brushless and induction drives use motors having similar stators.
- Both drives use 3-phase modulating inverters. The only differences are the rotors and the inverter controls. Moreover, with digital controllers, the only control differences are with the control code.
Conclusion:
- We conclude that DC brushless drives will likely continue to dominate in the hybrid and coming plug-in hybrid markets, and that induction drives will likely maintain dominance for the high-performance pure electrics.
- The fact that so much of the hardware is common for both drives could mean that we will see induction and DC brushless life and work side by side during the coming golden era of hybrid and electric vehicles.
References: