Simulink Door Bell and Fan control
Aim:
- To simulate a Simulink model of a Doorbell using Solenoid block and observe the output
Objective:
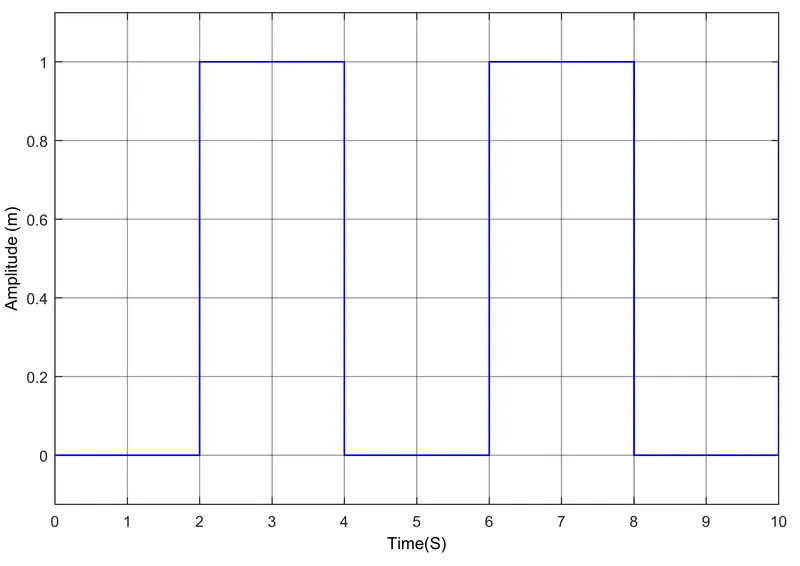
- To create a situation where the switch is closed for 2 seconds and then released. To observe the physical movement of the plunger.
Introduction:
Part 1: Doorbell
A simple construction of a doorbell is as shown in the figure [1] below.
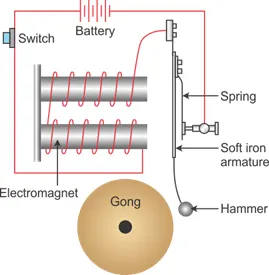
When the switch is pressed the circuit is completed and the electromagnet is activated which makes the hammer strike the bell. The armature is made of iron which attracts the magnet when the circuit is completed. This hammer is an iron ball that strikes on the bell. The iron armature is connected to the spring which maintains its position and not always in contact with the bell.
Solenoid:
A solenoid is nothing, but a copper wire wounded around the solenoid iron core which turns into a magnet when electricity is passed through it. The iron core demagnetises once the electricity is cut off [2]. A simple solenoid construction is shown in the figure below.
A solenoid is used in various fields such as in electrical appliances, automotive and aerospace applications, heavy machinery applications and much more. Solenoids are very beneficial as it has a very compact design plus having a controlled magnetic field which is only activated once the electricity is passed through it. The wire wrapped around the cylinder, the magnetic field because of the wires can become quite strong. More number of loops of wire stronger the magnetic field created. The formulae [3] for the magnetic field created inside the solenoid is as below:
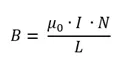
Where,
B = magnetic field (N/Amp m)
μ0 = permeability of free space
I = current (Amp)
N = number of loops
L = length of the solenoid
Modelling procedures:
Input:
Steps:
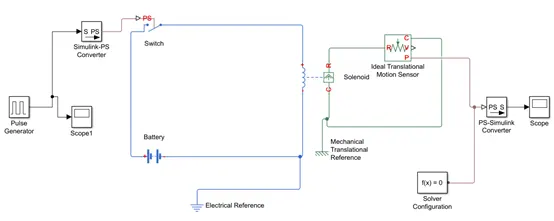
-A pulse generator is used to simulate the pressing of the bell switch ,it has a period of 4 seconds and a duty cycle of 50%,so it will remain open half of the wavelength and a delay of 2 seconds(not required)
-Then Simulink-ps converter is used to convert the Simulink signal to physical signal
-This is then connected to a switch controlled by external physical signal with all of its settings left in default, the switch is closed when it receives the signal, otherwise it is open
-This is connected to a battery and then the whole circuit is grounded by an electrical reference
-Then the battery and the switch were connected to the positive and negative terminals of the left side of the solenoid block, then the case terminal was connected to a mechanical translational reference, all the settings of the solenoid were left in default
-Then in order to detect the movement of the solenoid, an ideal motion translational sensor was used, its reference is connected to the reference of the solenoid and its case was connected to the mechanical translational reference, all of its settings were left in default
-Then a signal is taken from the p port which measure the displacement and connected to the solver configuration block which is required as each and every Simscape circuit needs to be attached with the solver configuration block as it specifies the solver parameters that the model needs before beginning the simulation
-then the signal is Converted to Simulink signal via ps Simulink converter ,and then it is connected to a scope to display it.
Output:
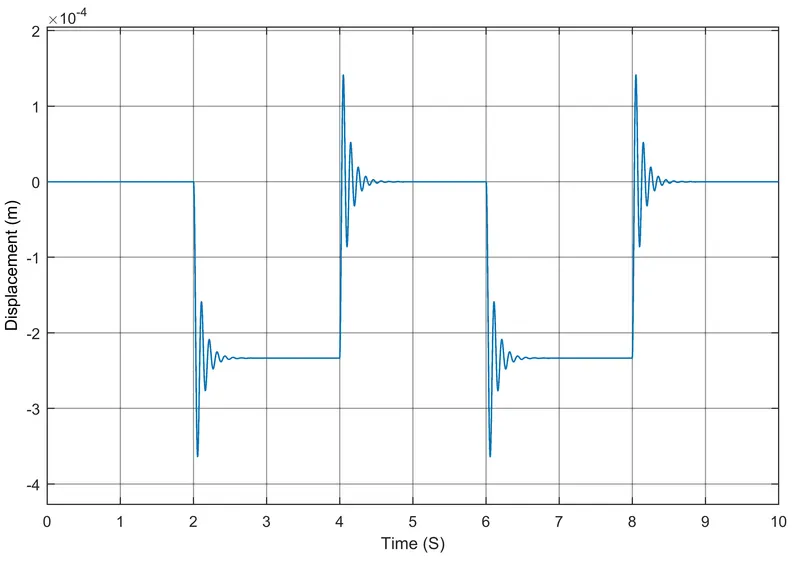 Figure:50 v solenoid rated output
Th output follows the input signal except for the flactuations related to the mass of plunger and spring stiffness and damping,the open flactuations can be damped it the solenoid rating voltage is the same as the battery 12v output
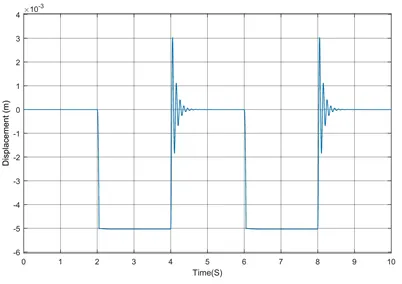 Figure:12v solenoid rated output
part 2: Fan control:
AIM:
- To simulate working of a fan under different conditions using a Thermistor in Simulink.
Objective:
- To turn on the fan if the temperature is above 25 °C else off. To use the temperature source to simulate temperatures, from 0 to 10 seconds at 20°C, from 10 to 30 seconds at 27°C and from 30 to 50 seconds at 23°C.
Introduction:
Thermistor is a thermally sensitive resistor which exhibits a precise and predictable change in resistance proportional to small changes in the surrounding temperature. The word “Thermistor” is derived from “thermally sensitive resistor”, whose resistance change with the change in temperature. Thermistors are very sensitive to the change in temperature therefore they are perfect to detect the changes in the temperature while recording the temperature or to operate electrical appliances such as AC, fan, oven, automotive and aerospace applications. There are a vast range of applications where thermistors can be used, and different sizes and shapes of thermistors are available in the market depending upon the applications. There are mainly two types of thermistors, NTC and PTC [4].
NTC: Negative Temperature Coefficient Thermistor
PTC: Positive Temperature Coefficient Thermistor.
In this study NTC type thermistor is used. This thermistor uses the B-parameter equation, where the resistance at temperature T is given by:
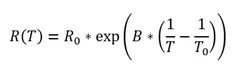
Where,
R0 = nominal resistance at the reference temperature
T0 = reference temperature
B = characteristic temperature constant
T = sensed temperature
The default values of R0, T0, and B in the thermistor block of Simulink are 1000 Ω, 298.15 K, and 3500 K, respectively.
Experimental model:
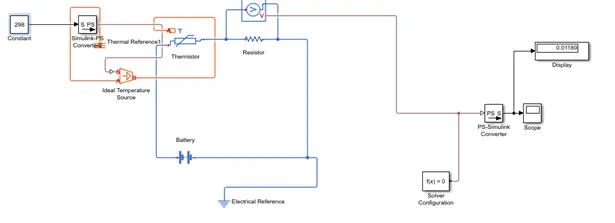
In order to now the voltage that the thermistor will supply with it senses the temperature of 25 degree Celsius which is the temperature required to operate the fan, and experimental model was first constructed
Steps:
-A constant is used to provide the required control temperature in kelvin for the thermistor
-Its signal is then converted to physical signal via simulink ps converter and then connected to a controlled temperature source which takes the physical signal t the s port and then its inlet A port is connected to a thermal reference and its output B port is connected to the A thermal port of the thermistor
-Then the positive and negative terminal of the thermistor were connected to a battery and to a resistor and all the circuit were grounded by electrical reference and all the setting of the thermistor were left in default
-In order to sense the voltage ,a voltage sensor was used and its positive and negative terminal were connected to the respective terminals of the resistance, and a is output voltage signal was connected to the solver configuration block and then converted to Simulink signal and then shown on a display
-it was found that this value is 0.01189 volt
Full fan model:
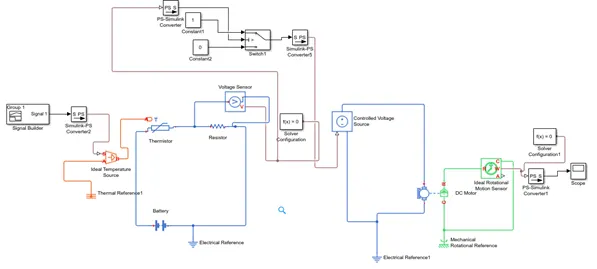
Modifications to the experimental model:
Input:
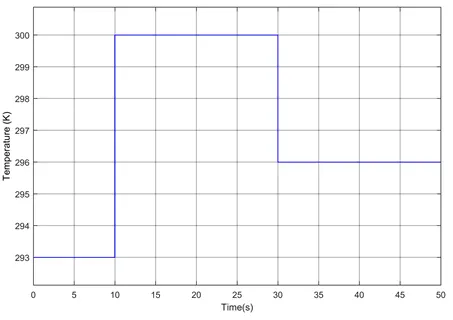
steps:
-Signal builder is connected instead of the constant where a signal of time value [0 10 10 30 30 50] and a temperature values of [293,293,300,300,296,296] were used to generate a signal
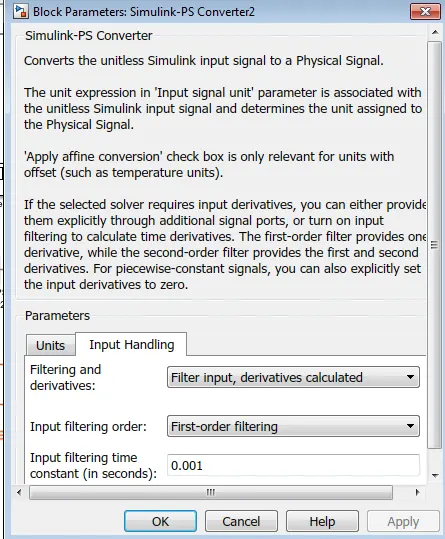
-The simulink ps converter was configured differently to take the first derivatives in order to provide enough inputs and to provide the derivatives required
-Also the voltage sensor output was connected to a switch that only opens at the threshould voltage which is configured at 0.01189 voltage,so it will change the ouput from zero to one which are represented by the constants when it receives a signal with a value greater than the threshould ,then the signal is converted to a physical signal to control the voltage source
-This was then connected to control voltage source ,which is connected to a positive and negative terminal on the left side of a dc motor which represents a fan
-This circuit was then grounded to electrical reference
-Then on the left part of the dc motor block its c (case) port was connected to a mechanical rotational reference. And in order to detect and measure the angular velocity of the motor, its r port was connected to the r port of ideal rotational sensor.
-then the case port was connected to the same mechanical rotational reference as the case of the motor
-Then the output was taken from the w port which measures the angular velocity, then this as connected to the solver configuration block as each circuit should be connected to one
Then its signal was converted to Simulink signal and then it was displayed on a scope
-Then simulation time was changed to 50 seconds to capture all the events
output:
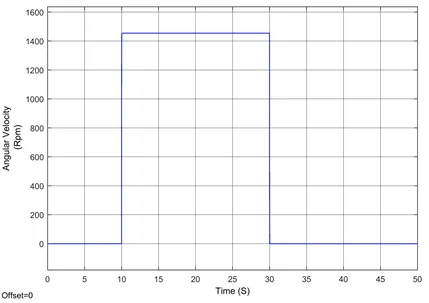
An output scope plot shown below depicts that when the temperature reached above 25°C, the DC Motor representing the fan was off for initial 10 seconds and then started working at 10th second showing around 1454.399 RPM of the motor and then, the motor turned off after 20 seconds at 30th second for the remaining 20 seconds of the time till 50th second.
Errors during modelling:
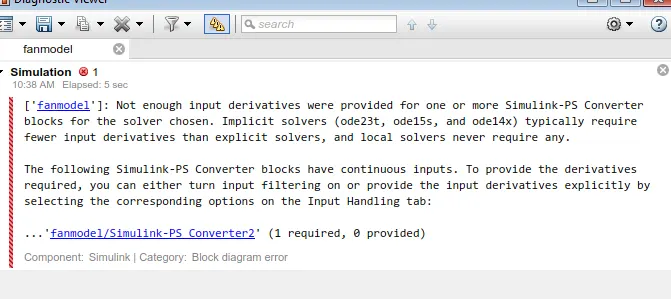
This error happened during modeling and it was dealt with by changing the default input signals to filter input,derivatives calculated in input handling menu in the simulink ps converter block
Conclusion:
It can be concluded that both the studies were a success where outputs observed were:
- When a doorbell rang, a deflection was observed in the scope plot.
- When the DC motor turned on and off when there was temperature difference was noticed by the thermistor and the switch and the RPM of the motor was observed in the scope plot in the end.
Models:
https://drive.google.com/file/d/1UhVJSuULcrL891kLH8HExGqy86TicqM6/view?usp=sharing
https://drive.google.com/file/d/1Wfu4pYILxgPABK0mG1RHN_VVH23TOdPT/view?usp=sharing
Reference:
Matlab help