Project - Speed Control of a Direct Current (DC) motor
Aim : to design a project- - Speed Control of a Direct Current (DC) motor by using the Proportional, Integral, and Derivative (PID) control design knowledge gained in the training to design, develop and test a controller to maintain a desired speed for the motor.
- As per the project Speed control of a DC motor is either done manually by the operator or by means of an automatic control device.
- This is different to speed regulation where the speed is trying to be maintained or regulated against the natural change in speed due to a change in the load on the shaft
-
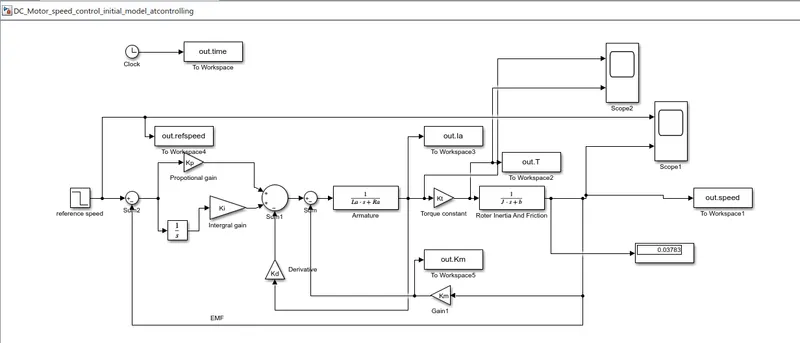
so the speed can be varied by changing by PID controller as shown in the program and also shown in my model below .
Initial Command
clear All;
clc;
J = 0.01; % Moment of inertia of the rotor in kg-m^2
b = 0.1; % Motor viscous friction constant in N-m-s
Km = 0.01; % Back EMF constant in v/rad/s
Kt = 0.01; % Motor torque constant in N-m/amp
Ra = 1.0; % Resistance of the armature circuit in ohms
La = 0.5;
Kp=0; Kd=0; Ki=0; %for initial speed I keep all values on zero
Initial Model
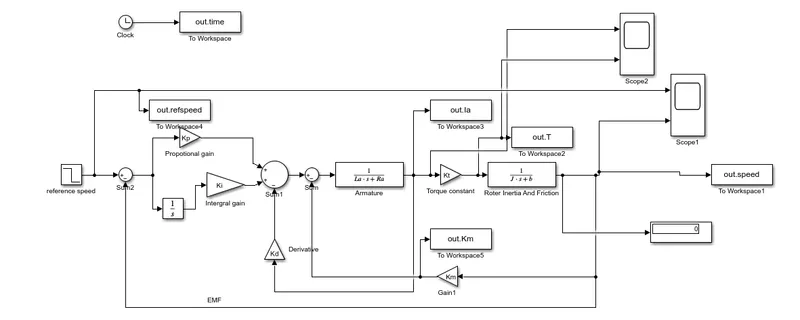
INITIAL SCOPE
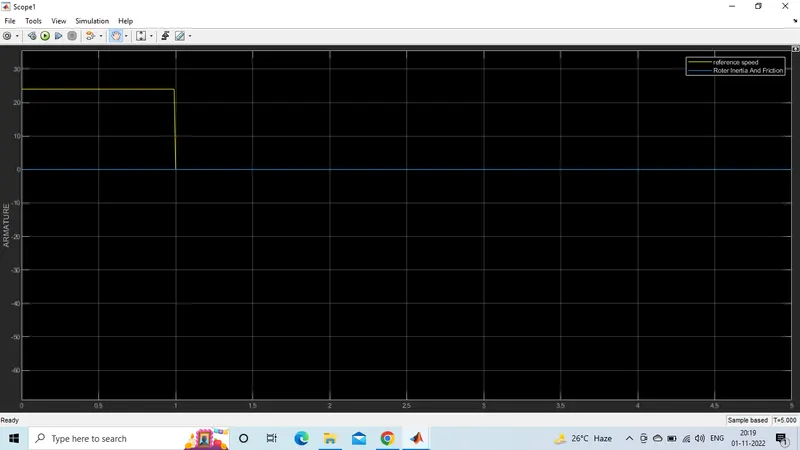
SPEED CONTROL Starting
Command changed with values of Kp, Kd, and Ki
clear All;
clc;
J = 0.01; % Moment of inertia of the rotor in kg-m^2
b = 0.1; % Motor viscous friction constant in N-m-s
Km = 0.01; % Back EMF constant in v/rad/s
Kt = 0.01; % Motor torque constant in N-m/amp
Ra = 1.0; % Resistance of the armature circuit in ohms
La = 0.5;
Kp=31.5; Kd=2.3; Ki=82.3; %for control speed
Now Model
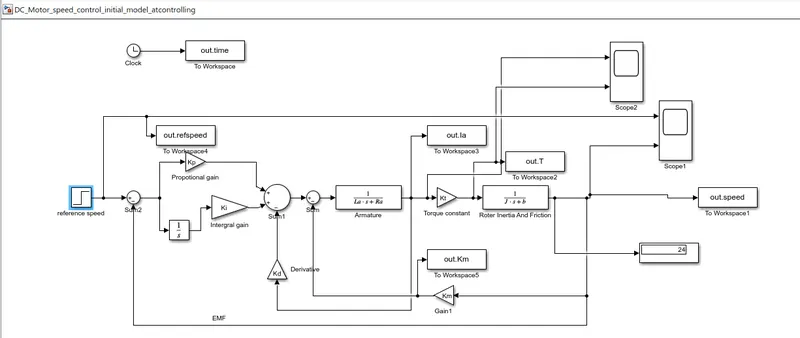
Scope with Refrence value zero to high
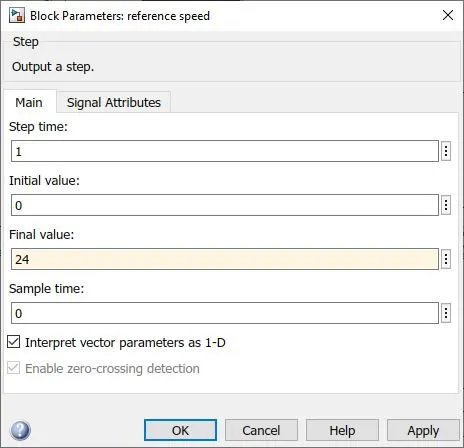
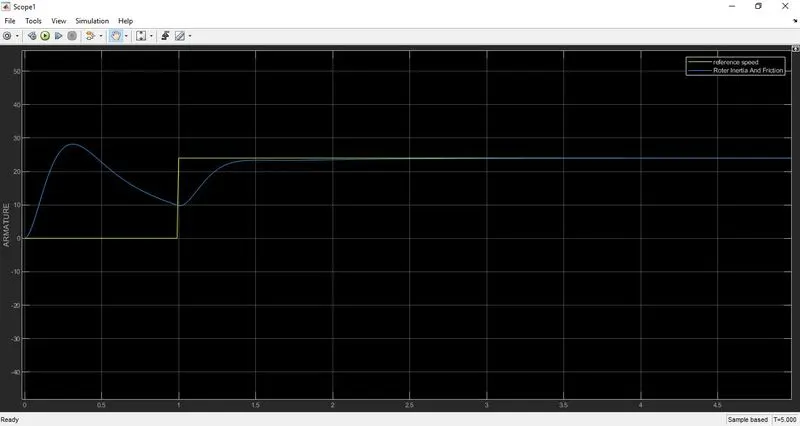
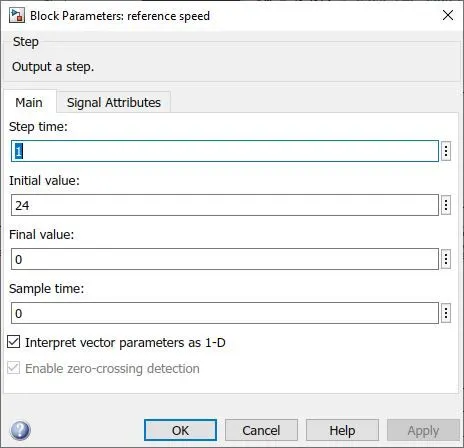
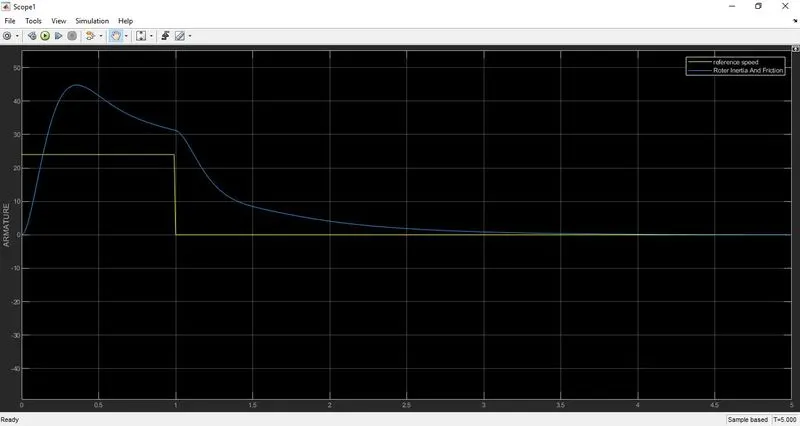
MODEL & Refrence Value High to zero