Project - Speed Control of a Direct Current (DC) motor
Project – Speed control of a DC Motor
Aim: To design a PID controller for the speed control of a DC Motor
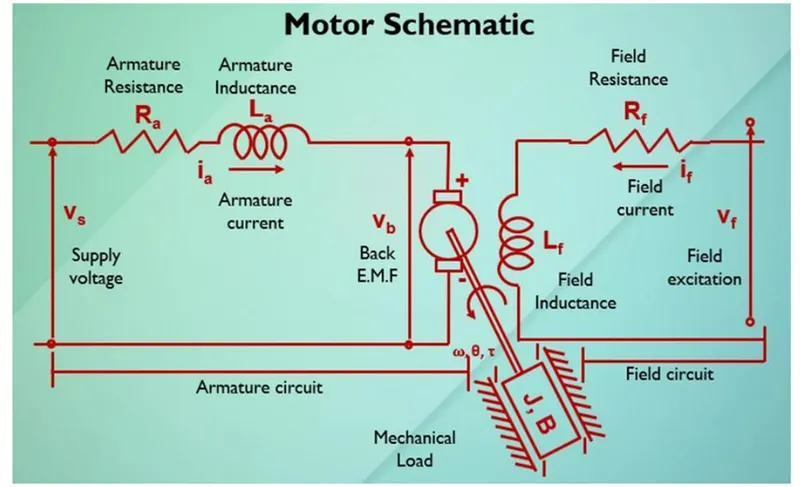
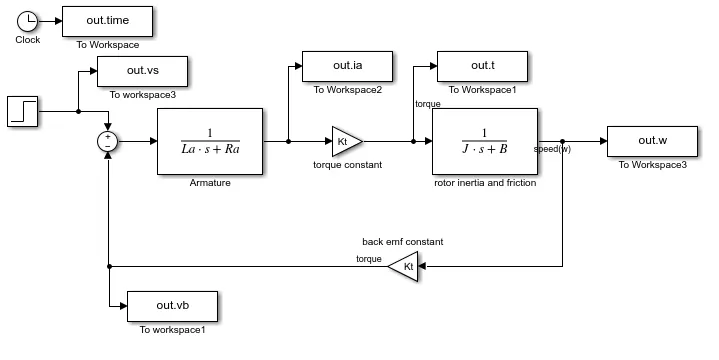
Objective: In this project, a Simulink model for the DC motor will be first developed per the schematic shown in Figure 1.
Use the Proportional, Integral, and Derivative (PID) control design knowledge gained in the training to design, develop and test a controller to maintain a desired speed for the motor.
Solution:
In this project, we have been tasked with designing a PID controller for the speed control of a DC motor. DC motors have speed-control capability, which means that speed, torque and even direction of rotation can be changed at any time to meet new conditions. PID controllers are commonly used to regulate the time-domain behaviour of many different types of dynamic plants. These controllers are extremely popular because they can usually provide good closed-loop response characteristics, can be tuned using relatively simple design rules, and are easy to construct using either analog or digital components. Consider the feedback system architecture that is shown in Fig. 1 where it can be assumed that the plant is a DC motor whose speed must be accurately regulated.
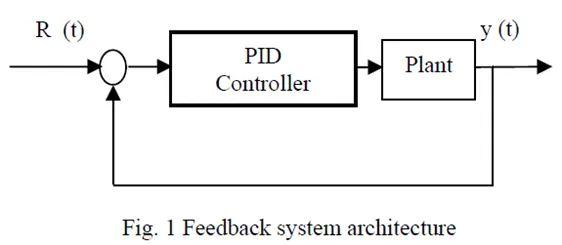
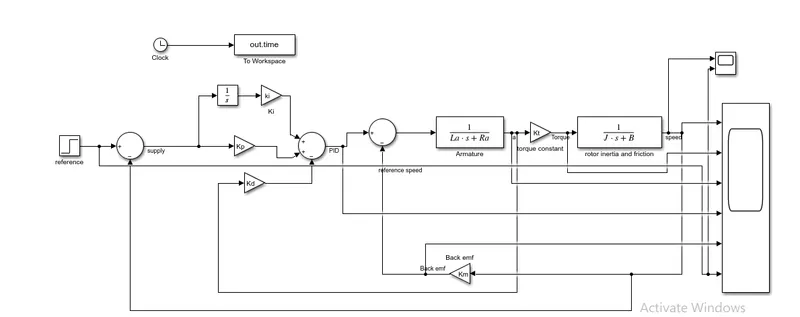
The PID controller is placed in the forward path, so that its output becomes the voltage applied to the motor's armature. The feedback signal is a velocity, measured by a tachometer. The output velocity signal y (t) is summed with a reference or command signal R (t) to form the error signal e (t). Finally, the error signal is the input to the PID controller. The PID controller is defined by the following relationship between the controller input e (t) and the controller output u (t) that is applied to the motor armature:
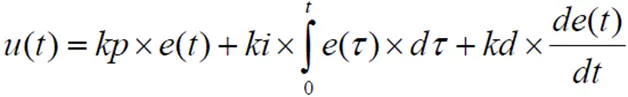
The electric circuit of the armature and the free body diagram of the rotor are shown below:
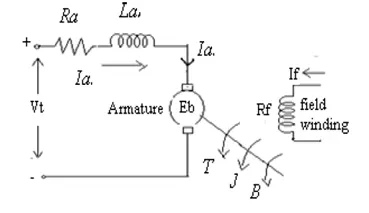
where, Ra=Armature Resistance,
La=Armature self inductance caused by armature flux,
ia= Armature current,
if= field current,
Eb=Back EMF in armature,
Vs =Applied voltage,
T=Torque developed by the motor,
θ = Angular displacement of the motor shaft,
Ј =Equivalent moment of inertia of motor shaft & load referred to the motor,
B= Equivalent Coefficient of friction of motor shaft & load referred to the motor.
Applying Kirchoff’s voltage law to the circuit,
Vs = Ra * ia + La * dia / dt + Vb ……….. (1)
Also, Eb = Kb * dθ/dt ………….. (2)
We know the torque and armature current equation to be,
T = Kt * ia ………….. (3)
where, Kb = back emf constant
Kt = torque constant
Also, torque is given by,
T = J*d2θ/dt2 + B * dθ/dt2 ………(4)
Taking the Laplace transform of the above equations,
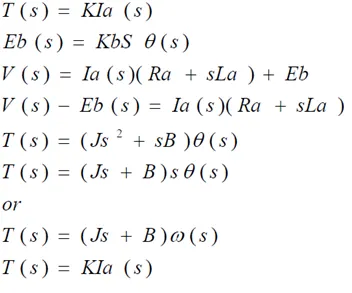
The transfer function based on the above transform can be given as:

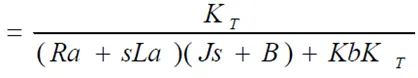
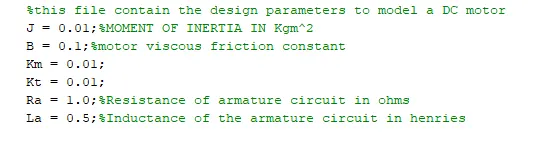
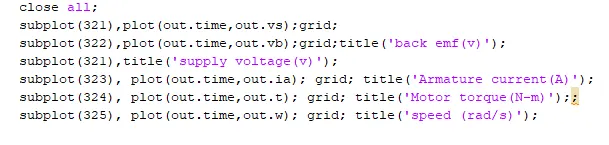
For building the Simulink models, I have taken into consideration the transfer functions as well as the differential equations and have built two models accordingly. The control here is for the output speed of the motor and the same has been set at 2000rpm.
SIMULINK OF DC MOTOR:
SIMULINK MODEL OF DC MOTOR WITH PID CONTROLLER:
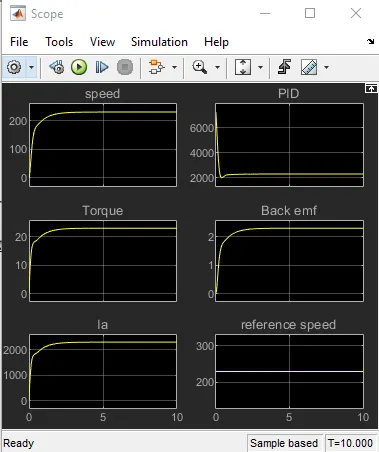
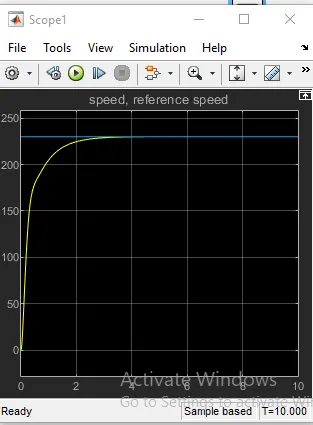
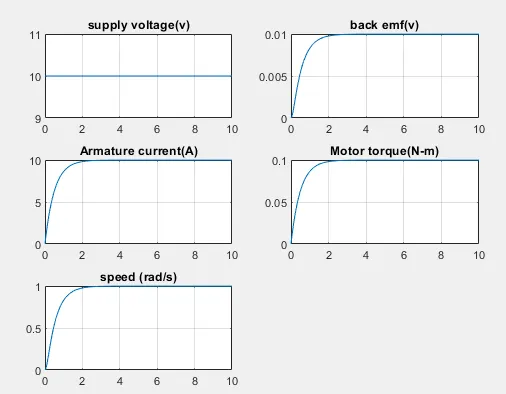
SCOPE OUTPUT OF THE ABOVE MODELS:
OUTPUT OF DC MOTOR
OUTPUT OF PID CONTROLLER MODEL