Project - Position control of mass spring damper system
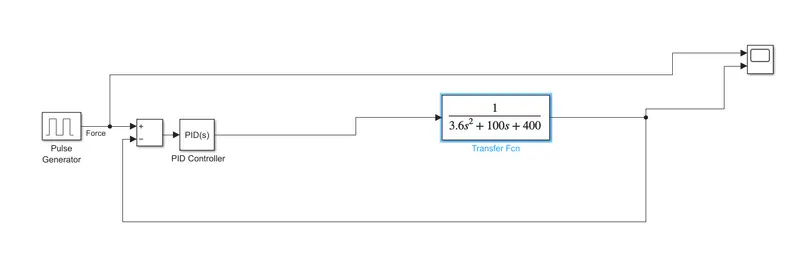
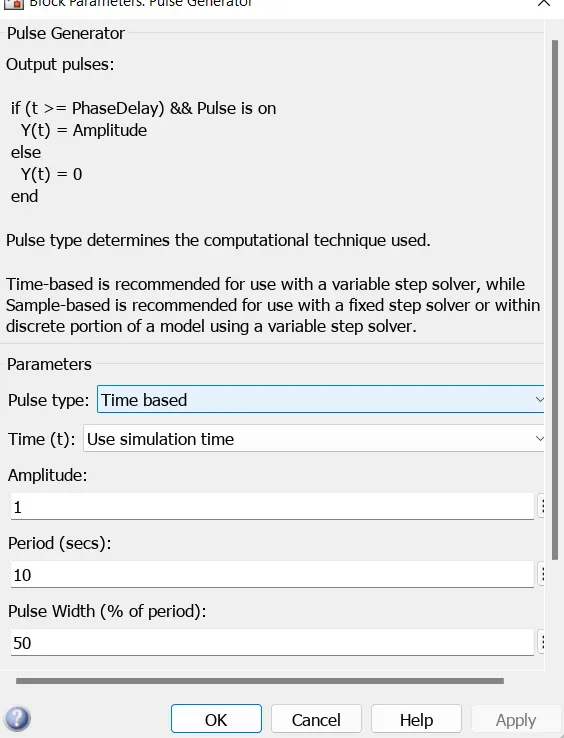
This is input signal which we have provided it contains all input values
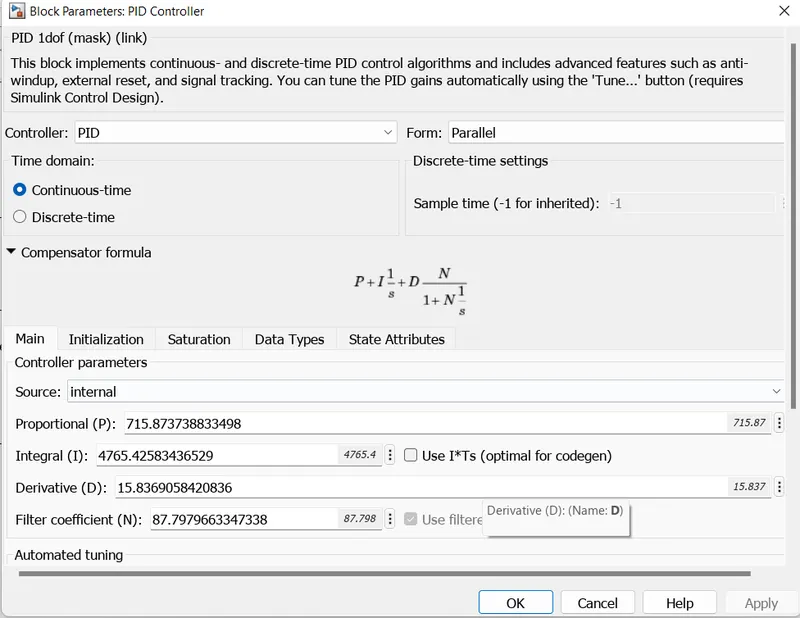
This is PID controller and contain all values(Kp,Kd,Ki).
PID controller:
This block implements continuous- and discrete-time PID control algorithms and includes advanced features such as anti-windup, external reset, and signal tracking. You can tune the PID gains automatically using the 'Tune...' button (requires Simulink Control Design)
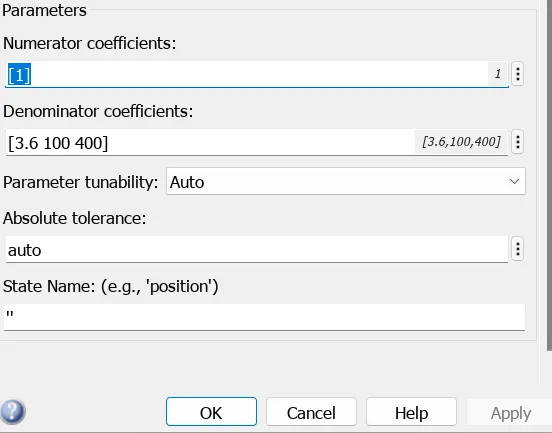
this is TRANSFER function block and shows all input value in it
TRANSFER FUNCTION BLOCK:
The numerator coefficient can be a vector or matrix expression. The denominator coefficient must be a vector. The output width equals the number of rows in the numerator coefficient. You should specify the coefficients in descending order of powers of s.
'Parameter tunability' controls the runtime tunability level for numerator and denominator coefficients.
'Auto': Allow Simulink to choose the most appropriate tunability level.
'Optimized': Tunability is optimized for performance.
'Unconstrained': Tunability is unconstrained across the simulation targets.
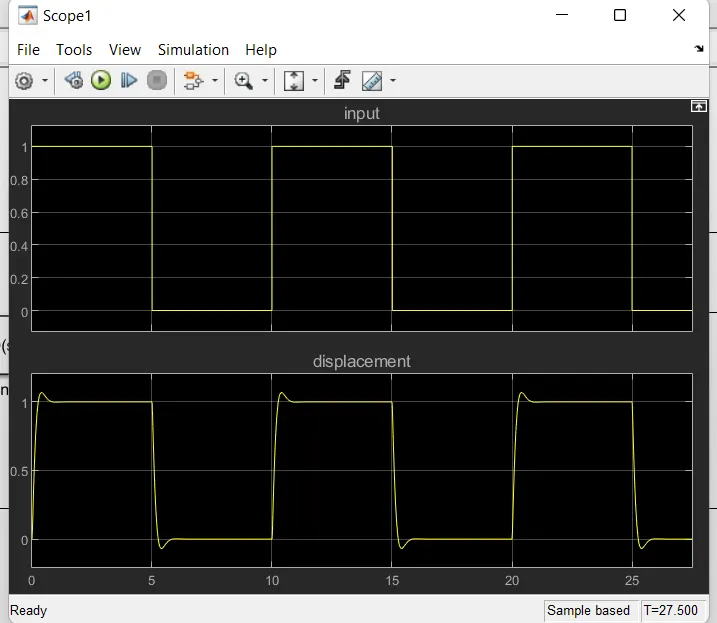
the scope shows input signal is shown in 1 and output signal is shown in displacement side and showing the signal is controlled