Project - Position control of mass spring damper system
Obtain the transfer function of a mass spring damper system and use it in the model. Add a PID controller to adjust the force on mass so that its position follows a reference signal.
Take m = 3.6; %kg k = 400; %N/m c = 100; %Ns/m
From the above values help we can find zeta,wn,fn,p1,p2,kp,kd which was shown below;
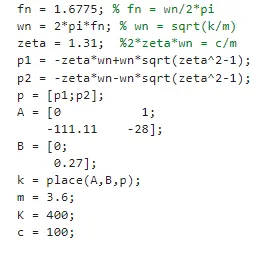
kp = -0.0648 kd = - 1.4262 p1 = -4.8882 p2 = -22.7267
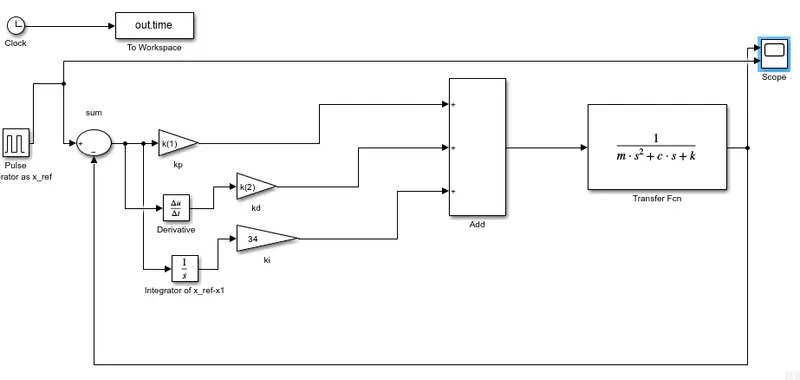
The block diagram is shown below;
GRAPH:
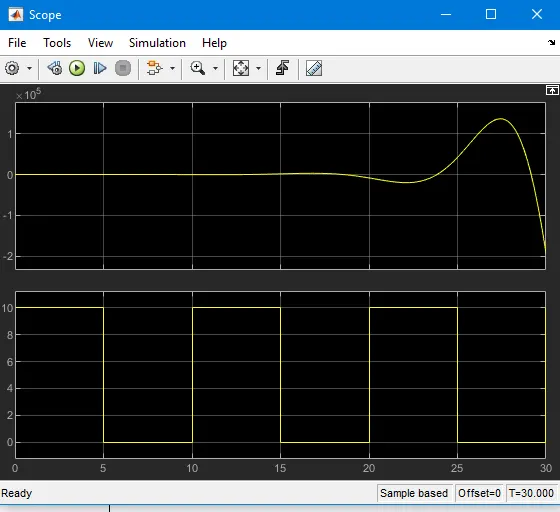
SUMMARY: THe above block diagram shows that representation of transfer function of spring mass damper system along PID controllers. Before developing a block diagram we need to find the values zeta,fn,wn,kp,kd,poles with the help of values m = 3.6,c=100,k=400 and that formulas is shown above in the matalb script model from above. In the block diagram the o/p is act as feedback signal to the motor in order to get the error signal.
THANK YOU!