Project - Position control of mass spring damper system
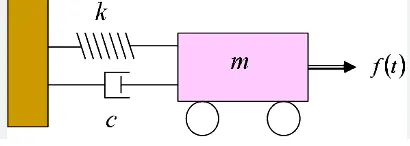
f(t)=force applied in mass
m=3.6 kg
c=100 Ns/m
k=400 N/m
the transfer function is
f(t)=m(dx^2/dt^2)+ c(dx/dt) + kx
put laplace transfer in that equation is
z(s)/f(s)=1/ms^2+cs+k
the this equation to state space
we got
A=[0 1;-k/m -c/m]
B=[0;1/m]
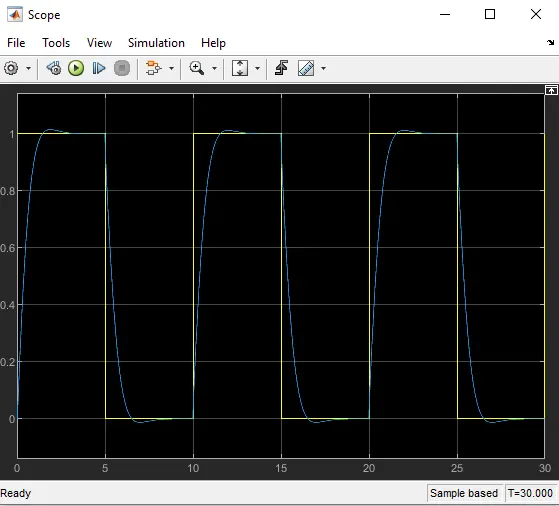
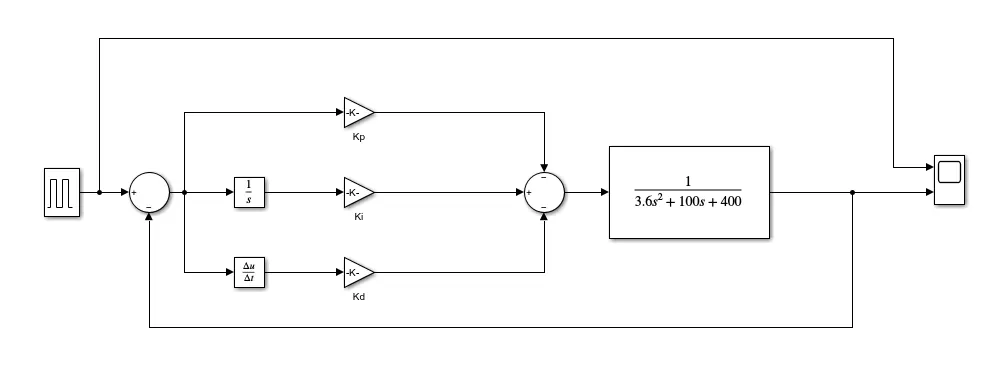
we set pulse generator as x_refence as shown..the pulse width is 50% for run time 30 sec
we put all vlaue directly in the transfer funtion.
we take zeta =0.5 for a under damped system
the matlab programing is
m=3.6; %mass
c=100;�mping constant
k=400; %spring co-eficient
A=[0 1;-k/m -c/m]; %vector for transfer function
B=[0;1/m]; % vector for transfer function
zeta=0.5; %under damped syatem
fn=1; % natural frequency
wn=2*pi*fn; %natural frequency
P1=-zeta*wn+wn*sqrt(zeta^2-1); % value for p1
P2=-zeta*wn-wn*sqrt(zeta^2-1);% value for p2
P=[P1,P2]; �fine p vector
K=place(A,B,P); % place command for kp and kd value
the kp and kd value are [-2.578776966243133e+02,-77.380532894153490]
we set ki to 900 for a minimize the error and got a stable system
the simulink model is
we got the output is