Project - Position control of mass spring damper system
Ans:-
The Transfer function for spring mass damper system is X(s)/F(s)=1/ms^2+cs+k where X(s) is displacement of the position wrt the force acting on the mass. F(s) is the force applied on the mass.m is mass=3.6kg, c=damping constant=100Ns/m, Spring constant=400 N/m.
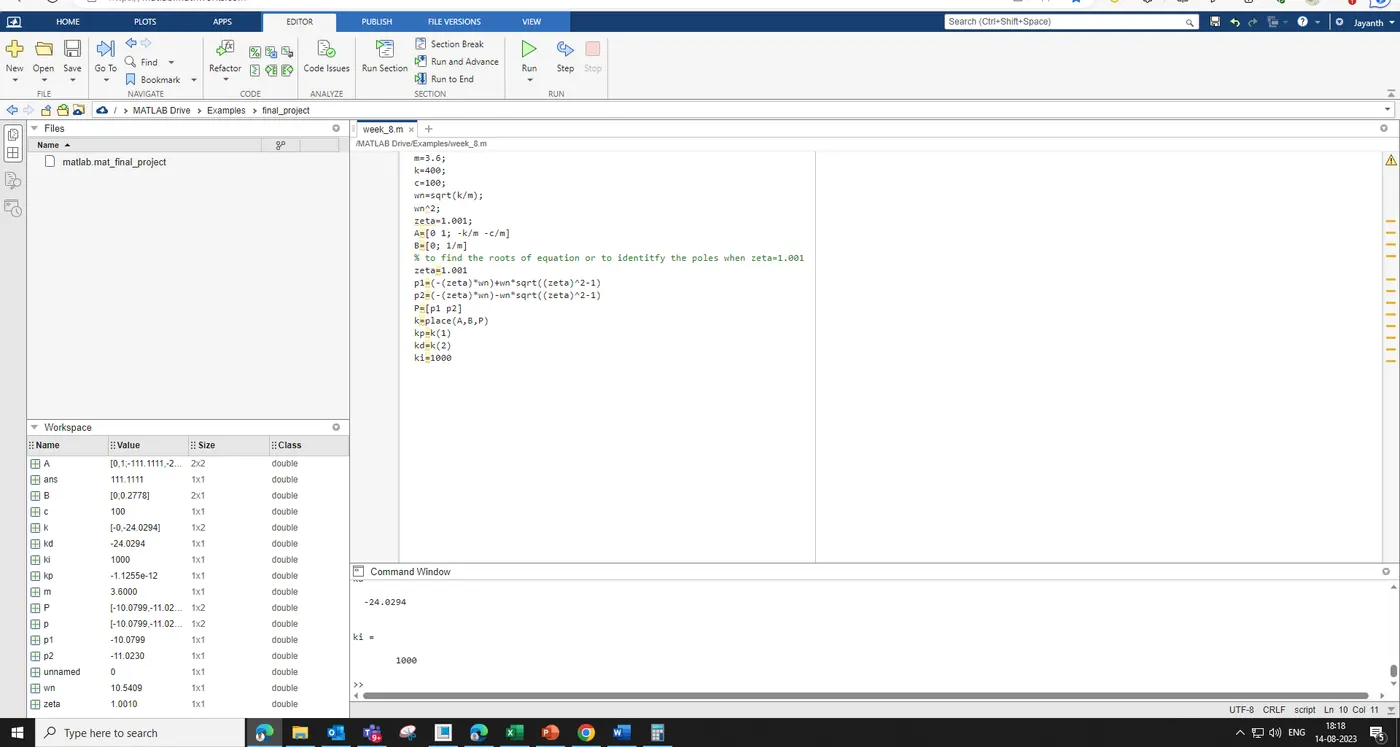
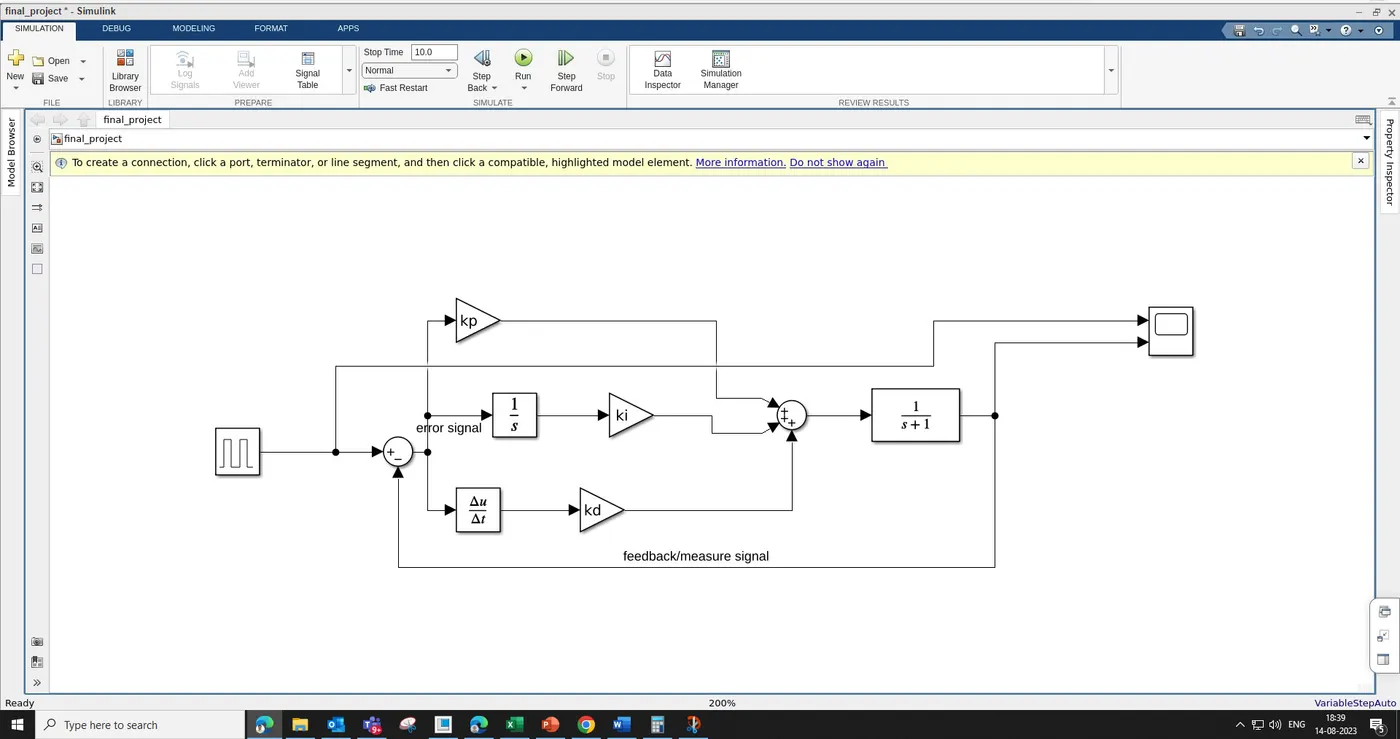
To control the displaced position of the mass after the force acting on it, we have to use PID controller. Here zeta value=1.001(critically damped condition) is considered by using zeta value Poles(P1,P2) are calculated and then Calculate kp (Proportionality constant),Kd (differntial constant) by using the place command. Ki value is manually modified to control the output wrt input.
Here input is pulse generated signal with amplitude of 1 and period of 10. as given in qusn.
The script file written to find the poles , kd and kp value is below.