Project - Position control of mass spring damper system
Aim :
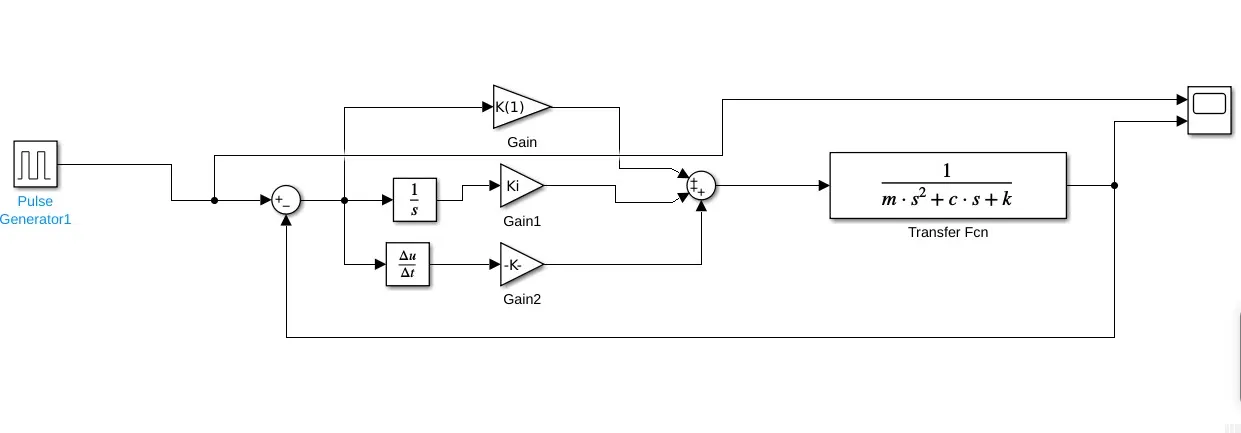
To design the project of position control of mass spring damper system using matlab simulink model of transfer function of a mass spring damper system and use it in the model. Add a PID controller to adjust the force on mass so that its position follows a reference signal.
Steps:
1.we build spring mass damper systerm using PID controller blocks Proportional, Integral, Derivative blocks.
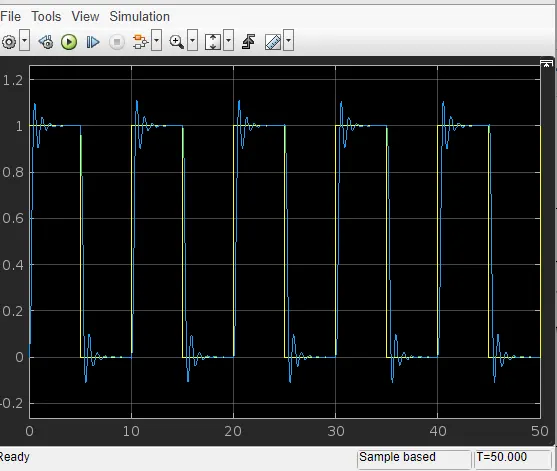
2.We give input signal through pulse generator and we get referal signal in the scope.
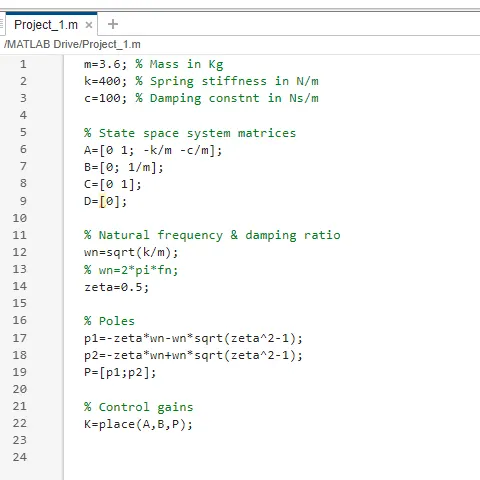
3.we get Kd,kp values by using pole method, and we gave Ki =1500 and we run the simulink.
Simulink model:
M-Script:
<![endif]-->
<![endif]-->
<![endif]-->
<![endif]-->
Conclusion :
To complete the project of Position control of mass spring damper system transfer function of a mass spring damper system and use it in the model. Add a PID controller to adjust the force on mass so that its position follows a reference signal to using matlab and simulink wave from plot.
<![endif]-->