Project - Position control of mass spring damper system
Obtain the transfer function of a mass spring damper system and use it in the model. Add a PID controller to adjust the force on mass so that its position follows a reference signal.
Take m = 3.6; %kg k = 400; %N/m c = 100; %Ns/m
The reference signal is shown in the following figure.
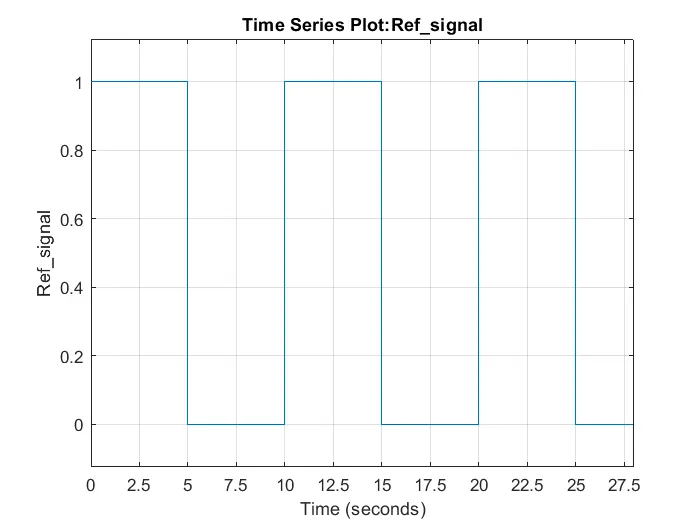
answer:
Aim:
To Obtain the transfer function of a mass spring damper system and use it in the model. Add a PID controller to adjust the force on mass so that its position follows a reference signal.
given data:
Take m = 3.6; kg k = 400; N/m c = 100; Ns/m
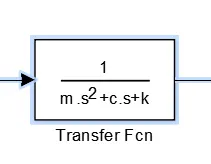
Here, our spring mass damper system is design by applying transferfunction to physical model as per previous case,
pid controller is design using pole placement method,ki is taken by adjusting the number
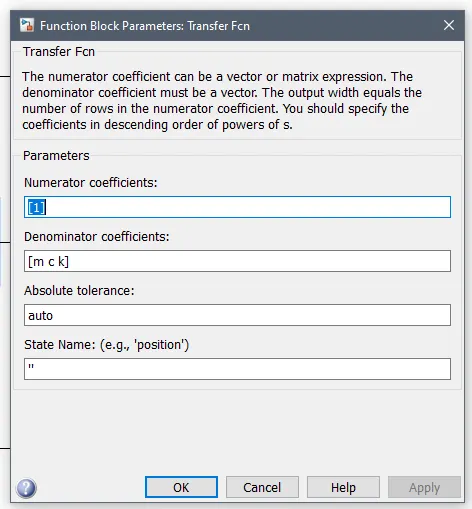
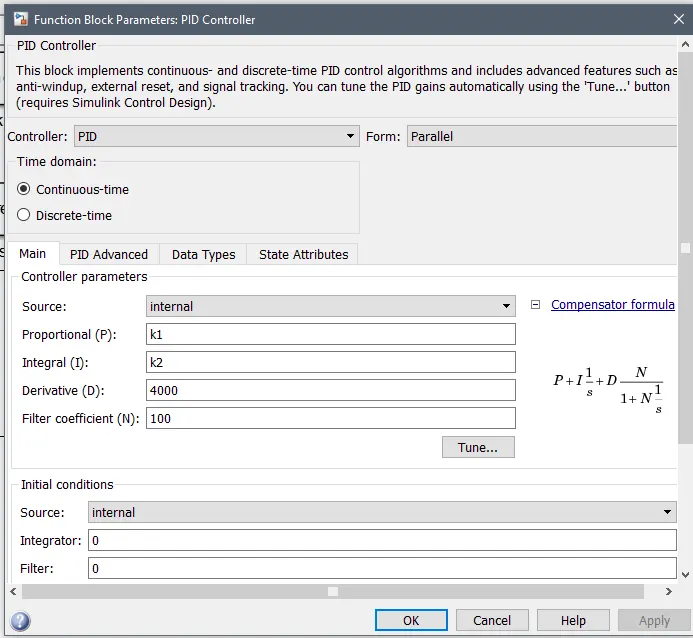
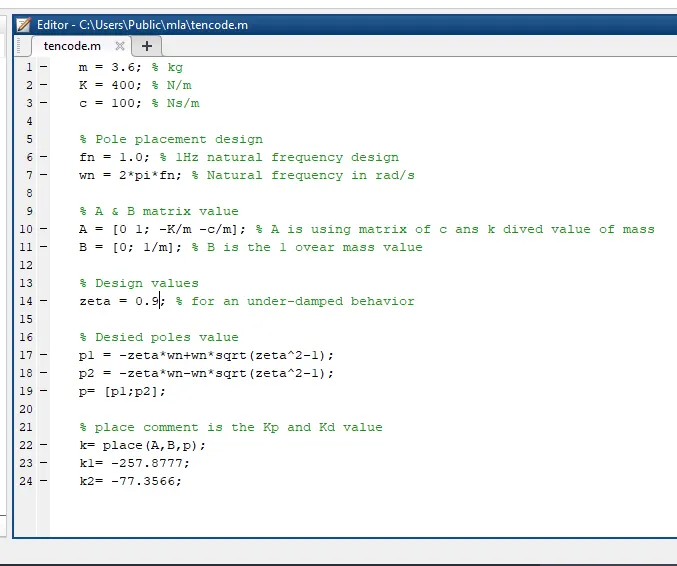
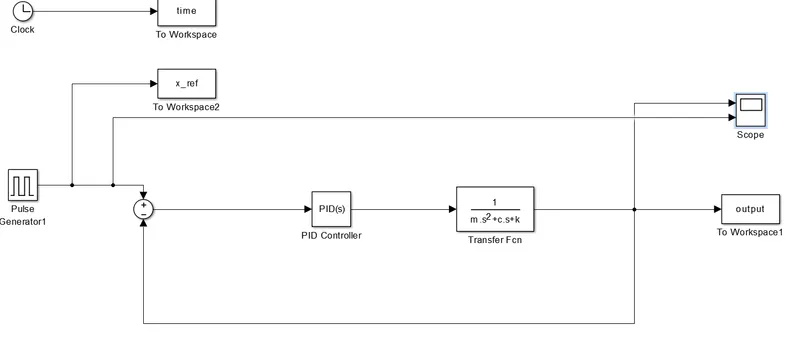
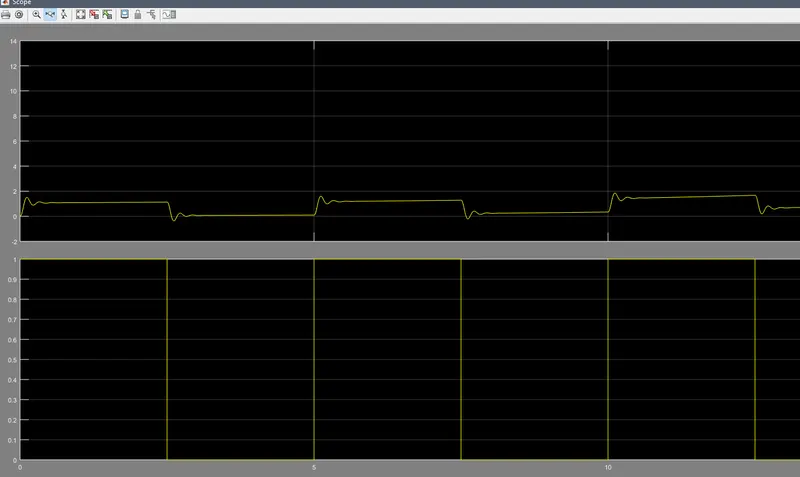
To complte the project of Position control of mass spring damper system transfer function of a mass spring damper system and use it in the model. Add a PID controller to adjust the force on mass so that its position follows a reference signal to using matlab and simulink wave from plot.