Project - Position control of mass spring damper system
The Block Diagram for the Project is
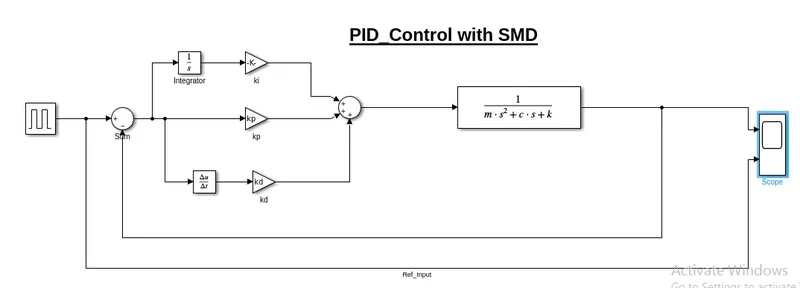
The Initial condition for the Model is Transfer function of Spring Mass Damper System by adding the PID control.
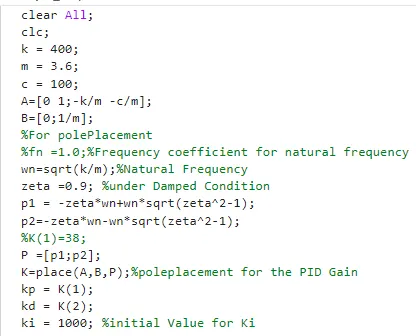
Here the Input Condition I have taken the Placement Comand for the Proportionality and derivative gain values using the "ki value as 1000" for settling the rise time less than 5% and Overshoot value less than '1'.
The Initial Reference signal is set with
Amplitude =1, timeperiod =10sec, pulsewidth size=50 ;
The design of PID block having the value using script file.
I have take jacobian Matrics of A ,B
Wn for natural frequency
Taken the Zeta value in under dampped condition.
The Ref signal is sending input along with error genrated feedback signal from the Transfer function block of System with input values.
Based on the Two inputs the PID Controller blocks send the Calculated value to System where it generate the Output signal
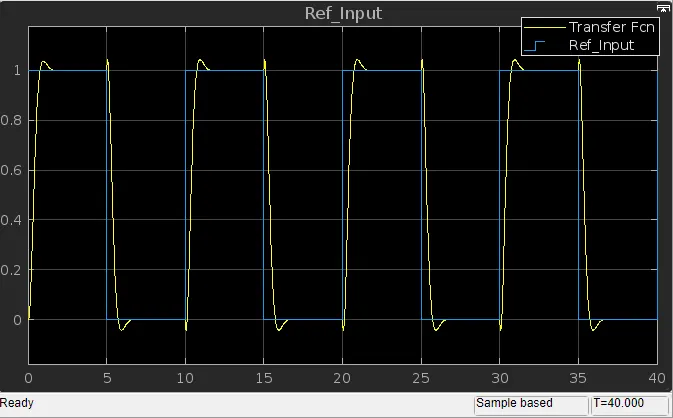
Output:-
Summary:
The final summary of this System is the Model for the Ref signal is accurate with output signal with less deviation with in the radians of controller.