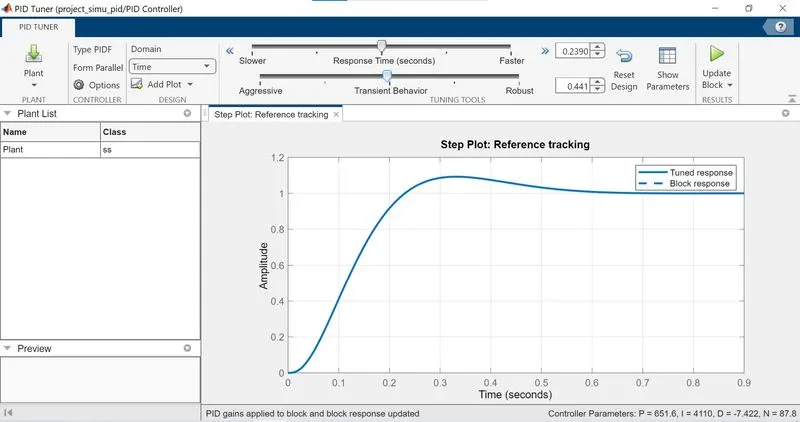
Project - Position control of mass spring damper system
using the values of m,k and c
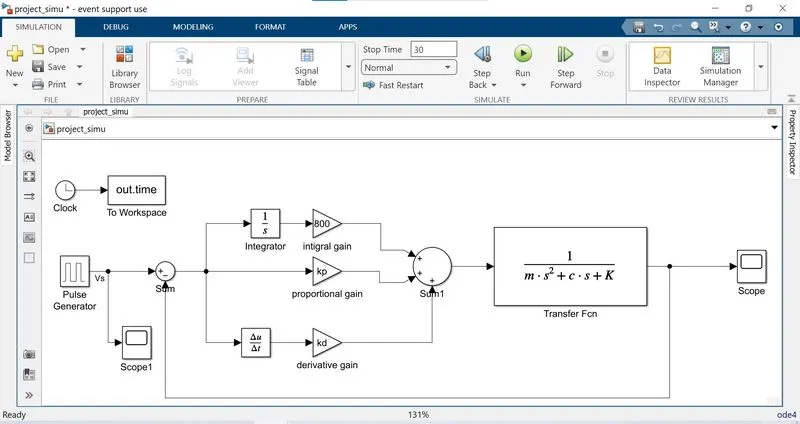
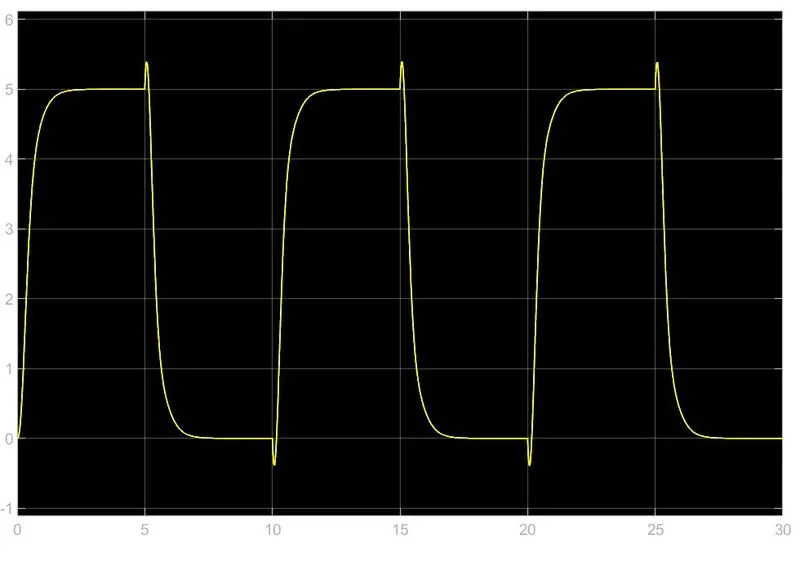
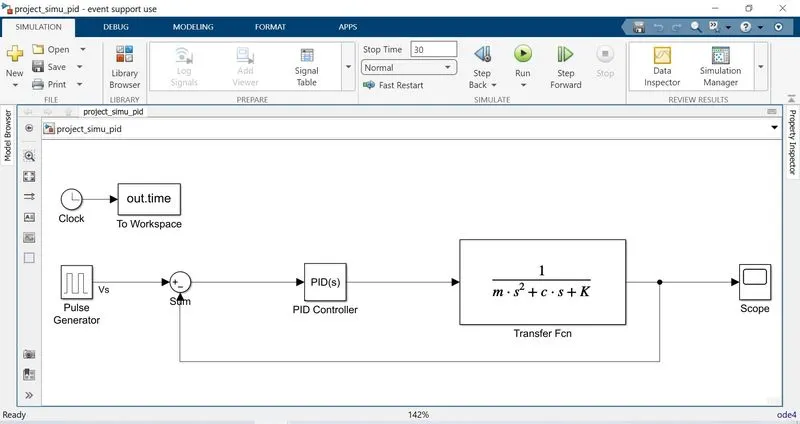
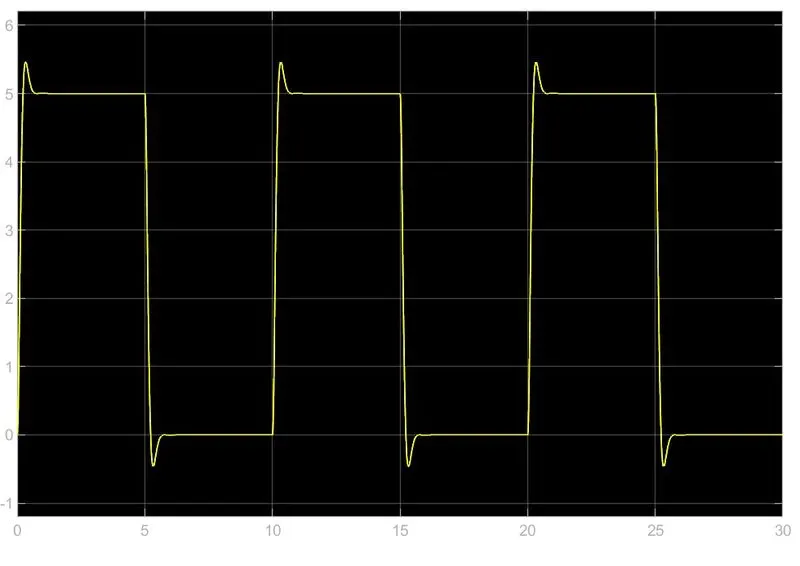
using place command and pid controler block respectively the output is displayed using scope
clear all;
clc;
m = 3.6 % kg
K = 400 %N/m
c = 100 %Ns/m
wn = sqrt(K/m);
z= 0.7; %z=c/2*m*wn
A= [0 1;-K/m -c/m];
B= [0;1/m];
p1=-z*wn+wn*sqrt(z^2-1);
p2=-z*wn-wn*sqrt(z^2-1);
p=[p1;p2];
k=place(A,B,p);
kp=k(1)
kd=k(2)