Project - Position control of mass spring damper system
1.Obtain the transfer function of a mass spring damper system and use it in the model. Add a PID controller to adjust the force on mass so that its position follows a reference signal.
Take m = 3.6; %kg k = 400; %N/m c = 100; %Ns/m
The reference signal is shown in the following figure.
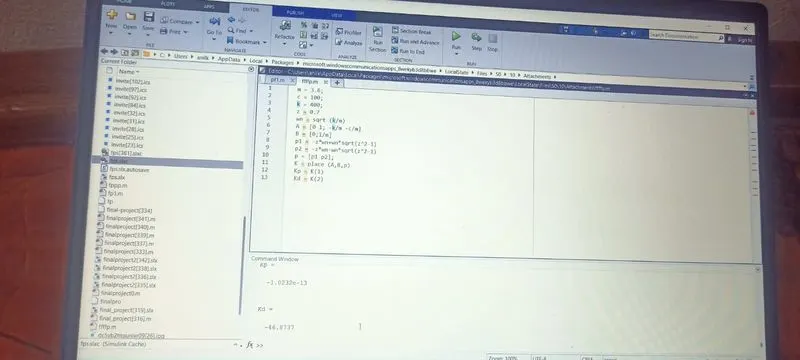
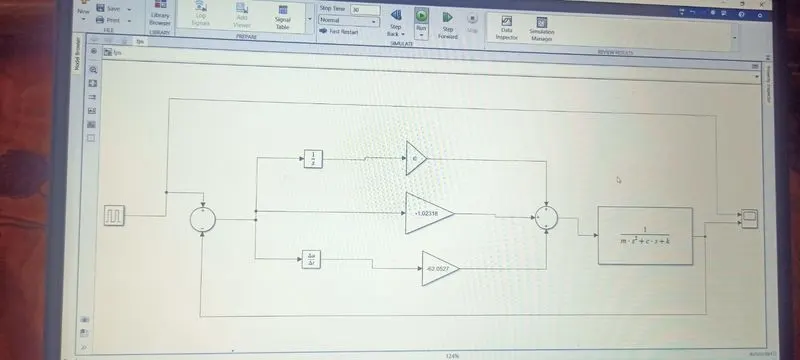
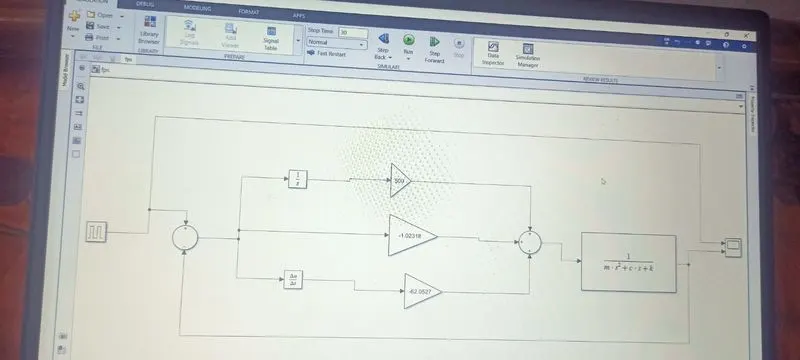
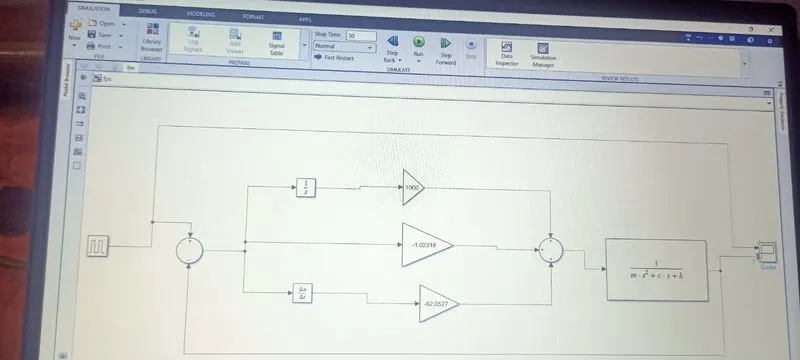
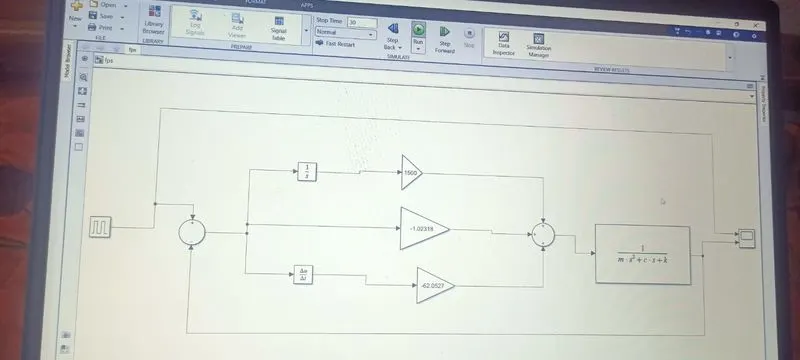
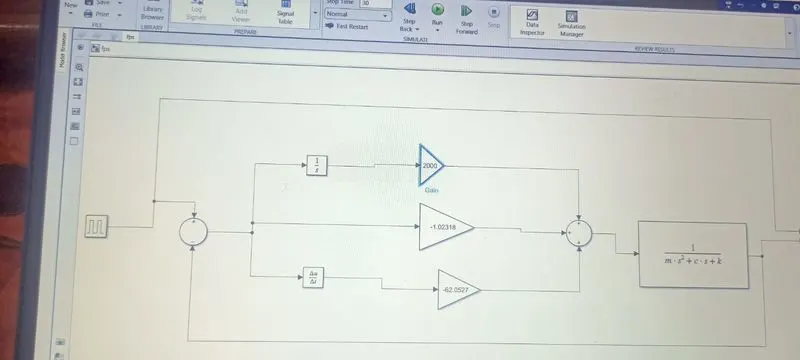
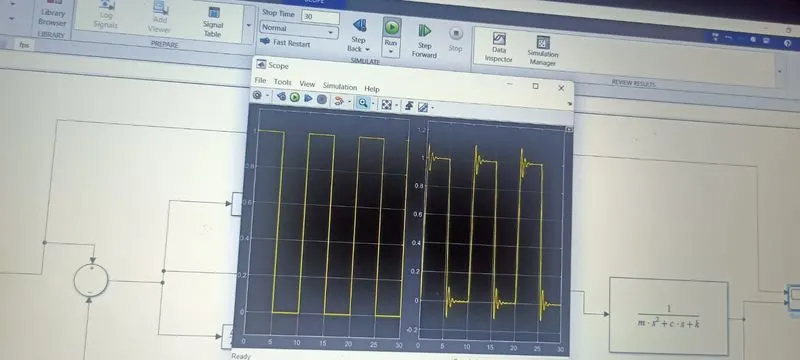
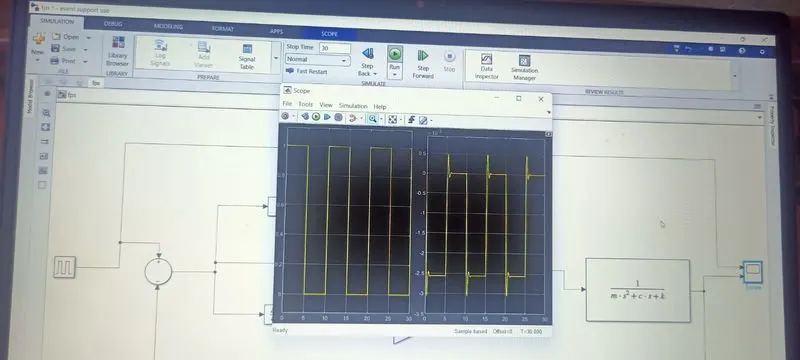
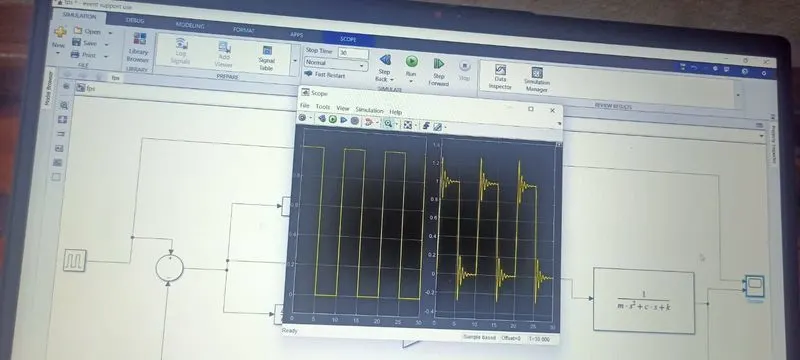
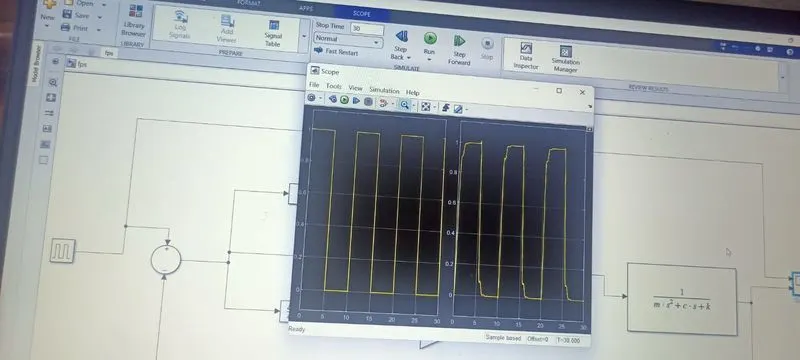
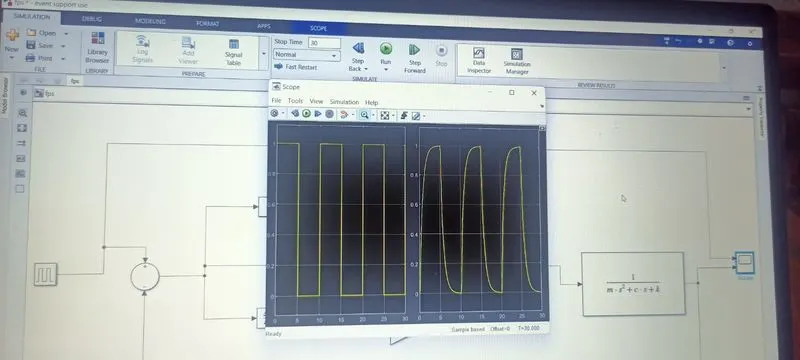
i am using some blocks and coding and some gain values ans transfor function block and scope block and integrator block and pulse generator block is main and finally different gain values like 0,500,1000,1500,2000 this are ki values