Project - Position control of mass spring damper system
Given :
Obtain the transfer function of a mass spring damper system and use it in the model. Add a PID controller to adjust the force on mass so that its position follows a reference signal.
Take m = 3.6; %kg k = 400; %N/m c = 100; %Ns/m
Step 1:
The transfers function of a mass spring damper is,1/(ms^2+cs+k).
here m,k and c value were given above.
To find poles assume wn(wn=sqrt(k/m) formula were used and consider zeta as 0.9 and following data were given below.
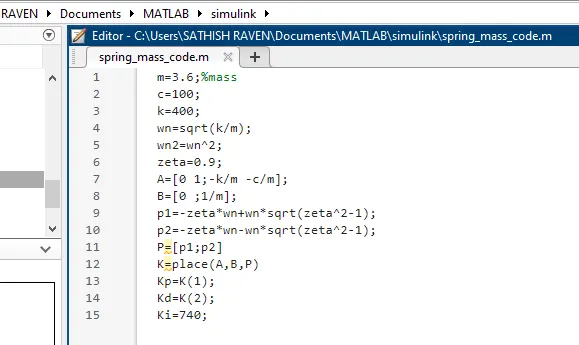
k is find by using above parameters resullt as shown below and named as kp and kd and ki should need to be asumed.
P =
-9.4868 + 4.5947i
-9.4868 - 4.5947i
K =
-0.0000 -31.6948....
Step 2:
After finding the kp and kd next step the model should need to built..
import the blocks from the library such as (pulse generator, clock,simout,scope, gain,sum and tansferfunction )
first import the transfer function block and enter the input as given below.
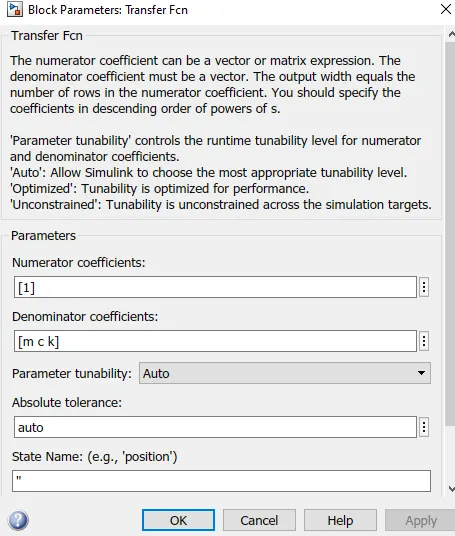
Step 3:
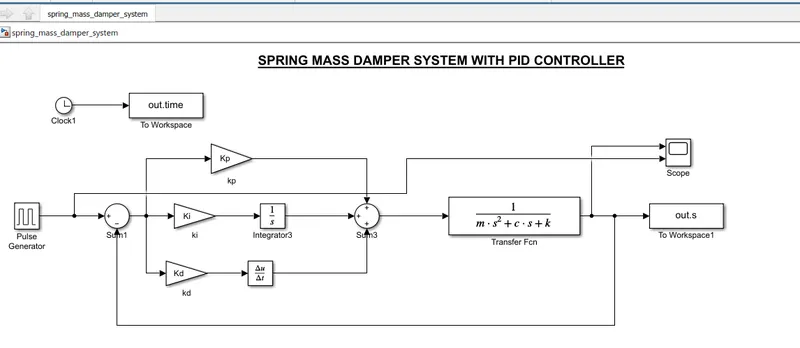
And inter linked with the PID controller given below.
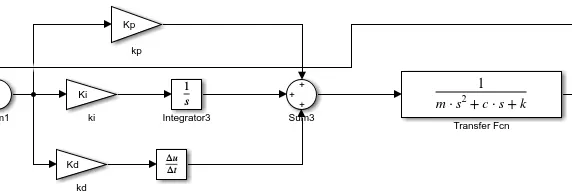
where PID controller were interlinked with refernce signal pulse generator
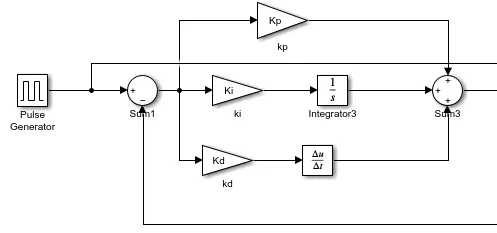
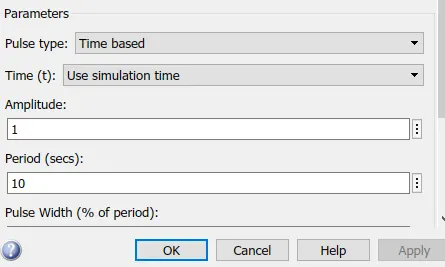
enter the input as given below in pulse generator.
Step 4:
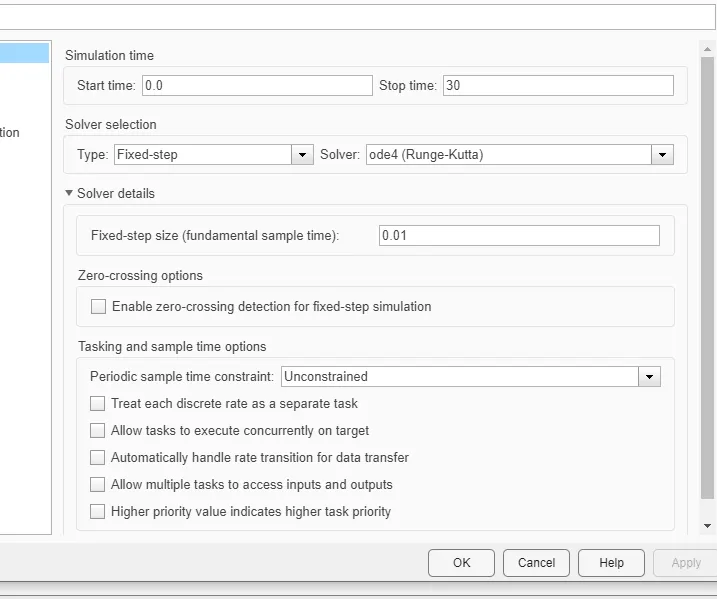
after the obtaining the model enter the model setting as given below start time and end time.
save and start run the model and the will be shown..
RESULT:
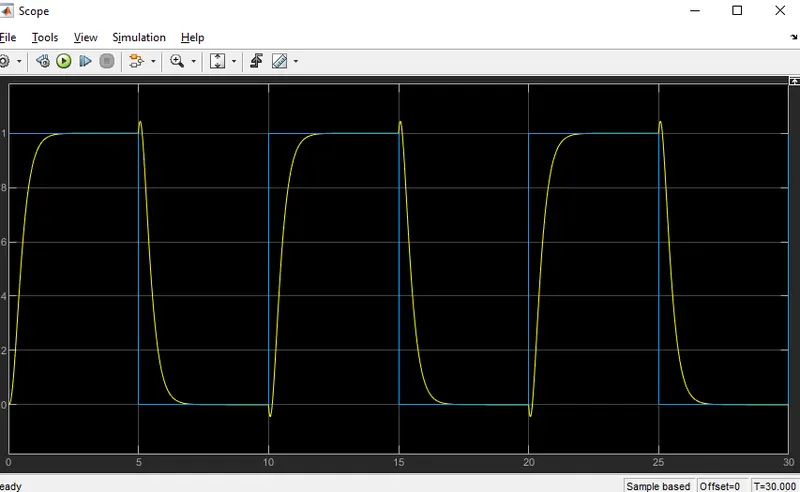
Hence by adjusting the force on mass so that its position follows a reference signal.