Project - Position control of mass spring damper system
The transfer function of the mass spring damper system is
X(s)/F(s) = 1/[(m*s^2) + (c*s) + k]
The given values of m,k,c is as follows:
m = 3.6
k = 400
c = 100
From the above value wn is calculated as
wn = sqrt(k/m)
The poles of the system is found using the A and B matrix as showm in the code below:
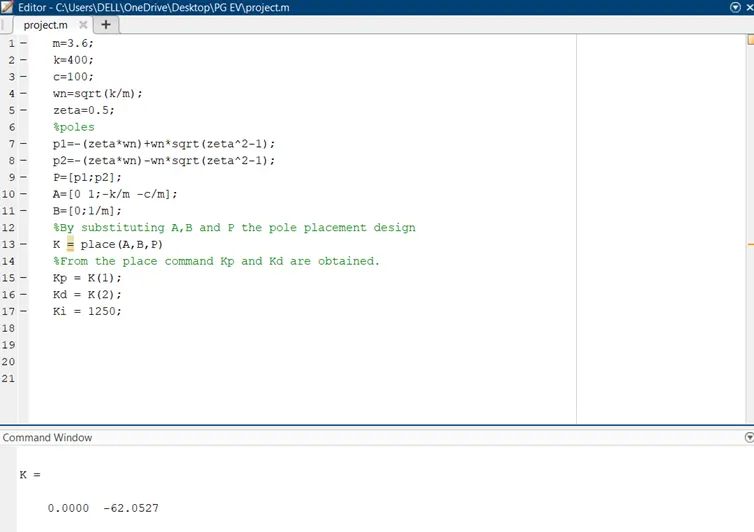
In the above attached the code the gain values of the Kp and Kd is found via the place command and the Ki value is manually tuned.
As we know that,
Ki is directly proportional to the integral of the error signal
Kp is directly proportional to the error signal
Kd is directly proportional to the derivative of the error signal
The simulink model is designed accordingly as shown below:
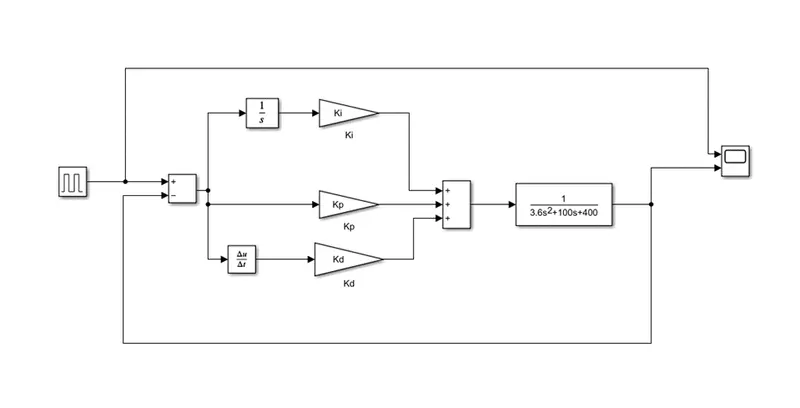
The model is designed by using the following simulink blocks:
- Pulse block
- integrator block
- derivative block
- gain block
- Transfer function block
- Sum block
- Scope
In this model a pulse input is considered as the reference input with amplitude = 1, period = 10 and pulse width = 50. The transfer function is designed according to the values m,c,k specified and the output is obtained as shown below:
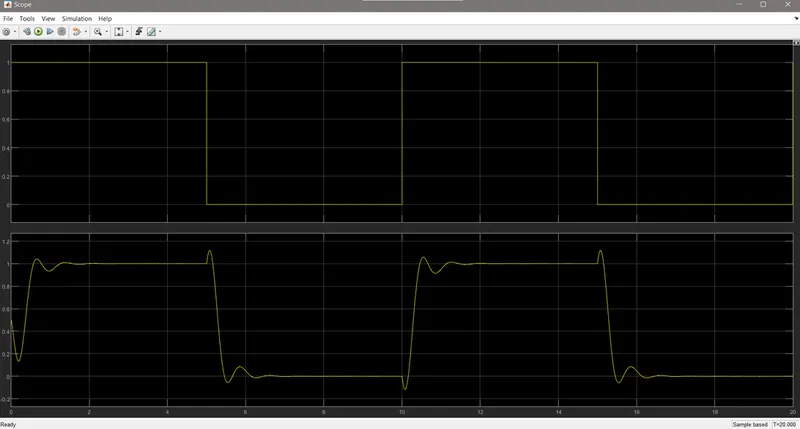
A PID controller is desinged to adjust the force on mass so that its position follows a reference signal.From the above output attached it is observed clearly.