Project
ANS:
AIM:
To study the system level simulation of an all-terrain vehicle.
OBJECTIVE:
Carry out a system level simulation of an all-terrain vehicle and prepare a technical report explaining the model properties and comments on the results.
INTRODUCTION:
Transmission, which transmit the power from engine to the wheels through the shafts. It consist of 4 types mainly.
1- Manual transmission.
2- Continous variable transmission.
3- Semi-automatic transmission.
4- Automatic transmission.
BAJA All terrain vehicle(ATV) that uses CVT and CVTs differ from traditional automatic transmission in that they dont have gears that provides "steps" between low-and-high speed operations. Instead the majority of them work via pair of variable-diameter, cone-shaped pulleys connected by a steel or composite belt. The step-less nature of its design allow the CVT to work to keep the engine in its optimum power range, increasing the efficiency, and fuel mileage by delivering an infinite number of smooth transitions from low to high.
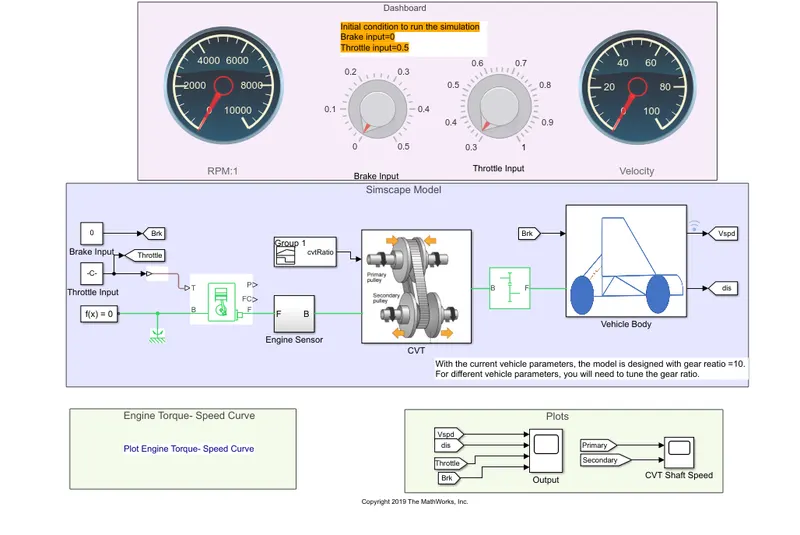
In This Model I Saw following Points:
1) Components of BAJA ATV
2) VehicLE Model
3) Effect of Parameter varriation like throttle and break.
Components of BAJA ATV:
CVT(Continuously variable transmission):
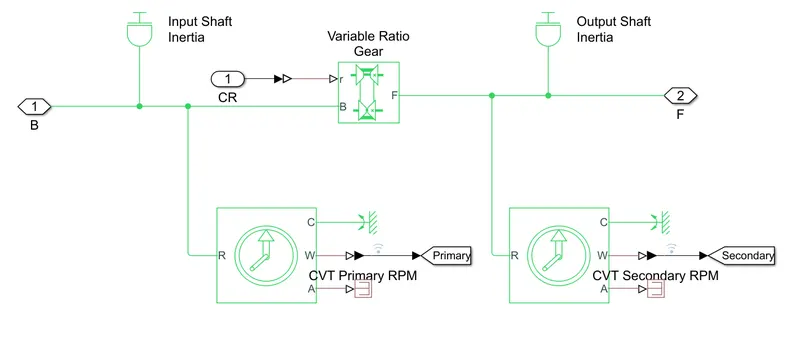
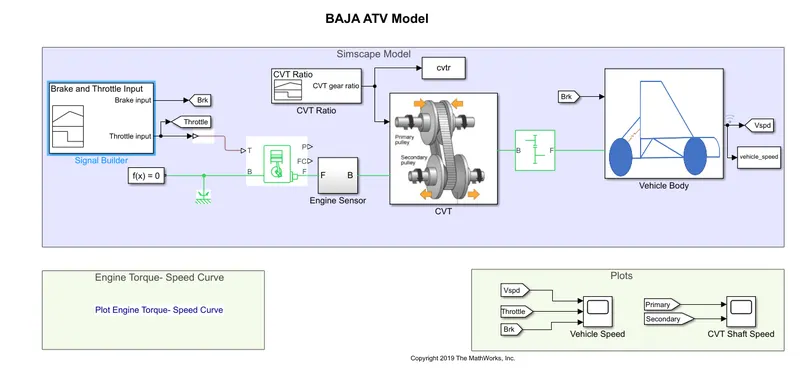
In this Continuously variable transmission (CVT) following blocks are used:-
1) Variable ratio Transmission:- The variable ratio transmission block represent the simple gearbox that dynamically transfer motion and torque between the two connected drive shaft axes B(Base) and F(Followers).the physical signal input r defines the ratio of input and output angular shaft velocities.
2) Inertia:- The block represent the ideal mechanical rotational inertia used as primary and secondary pully.
3) Ideal rotational motion sensor:- This block measure angular velocity or angle in mechanical rotational network.it sense the primary and secondary RPM only.
In CVT the primary pully get outward then secondary pully will inward that time speed reduction happens. means radius of primary pully is less than radius of secondary pully.
and primary pully get inward and secondary pully outward that time overdrive happenes.means radious of primary pully greater than radious of seconday pully.
1st condition:- Rs>Rp = speed reduction
2nd condition:- Rp>Rs = Overdrive.
Vehicle Model:
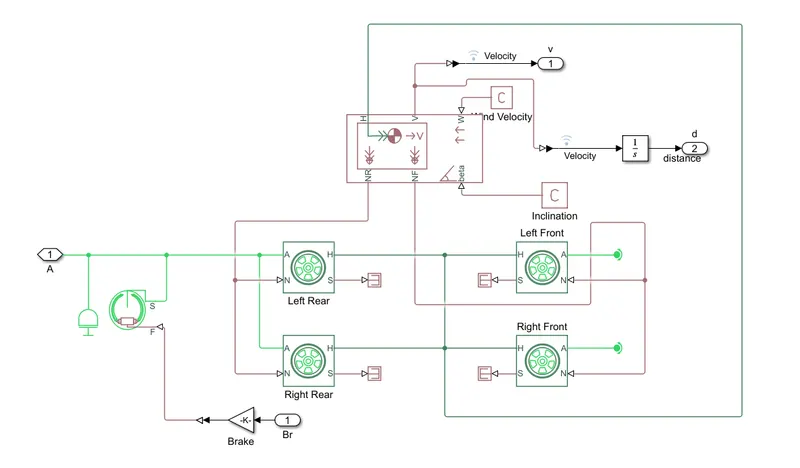
1)Vehicle body:
The vehicle body represents a two-axle vehicle body longitidunal motion.
2) Tire:
The tire Represents the longitudinal behavior of a highway tire characterized by the tire Magic Formula. The block is built from Tire-Road Interaction (Magic Formula) and Simscape Foundation Library Wheel and Axle blocks. Optionally, the effects of tire inertia, stiffness, and damping can be included.
3) Double-shoe brake:
Represents a brake arrange as two provide rigid shoe symmetrically installed inside drum or outside drum and operated by one actuator.The actuator force causes the shoes to exert a friction torque on a shaft connected to the drum.
4) Generic engine:
Represents a system level model of spark ignition and diesel engine, suitable for use at initial stage at modeling when only the basic parameter are available.
Dashboard:
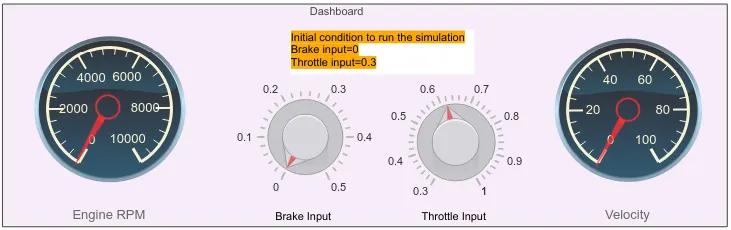
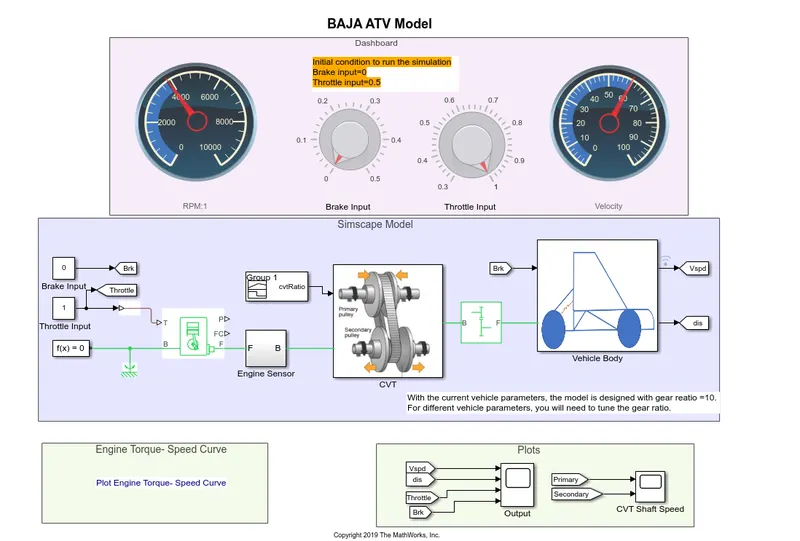
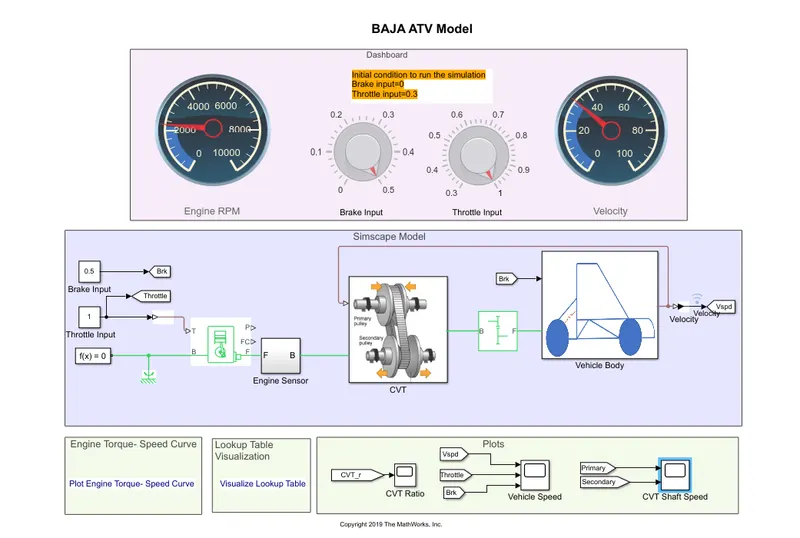
Here used for indication of Velocity, RPM,Brake input,Throttle input.
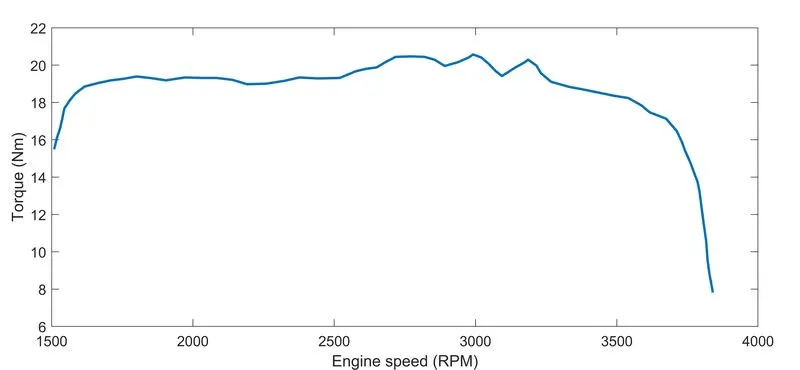
The Engine torque speed curve shown below:
Signal builder:
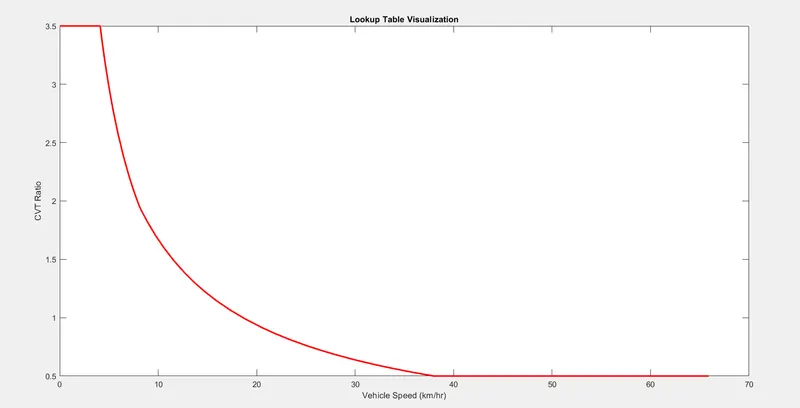
It is used to set the gear ratio of CVT gear.for a different velocity,the CVT will have different gear ratio from signal builder.
CASE 1:
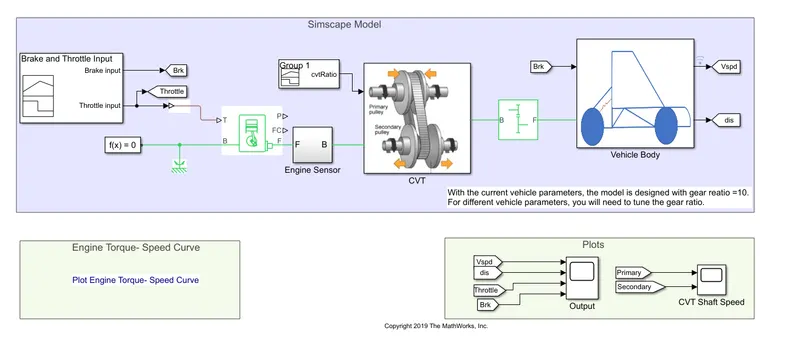
SIMULINK MODEL FOR BAJA ATV WITH CVT:
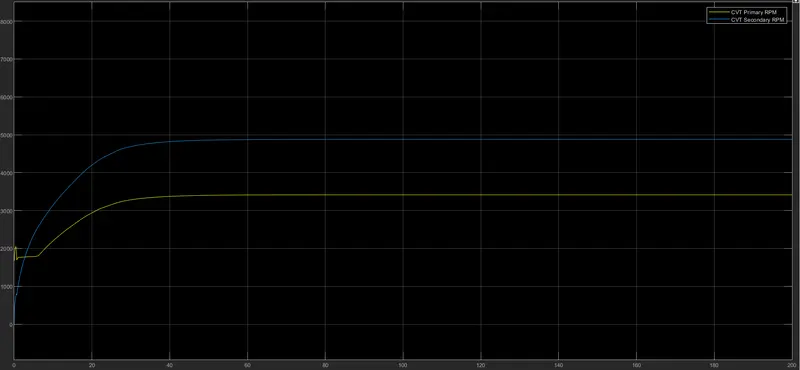
SIGNAL BUILDER INPUT OF THROTTLE-0.3,BRAKE-0
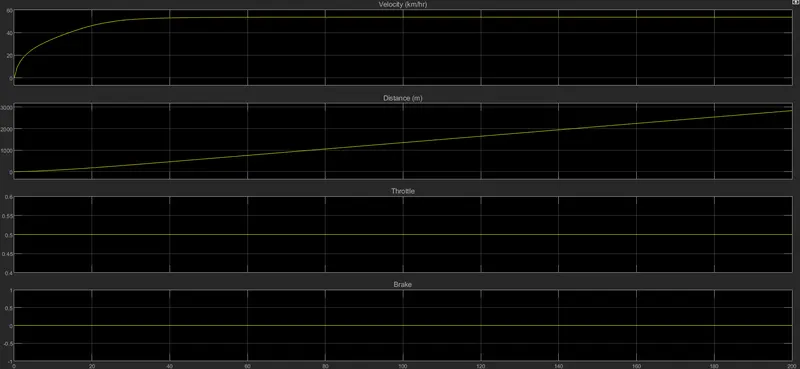
OUTPUT:
SPEED CURVE SHOWN BELOW:
SHAFT SPEED SHOWN BELOW:
CASE 2:
SIMULINK MODEL FOR BAJA ATV WITH CVT USING DASHBOARD:
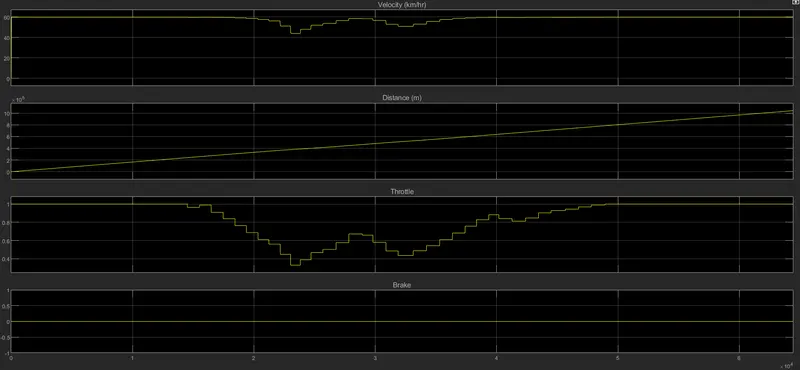
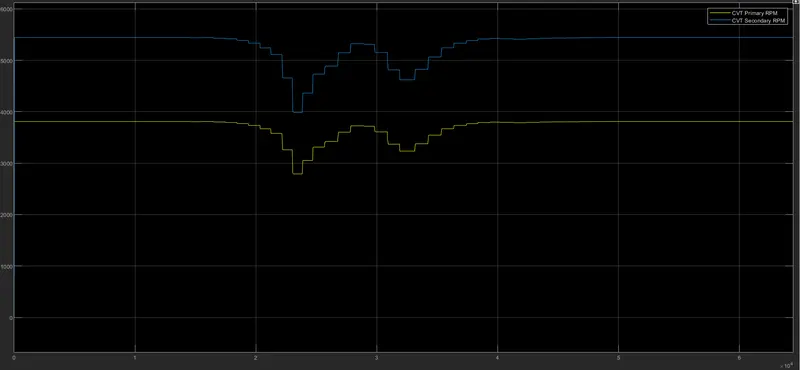
Throttle input-1 & Brake- 0
OUTPUT:
SPEED CURVE SHOWN BELOW:
SHAFT SPEED SHOWN BELOW:
CASE 3:
SIMULINK MODEL FOR BAJA ATV WITH CVT USING LOOKUP TABLE:
OUTPUT:
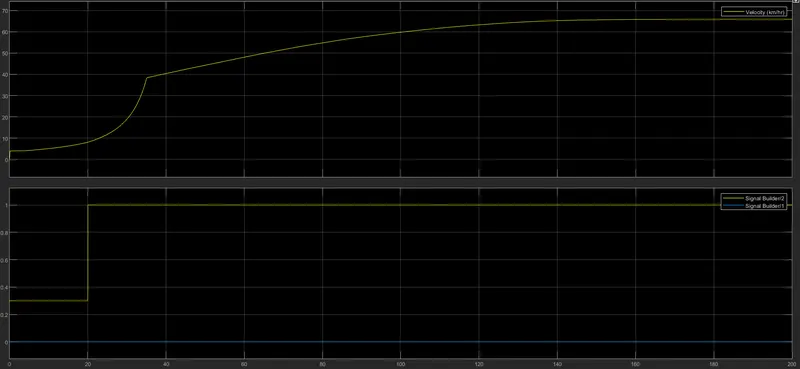
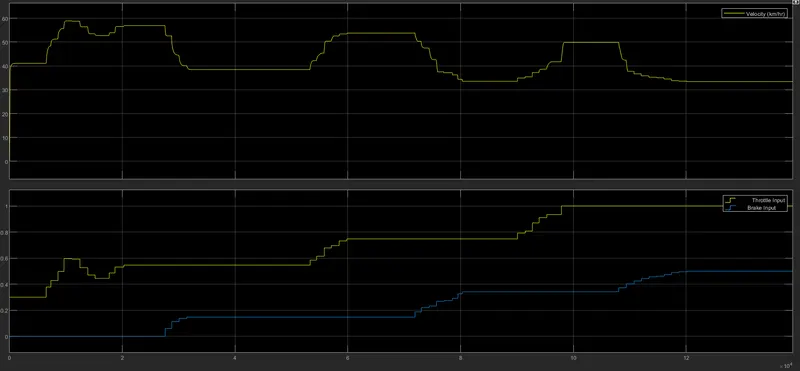
VEHICLE SPPED SHOWN BELOW:
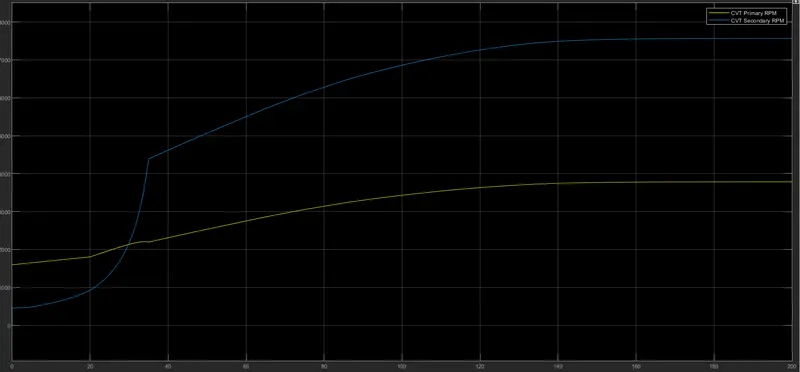
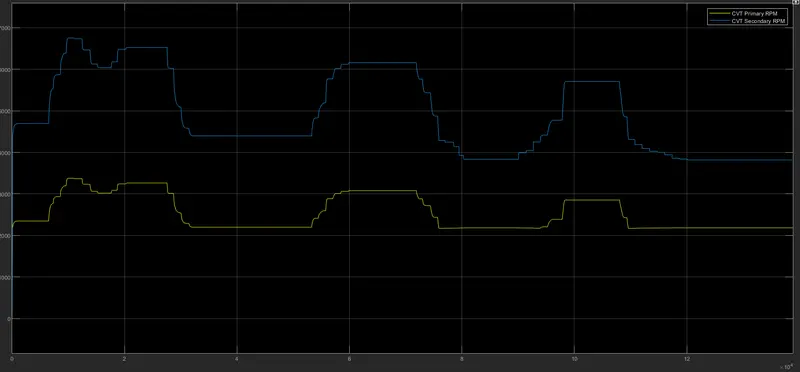
SHAFT SPEED SHOWN BELOW:
Lookup table visualisation:
CASE 4:
SIMULINK MODEL FOR BAJA ATV WITH CVT USING LOOKUP TABLE AND DASHBOARD:
OUTPUT:
VEHICLE SPEED CURVE SHOWN BELOW:
SHAFT SPEED SHOWN BELOW:
CONCLUSION:
Thus we have successfully analyzed 4 different models of BAJA ATV WITH CVT and recorded the outputs (Vehicle velocity and CVT shaft rpm) with respect to variation in input throttle and brake.