System Level simulation of an all terrain vehicle
Aim
Carry out a system level simulation of an all terrain vehicle
Objectives
Download the model of an all terrain vehicle from the given link and perform simulation. Explain the model properties and comment on the results.
Theory
File downloaded from above mentioned link includes BAJA all terrain vehicle (ATV) with continuously variable transmission (CVT).
Baja is a small off road vehicle that can withstand harshest elements of rough terrain. It looks similar to dune buggy or beach buggy.
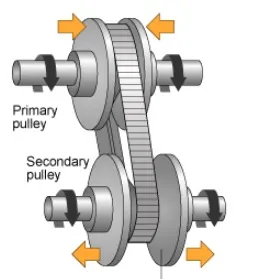
A CVT is an automatic transmission that can change through a continuous range of gear ratios. It may allow the engine to operate at a constant rpm while the vehicle moves at varying speeds. Common type of CVT uses two pulleys connected by a belt or chain as shown below.
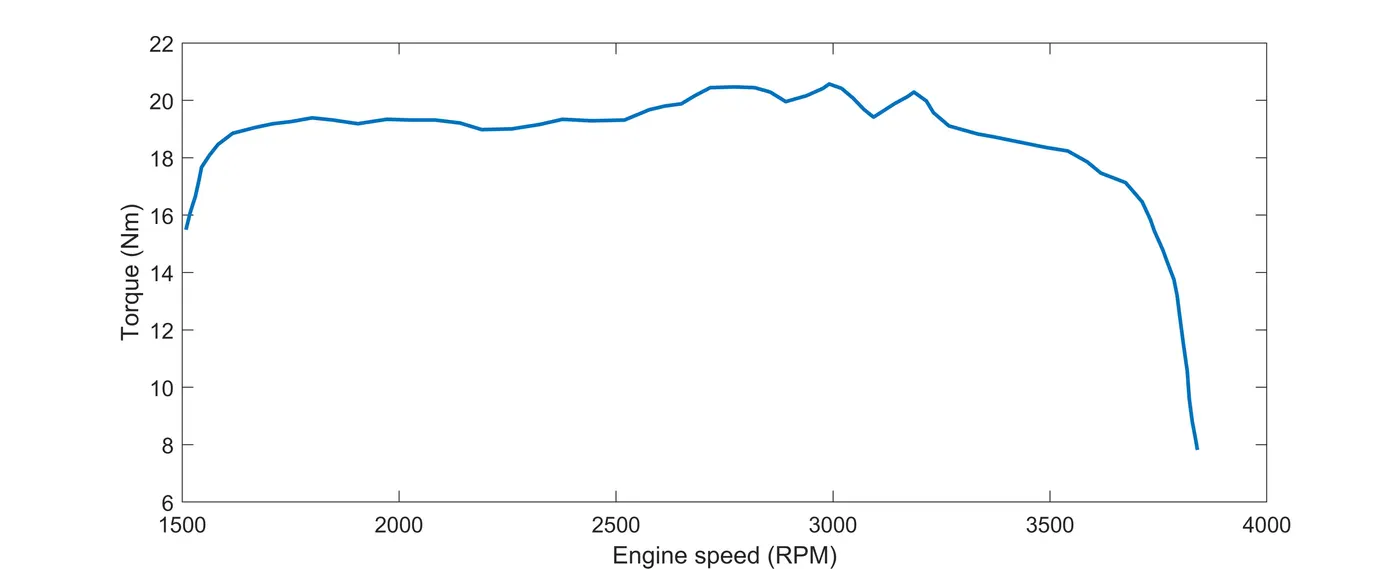
The engine data used in the model is provided as an image which shows the engine speed (RPM) Vs Torque curve.
Models
1. BAJA ATV Model
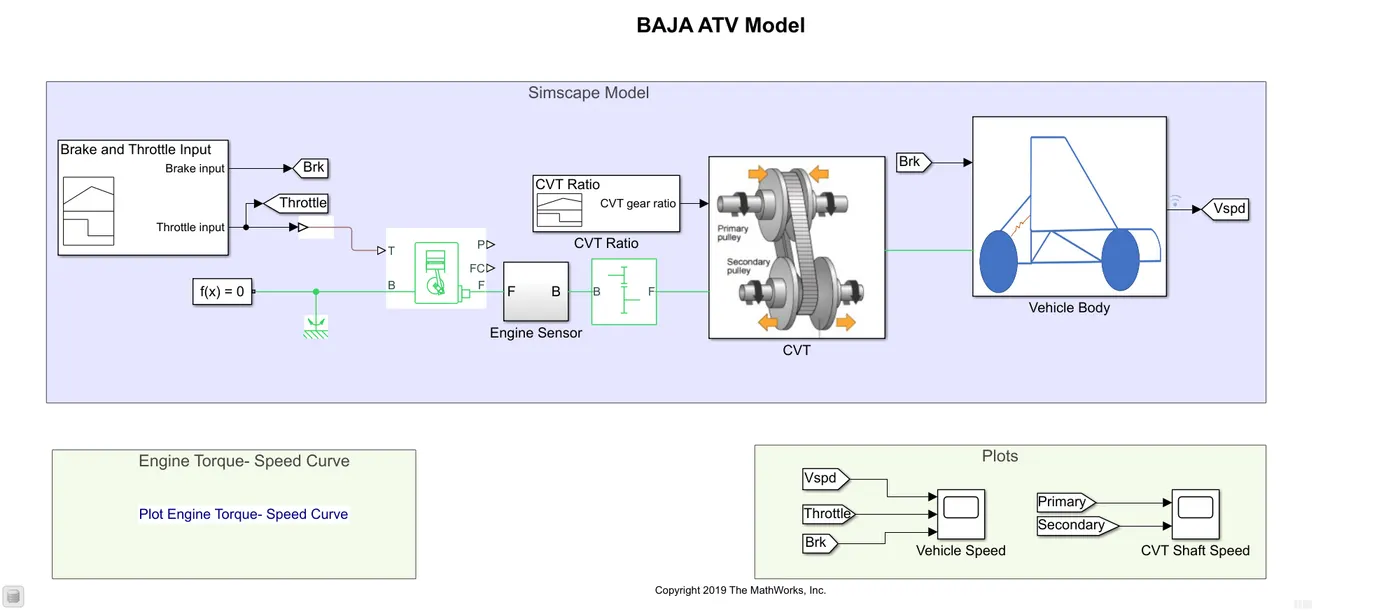
Initially, a signal builder is used to give brake and throttle input to the system. Go to blocks are used to send signals to from blocks that have specified tag. Signal from the signal builder is given below.
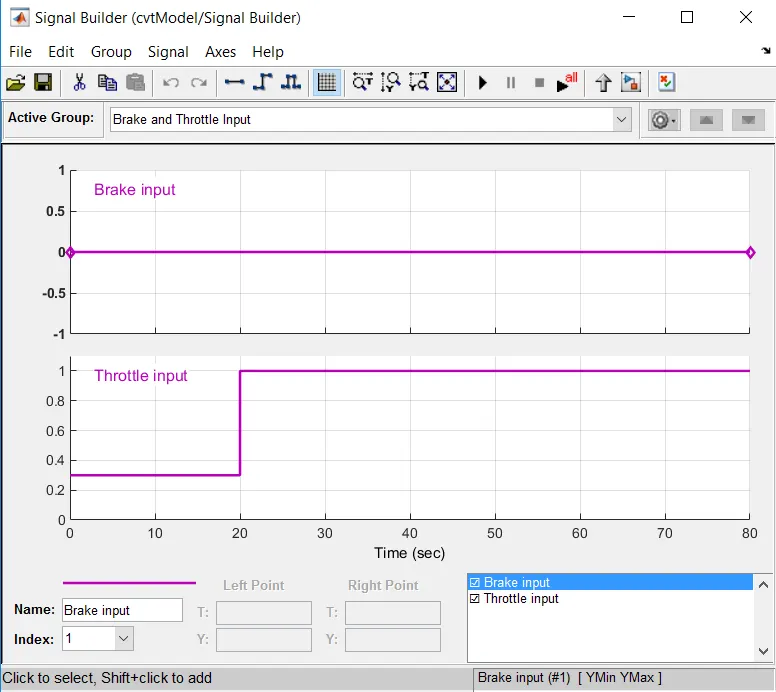
Here, no break input is given but throttle input is provided. For the first twenty seconds throttle value is 0.3 and for rest of the time its value is one. Then, this output is given to a generic engine block which represents a system level model. The throttle input signal T lies between zero and one and specifies the torque demanded from the engine as a fraction of the maximum possible torque. Connections F and B are mechanical rotational conserving ports associated with the engine crankshaft and engine block, respectively. Connections P and FC are physical signal output ports through which engine power and fuel consumption rate are reported. Speed vector and torque vector used in this block are given externally from workspace.
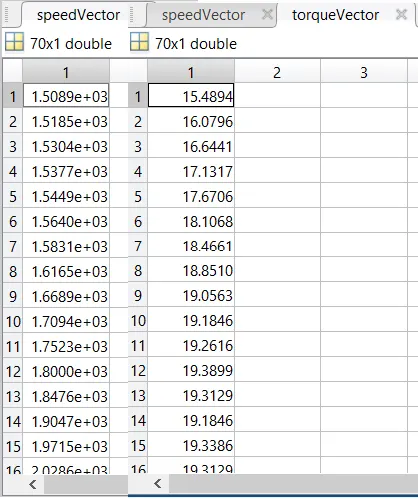
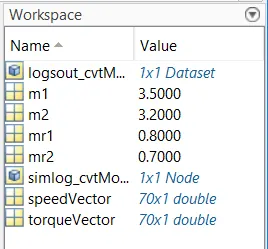
This block is connected to a sub system named engine sensor. It is represented below.
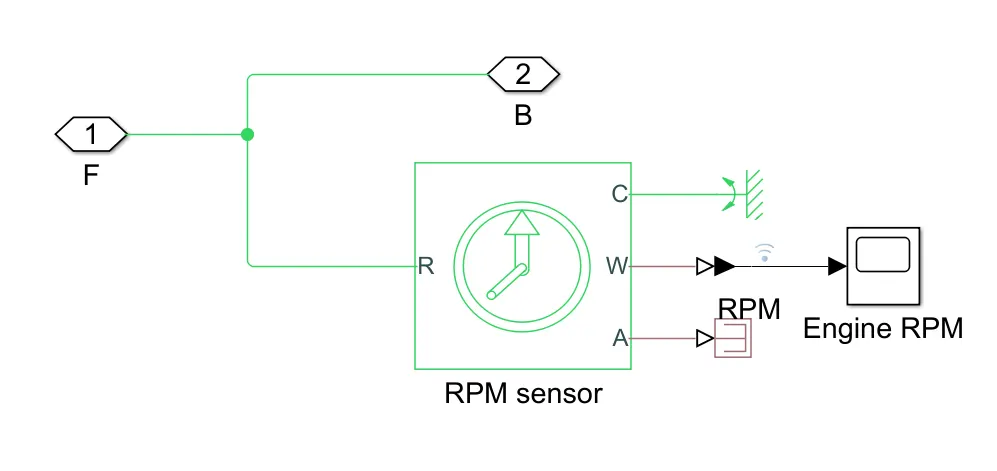
Ideal mechanical rotational motion sensor (RPM Sensor) has connections R and C those are mechanical rotational conserving ports and connections W and A are physical signal output ports for velocity and angular displacement, respectively. This is connected to a simple gear block followed by subsystems of CVT and vehicle body respectively. It is given below.
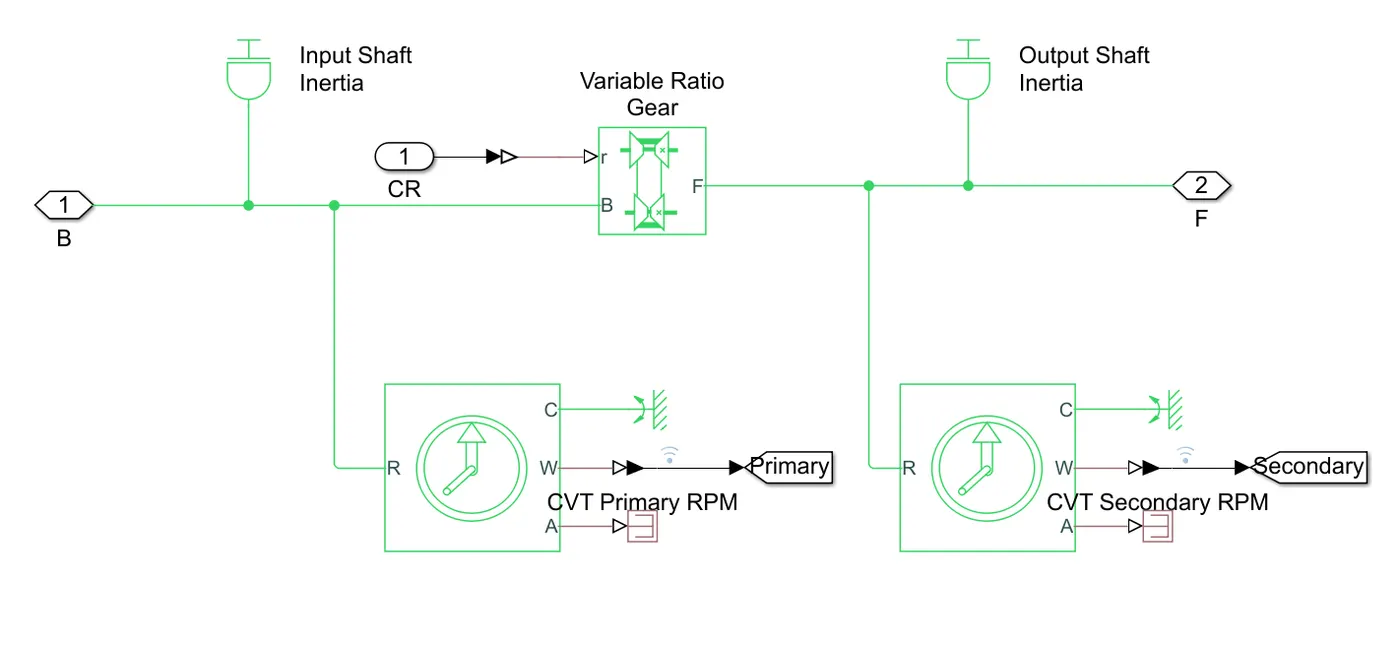
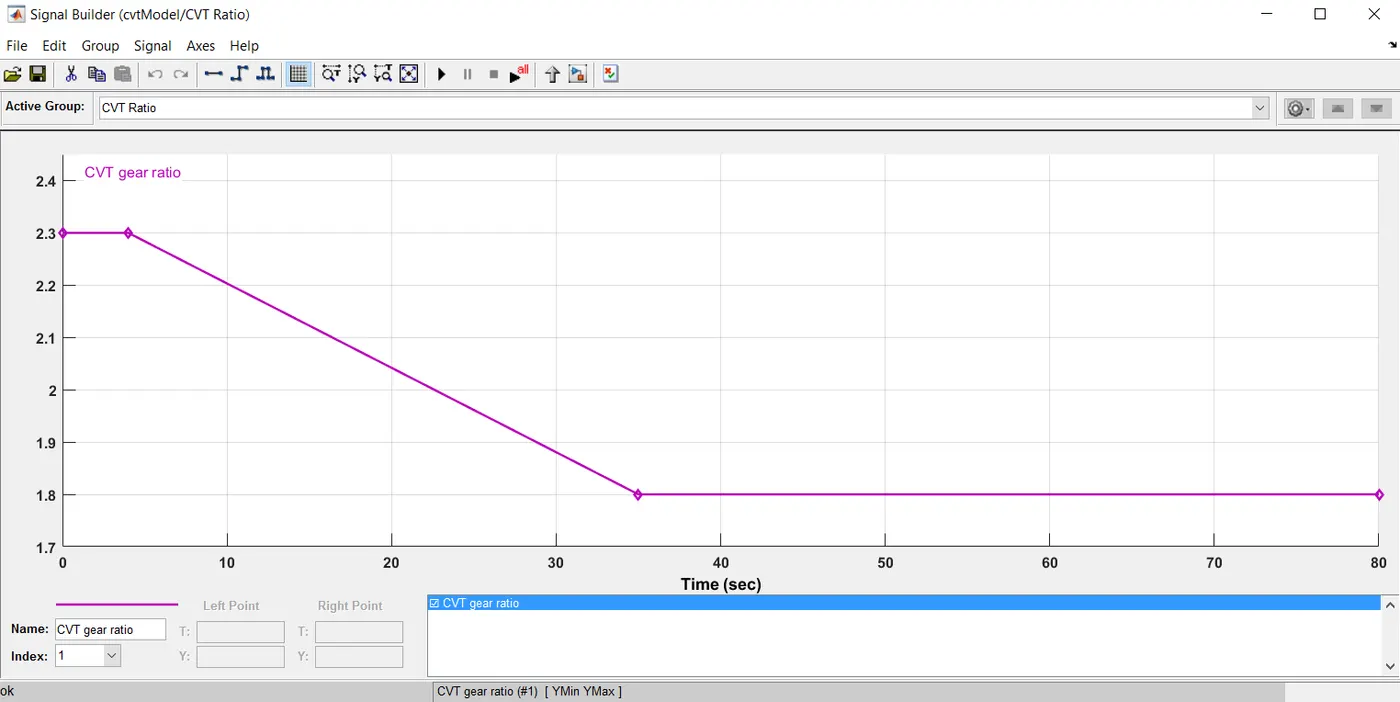
Data’s for input shaft inertia and output shaft inertia (m1 = 3.5 and m2 = 3.2) used in CVT subsystem are given through workspace. These inputs are given to a variable ratio gear. It represents a variable ratio gearbox such as implemented by mechanical belt CVT, electric, or hydraulic transmissions. The physical signal input r defines the ratio of input to output angular shaft velocities. Connections B (base) and F (follower) are mechanical rotational conserving ports. Specify the relation between base and follower rotation directions with the Output shaft rotates parameter. Two rotational motion sensors are provided to detect the motion of two shafts. Connections R and C are mechanical rotational conserving ports and connections W and A are physical signal output ports for velocity and angular displacement, respectively. A signal builder is used to give gear ratio inputs into CVT subsystem. It is represented below.
As we said earlier, there is a vehicle body subsystemalso. Its model is given below.
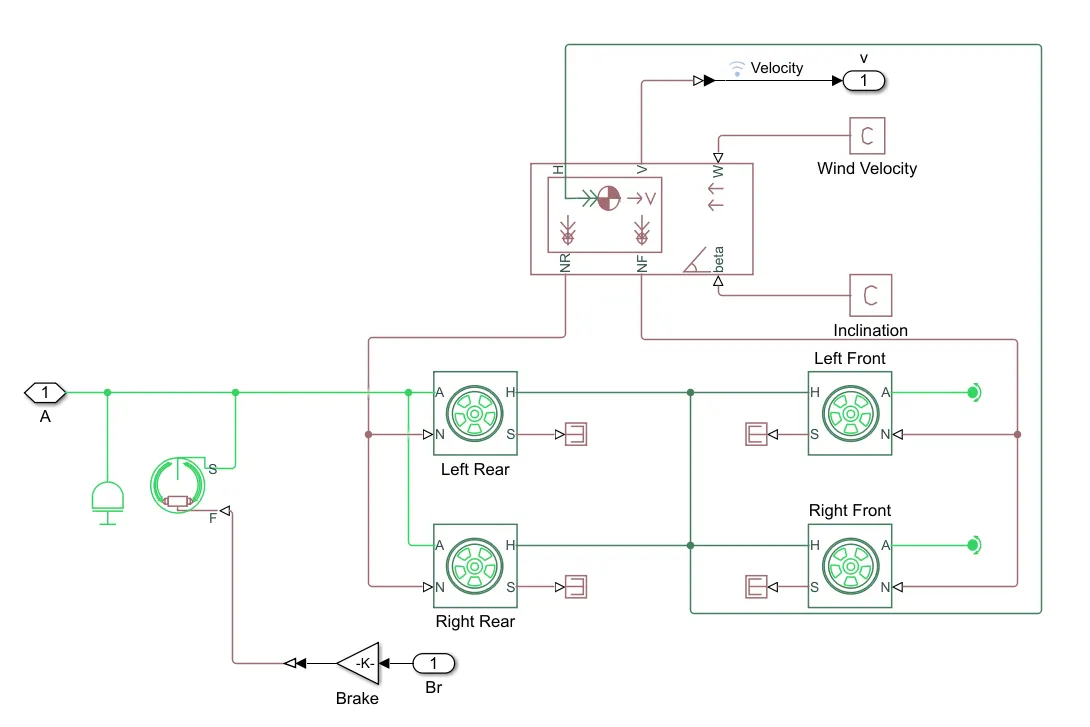
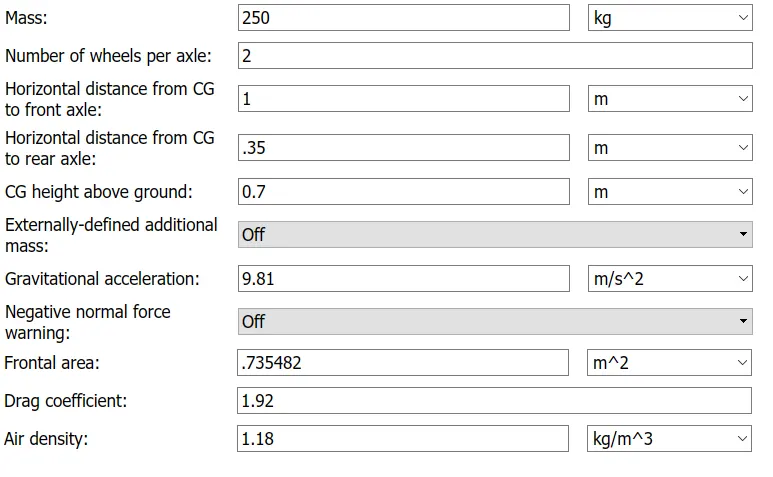
In vehicle body subsystem, the main block is vehicle body block. It represents a two-axle vehicle body in longitudinal motion. Connection H is the mechanical translational conserving port associated with the horizontal motion of the vehicle body. The resulting traction motion developed by tires should be connected to this port. Connections V, NF, and NR are physical signal output ports for vehicle velocity and front and rear normal wheel forces, respectively. Wheel forces are considered positive if acting downwards. Connections W and beta are physical signal input ports corresponding to headwind speed and road inclination angle, respectively. If variable mass is modelled, the physical signal input ports CG and M are exposed. CG accepts a two- element vector representing the x and y distance offsets from vehicle CG to additional load mass CG. M represents the additional mass. If both variable mass and pitch dynamics are included, the physical signal port J accepts the inertia of the additional mass about its own CG. The main parameters given as input are represented below.
Four tires are connected to a break drum block. It represents a brake arranged as two pivoted rigid shoes symmetrically installed inside or outside a drum and operated by one actuator. The actuator force causes the shoes to exert a friction torque on a shaft connected to the drum. Connection S is a conserving rotational terminal associated with the drum shaft. Connection F is a physical signal port representing the force input to the actuator. Positive force creates friction torque that resists shaft rotation. Its parameters are given below.
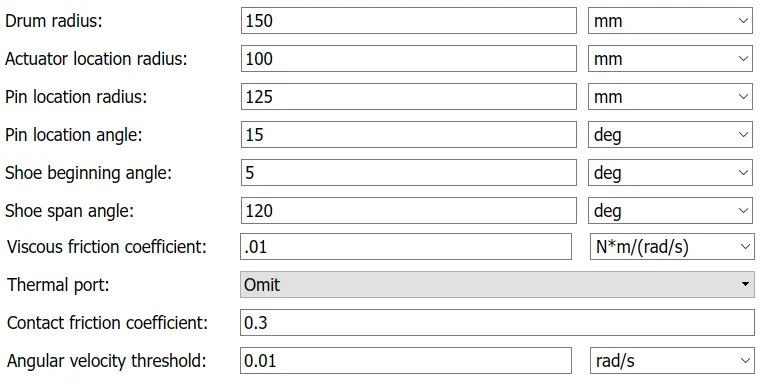
Finally, we run the simulation and every output is displayed through scope block from we can analyse the results.
Results
From the scope in engine sensor, we will be able to get the engine rpm values.
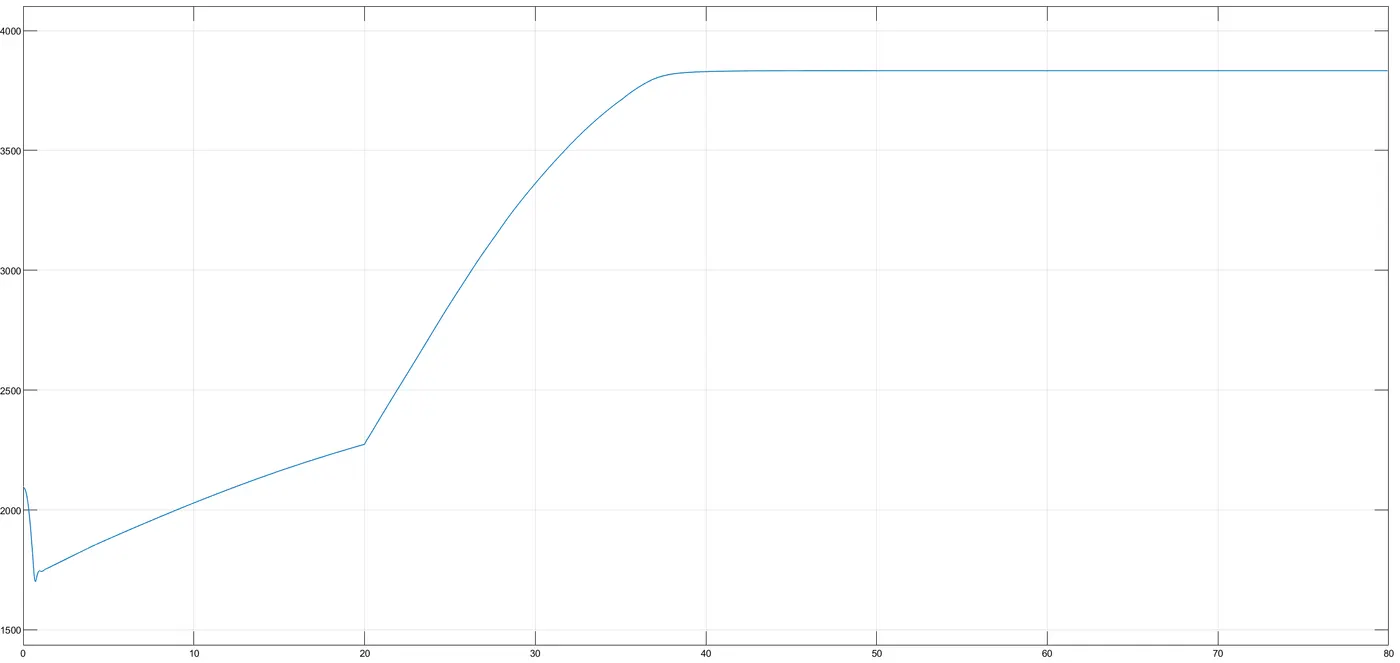
Above graph shows the engine rpm. We gave the throttle input as 0.3 for the first 20 seconds and increased the value to 1 after 20 seconds. So the rpm value was below 2250 during first 20 seconds and increased up to 3800 after 20 seconds. Rpm was steady after 40 seconds. Now, the vehicle speed is got from the scope which is placed externally. It is given below.
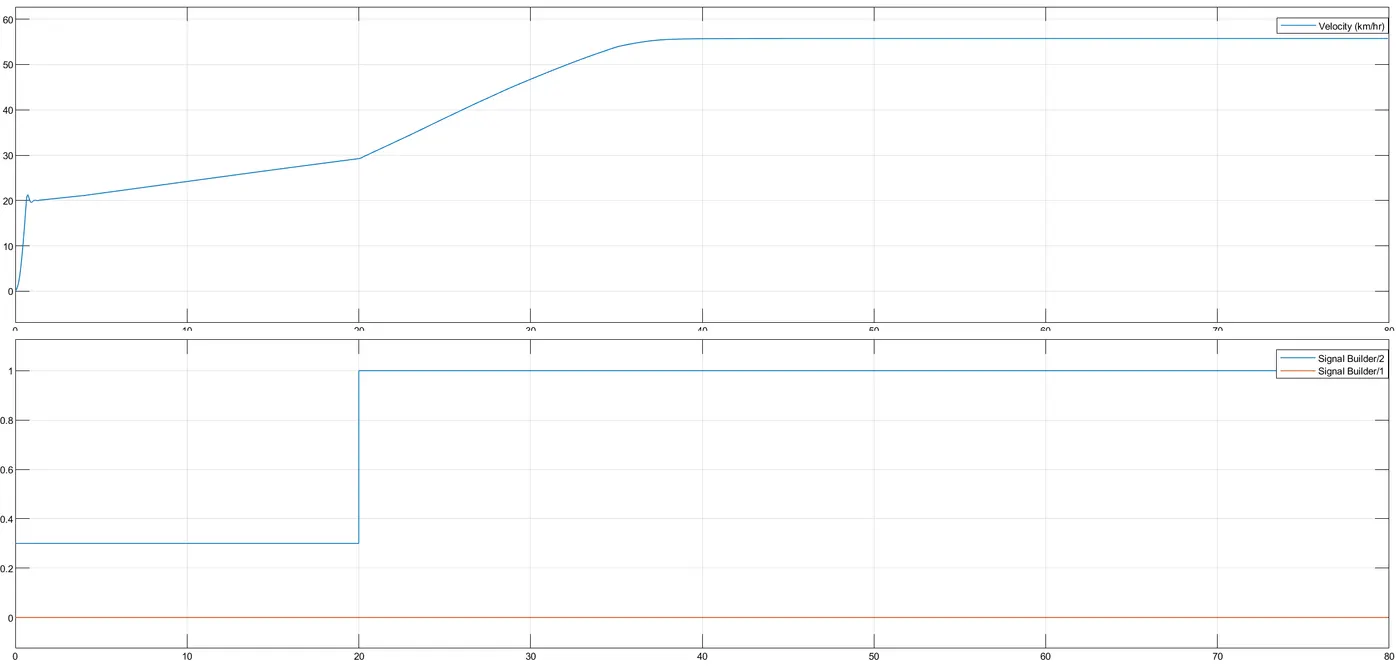
Vehicle Speed plot shows that, velocity of the vehicle was similar to the change of engine rpm. Velocity was below 30km/hr for first 20 seconds and reached about 58km/hr after 20 seconds. We can also refer that with trottle and break input in the plot. Shaft speed is also got from another scope block.
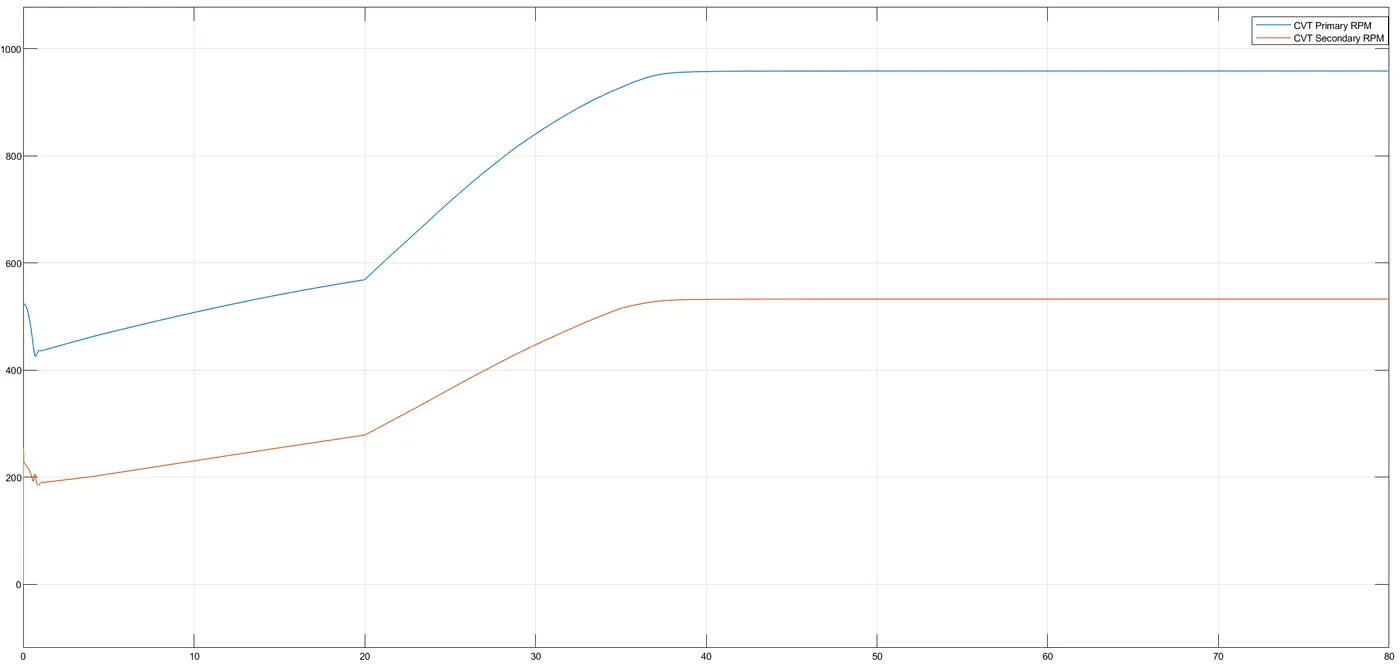
Shaft Speed plot is given above. Graph shows the speed of two shafts in CVT. It also behaved like other graphs. Speed was below 600 before 20 seconds and reached about 950 after 40 seconds.
So, from these results we can say that engine rpm, velocity of vehicle and shaft speed is propotional to the throttle input. These values behaves exactly like the value of throttle.
2. BAJA ATV With Dashboard
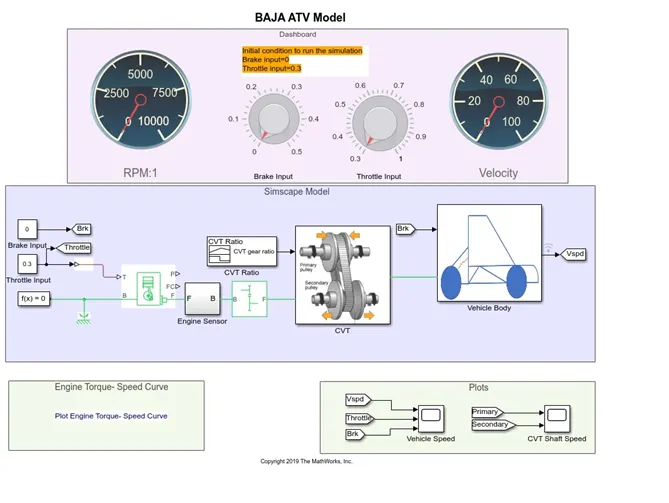
In this model the signal builder which used to give throttle and brake input is replaced with two knobs. By knob block, we can manually change throttle and bake like in a practical situation. Custom gauges and knobs replicate the dashboard. Every other connections and concepts are same as the previous model. Initial condition of the dashboard for simulation is defined as zero break input and 0.3 throttle input. Result of the simulation is given below.
Results
From engine sensor subsytem, we will get the engine rpm plot. It is given below.
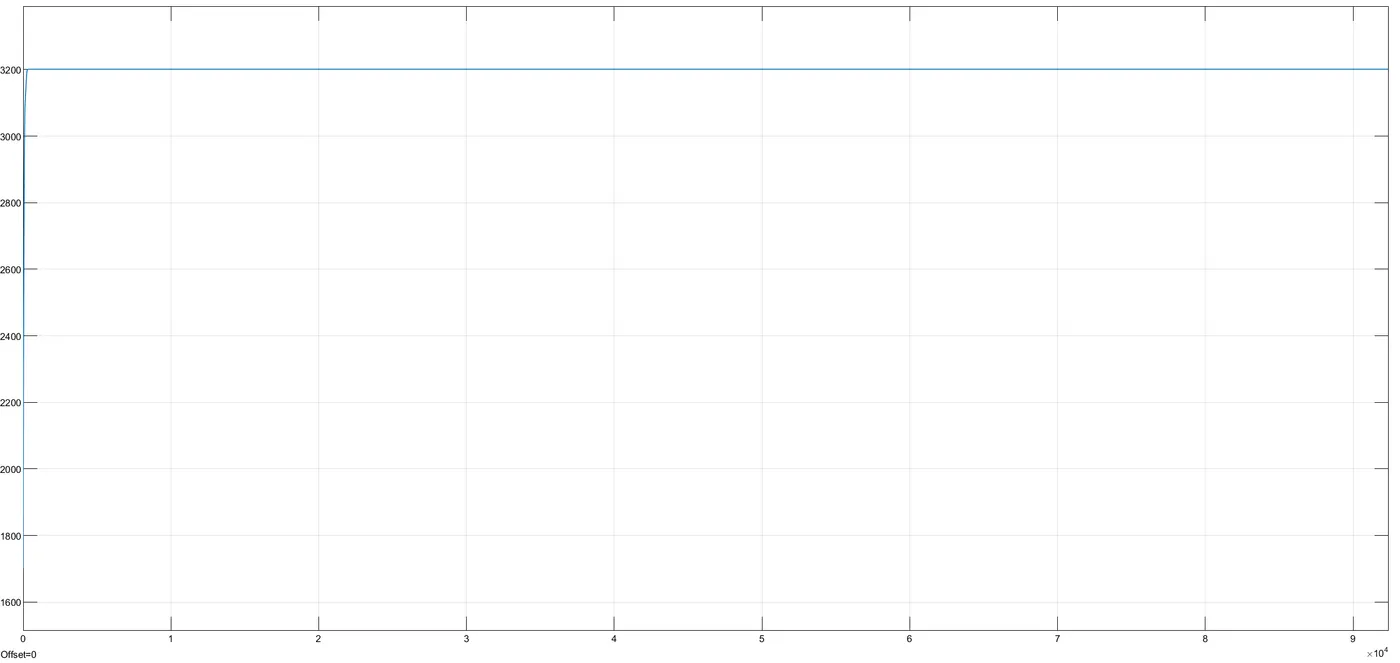
We can observe that, the rpm holds a steady value of 3200. Because the throttle input is constant and no break is applied. Now we can predict the vehicle speed same as engine rpm. Vehicle speed plot is given below.
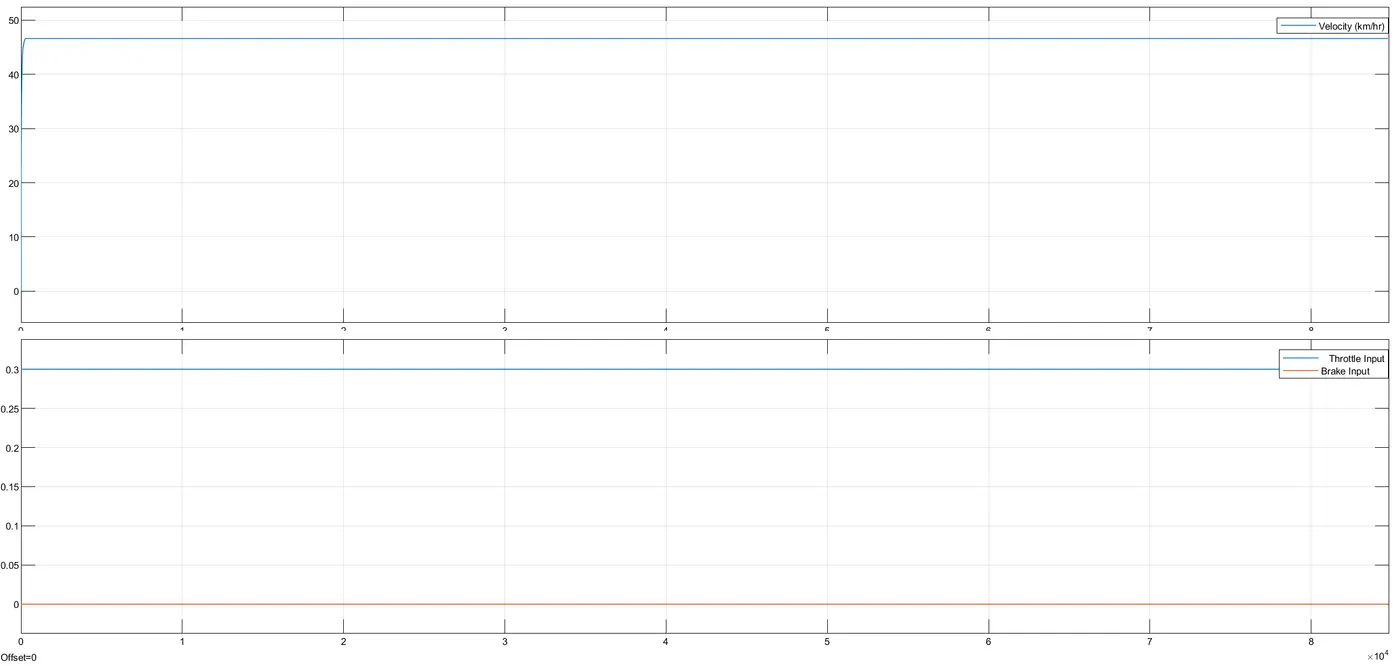
Vehicle speed is also constant because the throttle value is 0.3. Speed was more than 45km/hr. Shaft speed will be also constant. We can confirm it from the shaft speed plot provided below.
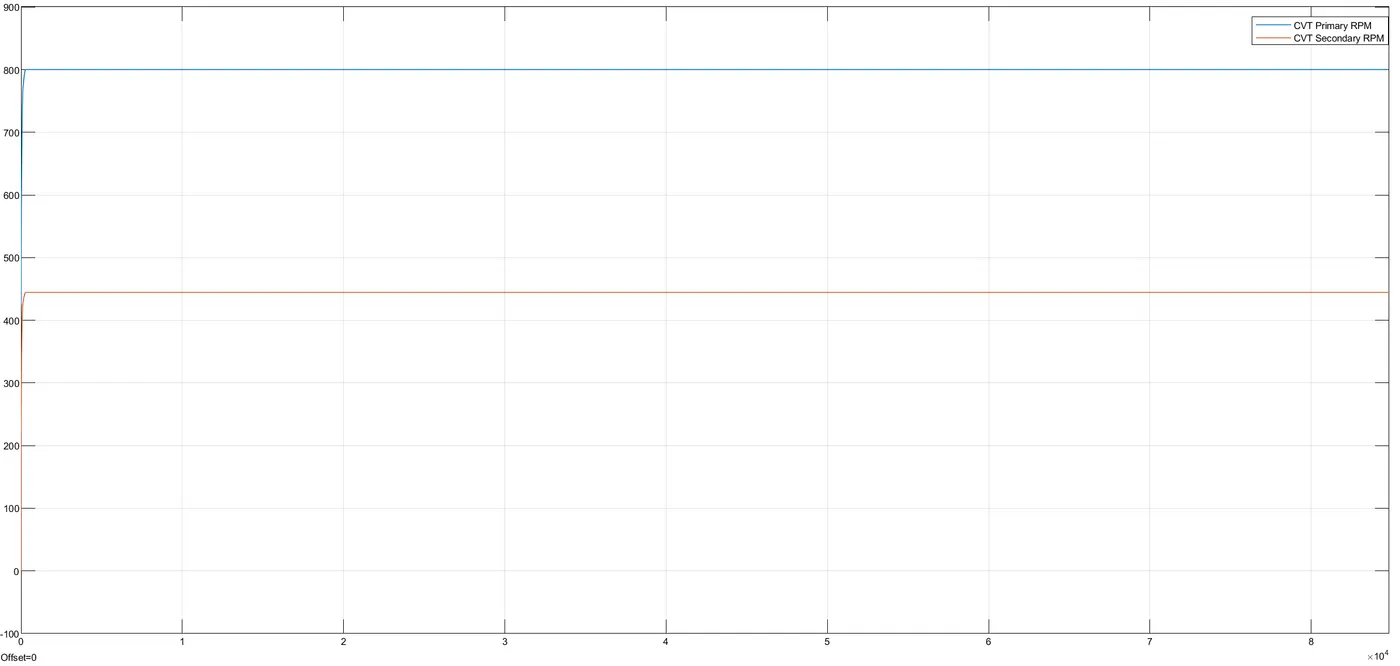
Pimary shaft obtained constant value of 800rpm and secondary shaft speed was 450rpm.
In this model, we have the facility to varry the input values. So by giving diffeent inputs, we can observe the changes in the plots.
Different input conditions are given to the model and the output is represented below.
Break Input = 0 and Throttle Input = 1
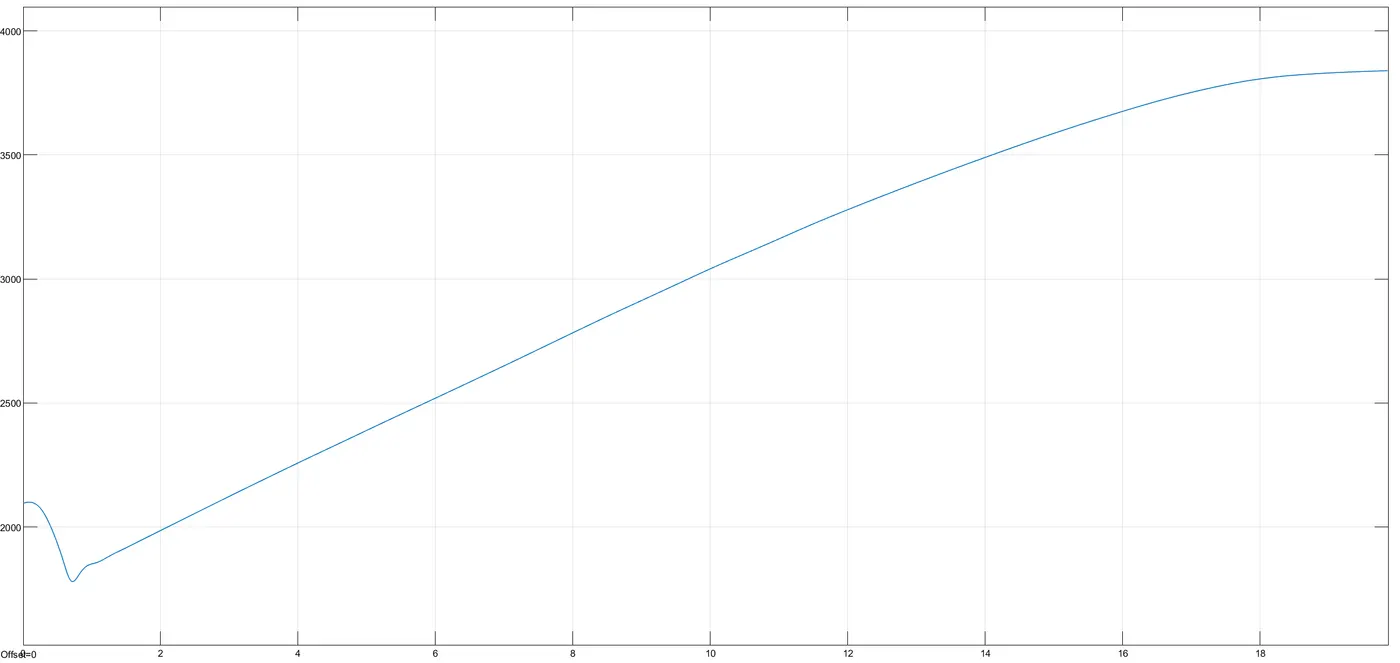
Engine rpm was rised upto 3800 when the throttle input was 1. But the rise was not sudden. The rise was gradual. Now the vehicle speed plot is given below.
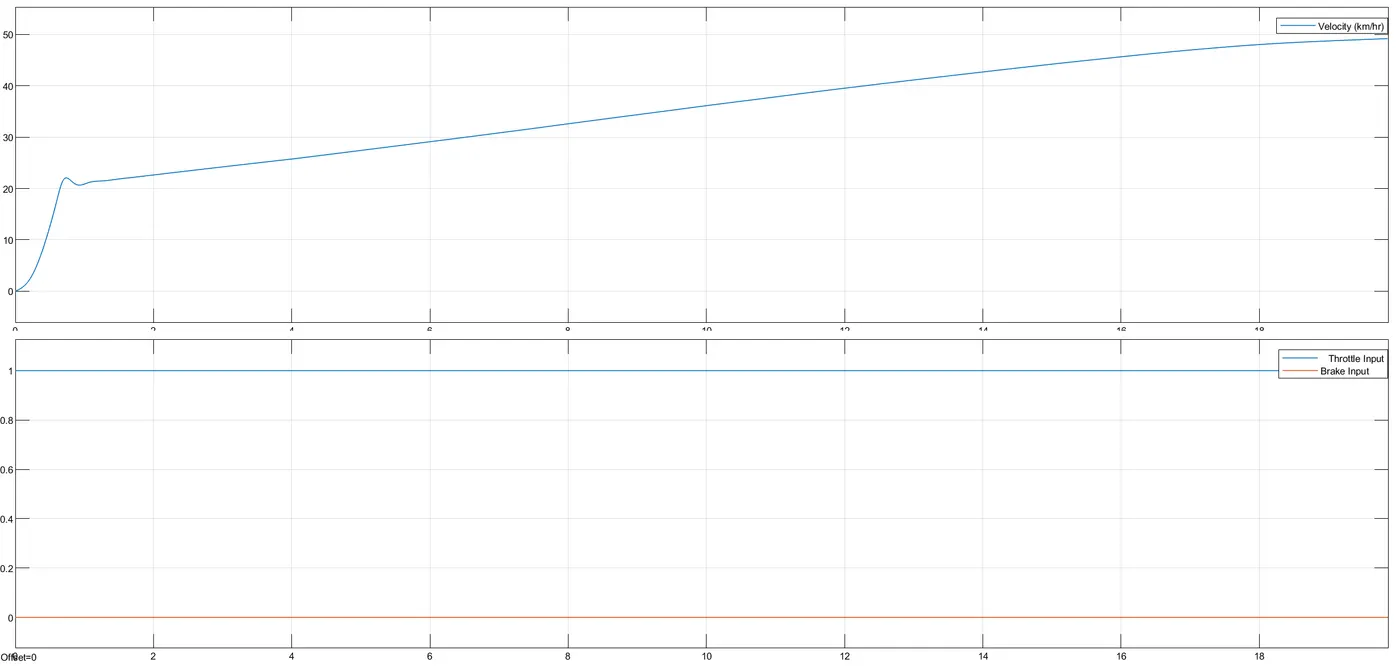
Vehicle Speed plot is similar to the plot that we had when there was no dashboard. But when we campare those two, here the increase in velocity was quick and reached maximum speed in less time. The shaft speed is also obserbed and it is given below.
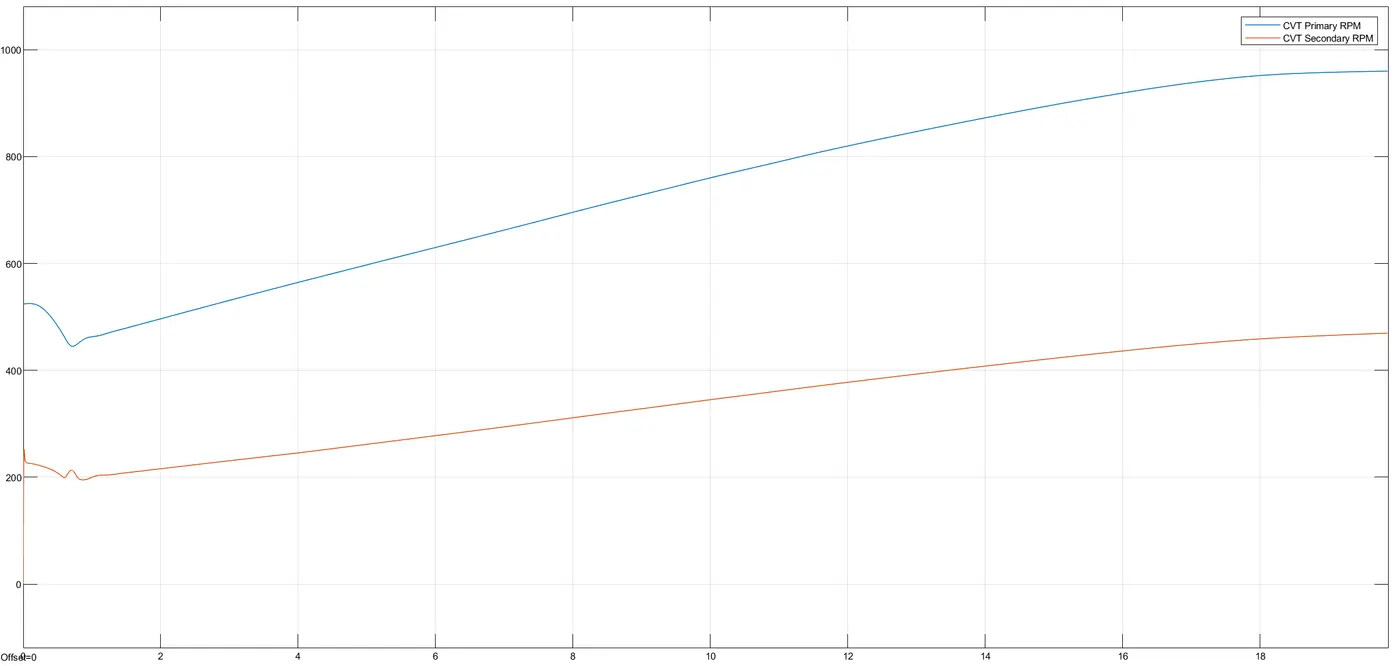
Shaft speed also resembled the shaft speed from first model. Here also, starting was rough but it gained maximum value in less time.
Break Input = 0.5 and Throttle Input = 1
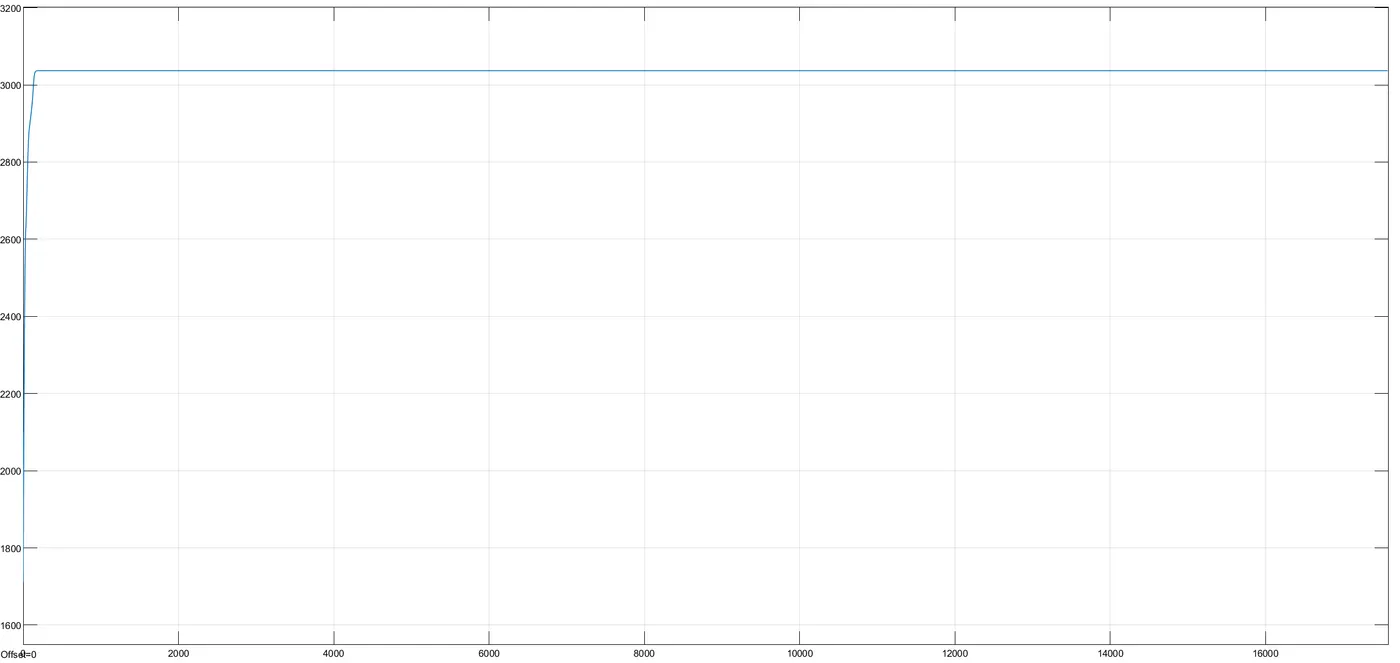
Engine rpm decreased when break input was given. But the it gained the maximum value with out any drama like in the previous case. So by looking this plot we can predict the velocity and shaft speed plot will be similar to this.
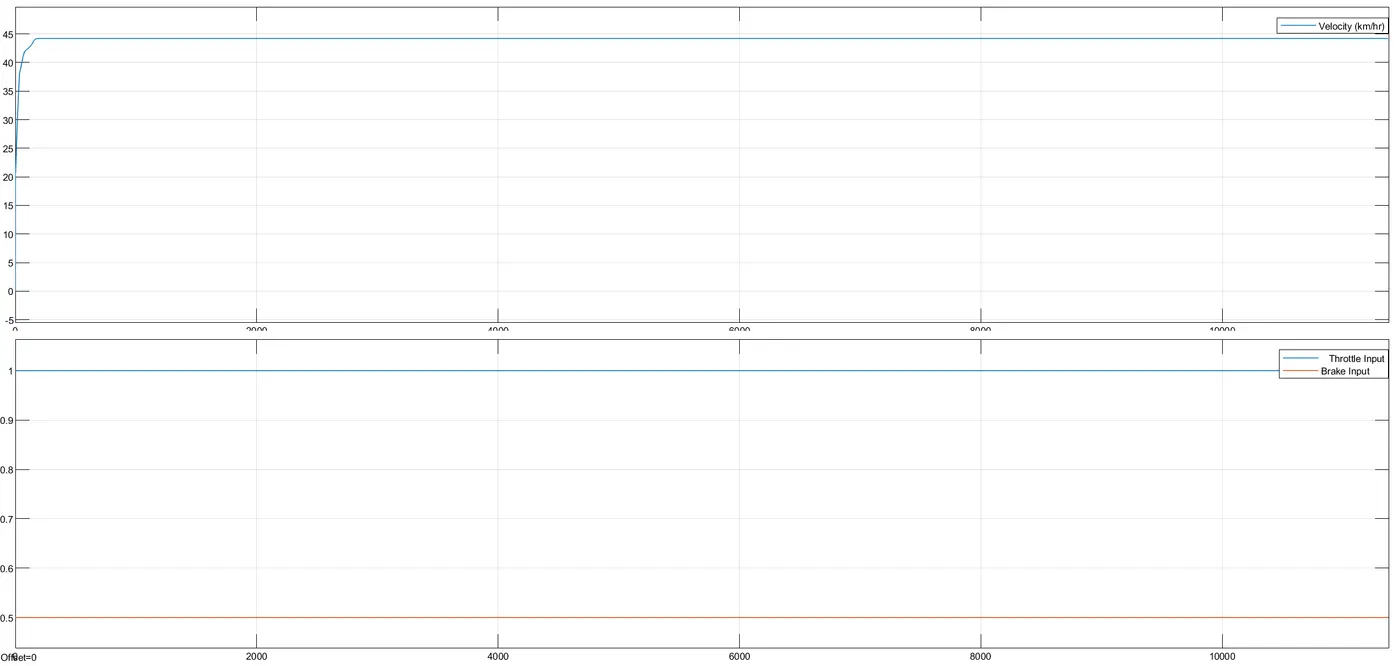
Maximum Vehicle Speed was decreased because of the application of break. The small roughness in the graph before it reach the maximum value is also because of the break input. Now, the shaft speed plot is given.
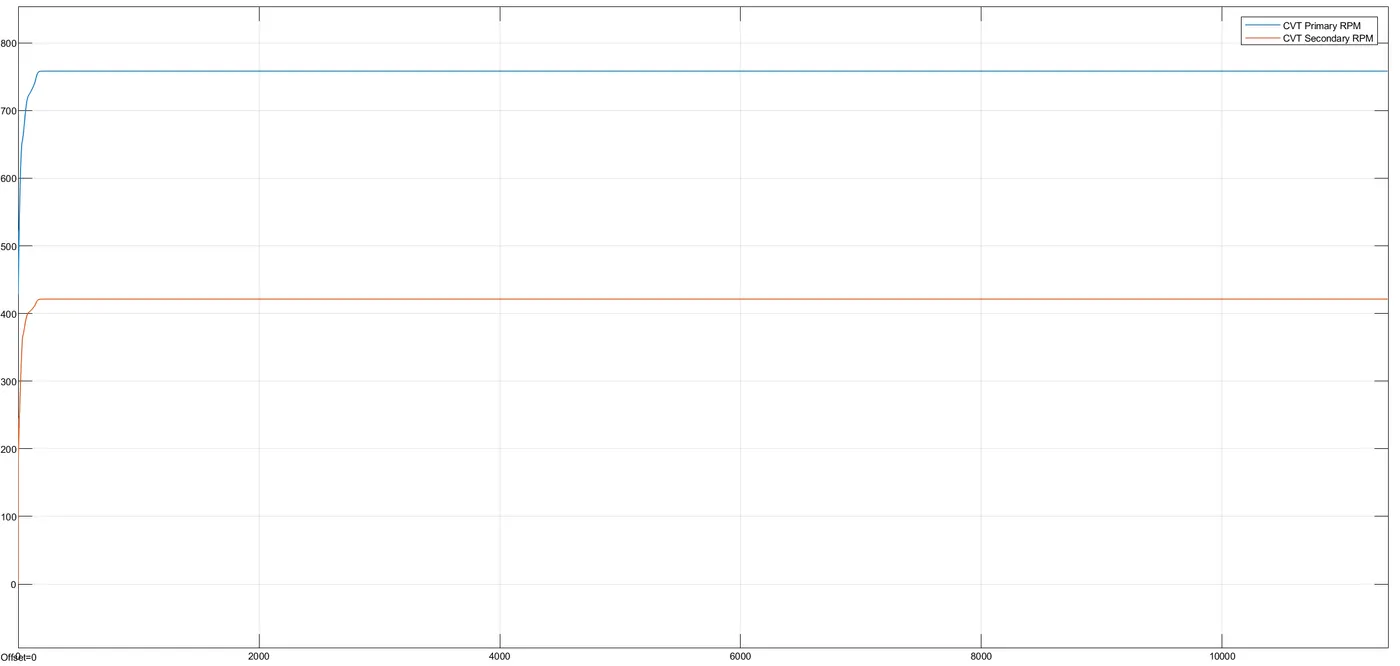
Shaft Speed also behaved like pevious case. Influence of break input brought down the maximum values and small jerk was observed in the start.
Modelling with the help of LOOKUP TABLE
Lookup table blocks use arrays of data to map input values to output values approximating mathematical functions. Here we use a PS lookup table (1D) block. It computes an approximation to some function with given data vectors. Both input and output will be physical signals. Data vectors provided for this model is having same length and x data vector is monotonic. Then the block generates output based on the input values. We can also visualize the data before the simulation. In this model the lookup data visualization is performed and the result is as follows.
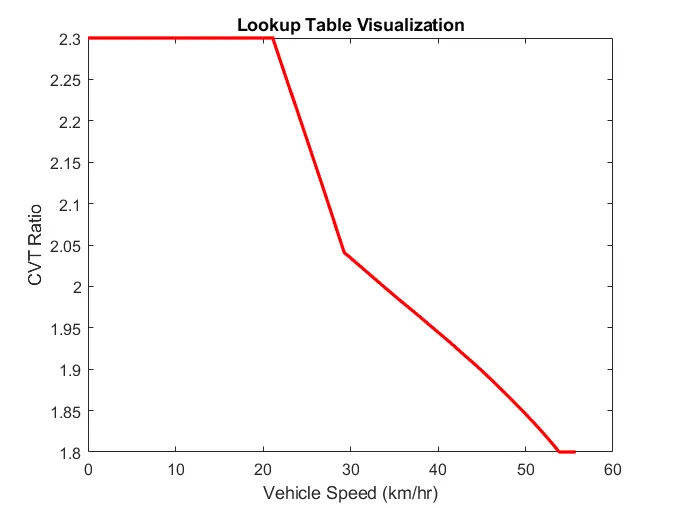
The plot reflects tabulated data specified for the block. Now we can apply the data’s into the model and simulate the results
3. BAJA ATV Model
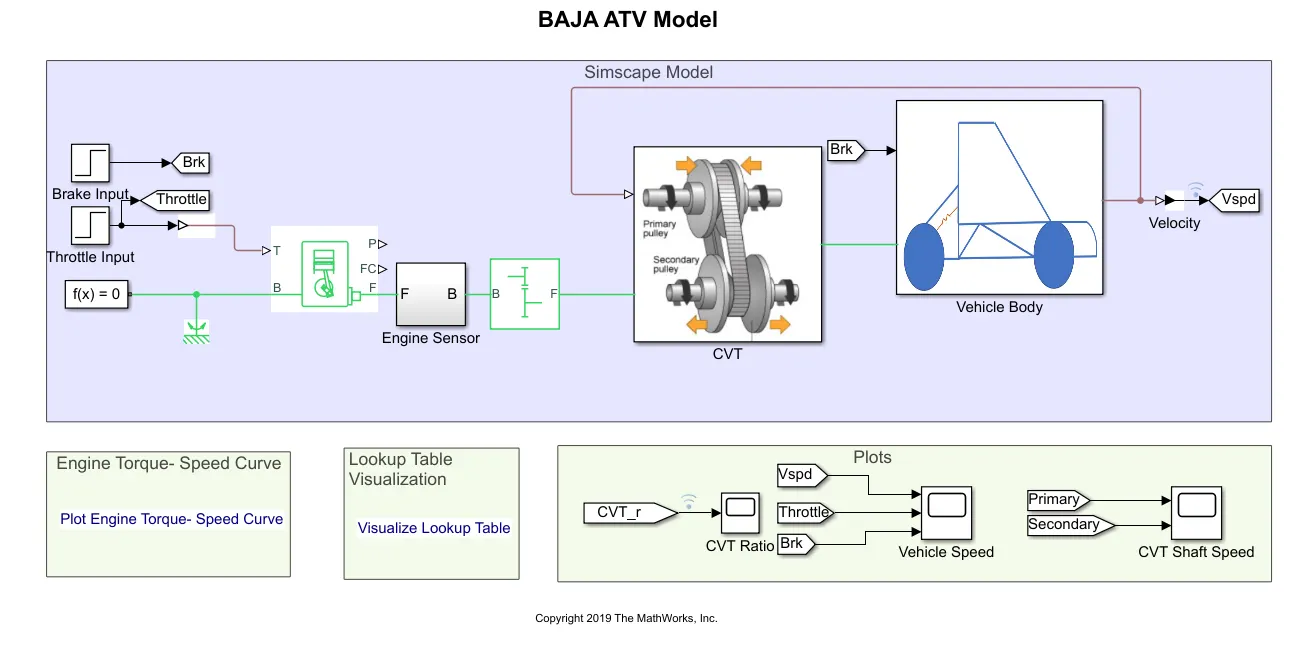
In this model the only differences from previous model are, the break and throttle inputs are given as step block values and CVT ratio is given through lookup table block. In break input, the step time is 35 and in throttle input, the step time is given as 20. In previous cases, the gear ratios were given to CVT subsystem as signals using signal builder blocks. Here the gear ratios are given externally using lookup tables. For this, a PS lookup table block is inserted in CVT subsystem. Now the simulation is performed and the results are plotted below.
Results
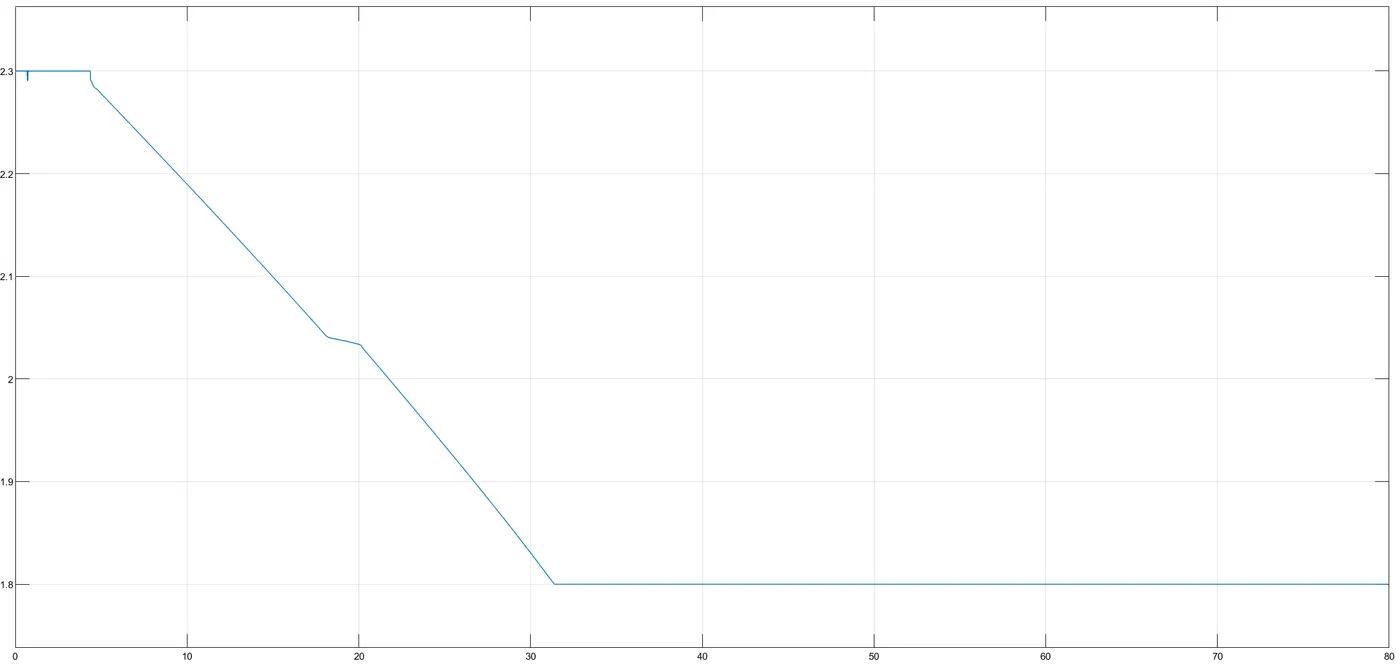
As we can observe from the plot of CVT Ratio, value decreased from 2.3 to 1.8 when speed was above 30. After that it was constant. The decrease as quite straight because we use step input. Now we can look into vehicle speed for more clarification
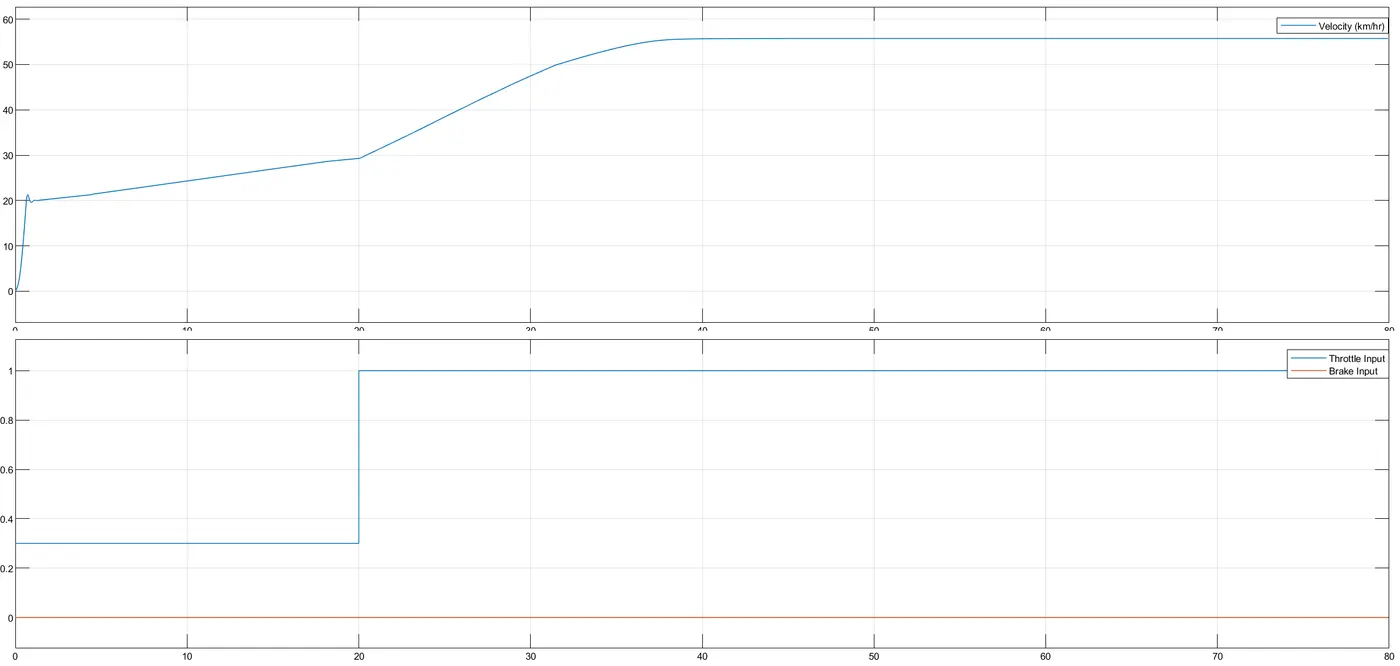
Vehicle speed suddenly increased after 20sec and reached above 55km/hr when throttle was changed to 1. Shaft speed is represented below.
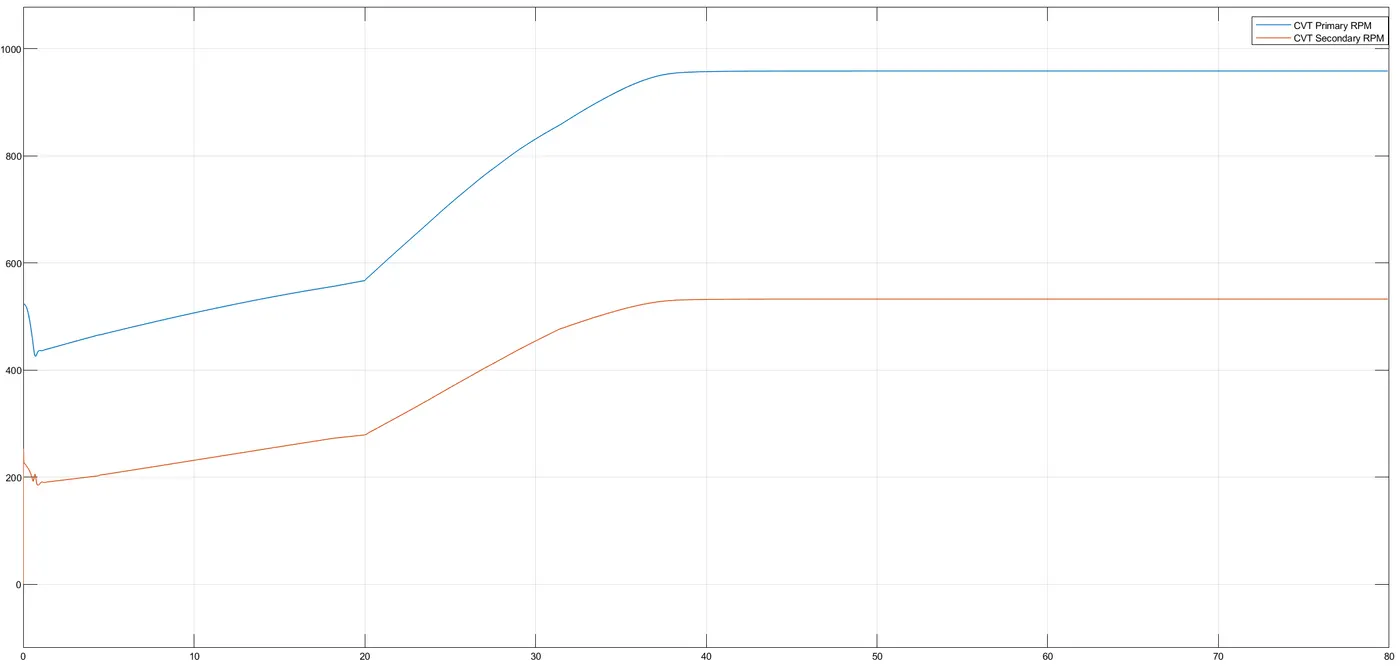
We can observe that, shaft speed exactly resembles the plot which have same kind of throttle input. Now we can check out the conditions for model with dashboard.
4. BAJA ATV With Dashboard
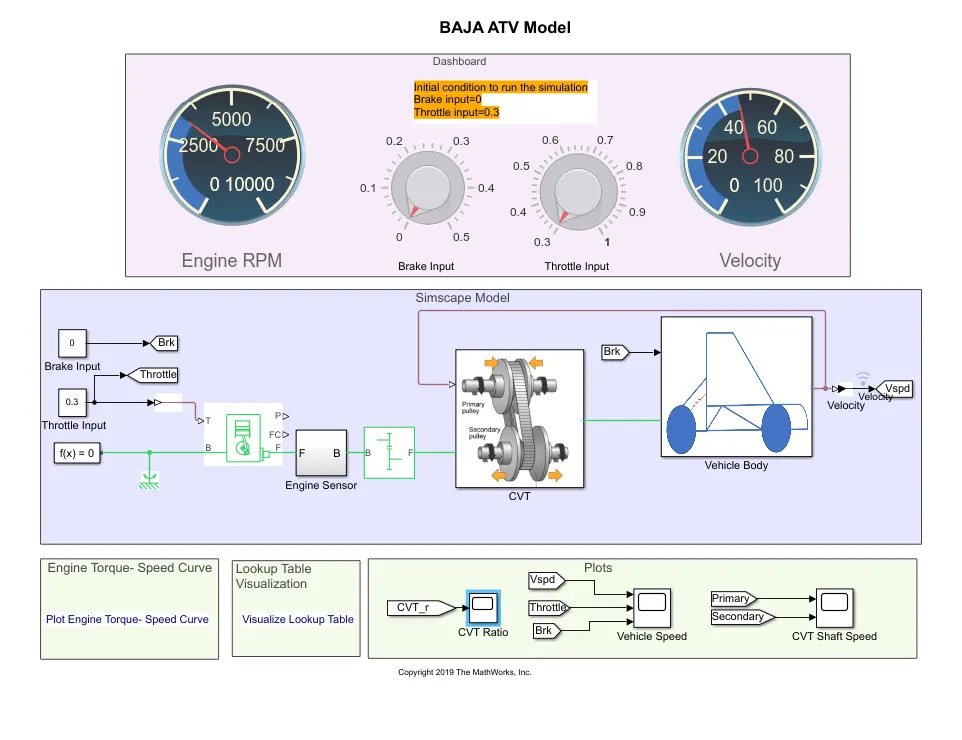
Here, the dashboard is made-up with two knobs and two custom gauges. The knobs give break and throttle input and the gauges represent the velocity and rpm. And in like previous model, CVT system is provided with lookup table block were we give gear ratio inputs. After running the simulation we got the results and they are given below.
Results
We start with the initial condition provided and will change accordingly.
Throttle input = 0.3 and Break input = 0
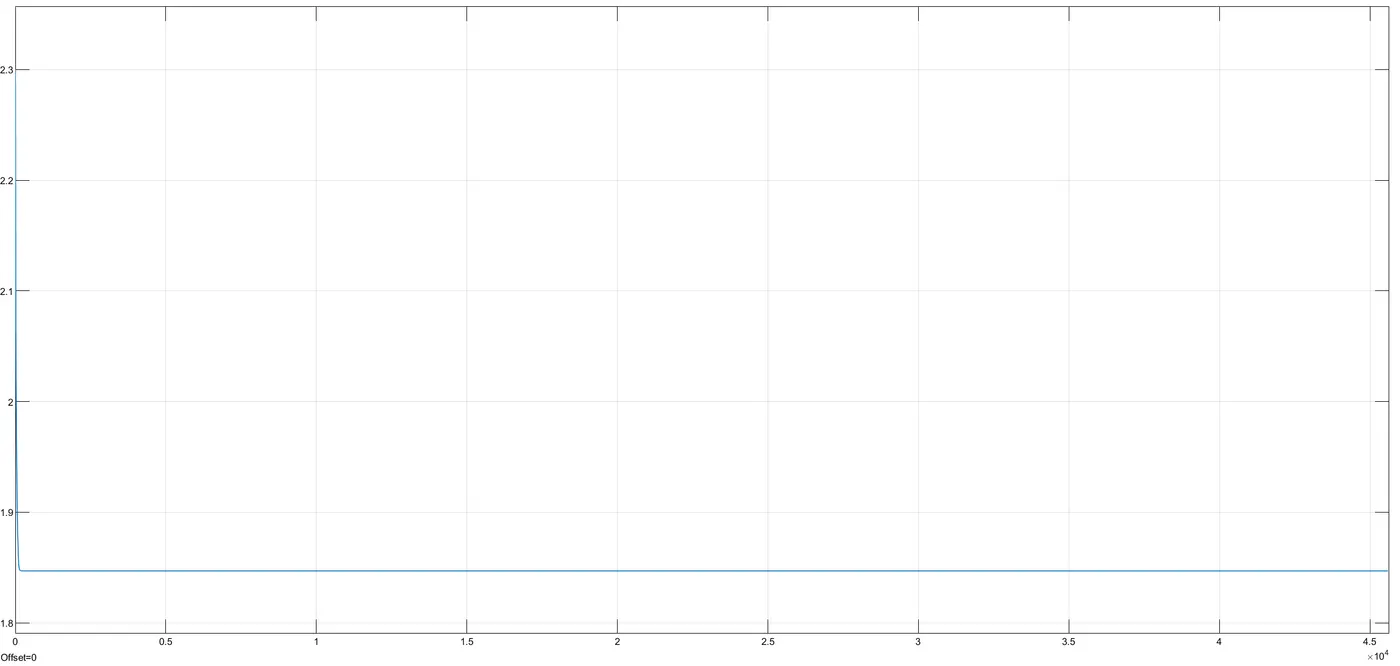
CVT Ratio plot is represented above. We can observe that the value was suddenly changed to a constant value of 1.85 when simulation as conducted with 0.3 throttle input.
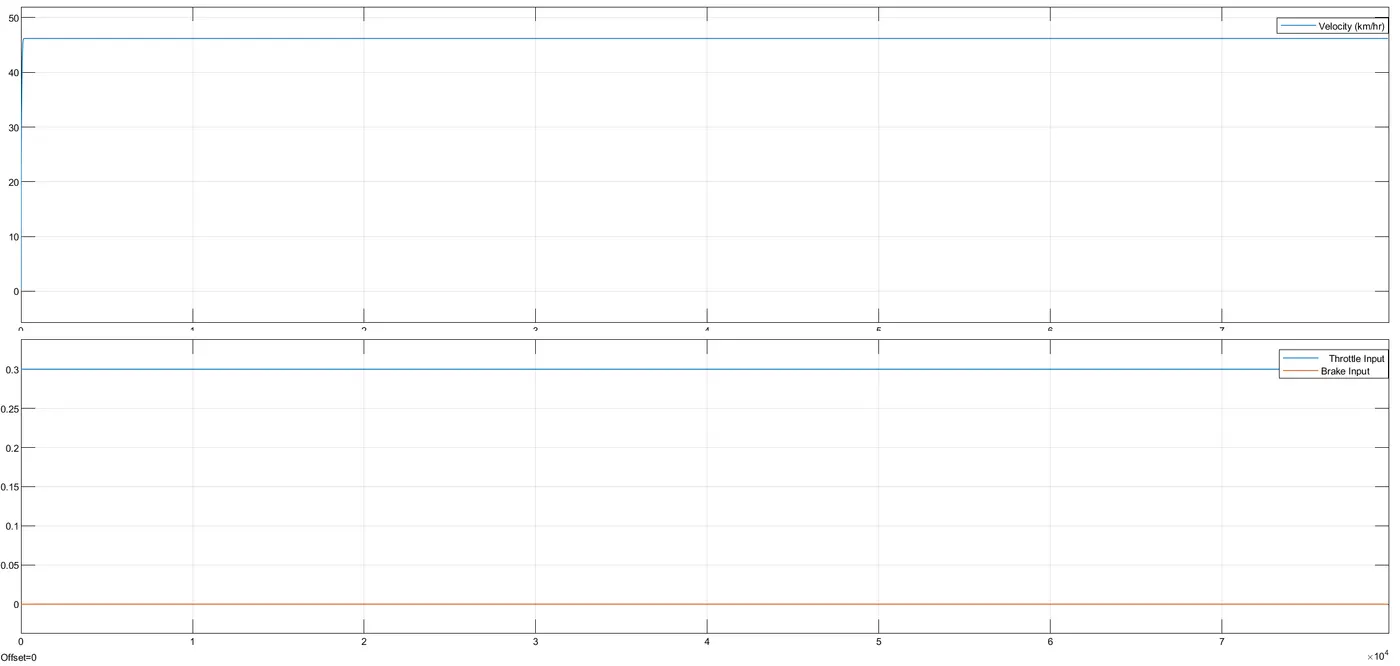
Vehicle Speed was constant at about 45km/hr as the throttle input was constant. So the shaft speed was also constant and it is represented below.
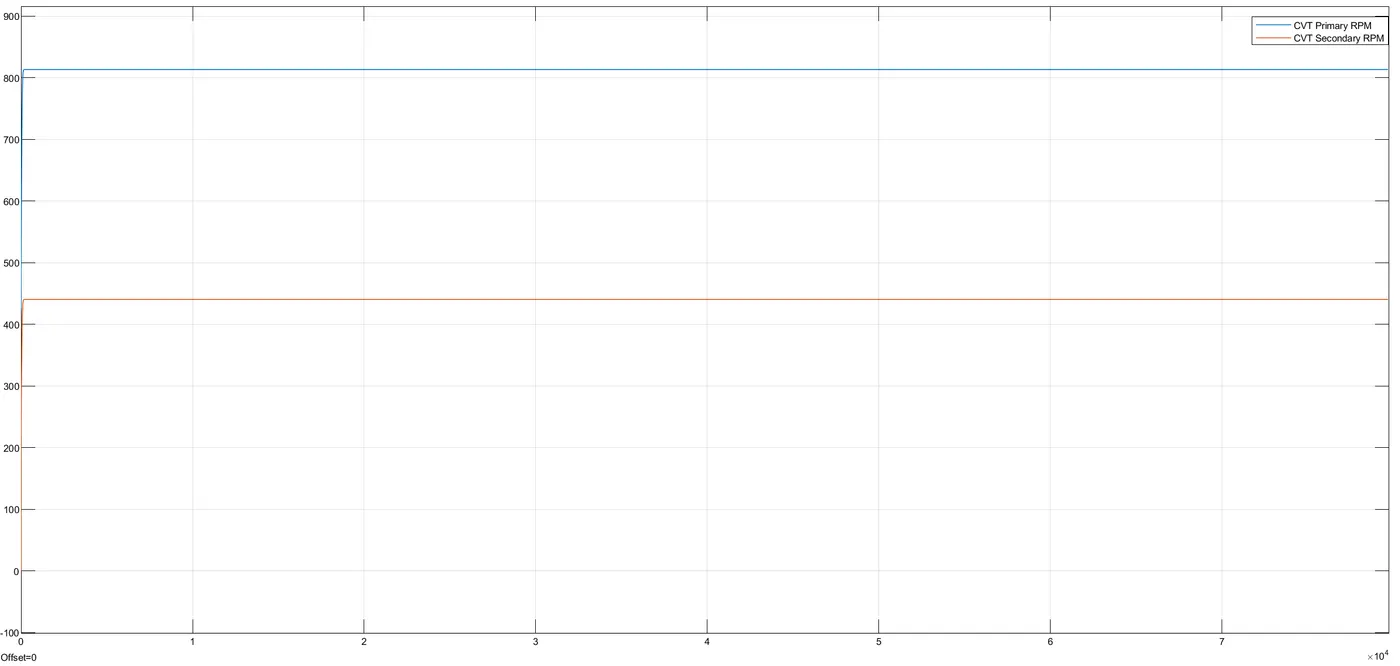
Both shaft speed was constant
Throttle input = 1 and Break input = 0.5
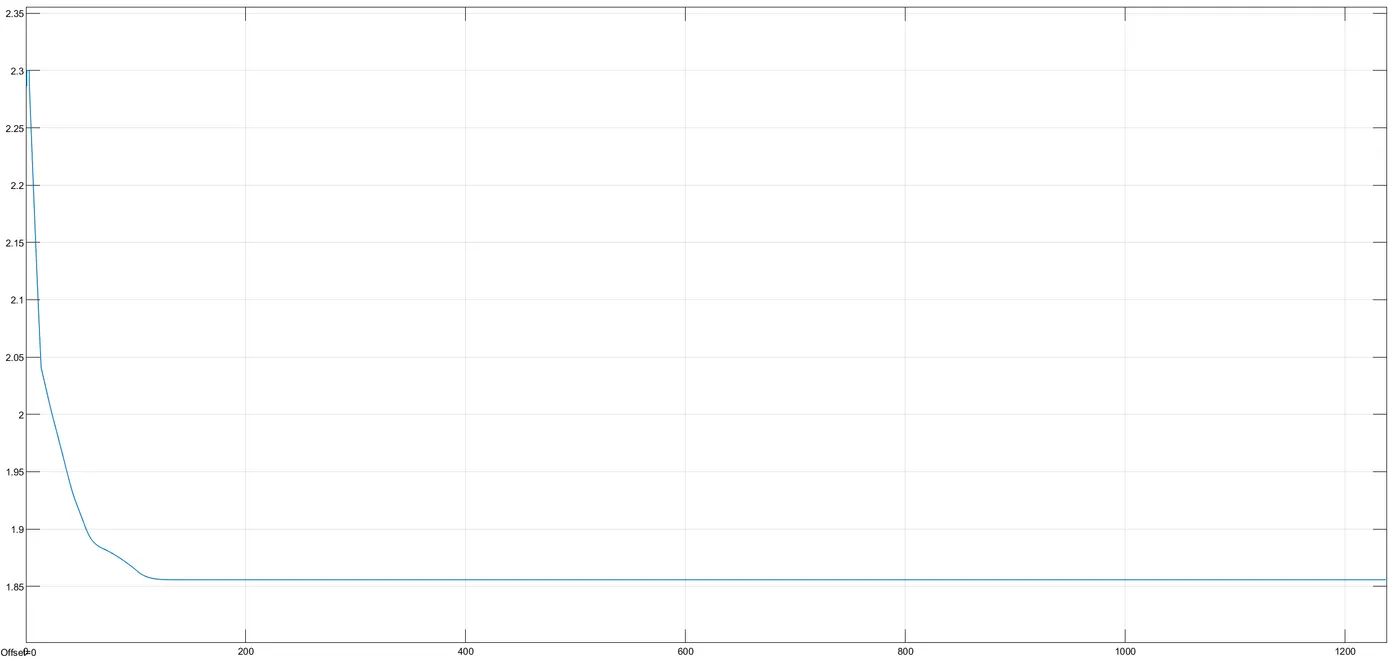
CVT ratio gained the constant value in more time compared to other cases because the break input as also present. So break input can make the time more high. The vehicle speed plot is represented below.
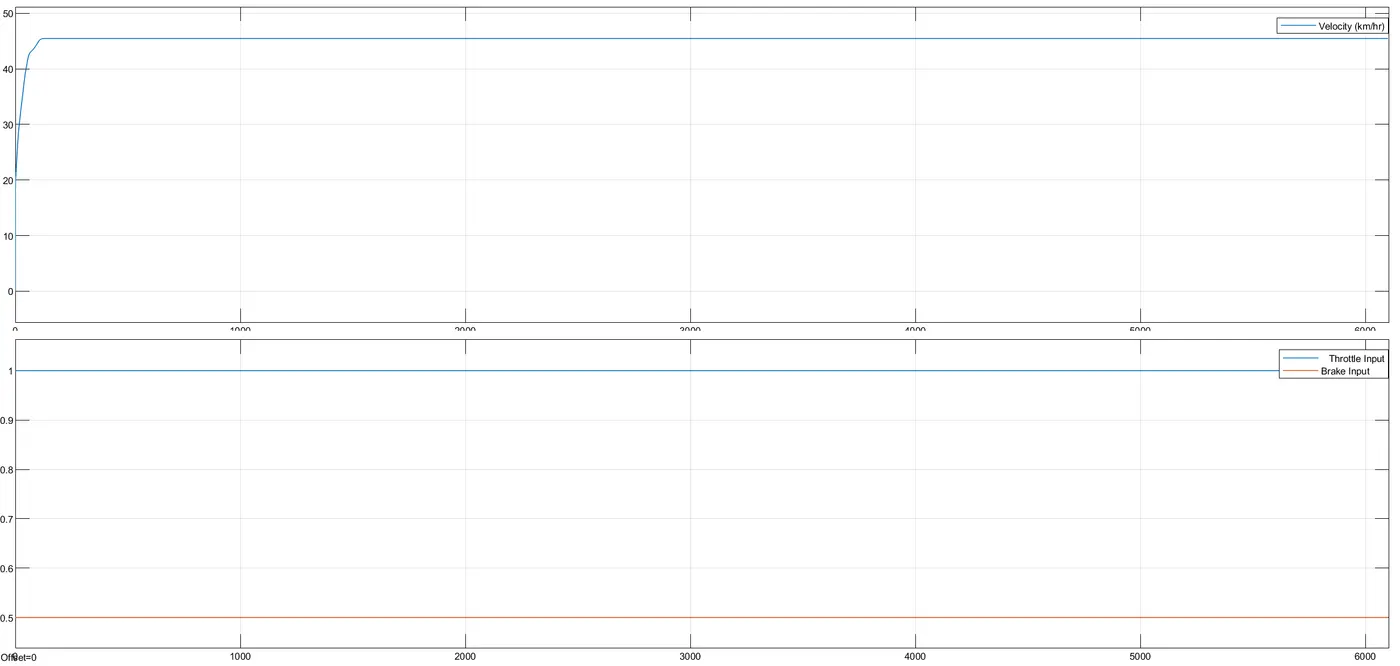
In the starting there was some irregularities in the plot. The break input teried to resist the velocity but evantually it reached the maximum value. Break input made the saturation time high.
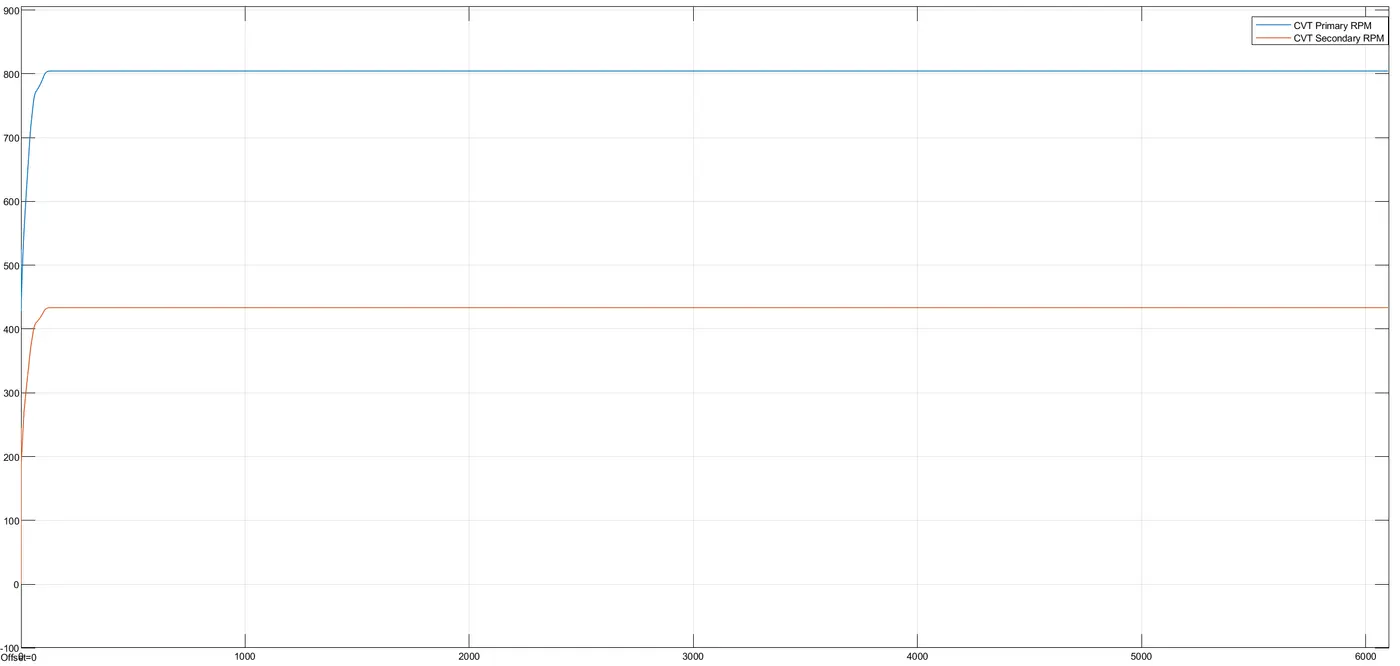
Above graph shows the shaft speed plot and we can observe thatt, as in velocity the shaft speed as aslo affected by the break input.
Throttle input = 1 and Break input = 0
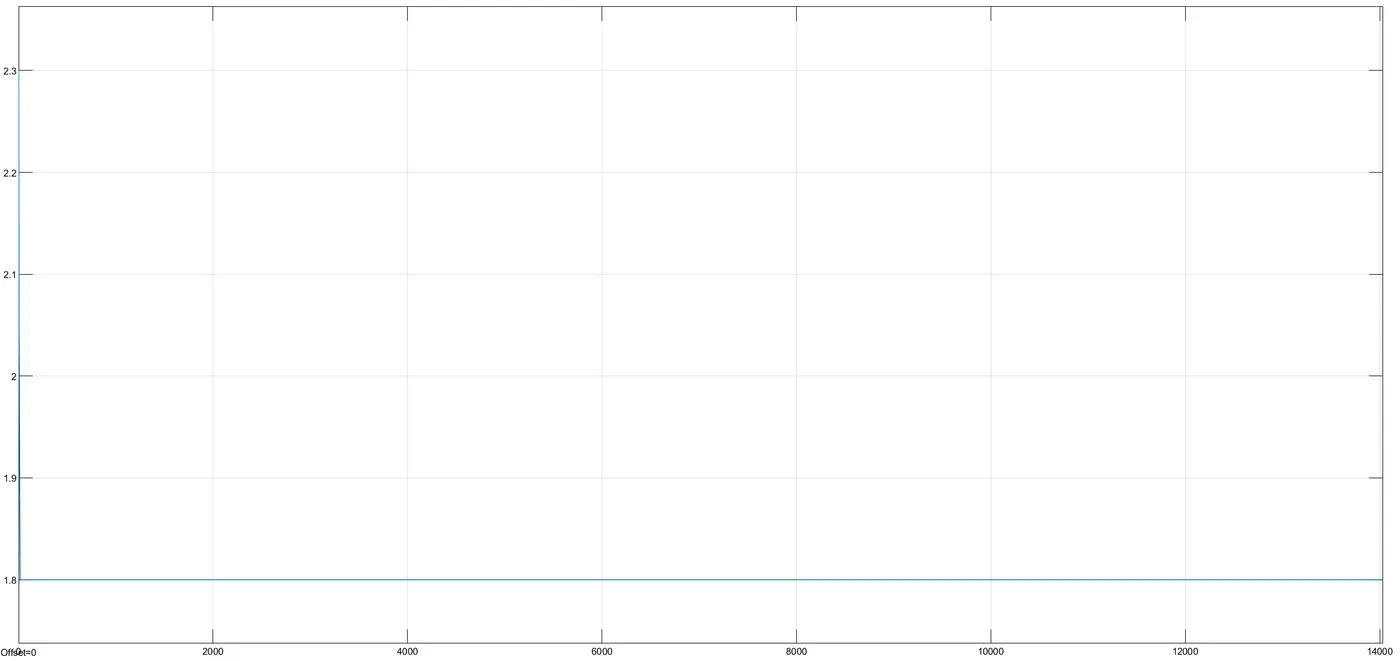
When the throttle input was maximum and there was no break input, the value perfectly reached 1.8 and was constant in short span. Now given plot represents the vehicle speed.
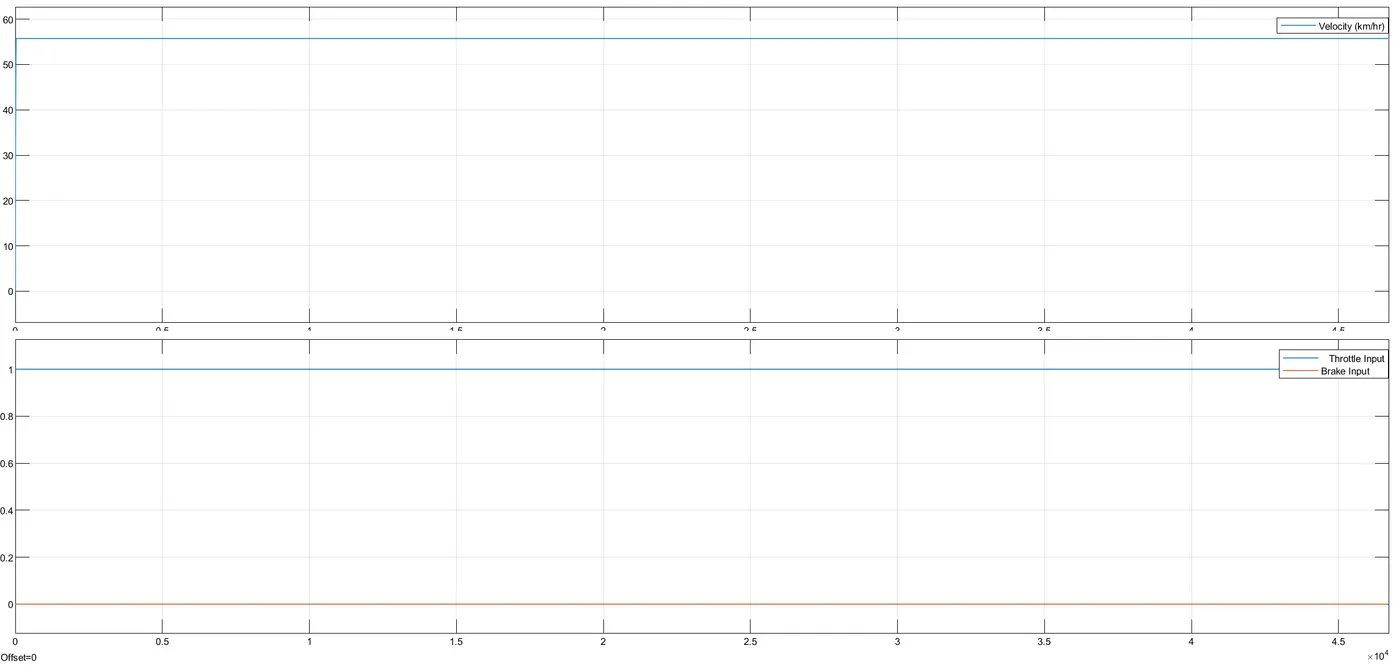
Vehicle Speed as also at the maximum range because of the high throttle input and by the absence of break input. It reached the maximum value at short time and was constant. The plot for shaft speed is given below.
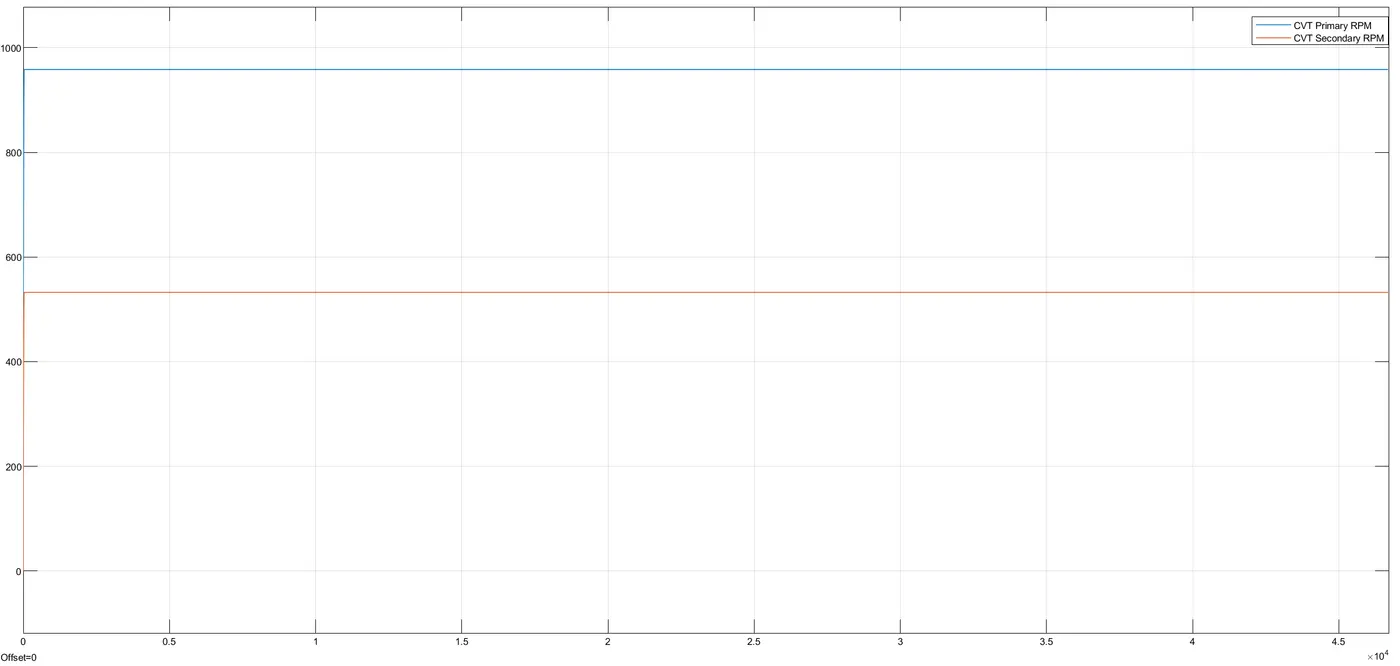
Like above plots, the shaft speed was also high and constant due to maximum throttle input.
Conclusion
Simulation for the all terrain vehicle was done and results were obtained.