Project
BAJA ALL TERRAIN VEHICLE (ATV) ANALYSIS USING SIMULINK: -
AIM: - To study and analyze the Baja all-terrain vehicle (ATV) using Simulink. And to prepare a technical report.
ALL TERRAIN VEHICLE: - An all-terrain vehicle is a quadricycle, light utility vehicle as defined by the american national standards institute (ANSI), this vehicle travels on low-pressure tires, with a seat that is straddled by the operator, along with handlebars for steering control. It is designed to handle a wider variety of terrian than most other vehicles.
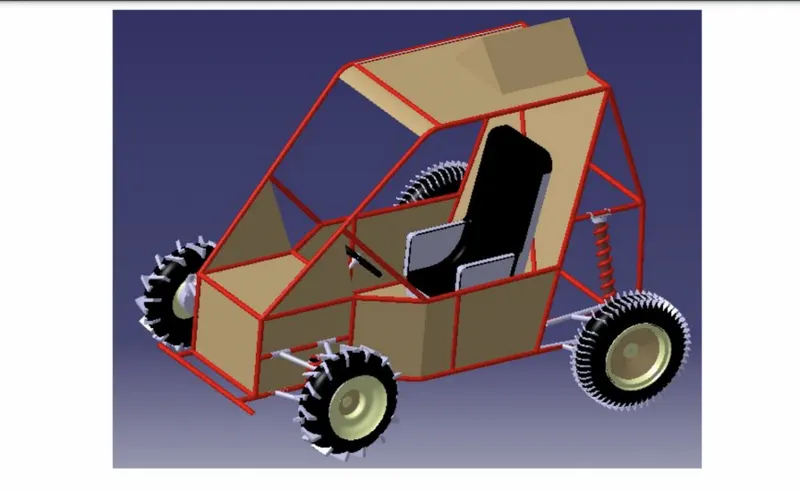
BAJA ATV: - The BAJA ATV SAE is an event for UG engineering students. The Baja tasks to the students are to design, fabricate, and analyze the four wheeled off-road vehicle to take part in event. The test for the vehicle will have many tests like design, vehicle sound, speed acceleration and ability to withstand the durability test.
MAJOR COMPONENTS USED IN SIMULATION: -
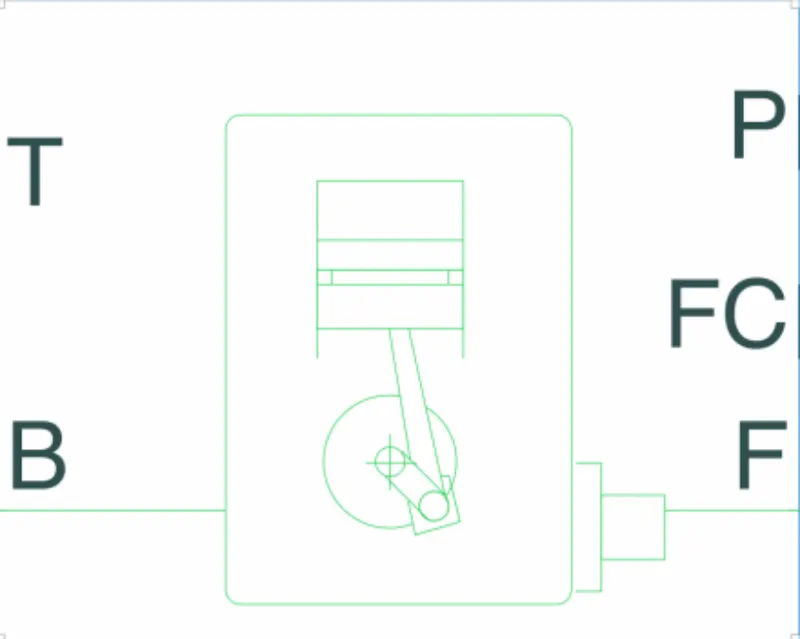
- GENERIC ENGINE: - The generic engine block represents a general internal combustion(ic) engine, which is a type of spark ignition (petrol) or compression ignition(diesel) the speed torque and speed power parameters are provided.
Ports
B- Rotational conserving port representing the engine block.
F- Rotational conserving port representing the engine crankshaft.
T- Physical signal input port specifying the normalized engine throttle level.
P- Physical signal output port reporting the instantaneous engine power in watts.
FC- Physical signal input port reporting the fuel consumption rate, in kg/s.
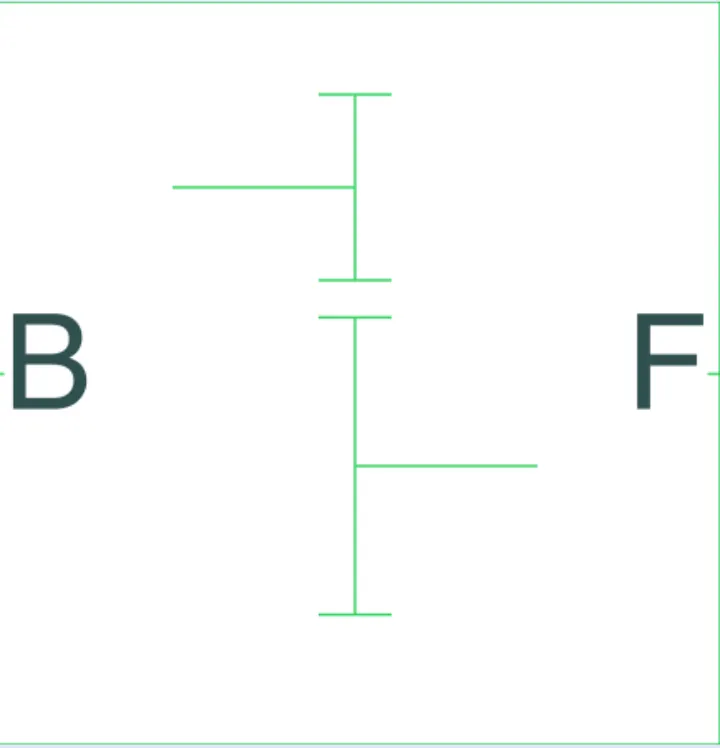
SIMPLE GEAR: - The simple gear is a combination of a driver gear and driven gear where the speed is reduced by the gear ratio. The gear ratio is defined as
Gear ratio= follower gear speed/base gear speed
Ports
B- Base gear or driver gear
F- Follower gear
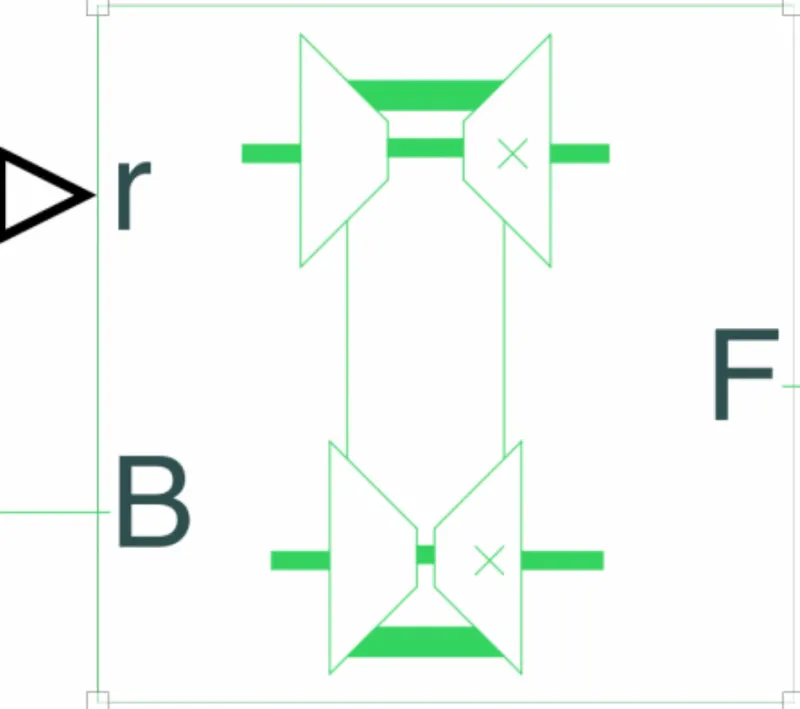
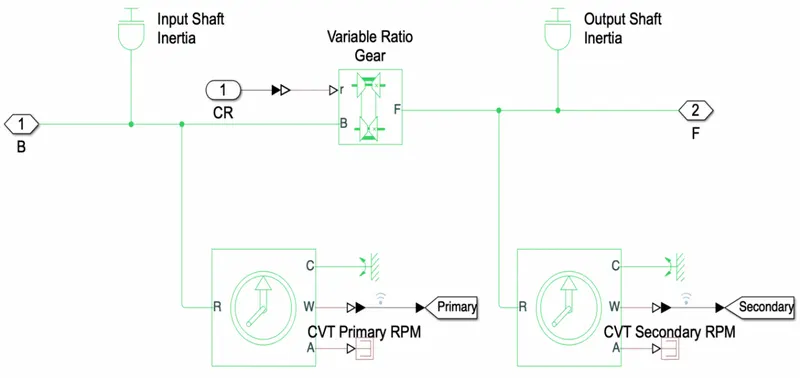
Continuous Variable Transmission: - cvt is mainly used components for the Baja vehicle. A cvt is an automatic transmission that can change seamlessly through a continuous range of gear ratios. This contrasts with other transmissions that provide a limited number of gear ratios in fixed steps. The flexibility of a cvt with suitable control may allow the engine to operate at a constant RPM while the vehicle moves at varying speeds.
Ports
B- Base pulley
F- Follower pulley
R-variable transmission ratio
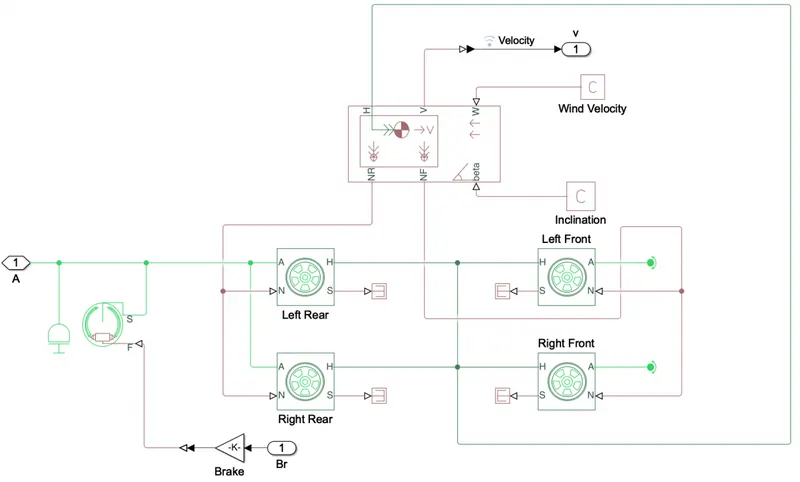
VEHICLE BODY: - Two axle vehicle with longitudinal dynamics and motion and adjustable mass, geometry and drag properties. The vehicle can have the same or a different number of wheels on each axle. For example, two wheels on the front axle and one wheel on the rear axle. The vehicle wheels are assumed to be identical in size. The vehicle can also have a center of gravity that is at or below the plane of travel.
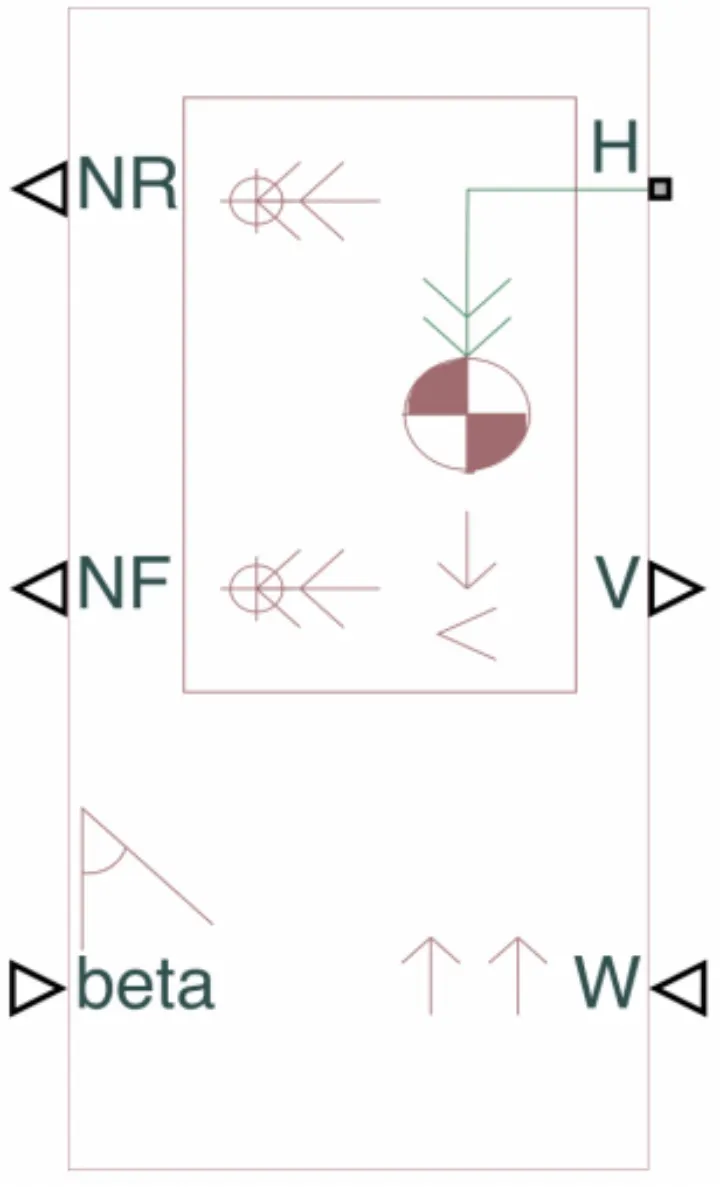
Ports
NR- Rear axle normal force(N).
NF- Front axle normal force(N).
Beta- Road incline angle(rad).
V- Longitudinal velocity(m/s).
W- Head wind speed(m/s).
H- Horizontal motion.
DOUBLE SHOE BRAKE: - The brake block represents a frictional brake with two pivoted rigid shoes that press against a rotating drum to produce a braking action. The rigid shoes sit inside or outside the rotating drum in a diametrically opposed configuration. A positive actuating force causes the rigid shoes to press against the rotating drum. Viscous and contact friction between the drum and the rigid shoe cause the rotating drum to decelerate.
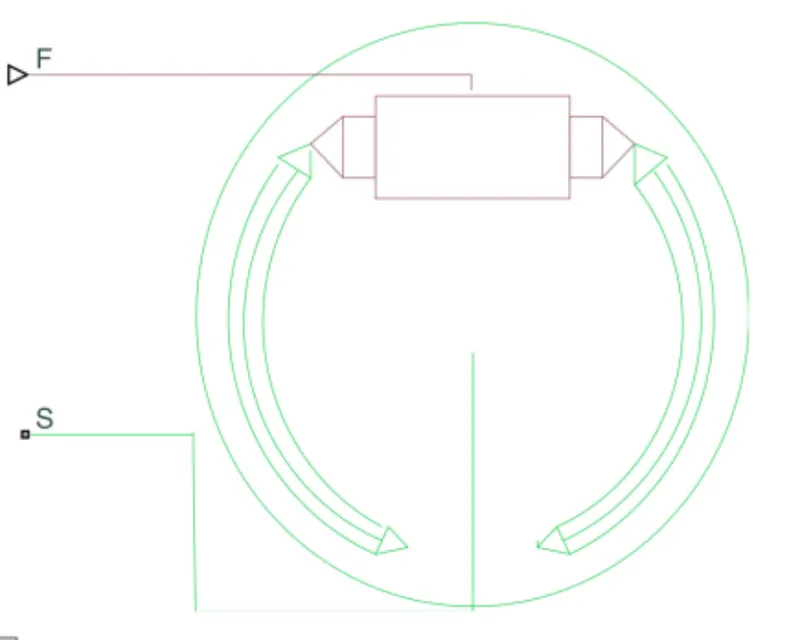
Ports
S- Rotational conserving port associated with the rotating drum shaft.
F- Physical signal input port associated with the applied actuating force.
TIRE: - The vehicle body is connected to 4 tires each per axle to move the vehicle according to the power input to the axle.
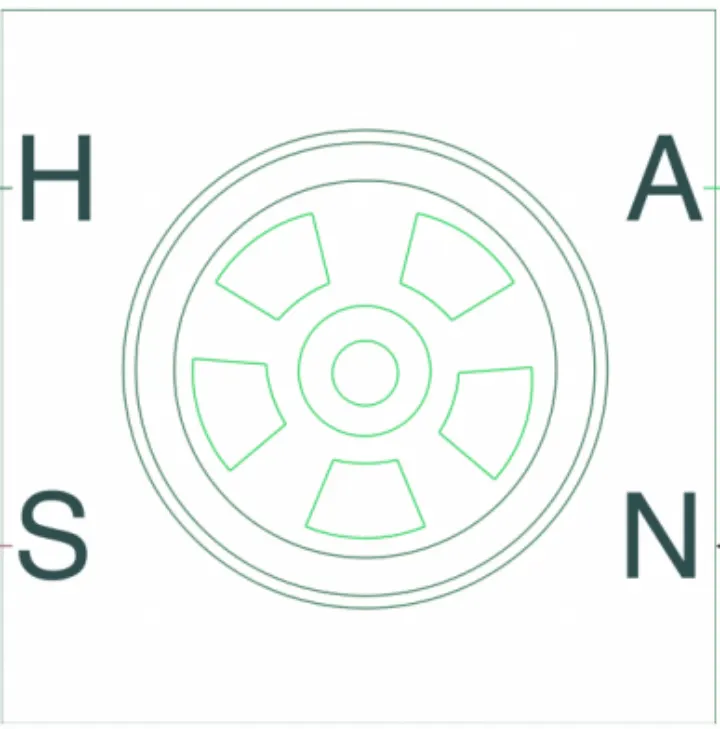
Ports
N- Normal force.
S- Tire slip.
A- Axle.
H- Mechanical translational port associated with the wheel hub transmits the thrust generated by the tire to remainder of vehicle.
BLOCKS USED :
- Signal builder - to input the brake, throttle and cvt ratio.
- Simulink to PS converter- to convert the Simulink signal to simscape environment.
- Solver configuration- to specify the solver parameters before starting the simulation.
- Mechanical reference- to make all components clamped to the ground.
- Generic engine - to run the engine with speed and torque values as input.
- Ps to Simulink converter - to convert simscape signal to Simulink environment.
- Scope - to view the graph of the parameters for better understanding.
- Display - to view the calculated engine power.
- Inertia - to represent solid inertia.
- Rotational motion sensor- to sense the rotational motion from the engine and give output as RPM.
- Variable gear ratio- to vary the speed according to the gear ratios.
- PS terminator- terminator for unconnected physical signal outputs.
- Double shoe brake- to apply brake to vehicle when needed.
- PS constant- generates constant physical signal.
- Tire -for transportation of the vehicle.
- Rotational free end- for mechanical component (tire)
- Vehicle body- to represent the BAJA ATV model body.
- Custom measure gauge- to measure the brake and throttle input.
- Knob - to increase, decrease and vice versa of throttle and brake inputs.
- Lookup table- to insert the cvt values from the workspace.
- Simple gear- to reduce the speed of the engine with pre-defined gear ratio.
- Step- to increase or decrease an input value for a defined time interval.
MAJOR TYPES
- BAJA ATV model without dashboard.
- BAJA ATV model with dashboard.
- BAJA ATV model - mapped lookup table dashboard
BAJA ATV MODEL WITHOUT DASHBOARD
MODEL
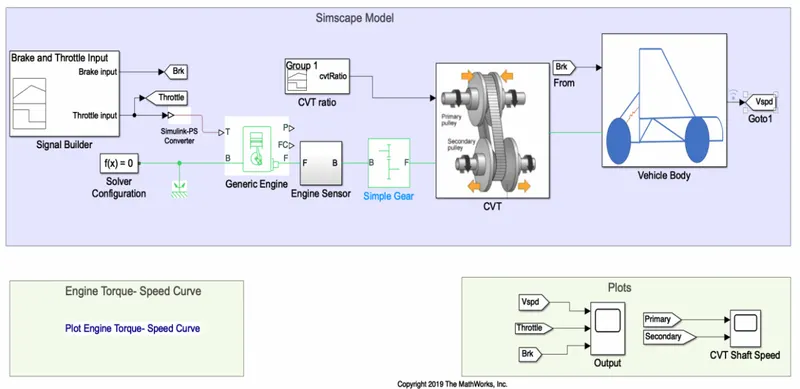
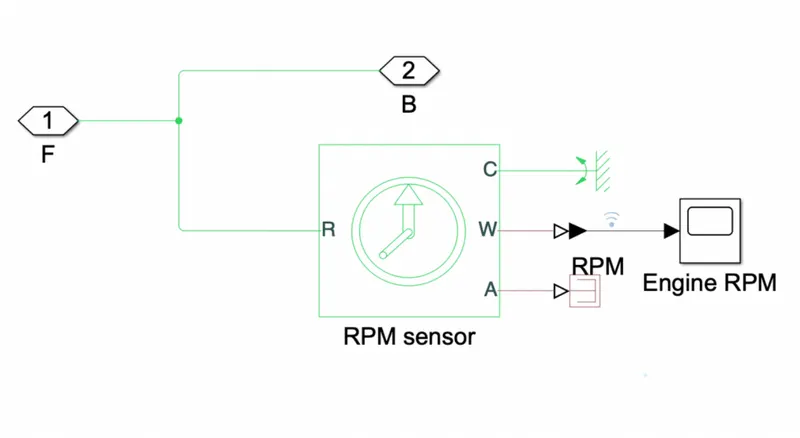
ENGINE SENSOR: - This block measures angular velocity or angle in a mechanical rotational network. The sensor is ideal since it does not account for inertia, friction, delays, energy consumption, and so on. The physical signal ports W and A report the angular velocity and angular displacement respectively of port R relative to port C. The measurement is postive when the motion at R is greater than motion at C.
CVT SYSTEM
VEHICLE BODY
SIMULATION
- The throttle signal is generated by signal builder block and input to generic engine.
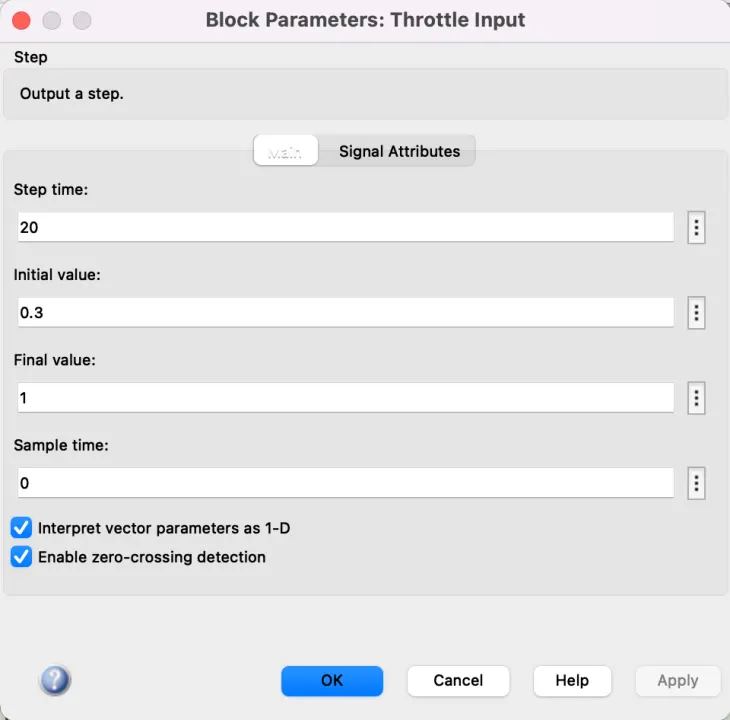
- The torque and speed vector are inputted from Matlab workspace. A constant throttle of 0.3 is maintained up to 20 seconds and throttle is raised for 1 and it is maintained through the simulation.
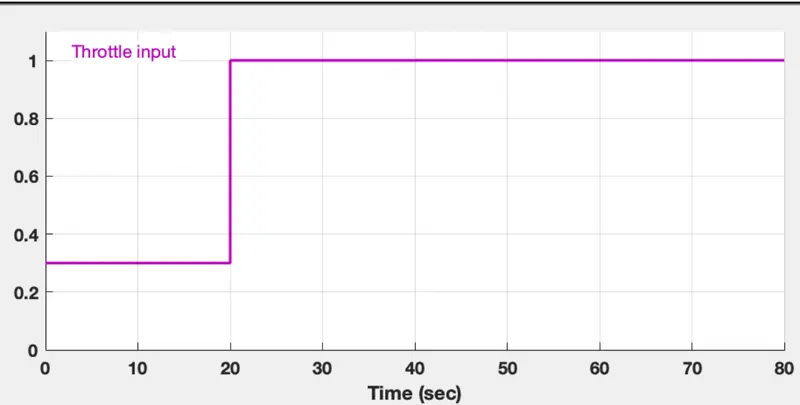
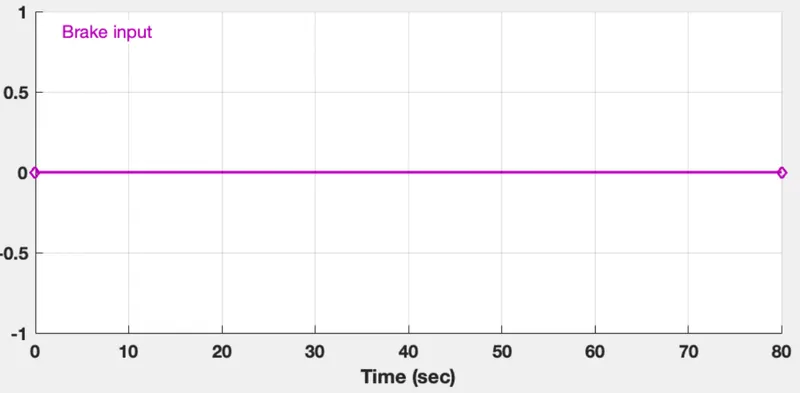
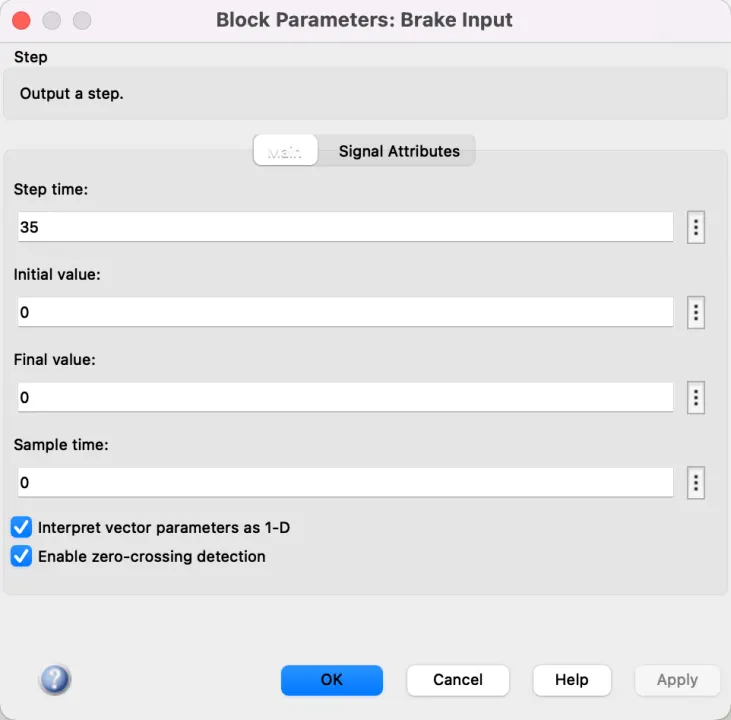
- The brake input is maintained as zero through the simulation. Both the throttle and brake inputs are connected to the generic engine block through the Simulink to PS converter.
- The engine will generate the output rpm which can be taken from the crankshaft output. This speed will be given to the ideal rotational motion sensor to sense the output rpm.
- Then the output speed from the gear reducer will be given to the variable ratio transmission block(cvt).
- This cvt ratio is provided to the variable ratio transmission block through signal builder.
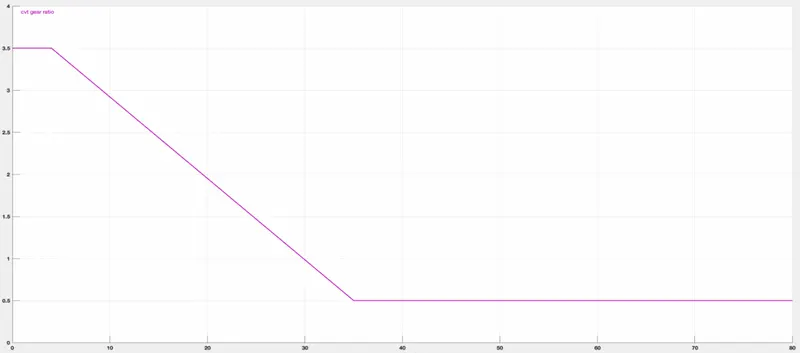
- The speed is controlled by the variable cvt ratios and the controlled output speed is inputted to the vehicle axle.
- The brake signal is generated by the signal builder and input to the vehicle body (shoe brake) for applying the brake to axle.
- The power from the cvt is inputted to the axle and the vehicle accelerates according to the speed.
- Then the velocity is taken as output from the vehicle body for further analysis.
OUTPUT
TORQUE SPEED PLOT
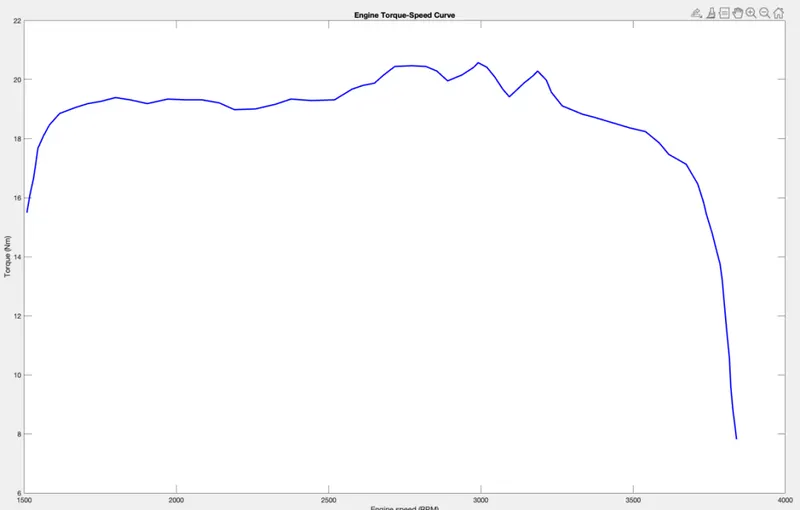
The torque and speed are inputted from the MATLAB workspace window to the generic engine block to generate the output rpm accordingly. This plot is common for all cases because it's a default to the engine.
SPEED VS THROTTLE PLOT
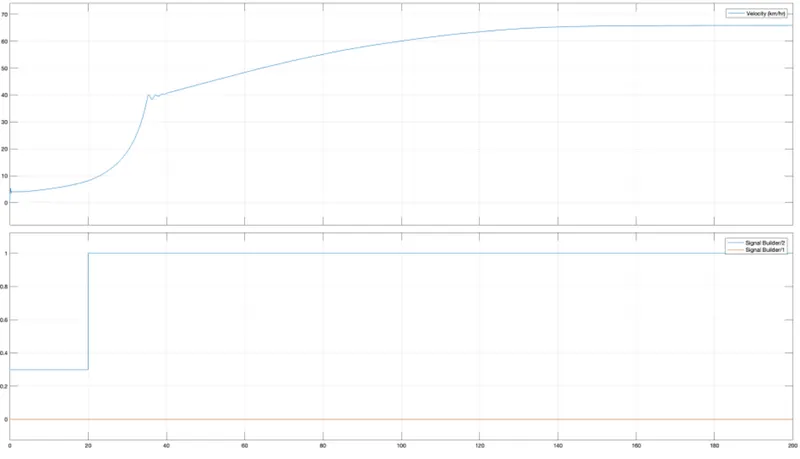
From the graph we can infer that the brake is not applied during the drive cycle and the throttle is constant (0.3) till 20 sec and being increased from 0.3 to 1 from 20 sec where it remains constant for rest of the run . with the increase in throttle the vehicle speed also increases.
ACCELERATION PLOT
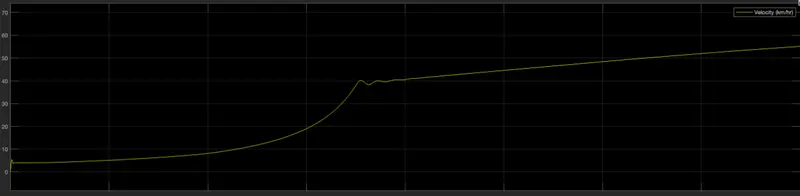
From the above plot we can gather that the vehicle is accelerated from 0-20 kmph and then gradually increases till 30kmph and its accelerated to 55.74kmph where it remains constant throughout the cycle
BAJA ATV MODEL WITH DASHBOARD
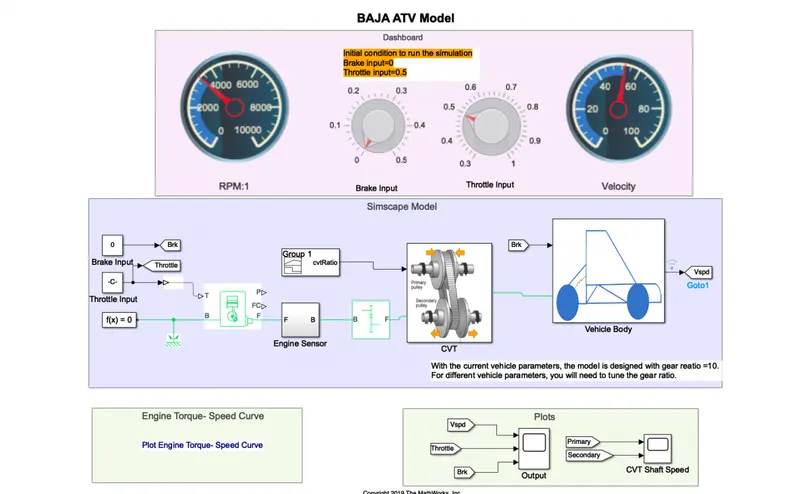
MAIN MODEL:
DASHBOARD:
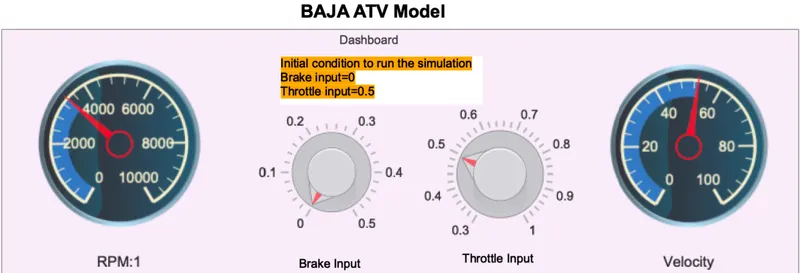
FLOW PROCESS: - the model work flow process is as same as the process of BAJA ATV model without dashboard but the throttle and brake inputs are controlled by the user with the knob. We are also replacing the signal builder with two separate constant blocks for throttle and brake.
OUTPUT
BAJA ATV WITH LOOKUP TABLE
Simulink model: -
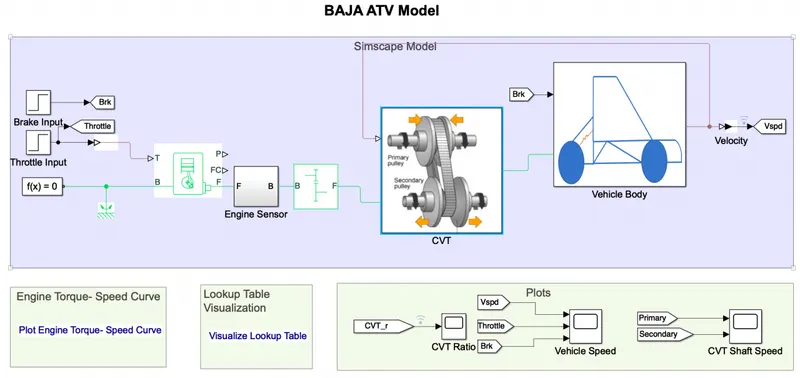
Flow process: -
- The model workflow process is same as the process of BAJA ATV model without dashboard.
- Instead of signal builder blocks for brake and throttle input the step blocks are used at 35 secs the brake input will take a step of value 0 and 20 sec throttle input will increase from 0.3-1 then then remains constant throughout.
- And instead of signal builder block of CVT ratio the 2-D look up table is used. The interpolations and extrapolation methods are set to linear.
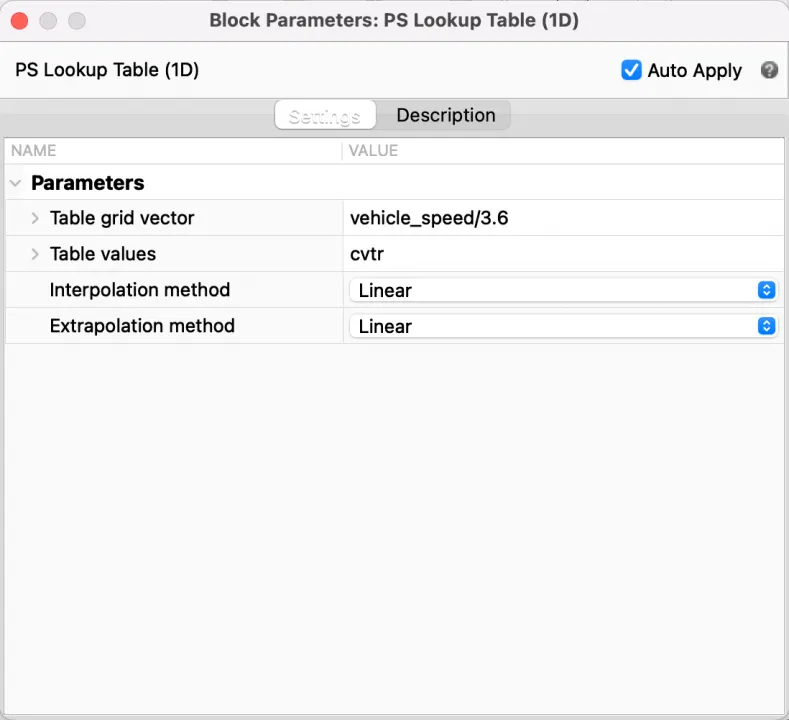
- Finally, the vehicle speed output is given as feedback to the 2d look up table so that we can verify that the velocity of the vehicle is changing perfectly when the CVT ratio changes. The vehicle speed is converted to m/s from kmph
RESULTS:-
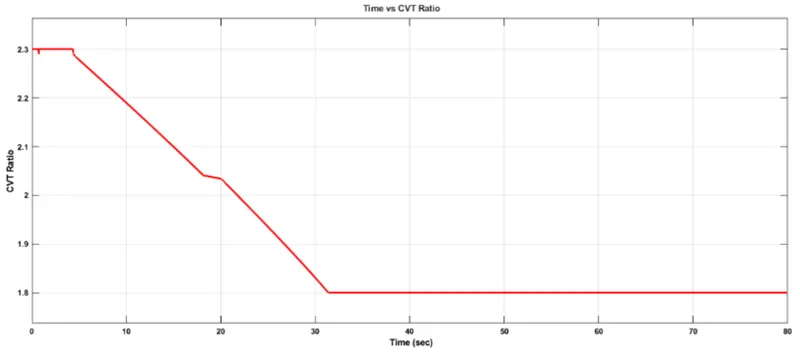
CVT RATIO PLOT
LOOK UP TABLE VISUALIZATION
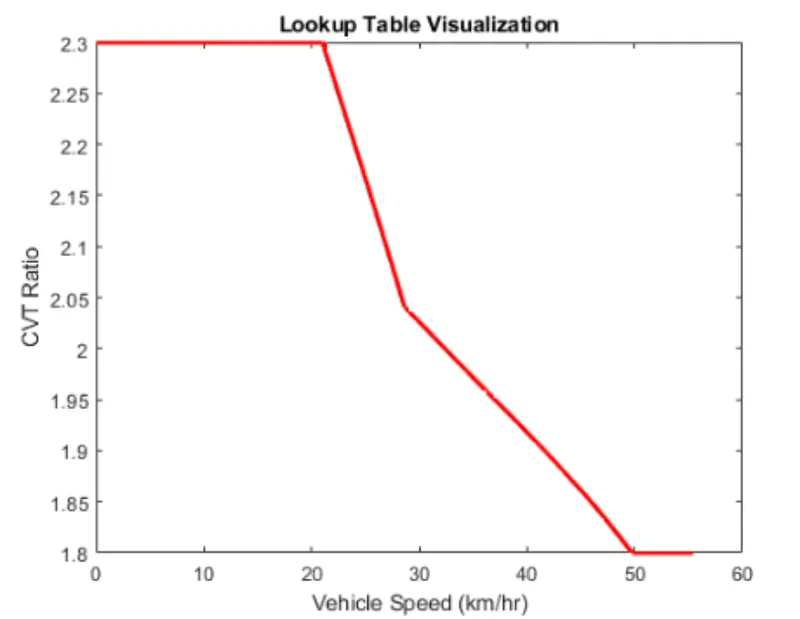
Here the cvt Ratio changes between 2.3 - 1.8 and the velocity value also changes. hence all the aspects of the design of the atv vehicle are studied and interpreted