Project
AIM: To Study And Analyze the BAJA All Terrain Vehicle Model Using Simulink.
Generic Engine:
The Generic engine block represents a general internal combustion engine which is a type of spark ignition og compression ingiyion. The Speed torqe and power parameters are provied
Ports:
B- Rotational Conserving Port representing the engine block
F- rotational conserving port representing the engine crankshaft
T- Physical signal Input port specifying the normalized engine throttle level
P- physical signal output piort reorting the instaneoues engine power in watts
FC- Physical signal Input port reporting the fuel cosumption rate in kg/s
Main Model:
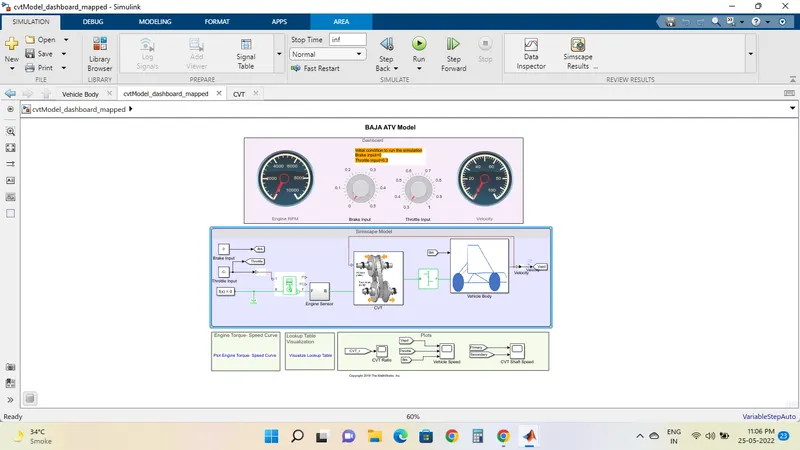
this block measure angilar velocity or angle in a mechanical rotational network. the sensor is ideal since it does not account for inertia friction delays energy consumption and so on.
the physical signal ports W and A report angular velocity and angular displcement repectively of port R relative to Port c the measurements is potive when the motion at R is greater than the motion at c.
MAIN MODEL:
this block measure anglar velocity or angle ina mechanical rorational network. the sensor is ideal since it does not account for inertia friction delays energy cinsumtion and so on.
the physical signal ports W and A report the angular velocity and angular displacement respectively of port R relative to port C. the measurement is positive when the motion at R greater than the motion at C.
SIMULATION PROCESS:
the throttle signal is generated by signal builder block and inputted to generic engine.
the torque and speed vector are inputted from the MATLAB workspace.
the engine will generate the output RPM which can taken From the crankshaft output. this speed will be given to the ideal Rotational motion sensor to sense the output rpm.
the same output speed will be given to a simple mechasim to reduce the speed where the gear ration is 4
this the output speed from the gear reducer will be given to the variable ration transmission block(CVT)
the CVT ration is provided to the variable ration transmission (CVT) block through signal Builder.
OUTPUT:
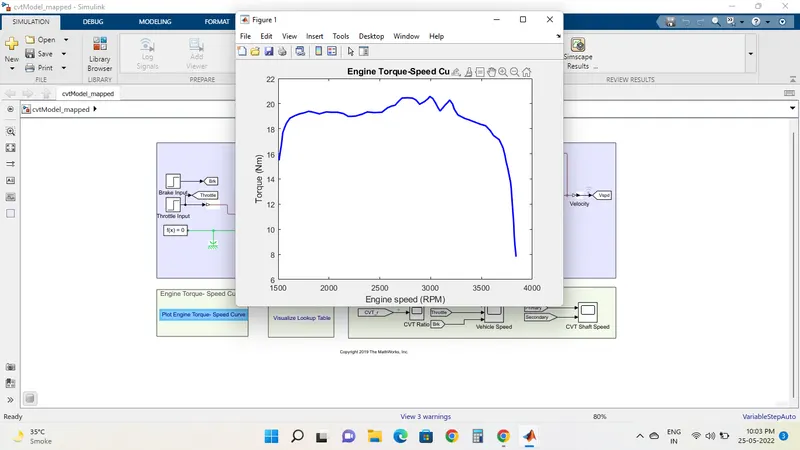
the toque and speed are inputted from the MATLAB workspace window to the generic engin block to generate output RPM accordinly . This plot is common for all the cases it's a default input to the engine