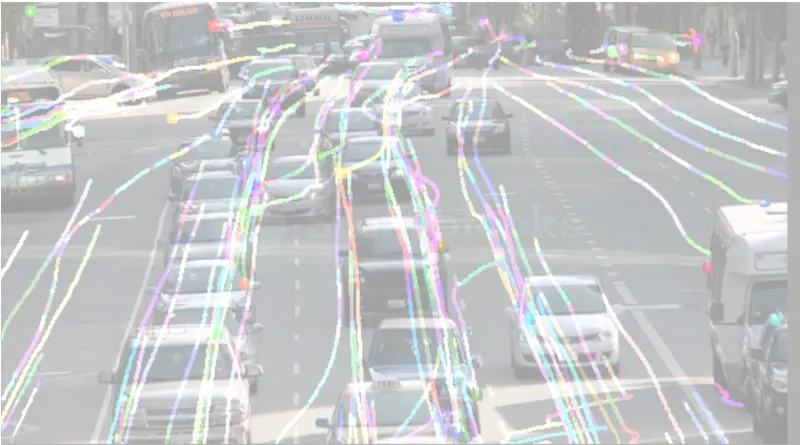
Project 8
The task is to find the optical flow of moving objects using the Lucas Kanade method. Initially, it first finds the corners of the objects in a file using the cv2.goodfeatures functionToTrack function. After finding those points we need to track those points. So to track the points we are using the OpenCV function called calcopticalflowpyrlk(), this function tracks the features where the parameters are :
- prev_image
- next_image
- prev points
- window size
- max level
- criteria
THE max level is the maximal pyramid level number in our case we are taking to 2 which is the first two levels and the criteria is the parameter specifying the termination criteria of the iterative.