Project
AIM:- To studay system level simulation of an all terrain vehical .
KEYWORDS :- CVT,Lookup table dashboard , baja ATV
SOFTWARE :- Matlab,Simulink
OBJECTIVE :-
- Study the baja ATV model without dashboard.
- Study the baja ATV model with dashbord.
- Study the baja ATV model using lookup table without dashboard.
- Studay the baja ATV model ushing lookup table with dashboard
INTRODUCTION:-
- Manual transmission
- CVT (continous variable transmission)
- semi-automatic transmission
- automatic transmission
IMP :-CVT (continous variable transmission)
A continuously variable transmission (CVT) is an automatic transmission that can change seamlessly through a continuous range of gear ratios. This contrasts with other transmissions that provide a limited number of gear ratios in fixed steps. The flexibility of a CVT with suitable control may allow the engine to operate at a constant RPM while the vehicle moves at varying speeds.
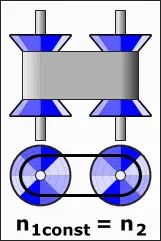
STUDY1:-
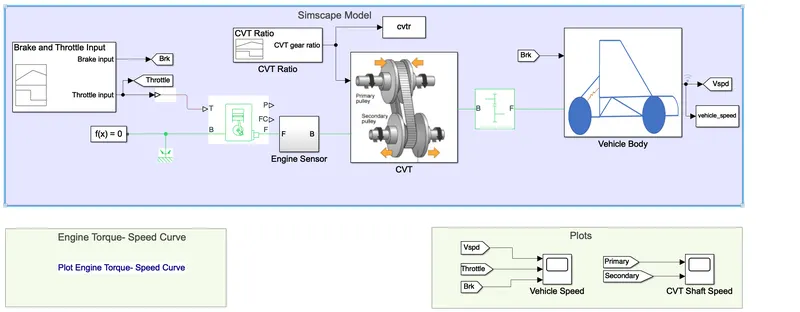
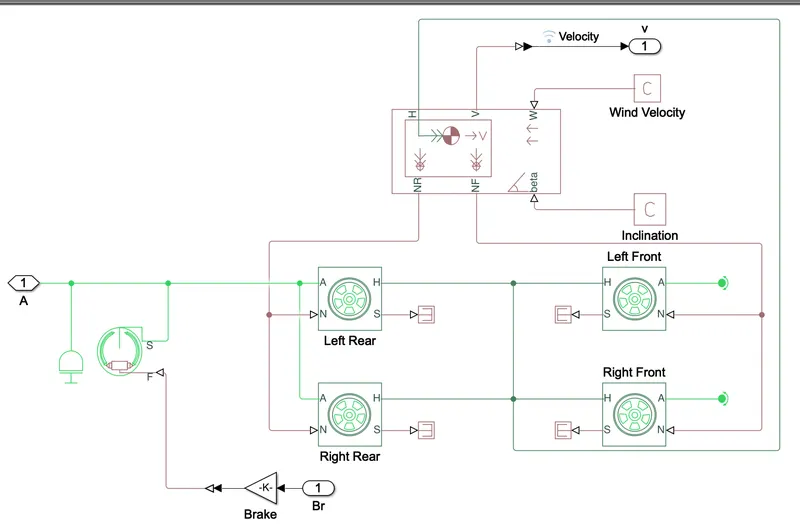
By ushing simulink model of CVT consists of signal builder ,generic engine ,motion sensor ,vehicle transmission,vechicle body,tyars,and solver configartion blockes ,engine sensor etc.AS SHOW INFIGURE-1 the cvt Subsystem includes transmission blocks ,input and output shaft inertia and motion sensor as shown in figure-2 The vechicle boday subsystem includes vehicle body blocks ,double drumbrake and tyres as show in FIGURE -3
FIGURE.1
d. FIGURE-2. CVT SUB SYSTEM
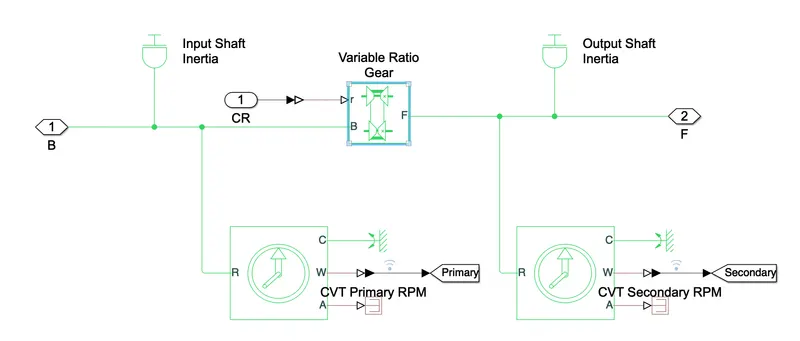 FIGURE-3
VECHICLE BODAY
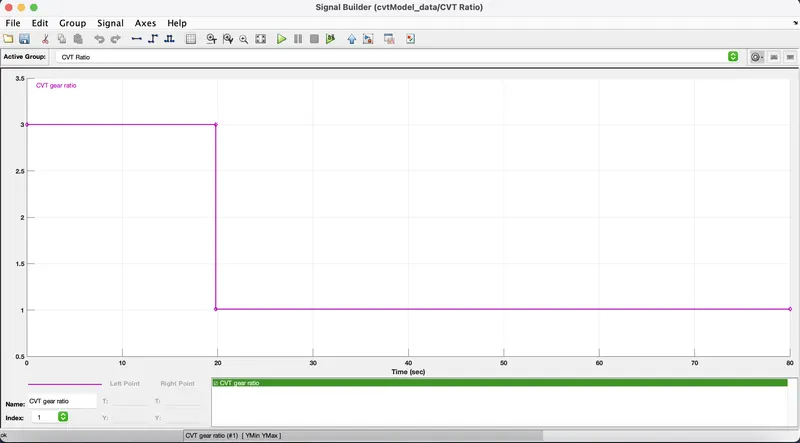
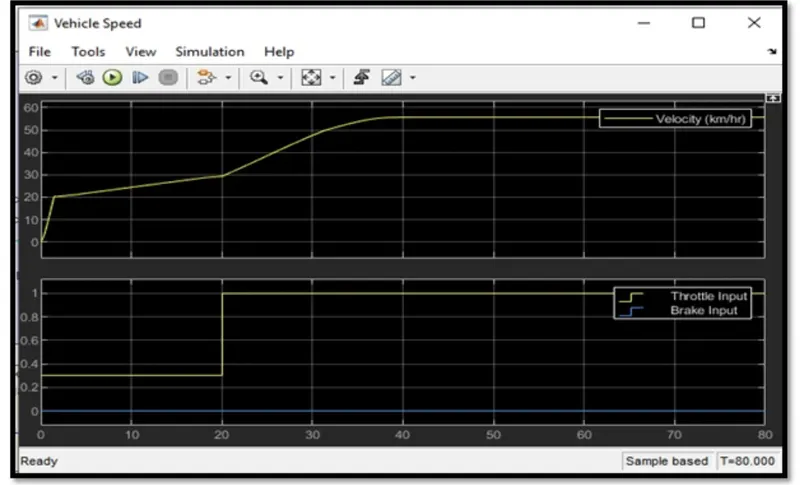
The signal builder is pinput for brake , throttle and gear ratio brake input is maintain as 0 for overall simulation .The throttle input is given as 0.4 for 20 sec and increase for to 1 for overall simulation .The throttle valve is mainly to control the flow or amount of fuel into the engine ,if the throttle value increase the flow value icrease to the ic engine whiche inturn increese the power of the engine .The gear rotion is maintain as 3 for 5 sec and linear decrease 1for 20 sec and maintained constant for overall simulation as show ofn figure 4-5.
figure -4
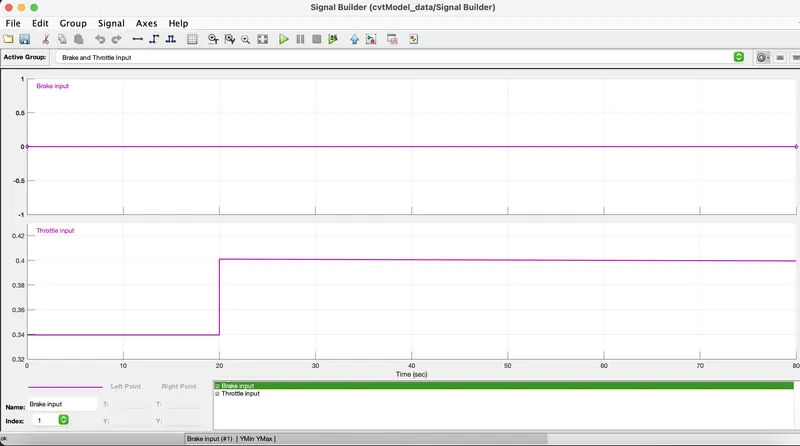
figure -5
and the outuput in figure -6
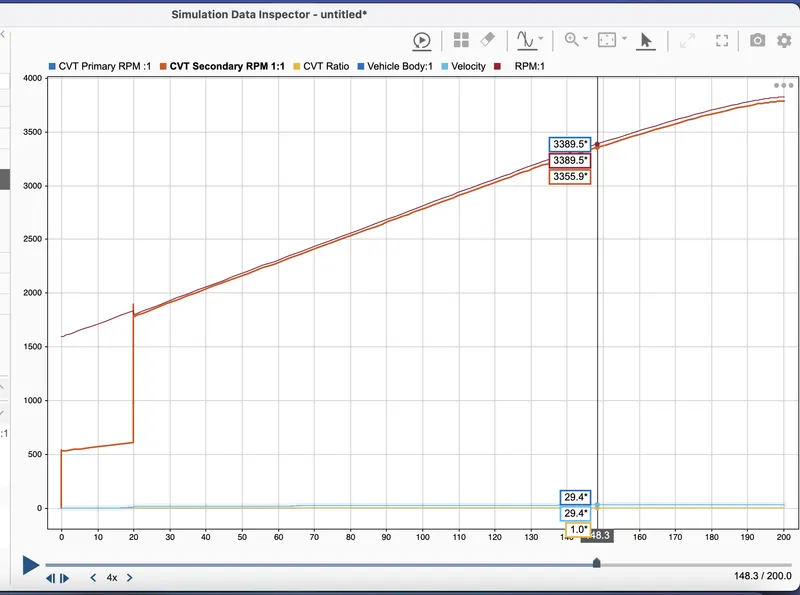
STUDY-1
CASE2
SIMULINK MODEL FOR BAJA ATV WITH CVT USING DASHBOAED
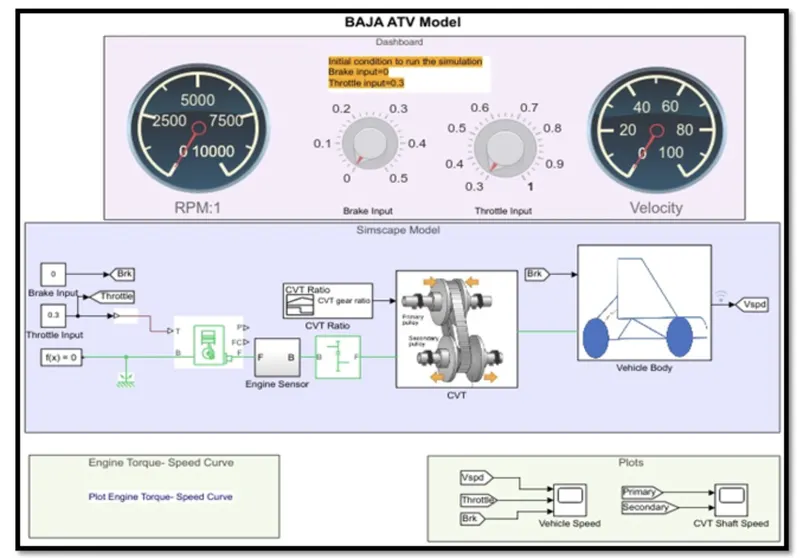
:- IN THIS MODEL WE HAVE A DASHBOARD WHICH CONTAINS KNOBS TO CONTAINS KNOBS TO CONTROL THE INPUT .In this case the input ;Throttle & Brake' are not provided using signal builder .A knob is provided to control both the parameters in real-time for the user .
OUTPUT For case-2
Vehicle speed:
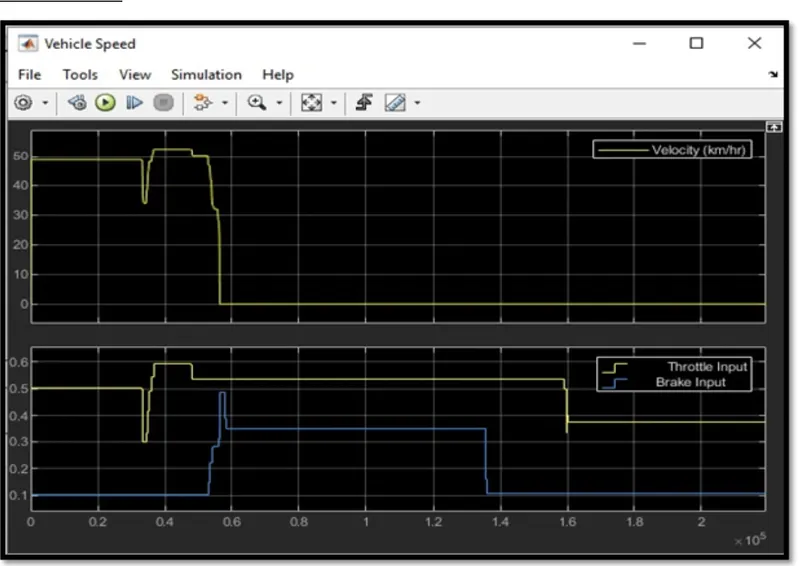
It can be observed from the graph that the velocity of the vehicle increase drastically from 0 to 50 kmph when throttle value is 0.5 & brake input is 0. once the braking value increase from 0.1 to 0.5 brake input is zero .once the braking value increases from 0.1 to 0.5 ,the velocity of the vehicle decrease to 0 at constant throttle value .this explains the direct relation of vehical velocity with respect to throttle and breake input .
CVT SHAFT RPM :-
STUDY :- 2
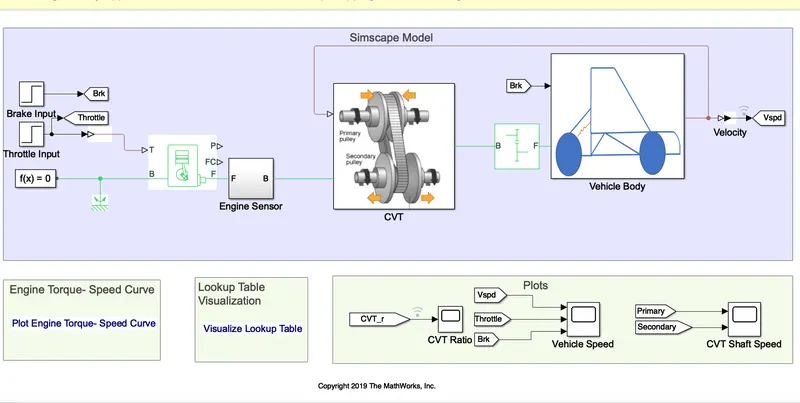
CASE :- SIMULINK MODEL FOR BAJA ATV CVT WITH LOOKUP TAB;LE
CVT BLOCK:-
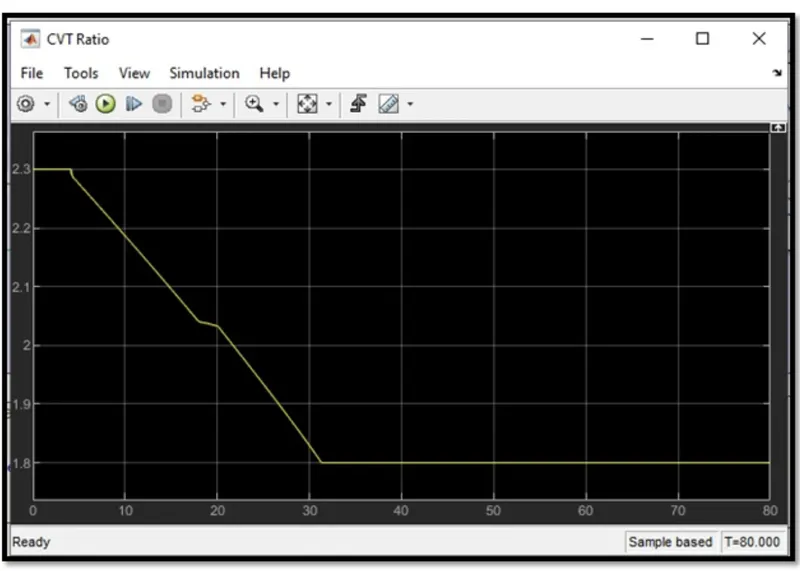
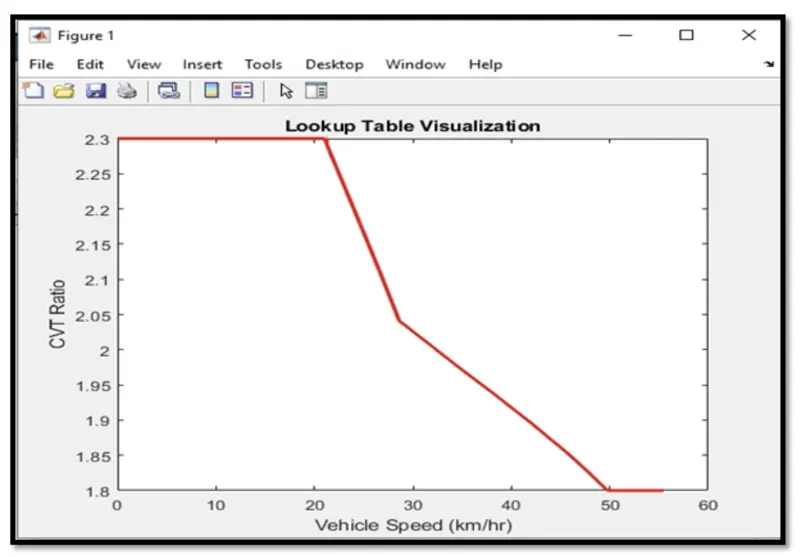
The only difference between this model and the first model is that in this model ,the gear ratio input to CVT is using lookup table .The vehicle velocity and shaft rpm outuput are same asa before
CVT GEAR RATIO :-
LOOKUP TABLE VISUALISATION :-
OUTPUT For CASE:-1
VEHICLE SPEED :-
CVT SHAFT RPM:-
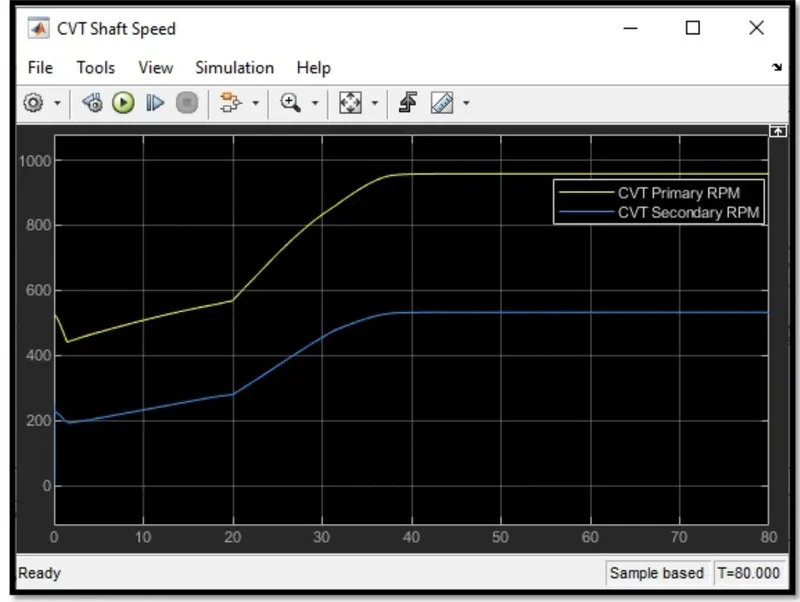 * BOTH RESULT ARE SAME AS THAT OF THE FIRST CASE :- SIMULINK MODEL FOR BAJA ATV WITH CVT SINCE THE INPUT PARAMETERS ARE SAME
STUDAY :- 2
CASE:-2
SMIULINK MODEL FOR BAJA ATV WITH CVT USING LOOKUP TABLE & DASHBOARD
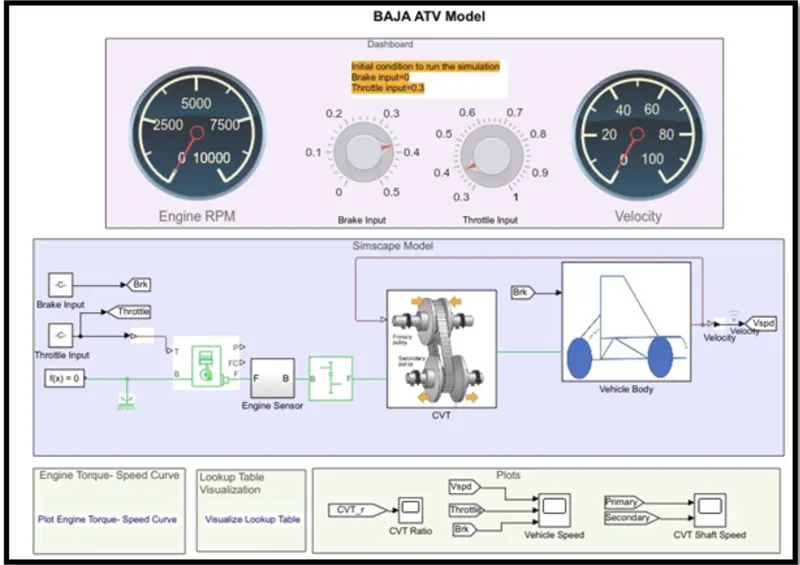
* IN this model a dashboard is used to control the input " Throttle & Brake " with knobs
outuput for case :-2
VEHICLE SPEED :-
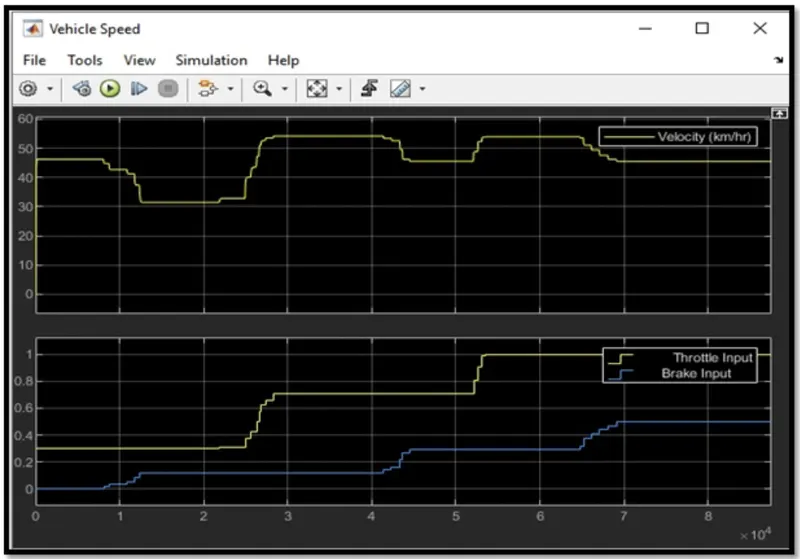
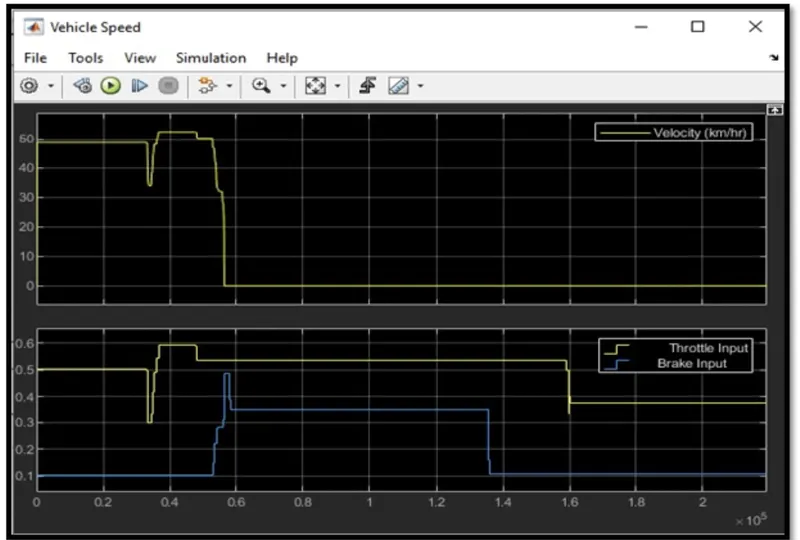
This graph is similar to that of cvt dashboard case . The variation in. vehicle can be observed with change in throttle and break inputs .Withi increase in breaking value ,the speed of vehicle decrease . On the other hand ,increase the throttle leads to increased vehicle velocity .
CVT SHAFT RPM :-
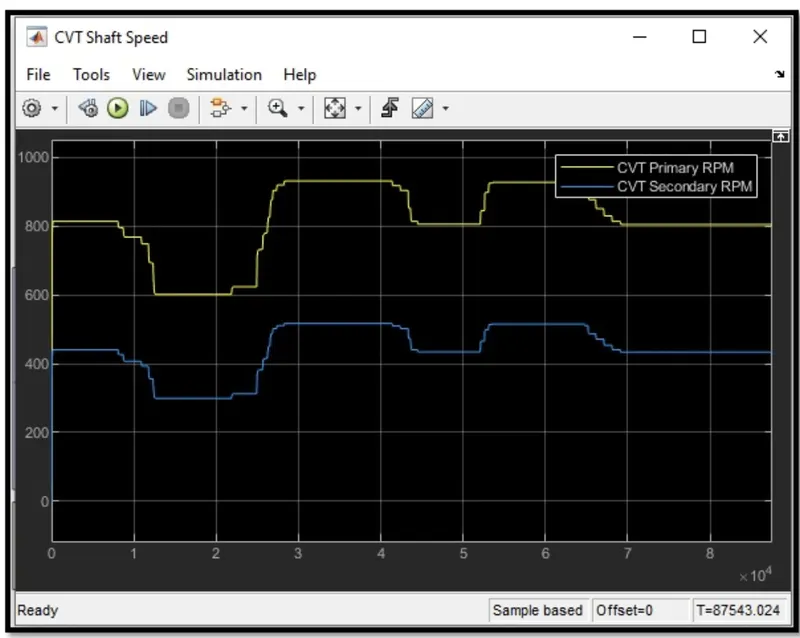
THE graph indicates the variation in rpm of primary and secondary shafts with respect to input parameters .
CONCLUSION :- We have scuccessfuly analysed 4 different models of BAJA ATV with CVT and recorded the outputs :- vehicle velocity & CVT shaft RPM with respect to varitation in inpots throttle and brake .