Project
AIM: To study and analyze the BAJA All Terrain Vehicle model (AVT) using SImulink and compare different models.
OBJECTIVE: The main objective of this project is,
- To prepare a technical report and explaining the functions of the Simulink blocks used for preparing the model.
- To explain all the differences among 'BAJA AVT model', 'BAJA AVT model with dashboard' and 'BAJA AVT model with mapped dashboard', in detail.
ALL TERRAIN VEHICLES:
An all-terrain vehicle (ATV) is defined as a motorized off-highway vehicle designed to travel as a four low-pressure or non-pneumatic tires, having a seat designed to be straddled by the operator and handlebars for steering control. ATVs are subdivided into two types, as a designed by the manufacturer. Type 1 ATVs are intended by the manufacturer for use by a single operator and no passenger. Type 2 ATVs are intended by the manufacturer for use by operator and a passenger, and are equipped with a designated seating position behind the operator.
BAJA SAE:
BAJA SAE is a collegiate design series competition run by the society of automotive engineers (SAE International). Teams of students from universities all over the world design and build small off-road cars. The cars all have engines of the same specifications. As of 2018 the engine has been an unmodified Briggs and Stratton Model 19 Vanguard engine single cylinder with displacement of 305cc and power output of approximately 10bhp(7.5kW).
The goal in BAJA SAE racing is to design, build and race off-road vehicles that can withstand the hardest elements of rough terrain. The vehicles used in BAJA SAE racing are often similar in appearance to dune buggies. Before 2007, the events were called ‘Mini Baja’.
CONTINUOUSLY VERIABLE TRANSMISSION (CVT):
A continuously variable transmission (CVT) in an automatic, single-speed and gearless transmission that can shift through an infinite number of gear ratios. A continuously variable transmission (CVT) is a transmission that operates on an ingenious pulley system that automatically varies the transmission ratios, allowing an infinite variability between highest and lowest gears with no discrete steps or shifts. CVTs provide more useable power, better fuel economy and smoother driving experience than traditional transmission that use gearboxes with fixed numbers of gear sets.
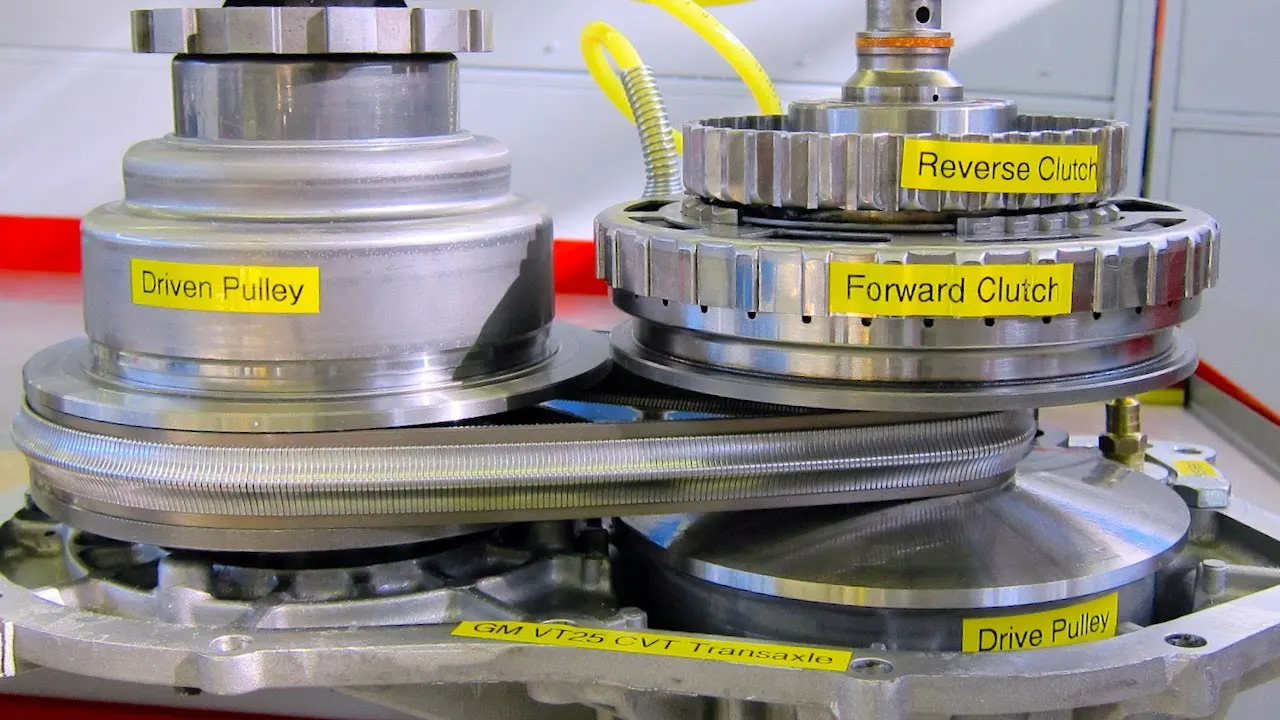
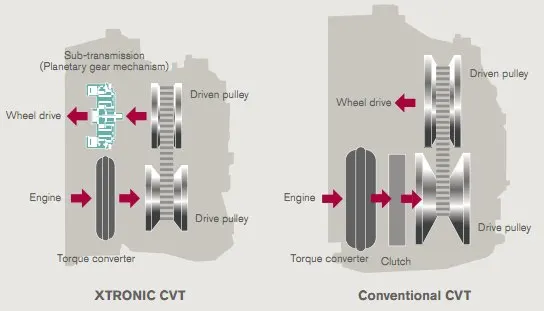
Before entering in to the Vehicle models, lets discuss about the main component (Blocks) used in the vehicle model,
GENERIC ENGINE:
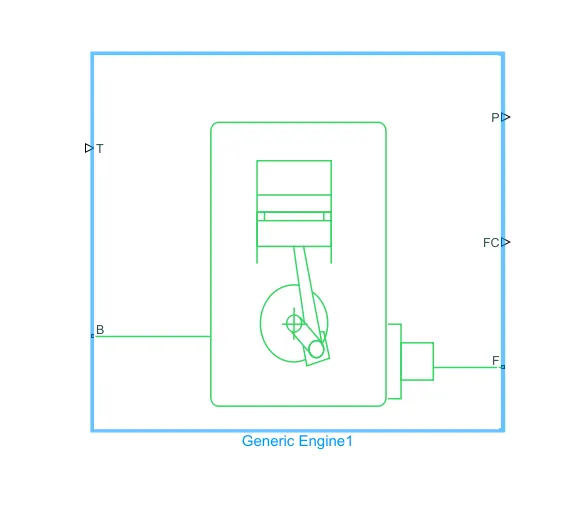
The generic engine block represents a general internal combustion engine. Engine types include spark-ignition and compression-ignition. Speed-power and speed-torque parameterizations are provided. A throttle physical signal input specifies the normalized engine torque, optional dynamic parameters include crankshaft inertia and response lag time. A physical signal port outputs engine fuel consumption rate based on choice of fuel consumption model, optional speed and redline controllers prevent engine stall and enable cruise control.
Main Ports:
- B – Rotational conserving port: Representing the engine block (should be connected to rotational motion reference).
- F – Rotational conversing port: Representing the engine crankshaft
- T – Physical signal input port: Specifying the normalized engine throttle level.
- P – Physical signal output port: Representing the instantaneous engine power, in W.
- FC – Physical signal output port: Representing the fuel consumption rate, in kg/S.
SIMPLE GEAR BLOCK:
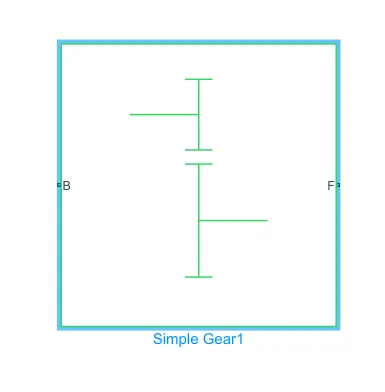
The simple gear block represents a gearbox that constrains the connected driveline axes of the base gear B and the follower gear F to corotate with a fixed ratio that is specified.
The follower- base gear ratio is, `gFB = (rf)/(rB) = (NF)/(NB)`
where,
- NB is the number of teeth in the base gear.
- NBF is the number of teeth in the follower gear.
Main ports:
- B – Base: Rotational mechanical conversing port associated with the base or input shaft.
- F – Follower: Rotational mechanical conversing port associated with the follower or output shaft.
VARIABLE RATIO TRANSMISSION BLOCK:
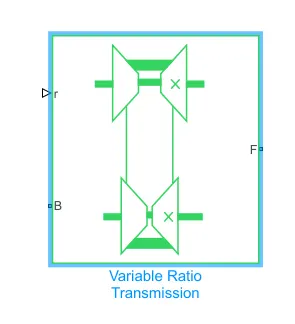
The variable ratio of transmission block represents a gearbox that dynamically transfers motion ad torque between the two connected driveshaft axes and follower.
Ignoring the dynamics of transmission compliance, the driveshafts are constrained to corotate with a variable gear ratio control that you control. You can choose whether the follower axis rotates in the same or opposite direction, wF and wB have opposite signs.
Transmission compliance introduces internal time delay between the axis motions. Therefore, unlike a gear a variable transmission does not act as a kinematic constraint. You can also control torque loss caused by transmission and viscous losses.
Main ports:
- B – Base pulley or Drive pulley.
- F – Follower pulley or Driven pulley.
- r – Variable transmission ratio (input).
VEHICLE BODY BLOCK:
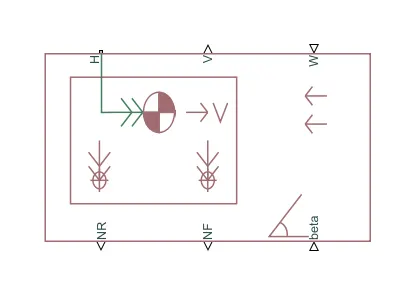
The variable body block represents a two-axle vehicle body in longitudinal motion. The vehicle can have the same or a different number of wheels on each axle.
The block accounts for body mass, aerodynamic drag, road incline (grade), and weight distribution between axles due to acceleration and road profile. Optionally include pitch and suspension dynamics. The vehicle does not move vertically relative to the ground. The block has an option to include an externally defined mass and an externally defined inertia. The mass, inertia, and center of gravity of the vehicle body can vary over the course of simulation in response to system changes.
Input ports:
- Beta – Road Incline Angle (rad): Physical signal input port for road incline angle.
- W – Head wind speed (m/s): Physical signal input port for road incline angle.
- CG – Center of Gravity (m): Physical signal input port of externally defined mass relative to the CG of vehicle (only available with externally defined additional mass is set to on).
- M – Mass (kg): Physical signal input port for mass of the externally defined mass (only available with externally defined additional mass is set to on).
- J – Externally defined moment of inertia (kg*m^2): Physical signal input port of the externally defined mass.
Output ports:
- NR – Rear axle normal force (N): Physical signal output port for the rear axle which is considered positive acting downward.
- NF – Front axle normal force (N): Physical signal output port for the front axle which is considered positive acting downward.
- V – Longitudinal velocity (m/s): Physical output signal of vehicle velocity.
Conserving ports:
- H – Horizontal motion: Conserving port to the horizontal motion of vehicle body (tires should be connected to this port)
DOUBLE SHOE BRAKE:
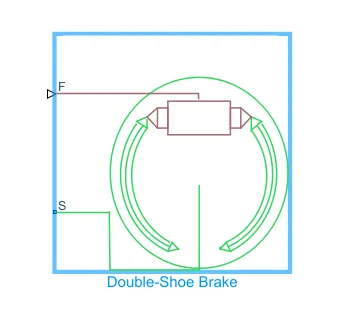
The double shoe brake represents a frictional brake with two pivoted rigid shoes that press against a rotating drum to produce a raking action. The rigid shoes sot inside or outside the rotating drum in a diametrically opposed configuration. A positive actuating force causes the rigid shoes to press against the rotating drum. Viscous and contact friction between the drum the rigid shoe surfaces cause the rotating drum to decelerate.
Double-shoe brakes provide high braking torque with small actuator deflections in applications that include motor vehicles and some heavy machinery. The model employs a simple parameterization with readily accessible brake geometry and friction parameters.
Input ports:
F – Physical signal input port associated with the applied actuating force.
Conserving ports:
S – Rotational conserving port associated with the rotating drum shaft.
TIRE (MAGIC FORMULA) BLOCK:
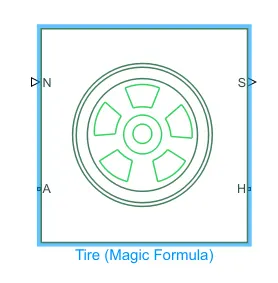
The tire (magic formula) block models a tire with longitudinal behavior given by the magic formula, an empirical equation based on four fitting coefficients. The block can model tire dynamics under constant or variable pavement conditions.
The longitudinal direction of the tire is the same as its direction of motion as it rolls on pavement. This block is a structural component based on the tire road interaction block. To increase the fidelity of the tire model, we can specify properties such as tire compliance, inertia and rolling resistance. However, these properties increase the complexity of the tire model and can slow down simulation. Consider ignoring tire compliance and inertia fi simulating the model in real time or if preparing the model for hardware-in-loop (HIL) simulation.
OTHER BLOCKS USED:
- Solver configuration – To specify the solver parameters before starting the simulation.
- Rotational free end – For mechanical components (Tire).
- Custom measure gauge – To measure the brake and throttle input.
- Signal builder – To input the brake, Throttle and CVT ratio.
- Simulink to PS converter – To convert the Simulink signal to Simscape environment.
- PS to Simulink converter – To convert simscape signal to Simulink environment.
- Mechanical Reference – To make sure all the components are clamped to the ground.
- Knob – To increase, decrease and vice versa from the workspace.
- Lookup table – To insert the CVT values from the workspace.
- Step – To increase or decrease an input value for a defined time interval.
- Rotational motion sensor – To sense the rotational motion from the engine and give output as RPM.
- PS terminator – Terminator for unconnected physical signal outputs.
- Inertia – To represent the solid inertia.
- PS constant – Generate constant physical signal.
- Rotational free end – The rotational free end block represents a mechanical rotational port that rotates freely, without torque.
- Scope – To display the output graphs.
- Display – To represent the solid inertia.
BAJA AVT Model Without Dashboard (CVT Model):
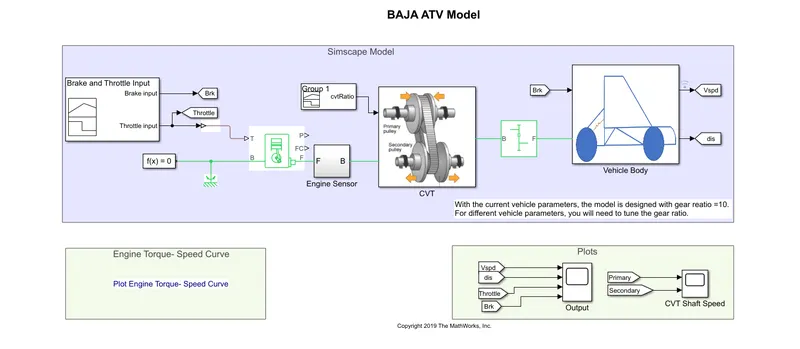
The above model is a basic model, so no need to change the input vaules of Brake, Throttle and CVT ratios. Because the CVT ratio is already generated in signal builder. the generic engine takes the inputs from the work space (Speed and Torque) and it generates the follower speed and inputted to the engine sensor, the engine sensor generates the base signals. Those signals are transfered to the CVT block(subsystem), the output from the CVT block is connceted to simple gear to reduce the speed according to the gear ratio (gear ration is 10). in CVT block the CVT ration reduces the engine speed according to the CVT ration that we have given from the signal builder. The output from the simple gear block is connected to the Vehicle body, the vehicle body moves with the velocty. The vehicle body output is connceted to the velocity and distance output block to visualize the vehicle Velocity and Distance. The Velocity and Distance is connected to scope block to visualize tehe results.
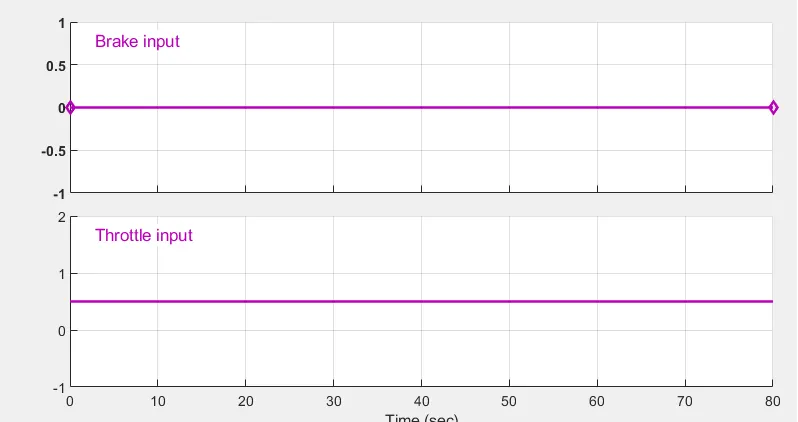
The brake and throttle inputs:
The CVT ratio Inputs:
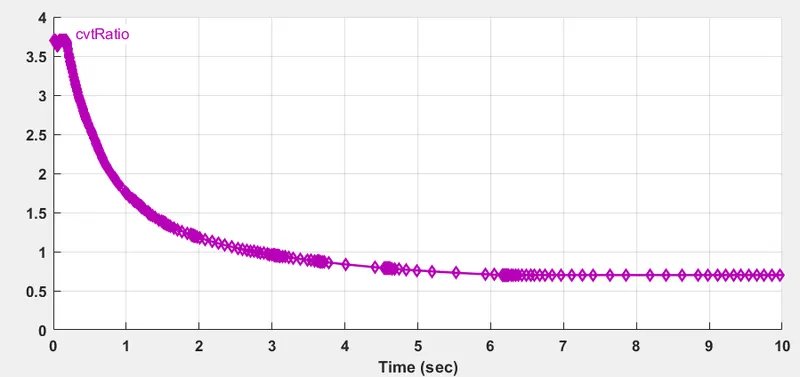
The CVT ratio starts at above 3.5 and then it gradually decreases to less than 1, and the value will remain same for whole simulation.
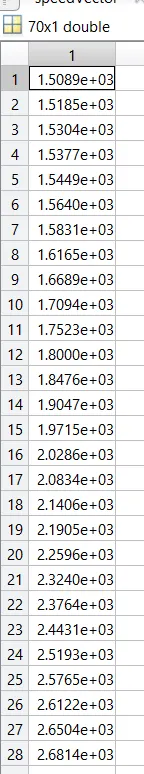
Speed Vector and Torque Vector:
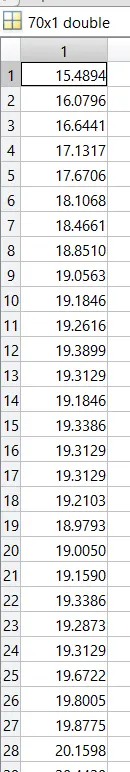
The engine sensor:
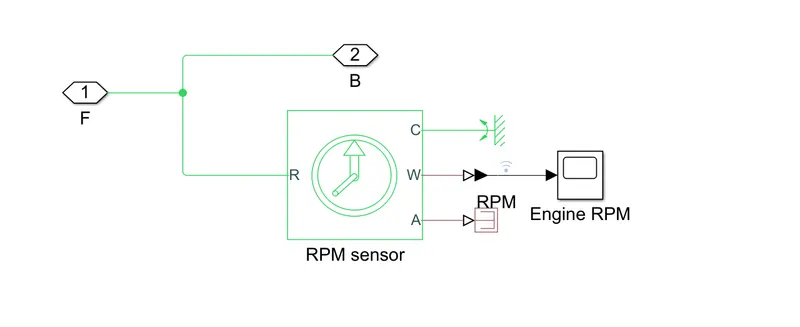
This sub-block measure engine rotational speed as it takes the output of the engine as its input and output engine RPM.
CVT SUBSYSTEM:
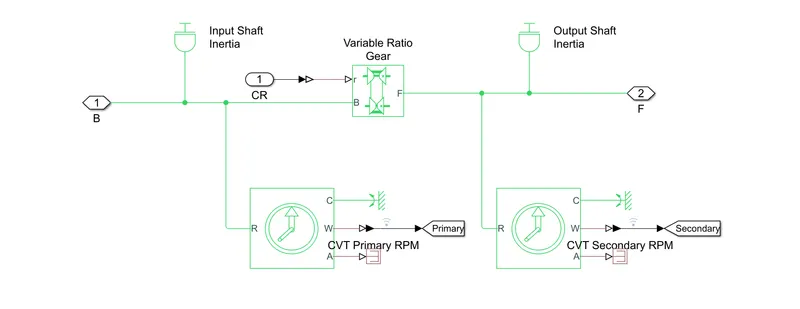
The CVT subsystem provides the input and output shafts of the CVT with inertia and measures the input shaft rpm and the output shaft rpm.
Vehicle body subsystem:
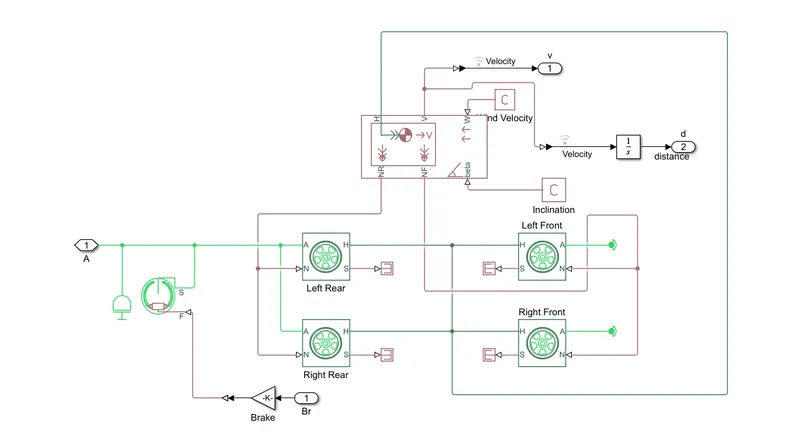
The model shows that the vehicle is rear wheel drive, as the output from the gear box isinputted to the rear axle, then an inertia is added to simulate axle inertia then the shoe brake conserving port is connected to the axle, teh sam eaxle is connected to the rare wheels, while the front wheels are free to rotate on a rotational free end. All the tires H hub port is connected together and then connected to the vehicle H port, also the rear wheels N port is connected together and connected to the vehicle body Nr output ports, while the front wheels are connected to the Nf vehicle body output ports, the vehicle body takes the road inclination and wind velocity from physical constants.
Torque Speed plot:
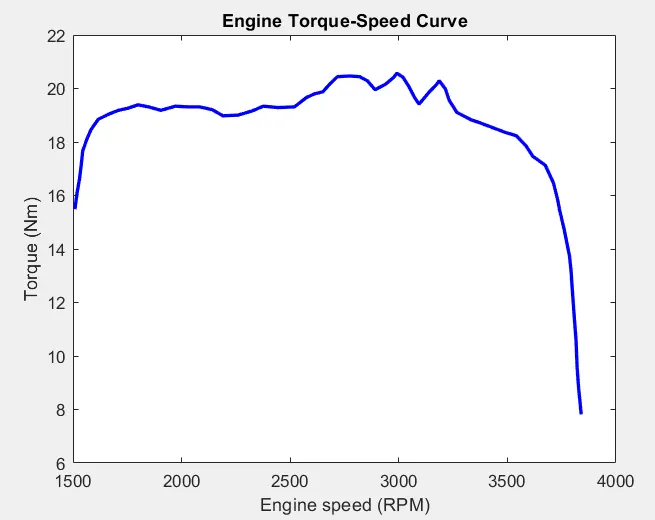
the torque and speed are inputted from the matlab workspace to the generic engine block to generate the output RPM accordingly. This plot behviour is generic to all IC engines.
Output graph for Velocity, Distance, Thottle and Brake:
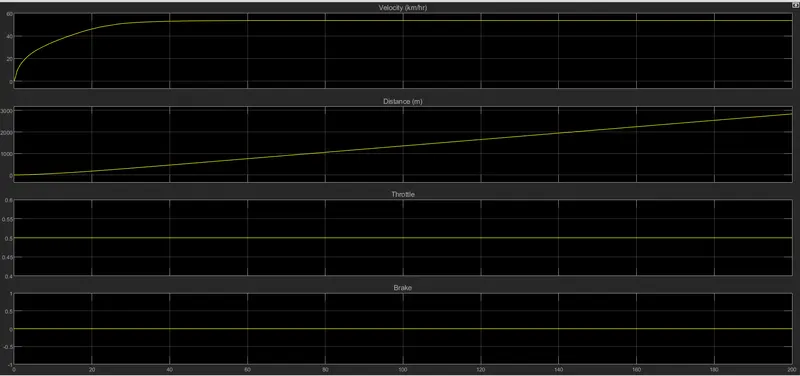
Output of CVT shaft speed:
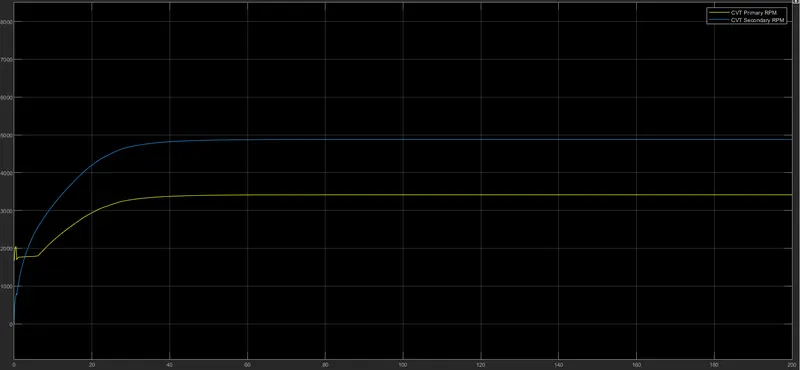
The engine reduced speed is controlled by various CVT ratios. For verification the maximum RPM is calculated by using below formula,
`GearRatio = (Driven)/(Driver)`
`Driven = (Driver)/(GearRatio)`
BAJA AVT Model With Dashboard (CVT Model):
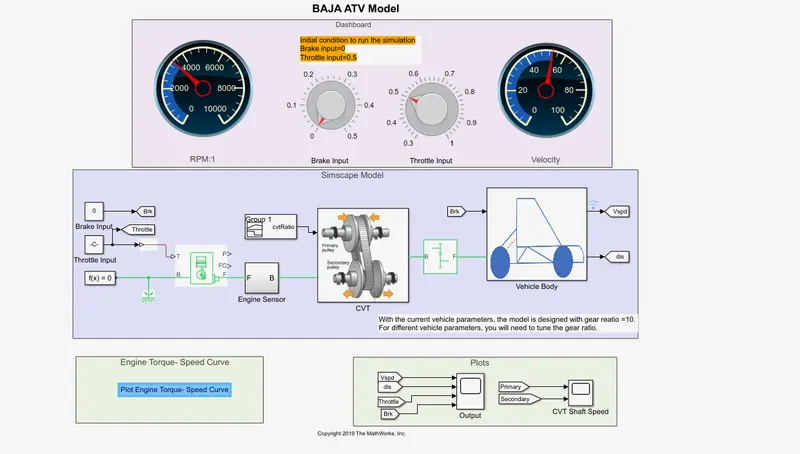
BAJA AVT Model with dashboard CVT Model has a dashboard to see the velocity, Rpm, Throttle input values and Brake input values. In this model we need to change the throttle input 1 to 0.5 and start the simulation. According to the throttle input the Engine RPM and velocity will increase up to certain level, now change the brake and throttle inputs gradually (increase or decrease) we can observe the Velocity and RPM changes in the dashboard.
Keep the brake input 0 and increase the Throttle input, we can observe the velocity and RPM increases according to the throttle input, If we increase the brake input and keep the throttle input at 0.5 the velocity and RPM will decreases, because we are applying the brake load on the wheels so the engine velocity and RPM decreases, Here also the CVT ratio is inputted with the help of signal builder, for this CVT ratio signal builder also no need to change any inputs, because the CVT ratio is already given in the signal builder.
If we observe the scope block, we can understand what happens, while increasing and decreasing the Throttle & Brake inputs and the CVT shaft speed graphs also.
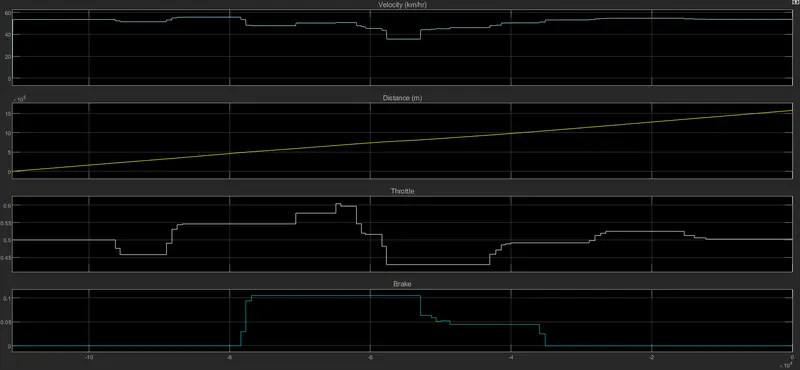
The below scope block visualizes the Velocity, Distance, Throttle and Brake grapghs:
The below scope block graph visualizes the CVT shaft speeds for both promary and secondary:
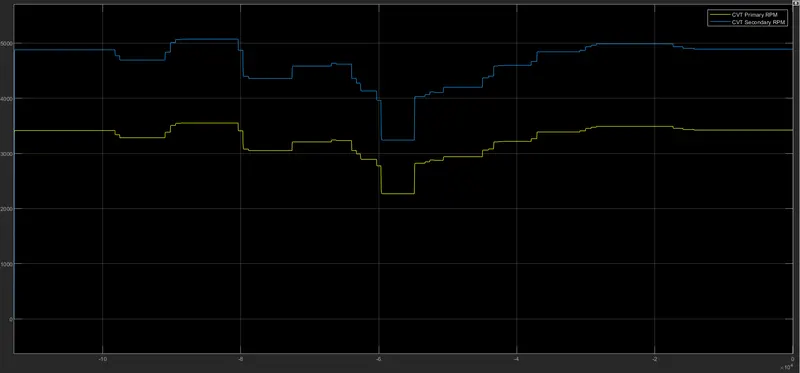
- In the above two grapths (Velocity, Distance, Throttle, Brake and CVT shaft speeds for both primary and secondary shafts) we can observe that the graph pointer moves upward when the throttle input is increased(brake input is 0), if the grapth will be downfalls when the throttle decrease or kepp it same and increases the brake input. if the brake input increase the RPM and velocity will drcreases with respect to the brake input.
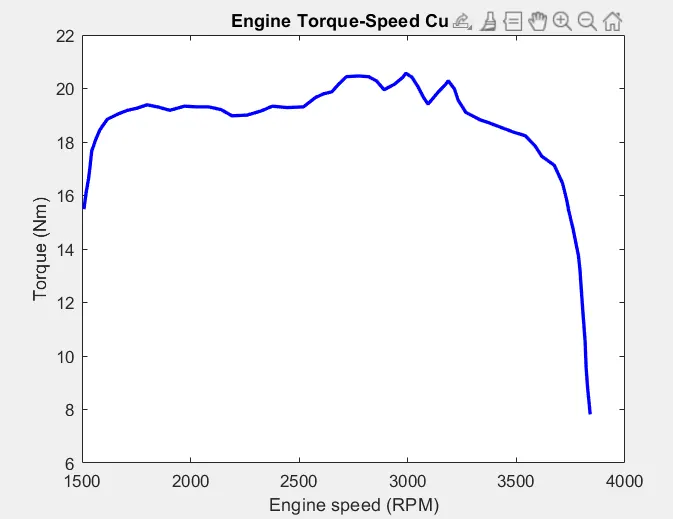
According to the below engine torqe and speed plot the engine torque ad speed will be given as an input to the Generic Engine block.
BAJA AVT Model-Mapped Lookup Tabel With Dashboard (CVT Model-Dashboard-Mapped):
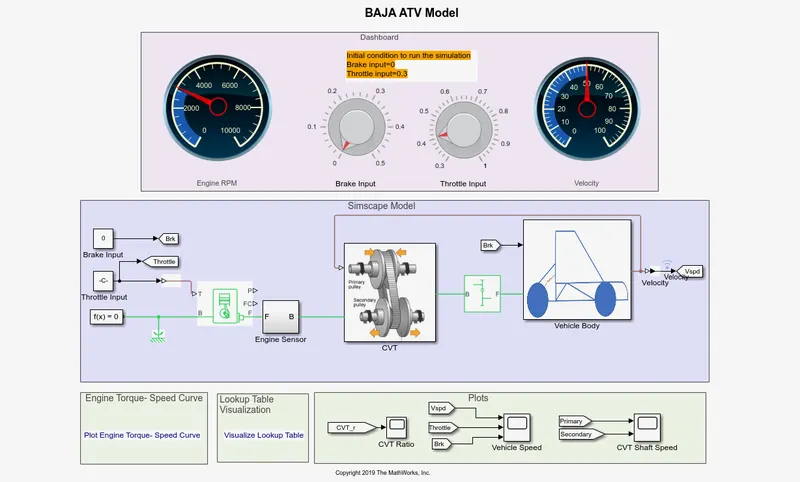
The BAJA AVT Mapped Lookup Tabel with Dashboard (CVT Model-Dashboard-Mapped) model has a Dashboard to visualize the Velocity, Engine RPM, Brake input and Throttle input. The initial condition of throttle input must be 0.3 and brake input will be 0. We can give the throttle and brake inputs from the Simscape model and from the dashboard also by moving the pointer in the dashboard knob. Here in this model the we don't use any signal builder block to give CVT Ratio to the CVT block, we used a loop to give CVT ratio instead of using using signal builder block. The vehicle body block output velocity loop is connected the CVT input port, with respect to the velocity the speed will be controlled in the CVT subsystem. In the CVT subsystem a 'Lookup' table is used to give the CVT rtaio data from the MATLAB workspace. The output from the CVT block is connected to the simple gear block in this block the speed will be controlled according to the gear ratio, here the gear ration is 12. The output from the simple gear block is connceted to the vehicle body, the vehicle body is also inputted with the brake input. The vehicle body output (velocity) is connceted to the scope block to visualize the velocity at different throtte and brake inputs, this output velocity is fed to the CVT subsystem as an input.
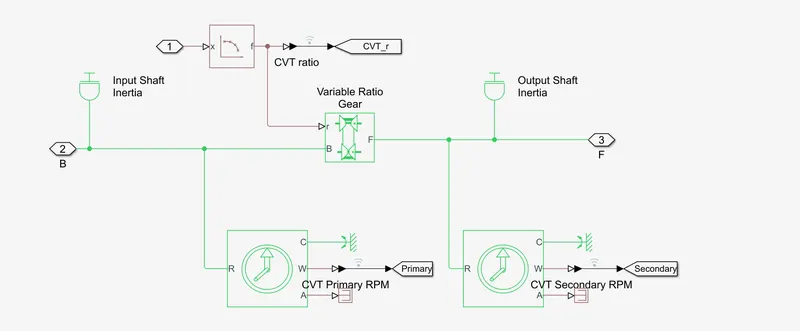
A lookup table block uses an array of data to map input values to output values, approximating a mathematical function. Given input values, Simulink performs a “lookup” operation to retrieve the corresponding output values from the table. Likewise, the lookup table outputs 27 in response to an input of 3. Here the lookup table is used to give the input of 'cvtr' data from MATLAb workspace. According to that data the CVT block will controll the speed of the vehicle.
The Engine Torque and Speed curve:
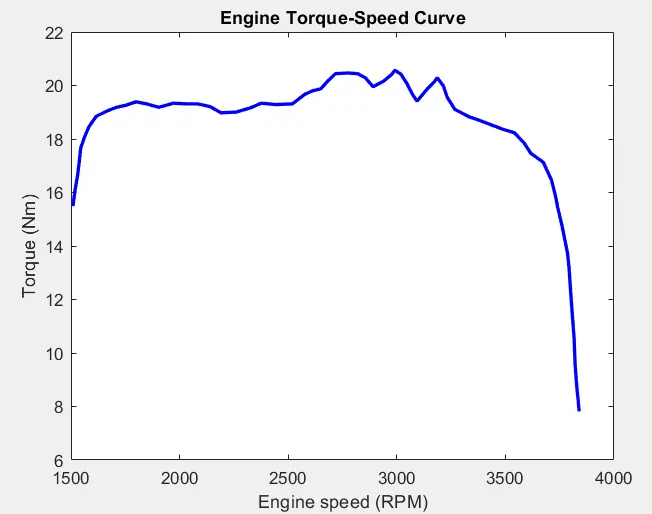
The above Engine speed an torque plot shows the input of engine speed and torque data.
LookUp Table Visualization:
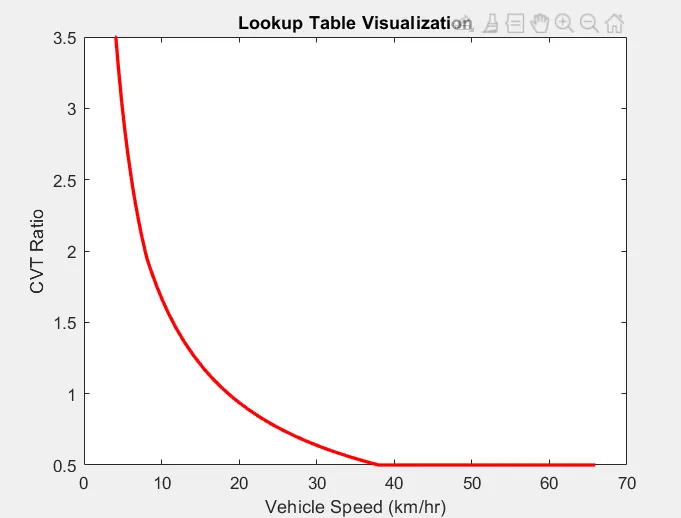
The above figure (plot) visualizes the CVT Ratio or 'cvrt' data from the workspace. According to the above plot the data will be inputted to the Lookup table.
Graphs for Velocity, Throttle input and Brake input:
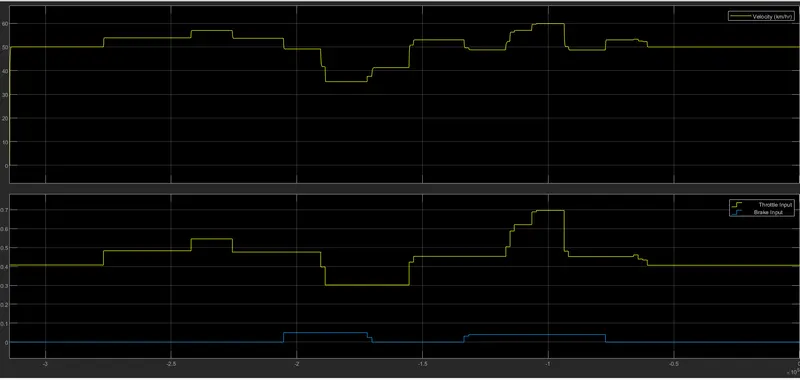
The above plot visualizes the output Velocity of the vehicle and Throttle & Brake inputs. With respect to the throttle and brake inuts the graph will changes. If the throttle input is increased gradually the velocity and RPM will also increases wrt throttle input. if the brake input increases the velocity and RPM will be decreased wrt to the brake input. The brake input applies the load on brakes the brakes applies the load on wheels, automatically the velocity and RPm will be decreases.
Graphs for bothe CVT Primary and Secondary RPM:
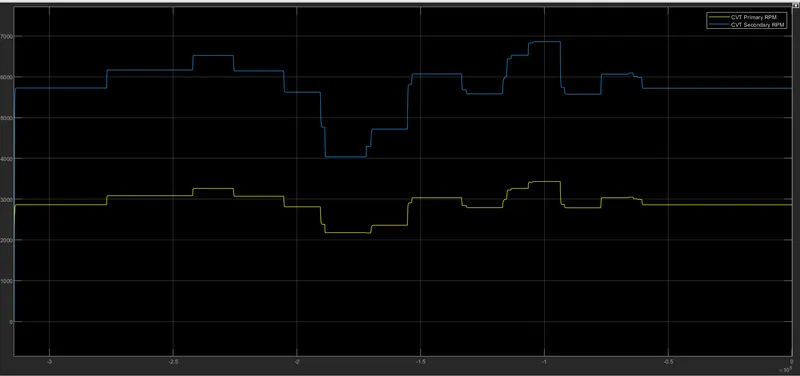
The above plit visualizes the CVT shaft speed for both primary and secondary shafts. For this CVT shaft speed is get controlled with resect to the throttle and brake inputs.