Project
AIM: To prepare a technical report of an All-Terrain Vehicle (ATV) under the different conditions.
INPUT MODEL: The Simulink model for the All-Terrain Vehicle (ATV) is shown below.
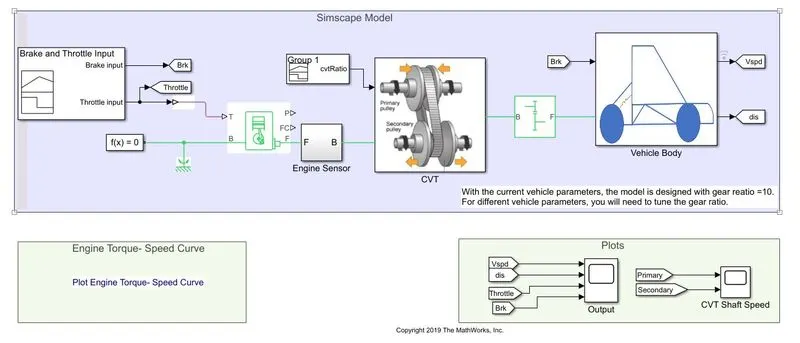
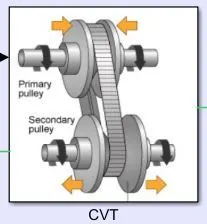
1. CVT (Continuously Variable Transmission): CVT is a type of automatic transmission that doesn’t have gears like a traditional planetary transmission.
The below figure represents the Simulink model of CVT.
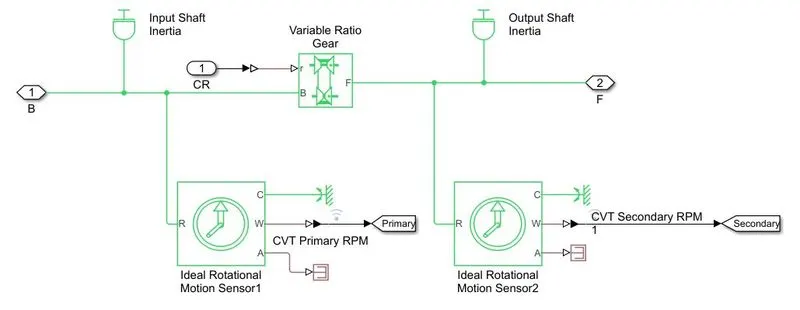
a. Variable Ratio Gear:
Represents a variable ratio gearbox such as implemented by mechanical belt CVT, electric, or hydraulic transmissions. The physical signal input r defines the ratio of input to output angular shaft velocities.
Connections B (base) and F (follower) are mechanical rotational conserving ports. Specify the relation between base and follower rotation directions with the Output shaft rotates parameter.
b. Ideal Rotational Motion Sensor:
This block measures angular velocity or angle in a mechanical rotational network. The sensor is ideal since it does not account for inertia, friction, delays, energy consumption, and so on.
The physical signal ports W and A report the angular velocity and angle, respectively, of port R relative to port C. The measured angular velocity is positive when the angular velocity at port R is greater than the angular velocity at port C.
c. Input Shaft Inertia:
The block represents an ideal mechanical rotational inertia.
The block has one or two mechanical rotational conserving ports. The difference is purely graphical, as the ports are rigidly linked. The block's positive direction is from its port to the reference point. This means that the inertia torque is positive if the inertia is accelerated in the positive direction.
2. Components inside Vehicle Body block:
a. Vehicle Body:
Represents a two-axle vehicle body in longitudinal motion. The block accounts for body mass, aerodynamic drag, road incline, and weight distribution between axles due to acceleration and road profile. The vehicle can have the same or a different number of wheels on each axle. Optionally include pitch and suspension dynamics or additional variable mass and inertia. The vehicle does not move vertically relative to the ground.
Connection H is the mechanical translational conserving port associated with the horizontal motion of the vehicle body. The resulting traction motion developed by tires should be connected to this port. Connections V, NF, and NR are physical signal output ports for vehicle velocity and front and rear normal wheel forces, respectively. Wheel forces are considered positive if acting downwards. Connections W and beta are physical signal input ports corresponding to headwind speed and road inclination angle, respectively. If the variable mass is modeled, the physical signal input ports CG and M are exposed. CG accepts a two-element vector representing the x and y distance offsets from vehicle CG to additional load mass CG. M represents the additional mass. If both variable mass and pitch dynamics are included, the physical signal port J accepts the inertia of the additional mass about its own CG.
b. Double-Shoe Brake:
Represents a brake arranged as two pivoted rigid shoes symmetrically installed inside or outside a drum and operated by one actuator. The actuator force causes the shoes to exert friction torque on a shaft connected to the drum.
Connection S is a conserving rotational terminal associated with the drum shaft. Connection F is a physical signal port representing the force input to the actuator. Positive force creates friction torque that resists shaft rotation. Optionally include thermal effects and expose thermal conserving port H by setting Thermal port to Model.
c. Tire:
Represents the longitudinal behavior of a highway tire characterized by the tire Magic Formula. The block is built from Tire-Road Interaction (Magic Formula) and Simscape Foundation Library Wheel and Axle blocks. Optionally, the effects of tire inertia, stiffness, and damping can be included.
Connection A is the mechanical rotational conserving port for the wheel axle. Connection H is the mechanical translational conserving port for the wheel hub through which the thrust developed by the tire is applied to the vehicle. Connection N is a physical signal input port that applies the normal force acting on the tire. The force is considered positive if it acts downwards. Connection S is a physical signal output port that reports the tire slip. Optionally expose physical signal port M by setting Parameterize by to Physical signal Magic Formula coefficients. Physical signal port M accepts a four-element vector corresponding to the B, C, D, and E Magic Formula coefficients.
d. Simple Gear
Represents a fixed-ratio gear or gearbox. No inertia or compliance is modeled in this block. You can optionally include gear meshing, backlash, and viscous bearing losses.
Connections B (base) and F (follower) are mechanical rotational conserving ports. Specify the relation between base and follower rotation directions with the Output shaft rotates parameter. Optionally include thermal effects and expose thermal conserving port H by setting the Friction model to a temperature-dependent setting.
e. Generic Engine:
Represents a system-level model of spark-ignition and diesel engines suitable for use at the initial stages of modeling when only the basic parameters are available. Optional idle speed and red line controllers are included.
The throttle input signal T lies between zero and one and specifies the torque demanded from the engine as a fraction of the maximum possible torque. If the engine speed falls below the Stall speed, the engine torque is blended to zero. If the engine speed exceeds the maximum speed, the simulation stops and issues an error message.
Connections F and B are mechanical rotational conserving ports associated with the engine crankshaft and engine block, respectively. Connections P and FC are physical signal output ports through which engine power and fuel consumption rate are reported.
CASE 1: Simulink model for BAJA ATV with CVT using Dashboard taking Brake input= 0, and Throttle input= 0.5
INPUT MODEL:
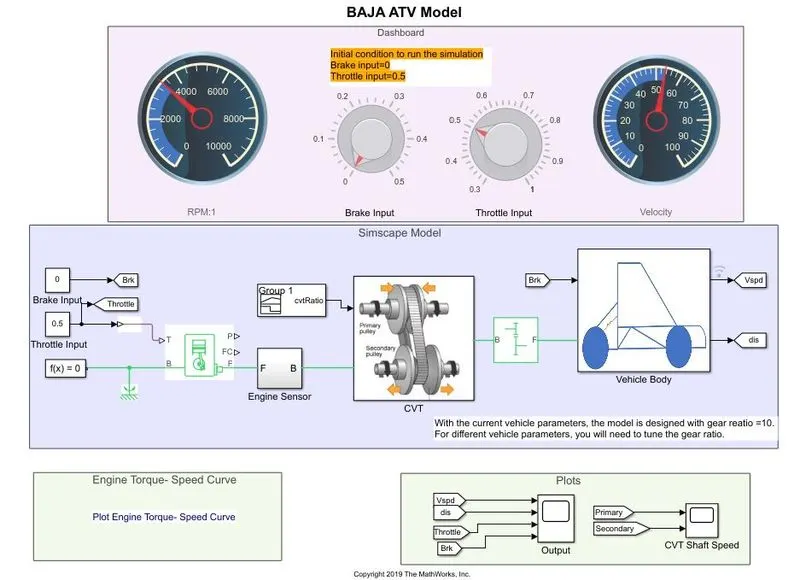
In this model, the dashboard is provided to control the inputs (brake and throttle) which helps us to verify the outputs in a real-time situation. Here we have considered brake=0 and throttle=0.5.
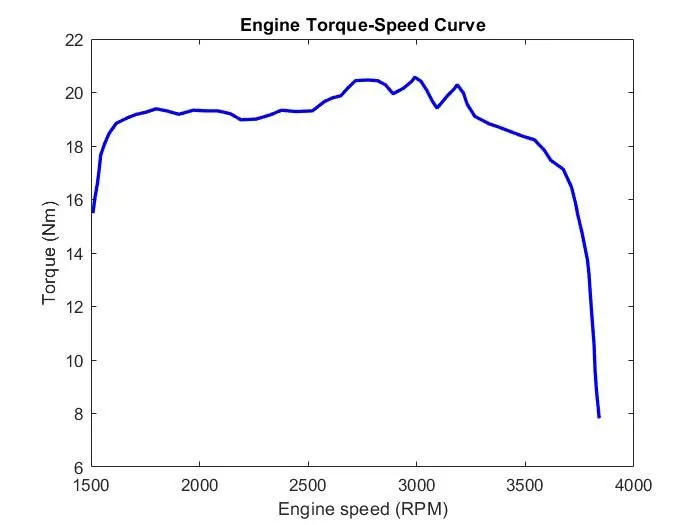
The below graph shows the graph of Engine torque vs speed curve.
OUTPUT: The below graph is a plot of vehicle speed w.r.t throttle and brake input.
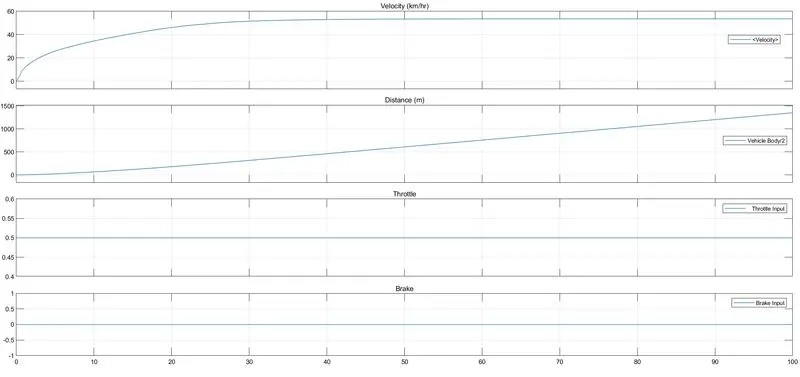
Referring to the above graph we can observe that the vehicle speed is increased from 0 to 53kmph for a constant 0.5 throttle value and 0 brake input. As the brake value increases beyond 0 or as the throttle value decreases, the speed of the vehicle decreases.
CASE 2: Simulink model for BAJA ATV with CVT using Dashboard taking Brake input= 0, and Throttle input= 0.3
INPUT MODEL: 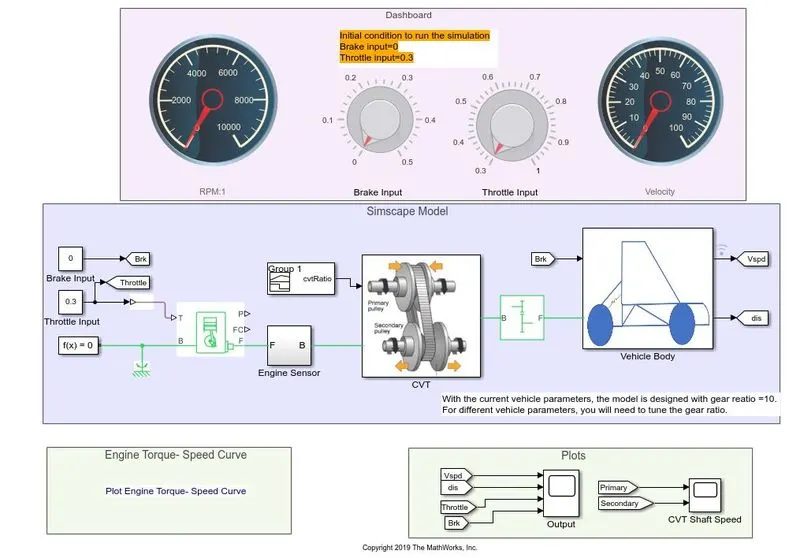
In this model, we have considered brake=0 and throttle=0.3.
The below graph shows the graph of Engine torque vs speed curve.
OUTPUT: The below graph is a plot of vehicle speed w.r.t throttle and brake input.
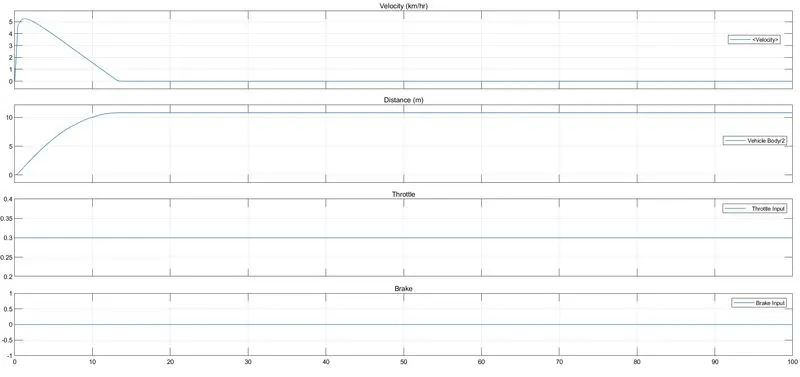
Referring to the above graph we can observe that the vehicle speed is increased from 0 to 53kmph for a constant 0.3 throttle value and 0 brake input. As the brake value increases beyond 0 or as the throttle value decreases, the speed of the vehicle decreases.
Case 3: Simulink model for BAJA ATV with CVT using Dashboard taking Brake input= 0.2, and Throttle input= 0.3
INPUT MODEL:
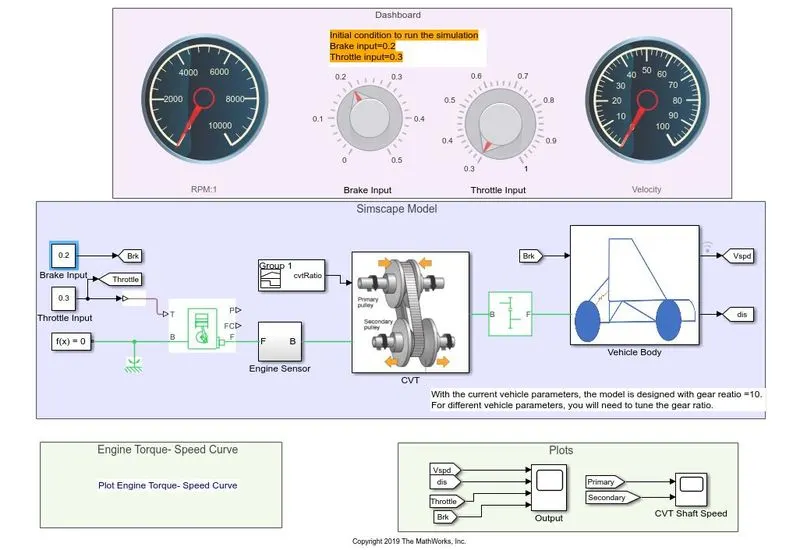
In this model, we have considered brake=0.2 and throttle=0.3.
The below graph shows the graph of Engine torque vs speed curve.
OUTPUT: The below graph is a plot of vehicle speed w.r.t throttle and brake input.
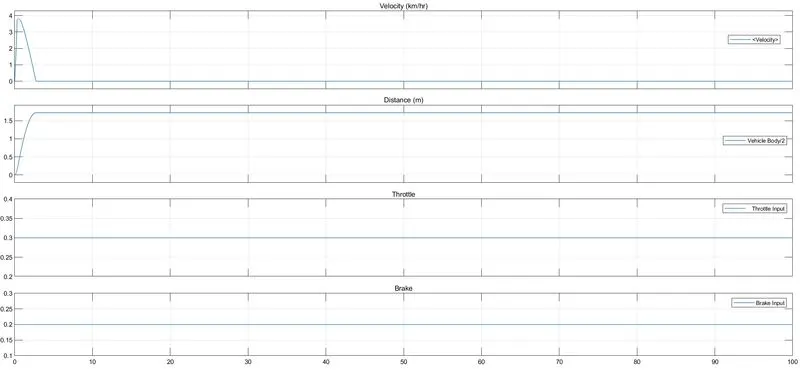
Referring to the above graph we can observe that the vehicle speed is increased from 0 to 53kmph for a constant 0.3 throttle value and 0.2 brake input. As the brake value increases beyond 0 or as the throttle value decreases, the speed of the vehicle decreases.