Project 2 - Speed Control of a Direct Current (DC) motor
The Project is based on speed control of a DC Motor using PID Controller. Initially,simulink model of a DC Motor is constructed and it is made as a subsystem. Then, Subsystem of DC motor is connected to the PID controller to maintain the desired speed as it is.
Block diagram of DC motor is as shown below:
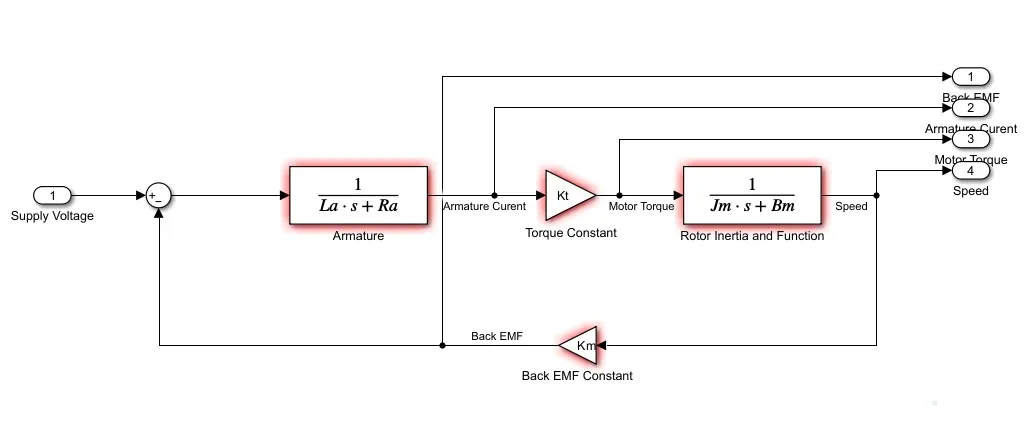
Values of La, Ra, Kt, Jm, Bm and Km are defined using m file. Parameters are as shown below:
Jm=0.01;
Bm=0.1;
Km=0.01;
Kt=0.01;
Ra=1;
La=0.5;
Results obtained are shown below
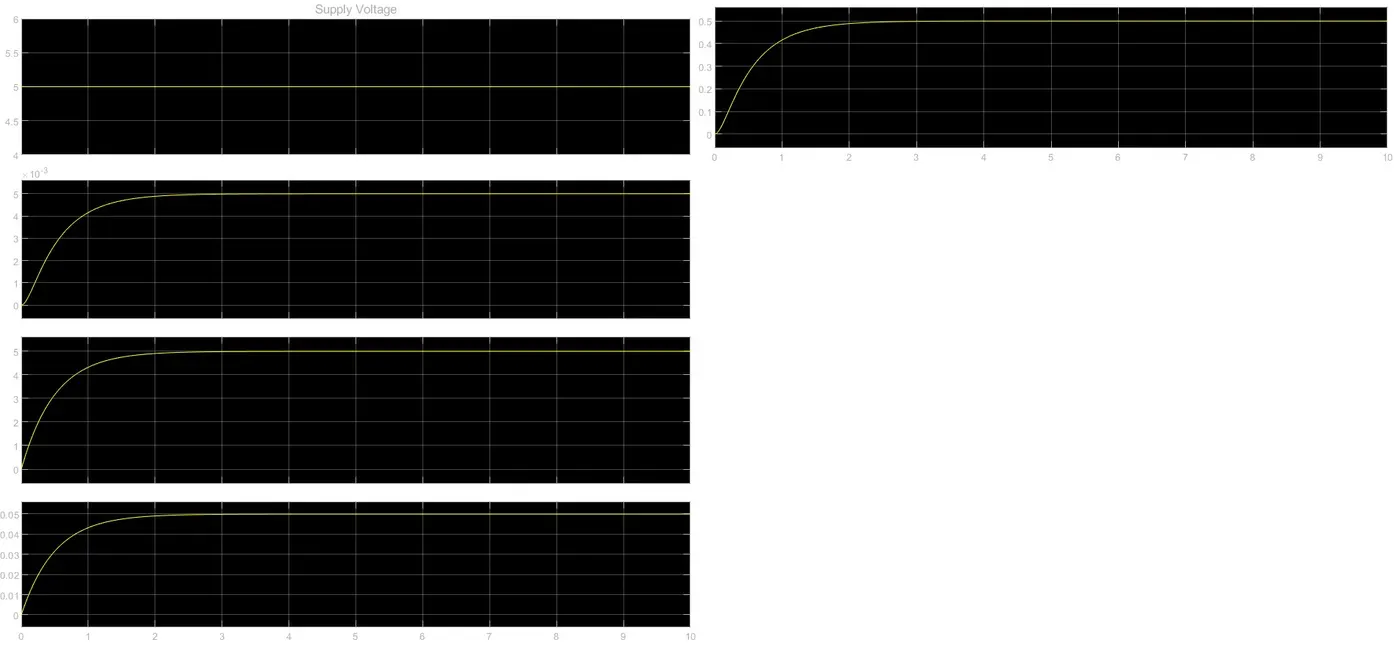
Reference value is given as 5. From the values it can be seen that values are settled after 2 seconds. Now PID controllers are provided in order to get the desired speed and results. Block diagram of the same is shown below.
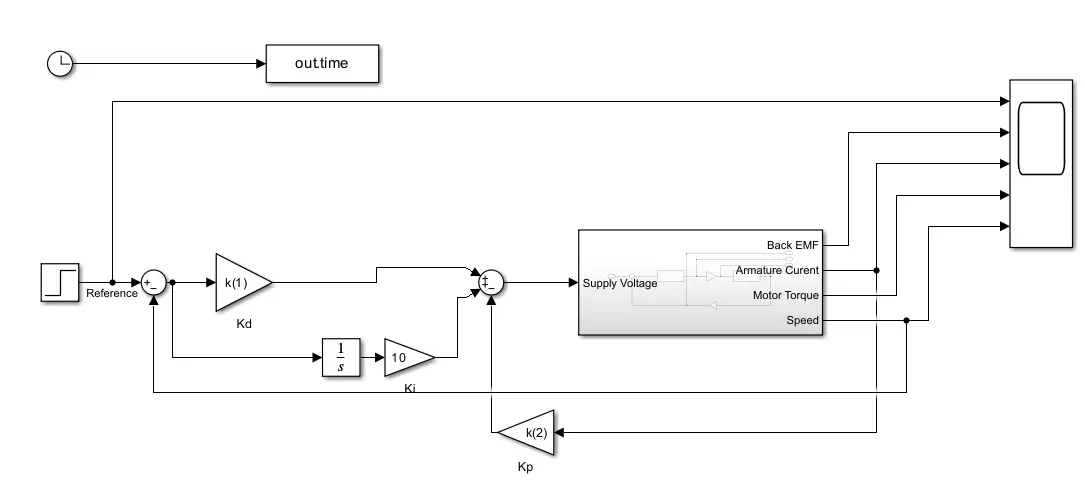
Values of Kp and Kd are obtained by K mapping. Programme is set as below:
A=[-Bm/Jm Kt/Jm;-Km/La -Ra/La];
B=[0; 1/La];
fn=1;
wn=2*pi*fn;
zeta=0.5;
p1=-zeta*wn+wn*sqrt(zeta^2-1);
p2=-zeta*wn-wn*sqrt(zeta^2-1);
P=[p1;p2];
k= place (A,B,P);
Values of Kp and Kd obtained are:
k =
38.3133 -2.8584
Model is run by putting above values. Output obtained with no Integral controller are shown below:
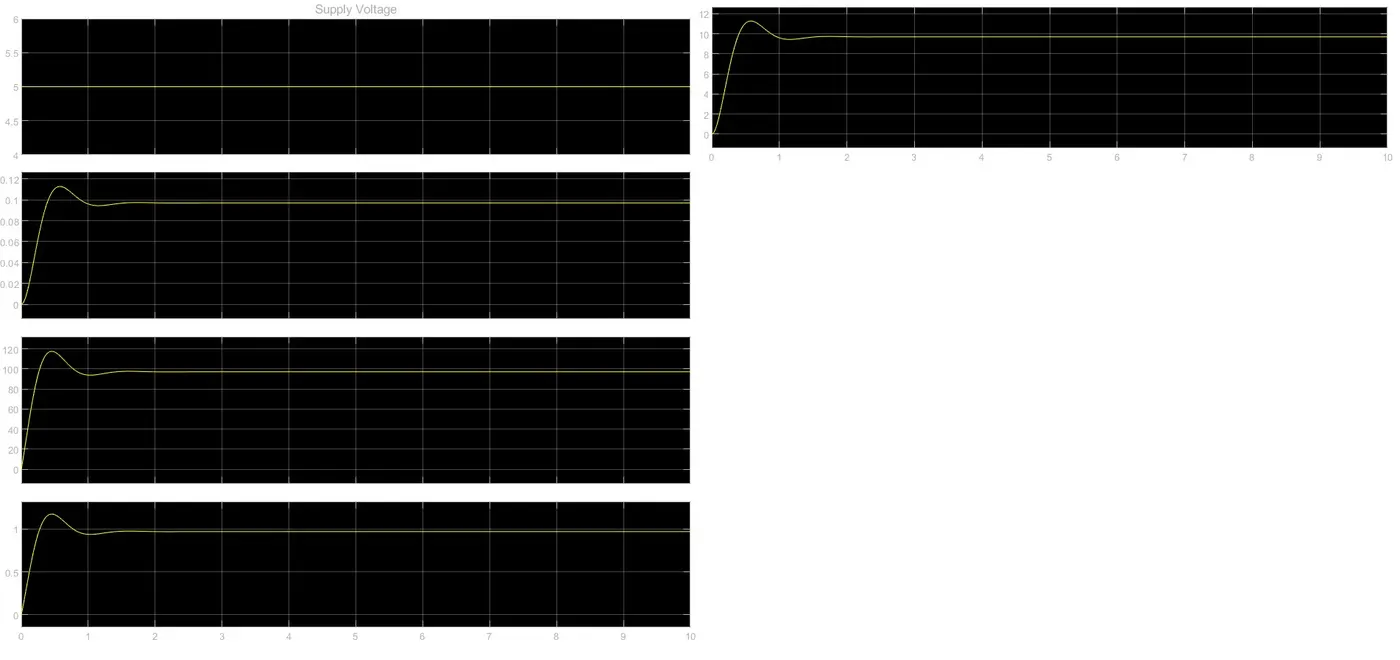
It can be seen that output value hase settled to its final value by 1.5 seconds. But there is an overshoot in the output. Now Ki is applied to the system. Value of Ki is taken as 100.
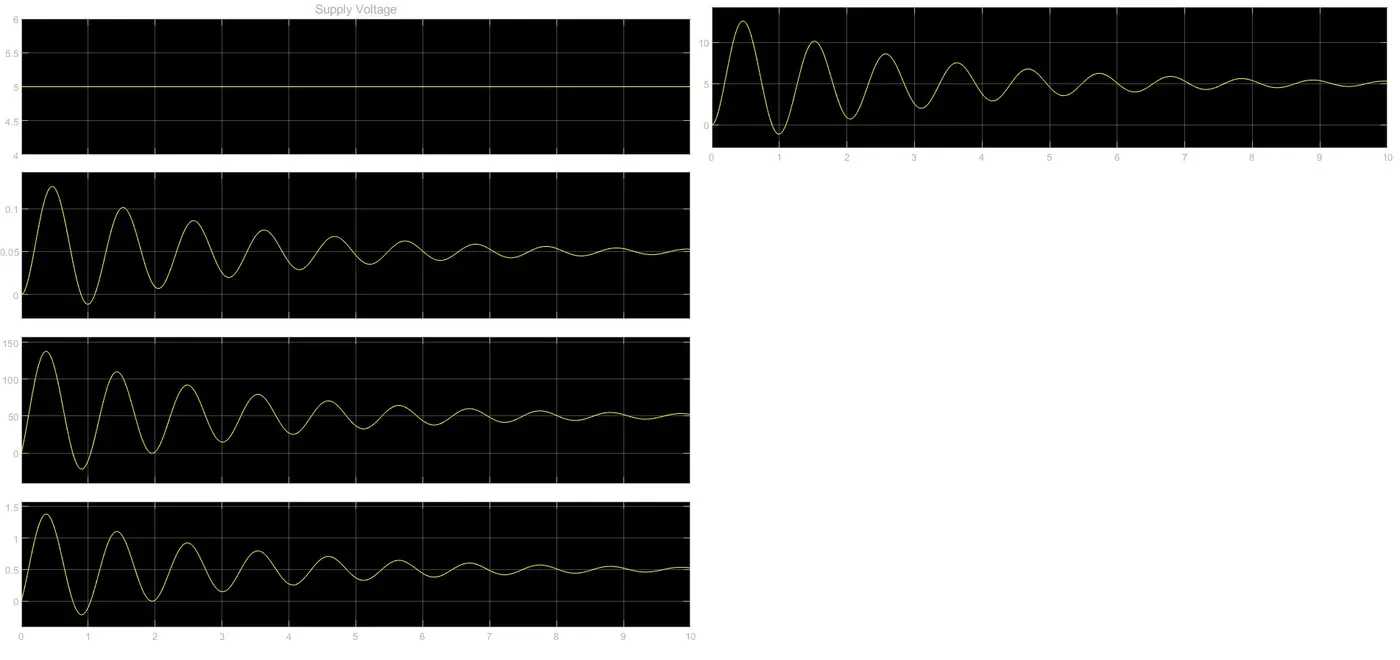
It can be seen from the results that there is large oscillations in the output. When value of Ki is increased output has become more unstable. So, value of Ki is decreased to 10. Result obtained is shown below.
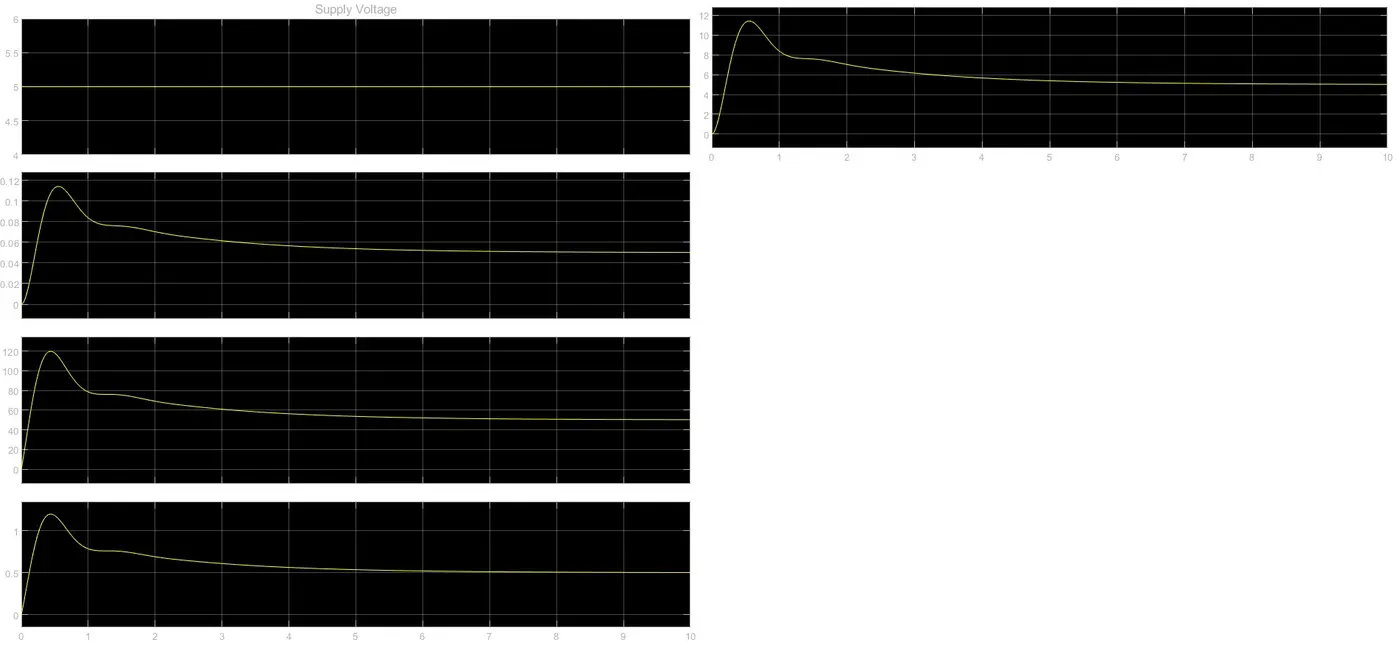
From the results there is a steep reduction in the final value. So it can be judged that in order to get the better results in terms of setting time, overshoot and steady state error, integral controller can be neglected. Results obtained is shown earlier.