Project 2 - Measuring the distance of an object using ultrasonic sensor and also smoothen the sensor data using moving average filter
OFFLINE EMBEDDED BATCH NO:1
Project 2 - Measuring the distance of an object using an ultrasonic sensor and also smoothening the sensor data using a moving average filter
Overview of the Project:
In this project the implementation of code for “Measuring the distance of an object using ultrasonic distance sensor (28015 Ping) and also smoothen the sensor data using moving average filter”.
Goals:
- Measuring the distance in terms of inches of an object using an Ultrasonic Distance Sensor (28015 Ping).
- The sensor data is smoothened by using the Moving average filter technique to eliminate the high-frequency variations from the sensor data.
Key Highlights of the Project:
- Measuring the distance traveled by the wave to the object and gets bounced back from the object to the sensor.
- Smoothening the sensor data by moving average filter technique, the filter has a window of a certain size. That window determines how much data the filter can take.
Deliverables of this project:
- The distance traveled by a wave to the object for which we want to measure the distance using Ultrasonic Distance Sensor (28015 Ping).
- Eliminate the high-frequency jitters from the sensor data by Moving the Average filter to smoothen the sensor data.
Expected Outcomes:
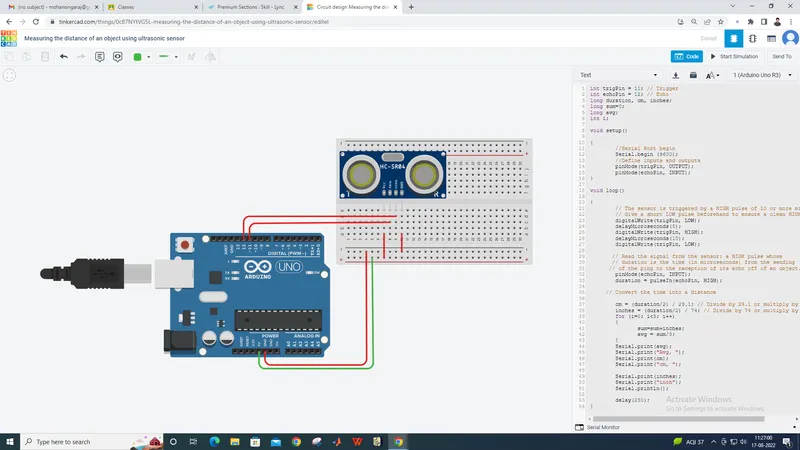
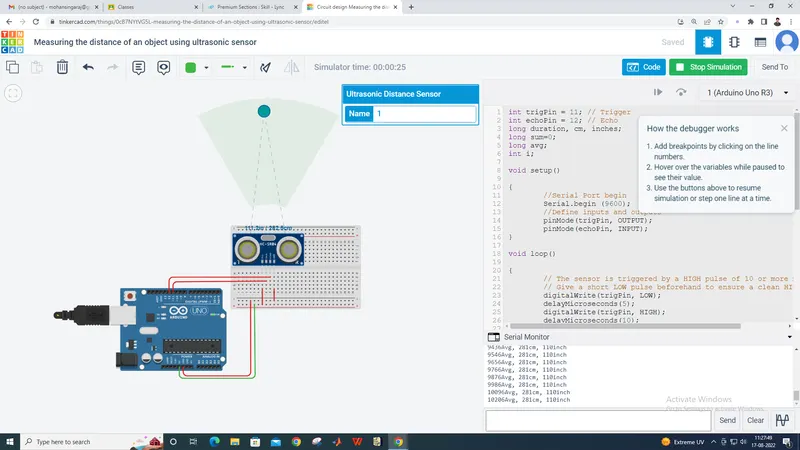
The students will get Knowledge on Ultrasonic sensors (28015 Ping) to measure the distance traveled by wave to the object, the hardware connection of 2 Arduino connected to the sensor, and smoothening the sensor data by removing high-frequency variations using the Moving Average Filter Technique.
PROGRAM:
int trigPin = 11; // Trigger pin is connected to 11 pin
int echoPin = 12; // Echo Pin is connected to 12 pin
long duration, cm, inches;
long sum=0;
long avg;
int i;
void setup()
{
//Serial Port begin
Serial.begin (9600);
//pinMode of trigPin,echoPin
pinMode(trigPin, OUTPUT);
pinMode(echoPin, INPUT);
}
void loop()
{
// The sensor is triggered by a HIGH pulse of 10 or more microseconds.
// Give a short LOW pulse beforehand to ensure a clean HIGH pulse:
digitalWrite(trigPin, LOW);
delayMicroseconds(5);
digitalWrite(trigPin, HIGH);
delayMicroseconds(10);
digitalWrite(trigPin, LOW);
// Read the signal from the sensor: a HIGH pulse whose
// duration is the time (in microseconds) from the sending
// of the ping to the reception of its echo off of an object.
pinMode(echoPin, INPUT);
duration = pulseIn(echoPin, HIGH);
// Convert the time into a distance
cm = (duration/2) / 29.1; // Divide by 29.1 or multiply by 0.0343
inches = (duration/2) / 74; // Divide by 74 or multiply by 0.0135
for (i=0; i<5; i++)
{
sum=sum+inches;
avg = sum/5;
}
Serial.print(avg);
Serial.print("Avg, ");
Serial.print(cm);
Serial.print("cm, ");
Serial.print(inches);
Serial.print("inch");
Serial.println();
delay(250);
}