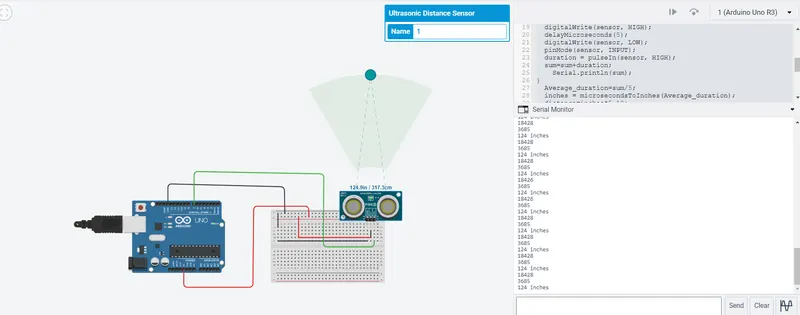
Project 2 - Measuring the distance of an object using ultrasonic sensor and also smoothen the sensor data using moving average filter
Project 2 - Measuring the distance of an object using ultrasonic sensor and also smoothen the sensor data using moving average filter
In this project ultrasonic sensor is used to measure the distance of an object. The sensor used is 28015 Ping.
Working of 28015 Ping
The PING sensor measures distance using sonar; an ultrasonic (well above human hearing) pulse is transmitted from the unit and distance-to-target is determined by measuring the time required for the echo return. Output from the PING sensor is a variable-width pulse that corresponds to the distance to the target.
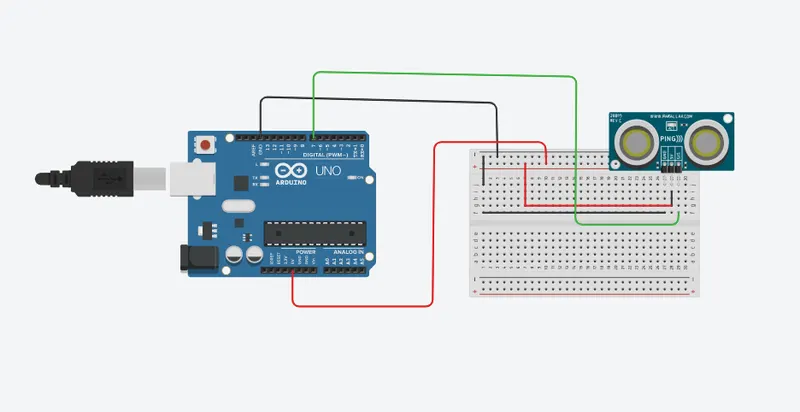
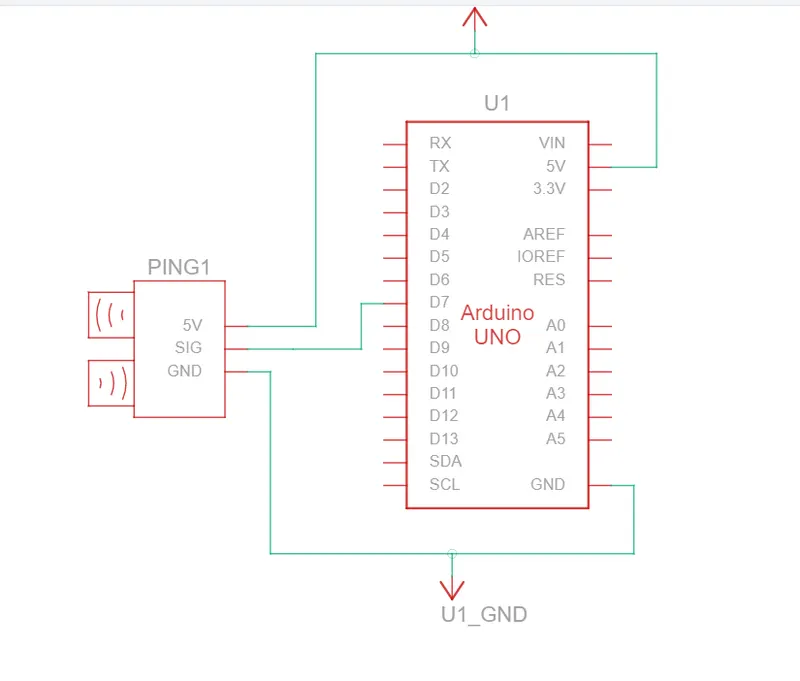
Schematics
Program
const int sensor= 7;
int x;
long duration, inches, Average_duration,i,distance;
void setup() {
// initialize serial communication:
Serial.begin(9600);
}
void loop() {
long sum=0;
for (i=0;i<5;i++); // for the averaging
{
pinMode(sensor, OUTPUT);
digitalWrite(sensor, LOW);
delayMicroseconds(2);
digitalWrite(sensor, HIGH);
delayMicroseconds(5);
digitalWrite(sensor, LOW);
pinMode(sensor, INPUT);
duration = pulseIn(sensor, HIGH);
sum=sum+duration;
Serial.println(sum);
}
Average_duration=sum/5;
inches = microsecondsToInches(Average_duration);
distance=inches*5.18;
Serial.println(Average_duration);
Serial.print(distance);
Serial.print(" inches");
Serial.println();
delay(100);
}
// to convert duration to distance in inches
long microsecondsToInches(long microseconds) {
return microseconds / 74 / 2;
}
output